Project 2 - Measuring distance of an object using ultrasonic sensor (HC-SR04)
1,
AIM:
In this project, the implementation of code for “Measuring distance of an object using ultrasonic distance sensor (HC-SR04)
Goals:
- Measuring the distance of an object using Ultrasonic Distance Sensor (HC-SR04)
- Usage of Input Capture Mode
Key Highlights of the Project:
- Measuring the distance travelled by the wave to the object and gets bounced back from the object to sensor.
- Measuring Pulse width using Input Capture Mode
PROGRAM:
/*
 * Bharath_AVR32.c
 *
 * Created: 04-04-2023 11:24:37 AM
 * Author : Admin
 */


#include <avr/io.h>
#include <avr/interrupt.h>
#define F_CPU 8000000UL
#include <util/delay.h>
#include <string.h>
#include <stdlib.h>


#define LCD_Data_Dir DDRD // Define LCD data port direction
#define LCD_Command_Dir DDRC // Define LCD command port direction register
#define LCD_Data_Port PORTD // Define LCD data port
#define LCD_Command_Port PORTC // Define LCD data port

#define EN PC2
#define RW PC3
#define RS PC4

void LCD_Command (char); // LCD command write function
void LCD_Char (char); // LCD data write function
void LCD_Init (void); // LCD Initialize function
void LCD_String (char*); // Send string to LCD function
void LCD_String_xy (char,char,char*); // Send row, position and string to LCD function

void LCD_Command (char cmd) // LCD command write function
{
	LCD_Data_Port = cmd; // Write command data to LCD data port
	LCD_Command_Port &= ~((1<<RS)|(1<<RW)); // Make RS LOW (command reg.), RW LOW (Write)
	LCD_Command_Port |= (1<<EN);
	_delay_us(1);
	LCD_Command_Port &= ~(1<<EN);
	_delay_ms(1);
}

void LCD_Char (char char_data) // LCD data write function
{
	LCD_Data_Port = char_data; // Write data to LCD data port
	LCD_Command_Port &= ~(1<<RW); // Make RW LOW (Write)
	LCD_Command_Port |= (1<<EN)|(1<<RS); // Make RS HIGH (data reg.) and High to Low transition on EN (Enable)
	_delay_us(1);
	LCD_Command_Port &= ~(1<<EN);
	_delay_ms(1);
}

void LCD_Init (void) // LCD Initialize function
{
	LCD_Command_Dir |= (1<<RS)|(1<<RW)|(1<<EN); // Make LCD command port direction as o/p
	LCD_Data_Dir = 0xFF; // Make LCD data port direction as o/p

	_delay_ms(20); // LCD power up time to get things ready, it should always >15ms
	LCD_Command (0x38); // Initialize 16X2 LCD in 8bit mode
	LCD_Command (0x0C); // Display ON, Cursor OFF command
	LCD_Command (0x06); // Auto Increment cursor
	LCD_Command (0x01); // Clear LCD command
	LCD_Command (0x80); // 8 is for first line and 0 is for 0th position
}

void LCD_String (char *str) // Send string to LCD function
{
	int i;
	for(i=0;str[i]!=0;i++) // Send each char of string till the NULL
	{
		LCD_Char (str[i]); // Call LCD data write
	}
}

void LCD_String_xy (char row, char pos, char *str) // Send string to LCD function
{
	if (row == 1)
	LCD_Command((pos & 0x0F)|0x80); // Command of first row and required position<16
	else if (row == 2)
	LCD_Command((pos & 0x0F)|0xC0); // Command of Second row and required position<16
	LCD_String(str); // Call LCD string function
}
#define Trigger_pin PA0 // Trigger pin

int TimerOverflow = 0;

ISR(TIMER1_OVF_vect)
{
	TimerOverflow++; // Increment Timer Overflow count
}

int main(void)
{
	char string[10];
	long count;
	double distance;

	DDRA = 0x01; // Make trigger pin as output
	PORTB = 0xFF; // Turn on Pull-up

	LCD_Init();
	LCD_String_xy(1, 0, "Ultrasonic");

	sei(); // Enable global interrupt
	TIMSK = (1 << TOIE1); // Enable Timer1 overflow interrupts
	TCCR1A = 0; // Set all bit to zero Normal operation

	while(1)
	{
		// Give 10us trigger pulse on trig. pin to HC-SR04
		PORTA |= (1 << Trigger_pin);
		_delay_us(10);
		PORTA &= (~(1 << Trigger_pin));

		TCNT1 = 0; // Clear Timer counter
		TCCR1B = 0x41; // Capture on rising edge, No prescaler
		TIFR = 1<<ICF1; // Clear ICP flag (Input Capture flag)
		TIFR = 1<<TOV1; // Clear Timer Overflow flag

		// Calculate width of Echo by Input Capture (ICP)

		while ((TIFR & (1 << ICF1)) == 0);// Wait for rising edge
		TCNT1 = 0; // Clear Timer counter
		TCCR1B = 0x01; // Capture on falling edge, No prescaler
		TIFR = 1<<ICF1; // Clear ICP flag (Input Capture flag)
		TIFR = 1<<TOV1; // Clear Timer Overflow flag
		TimerOverflow = 0; // Clear Timer overflow count

		while ((TIFR & (1 << ICF1)) == 0); // Wait for falling edge
		count = ICR1 + (65535 * TimerOverflow); // Take count
		// 8MHz Timer freq, sound speed =343 m/s
		distance = (double)count / 466.47;

		dtostrf(distance, 2, 2, string);// distance to string
		strcat(string, " cm "); // Concat unit i.e.cm
		LCD_String_xy(2, 0, "Dist = ");
		LCD_String_xy(2, 7, string); // Print distance
		_delay_ms(200);
	}
}
RESULT:
CASE_1:
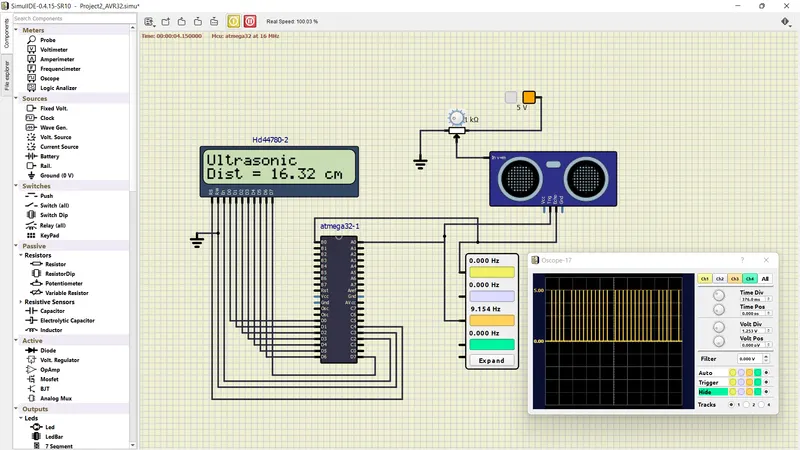
CASE_2:
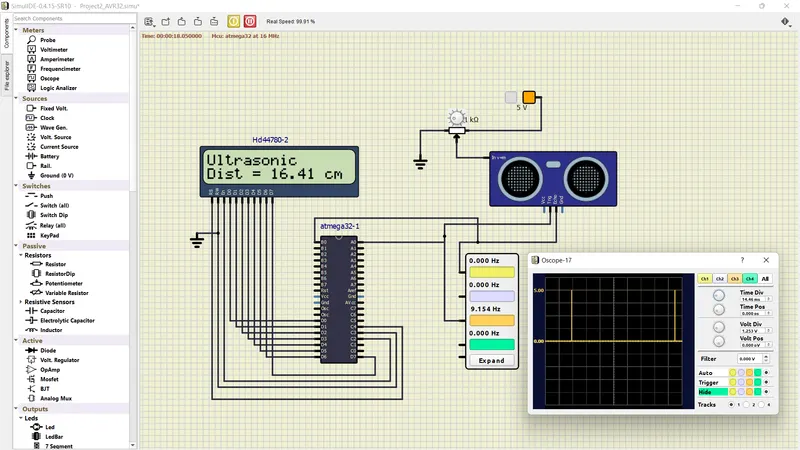
Deliverables of this project:
- The distance travelled by a wave to the object for which we want to measure the distance using Ultrasonic Distance Sensor (HC-SR04).
- Measuring Pulse width using Input Capture Mode of Timer 1
Expected Outcomes:
The students will get the Knowledge on Ultrasonic sensor (HC-SR04) to measure the distance travelled by wave to the object, the hardware connection of Atmega328p and HC-SR04 and how to use input capture mode of Timer1.