Project 2 - Implement the Code for controlling the retraction and extension of Airplane’s landing gear
Aim : Implement the Code for controlling the retraction and extension of Airplane’s landing gear.
Overview of the Project:
- In this project, controlling the retraction and extension of the Airplane’s landing gear can be implemented using Finite State Machine (FSM). FSM is the most efficient algorithm which is a mathematical model of computation.
Goals:
- Controlling the direction of Valve.
- Controlling the retraction and extension of the Airplane’s landing gear.
Key Highlights of the Project:
- A direction valve is controlled by the software to allow the hydraulic pressure to either raise or lower the landing gear.
Program Code :
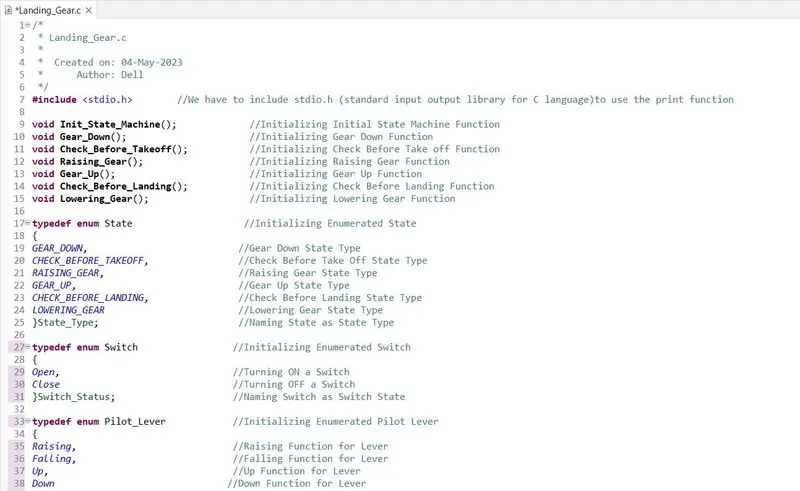
#include         //We have to include stdio.h (standard input output library for C language)to use the print function

void Init_State_Machine();             //Initializing Initial State Machine Function
void Gear_Down();                      //Initializing Gear Down Function
void Check_Before_Takeoff();           //Initializing Check Before Take off Function
void Raising_Gear();                   //Initializing Raising Gear Function
void Gear_Up();                        //Initializing Gear Up Function
void Check_Before_Landing();           //Initializing Check Before Landing Function
void Lowering_Gear();                  //Initializing Lowering Gear Function

typedef enum State                    //Initializing Enumerated State
{
GEAR_DOWN,                           //Gear Down State Type
CHECK_BEFORE_TAKEOFF,                //Check Before Take Off State Type
RAISING_GEAR,                        //Raising Gear State Type
GEAR_UP,                             //Gear Up State Type
CHECK_BEFORE_LANDING,                //Check Before Landing State Type
LOWERING_GEAR                        //Lowering Gear State Type
}State_Type;                         //Naming State as State Type

typedef enum Switch                 //Initializing Enumerated Switch
{
Open,                               //Turning ON a Switch
Close                               //Turning OFF a Switch
}Switch_Status;                     //Naming Switch as Switch State

typedef enum Pilot_Lever            //Initializing Enumerated Pilot Lever
{
Raising,                            //Raising Function for Lever
Falling,                            //Falling Function for Lever
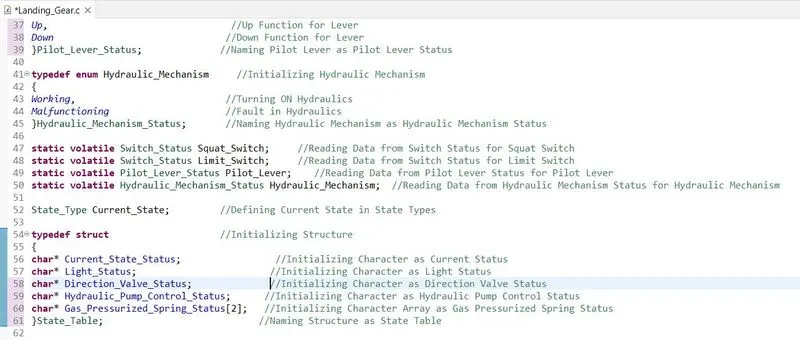
Up,                                 //Up Function for Lever
Down                               //Down Function for Lever
}Pilot_Lever_Status;              //Naming Pilot Lever as Pilot Lever Status

typedef enum Hydraulic_Mechanism     //Initializing Hydraulic Mechanism
{
Working,                           //Turning ON Hydraulics
Malfunctioning                     //Fault in Hydraulics
}Hydraulic_Mechanism_Status;       //Naming Hydraulic Mechanism as Hydraulic Mechanism Status

static volatile Switch_Status Squat_Switch;     //Reading Data from Switch Status for Squat Switch
static volatile Switch_Status Limit_Switch;     //Reading Data from Switch Status for Limit Switch
static volatile Pilot_Lever_Status Pilot_Lever;    //Reading Data from Pilot Lever Status for Pilot Lever
static volatile Hydraulic_Mechanism_Status Hydraulic_Mechanism;  //Reading Data from Hydraulic Mechanism Status for Hydraulic Mechanism

State_Type Current_State;         //Defining Current State in State Types

typedef struct                    //Initializing Structure
{
char* Current_State_Status;                 //Initializing Character as Current Status
char* Light_Status;                        //Initializing Character as Light Status
char* Direction_Valve_Status;              //Initializing Character as Direction Valve Status
char* Hydraulic_Pump_Control_Status;      //Initializing Character as Hydraulic Pump Control Status
char* Gas_Pressurized_Spring_Status[2];   //Initializing Character Array as Gas Pressurized Spring Status
}State_Table;                            //Naming Structure as State Table

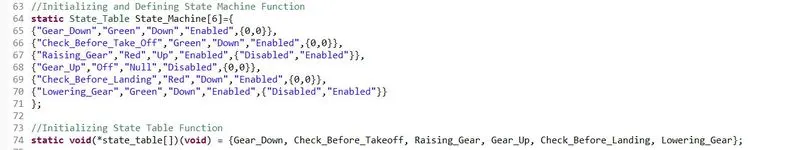
//Initializing and Defining State Machine Function
static State_Table State_Machine[6]={
{"Gear_Down","Green","Down","Enabled",{0,0}},
{"Check_Before_Take_Off","Green","Down","Enabled",{0,0}},
{"Raising_Gear","Red","Up","Enabled",{"Disabled","Enabled"}},
{"Gear_Up","Off","Null","Disabled",{0,0}},
{"Check_Before_Landing","Red","Down","Enabled",{0,0}},
{"Lowering_Gear","Green","Down","Enabled",{"Disabled","Enabled"}}
};

//Initializing State Table Function
static void(*state_table[])(void) = {Gear_Down, Check_Before_Takeoff, Raising_Gear, Gear_Up, Check_Before_Landing, Lowering_Gear};

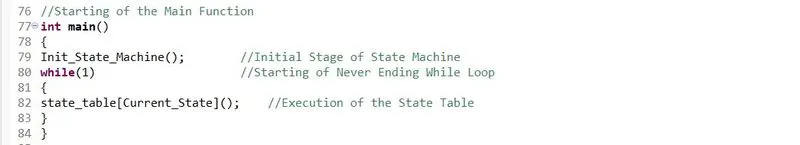
//Starting of the Main Function
int main()
{
Init_State_Machine();        //Initial Stage of State Machine
while(1)                     //Starting of Never Ending While Loop
{
state_table[Current_State]();    //Execution of the State Table
}
}

//Defining Initial State of State Machine
void Init_State_Machine()
{
Current_State = GEAR_DOWN;                       //Current State is Gear Down State
printf("\nState Machine is Initialized.");       //Started Execution of the State Machine
printf("\nAirplane is in Gear_Down State.");     //Airplane is in Gear Down State
printf("\nLight Status: %s.\n",State_Machine[Current_State].Light_Status);         //Light Shows the State of the Gear
}

//Defining Gear Down State
void Gear_Down()
{
Current_State = GEAR_DOWN;      //Gear Down is the Current State

printf("\nEnter the Pilot's Lever Position: ");       //Asking Pilot Lever Position
fflush(stdout);                 //Carries Output to Console
scanf("%d",&Pilot_Lever);      //Storing Pilot Lever Value

printf("Enter the Squat Switch Status: ");       //Asking Squat Switch Status
fflush(stdout);                                  //Carries Output to Console
scanf("%d",&Squat_Switch);                       //Storing Squat Switch Value

if(Pilot_Lever == Raising && Squat_Switch == Open)      //Compare Input from the Required Condition
{
Current_State = CHECK_BEFORE_TAKEOFF;       //If Input Matches Current State Will be Check Before Take Off State

printf("\nCurrent State: %s\n",State_Machine[Current_State].Current_State_Status);      //Printing Airplane Current Status
printf("Light Status:%s\n", State_Machine[Current_State].Light_Status);         //Printing State of Gear from Light Indication
printf("Direction Valve Status:%s\n", State_Machine[Current_State].Direction_Valve_Status); //Printing Direction Valve Status
}
else             //If Input Doesn't Matches Return to Gear Down State
{
Gear_Down();     //Calling Gear Down Function
}
}

//Defining Check Before Take Off State
void Check_Before_Takeoff()
{
Current_State = CHECK_BEFORE_TAKEOFF;     //Check Before Take Off is the Current State

printf("\nEnter the Pilot's Lever Position: ");   //Asking Pilot Lever Position
fflush(stdout);                                   //Carries Output to Console
scanf("%d",&Pilot_Lever);                         //Storing Pilot Lever Value
printf("Enter the Squat Switch Status: ");        //Asking Squat Switch Status
fflush(stdout);                                   //Carries Output to Console
scanf("%d",&Squat_Switch);                         //Storing Squat Switch Value

printf("Enter the Hydraulic Mechanism Status: ");  //Asking Hydraulic Mechanism Status
fflush(stdout); //Carries Output to Console
scanf("%d",&Hydraulic_Mechanism);                   //Storing Hydraulic Mechanism Value

printf("\nWait for 4 seconds\n");                     //Printing Wait for 4 Seconds

if(Pilot_Lever == Up && Squat_Switch == Open && Hydraulic_Mechanism == Working)     //Compare Input from the Required Condition
{
Current_State = RAISING_GEAR;        //If Input Matches, Current State is Raising Gear

printf("\nCurrent State :%s\n",State_Machine[Current_State].Current_State_Status);  //Printing Airplane Current Status
printf("Light Status: %s\n", State_Machine[Current_State].Light_Status);           //Printing State of Gear from Light Indication
printf("Direction Valve Status:%s\n", State_Machine[Current_State].Direction_Valve_Status);    //Printing Direction Valve Status
printf("Hydraulic Control for Landing Gear Status:%s\n",State_Machine[Current_State].Hydraulic_Pump_Control_Status);   //Printing Hydraulic Status
}
else if(Pilot_Lever == Up && Squat_Switch == Open && Hydraulic_Mechanism == Malfunctioning)    //Compare Input from the Required Condition
{
Current_State = RAISING_GEAR;     //If Input Matches, Current State is Raising Gear

printf("\nCurrent State :%s\n",State_Machine[Current_State].Current_State_Status);    //Printing Airplane Current Status
printf("Light Status: %s\n", State_Machine[Current_State].Light_Status);         //Printing State of Gear from Light Indication
printf("Direction Valve Status:%s\n", State_Machine[Current_State].Direction_Valve_Status);   //Printing Direction Valve Status
printf("Gas Pressurized Spring System Status:%s\n",State_Machine[Current_State].Gas_Pressurized_Spring_Status[Hydraulic_Mechanism]); //Printing Gas Spring Status
}
else                  //If Input Doesn't Matches Return to Check Before Take Off State
{
Check_Before_Takeoff(); //Calling Check Before Take Off Function
}
}

//Defining Raising Gear State
void Raising_Gear()
{
Current_State = RAISING_GEAR;                      //Raising Gear is the Current State

printf("\nEnter the Pilots Lever Status: ");      //Asking Pilot Lever Position
fflush(stdout);                                  //Carries Output to Console
scanf("%d",&Pilot_Lever);                        //Storing Pilot Lever Value

printf("Enter the Limit Switch Status: ");       //Asking Limit Switch Status
fflush(stdout);                                  //Carries Output to Console
scanf("%d",&Limit_Switch);                       //Storing Limit Switch Value

if(Pilot_Lever == Falling && Limit_Switch == Open)   //Compare Input from the Required Condition
{
Current_State = CHECK_BEFORE_LANDING;                //If Input Matches, Current State is Check Before Landing

printf("\nCurrent State: %s\n",State_Machine[Current_State].Current_State_Status);    //Printing Airplane Current Status
printf("Light Status:%s\n",State_Machine[Current_State].Light_Status);                //Printing State of Gear from Light Indication
printf("Direction Valve Status:%s\n", State_Machine[Current_State].Direction_Valve_Status);    //Printing Direction Valve Status
printf("Hydraulic Control for Landing Gear Status:%s\n",State_Machine[Current_State].Hydraulic_Pump_Control_Status); //Printing Hydraulic Status
}
else if(Limit_Switch == Close && Pilot_Lever == Up)             //Compare Input from the Required Condition
{
Current_State = GEAR_UP;                                        //If Input Matches, Current State is Gear Up State

printf("\nCurrent State: %s\n",State_Machine[Current_State].Current_State_Status);    //Printing Airplane Current Status
printf("Light Status: %s\n", State_Machine[Current_State].Light_Status);           //Printing State of Gear from Light Indication
printf("Direction Valve Status:%s\n", State_Machine[Current_State].Direction_Valve_Status);   //Printing Direction Valve Status
printf("Hydraulic Control for Landing Gear Status:%s\n", State_Machine[Current_State].Hydraulic_Pump_Control_Status); //Printing Hydraulic Status
}
else                        //If Input Doesn't Matches Return to Raising Gear State
{
Raising_Gear();                      //Calling Raising Gear Function
}
}

//Defining Gear Up State
void Gear_Up()
{
Current_State = GEAR_UP;              //Gear Up is the Current State

printf("\nEnter the Pilot's Lever Position: ");      //Asking Pilot Lever Position
fflush(stdout);                                     //Carries Output to Console
scanf("%d",&Pilot_Lever);                           //Storing Pilot Lever Value

if(Pilot_Lever == Falling)                    //Compare Input from the Required Condition
{
Current_State = CHECK_BEFORE_LANDING;         //If Input Matches, Current State is Check Before Landing State

printf("\nCurrent State: %s\n",State_Machine[Current_State].Current_State_Status);      //Printing Airplane Current Status
printf("Light Status:%s\n", State_Machine[Current_State].Light_Status);            //Printing State of Gear from Light Indication
printf("Hydraulic Control for Landing Gear Status:%s\n",State_Machine[Current_State].Hydraulic_Pump_Control_Status); //Printing Hydraulic Status
}
else                                  //If Input Doesn't Matches Return to Gear Up State
{
Gear_Up();                           //Calling Gear Up Function
}
}

//Defining Check Before Landing State
void Check_Before_Landing()
{
Current_State = CHECK_BEFORE_LANDING;                 //Check Before Landing is the Current State

printf("\nEnter the Pilot's Lever Position: ");     //Asking Pilot Lever Position
fflush(stdout);                                    //Carries Output to Console
scanf("%d",&Pilot_Lever);                          //Storing Pilot Lever Value

printf("Enter the Status of Hydraulic Mechanism: ");            //Asking Hydraulic Mechanism Status
fflush(stdout); //Carries Output to Console
scanf("%d",&Hydraulic_Mechanism);                              //Storing Hydraulic Mechanism Value

if(Pilot_Lever == Down && Hydraulic_Mechanism == Working)    //Compare Input from the Required Condition
{
Current_State = LOWERING_GEAR;                               //If Input Matches, Current State is Lowering Gear State

printf("\nCurrent State:%s\n", State_Machine[Current_State].Current_State_Status);          //Printing Airplane Current Status
printf("Light Status:%s\n", State_Machine[Current_State].Light_Status);                     //Printing State of Gear from Light Indication
printf("Direction Valve Status:%s\n", State_Machine[Current_State].Direction_Valve_Status); //Printing Direction Valve Status
printf("Hydraulic Control for Landing Gear Status:%s\n",State_Machine[Current_State].Hydraulic_Pump_Control_Status);   //Printing Hydraulic Status
}
else if(Pilot_Lever == Down && Hydraulic_Mechanism == Malfunctioning)            //Compare Input from the Required Condition
{
Current_State = LOWERING_GEAR;                //If Input Matches, Current State is Lowering Gear State

printf("\nCurrent State:%s\n",State_Machine[Current_State].Current_State_Status);      //Printing Airplane Current Status
printf("Light Status:%s\n", State_Machine[Current_State].Light_Status);                //Printing State of Gear from Light Indication
printf("Direction Valve Status:%s\n", State_Machine[Current_State].Direction_Valve_Status); //Printing Direction Valve Status
printf("Gas Pressurized Spring System Status:%s\n",State_Machine[Current_State].Gas_Pressurized_Spring_Status[Hydraulic_Mechanism]); //Printing Gas Spring Status
}
else if(Pilot_Lever == (Up || Raising || Falling))           //Compare Input from the Required Condition
{
Check_Before_Landing();                                     //Calling Gear Down Function
}
}

//Defining Lowering Gear State
void Lowering_Gear()
{
Current_State = LOWERING_GEAR;      //Lowering Gear is the Current State

printf("\nEnter the Limit Switch Status: "); //Asking Limit Switch Status
fflush(stdout);                            //Carries Output to Console
scanf("%d",&Limit_Switch);                  //Storing Limit Switch Value

printf("Enter the Pilots Lever Status: ");      //Asking Pilot Lever Position
fflush(stdout); //Carries Output to Console
scanf("%d",&Pilot_Lever); //Storing Pilot Lever Value

if(Limit_Switch == Close && Pilot_Lever == Raising ) //Compare Input from the Required Condition
{
Current_State = CHECK_BEFORE_TAKEOFF; //If Input Matches, Current State is Check Before Take Off State

printf("\nCurrent State:%s\n",State_Machine[Current_State].Current_State_Status); //Printing Airplane Current Status
printf("Light Status:%s\n",State_Machine[Current_State].Light_Status); //Printing State of Gear from Light Indication
printf("Direction Valve Status:%s\n", State_Machine[Current_State].Direction_Valve_Status); //Printing Direction Valve Status
}
else if(Limit_Switch == Open && Pilot_Lever == Down) //Compare Input from the Required Condition
{
Current_State = GEAR_DOWN; //If Input Matches, Current State is Gear Down State

printf("\nCurrent State:%s\n",State_Machine[Current_State].Current_State_Status); //Printing Airplane Current Status
printf("Light Status:%s\n",State_Machine[Current_State].Light_Status); //Printing State of Gear from Light Indication
printf("Direction Valve Status:%s\n", State_Machine[Current_State].Direction_Valve_Status); //Printing Direction Valve Status
}
else           //If Input Doesn't Matches Return to Lowering Gear State
{
Lowering_Gear();              //Calling Lowering Gear Function
}
}
Initializing States and State Table
Main Function :
Initial State :
Gear Down State :
Check Before Take Off State :
Raising Gear State :
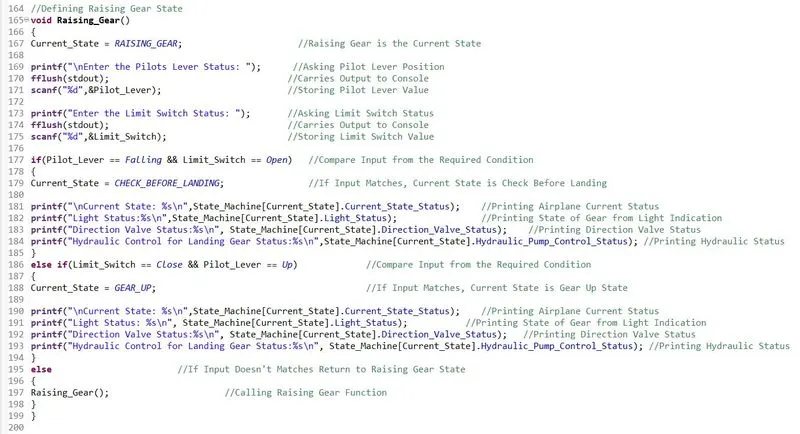
Gear Up State :
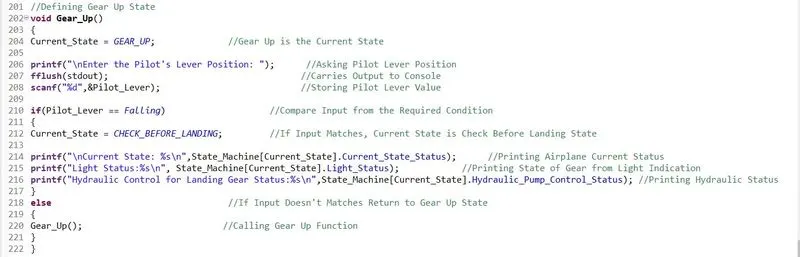
Check Before Landing State :
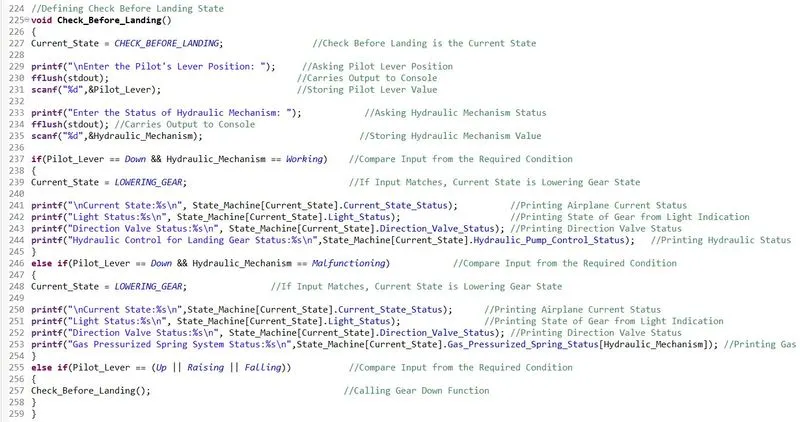
Lowering Gear State :
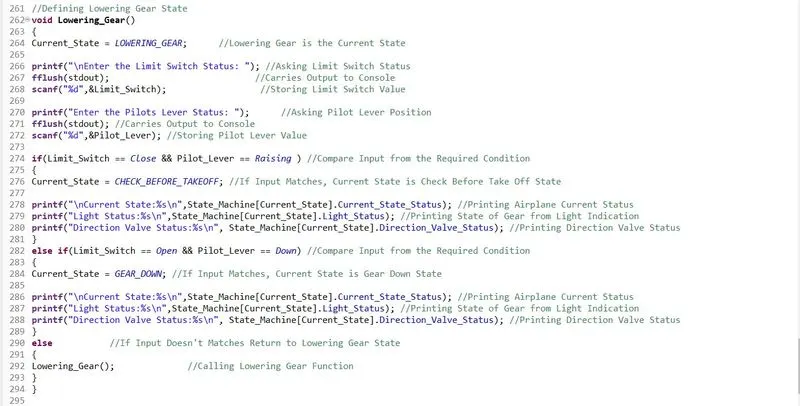
-------------------------------------------------------------------------------------------------------------------
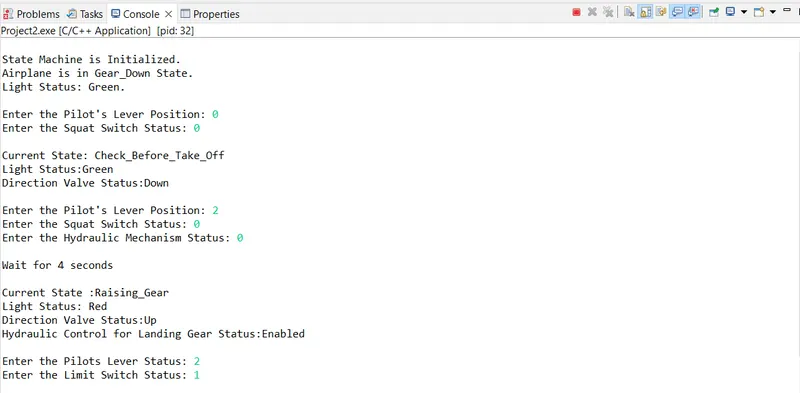
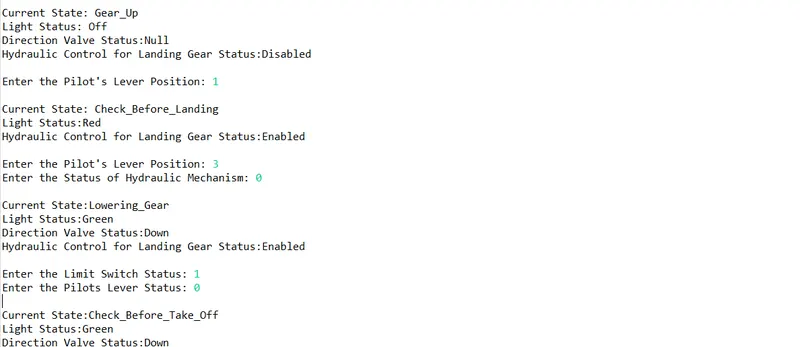
Console Output :
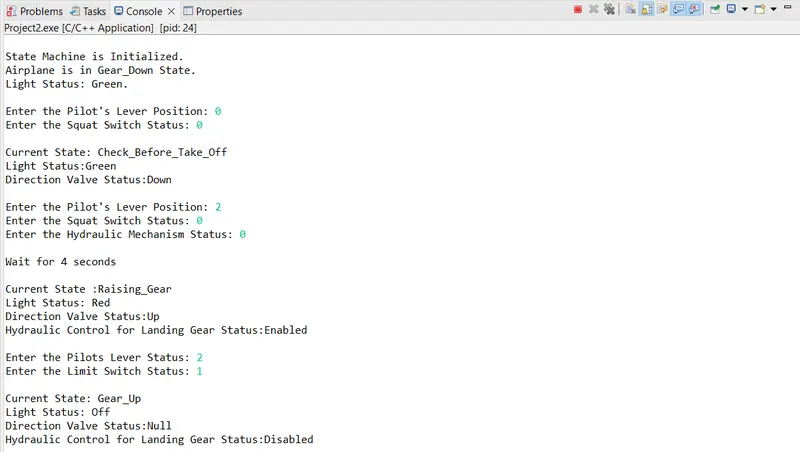
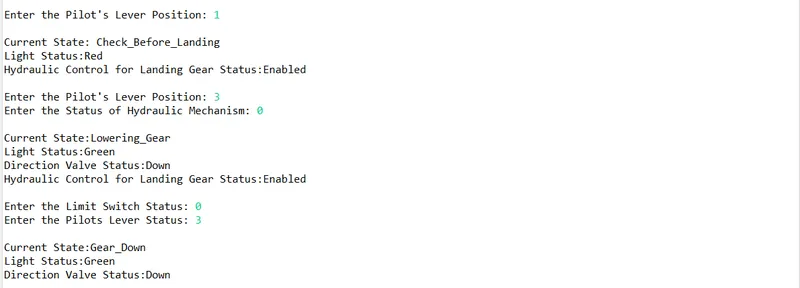
Full Code Execution From
Gear Down ---> Check Before Take Off ---> Raising Gear ---> Gear Up ---> Check Before Landing ---> Lowering Gear ---> Gear Down.
-----------------------------------------------------------------------------------------------------------------
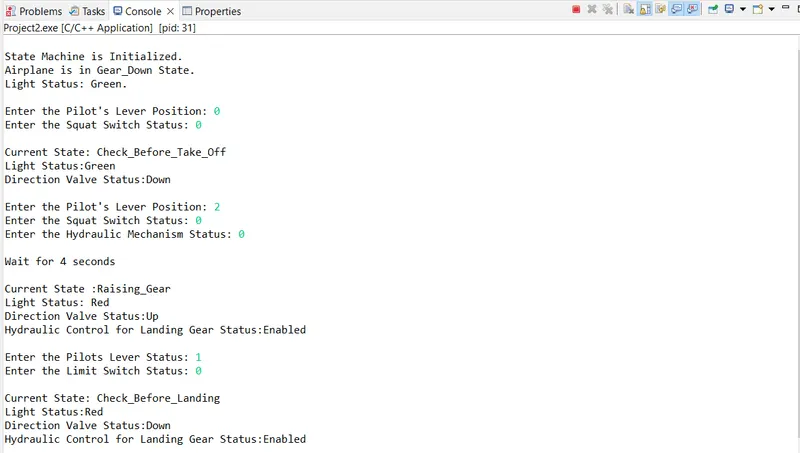
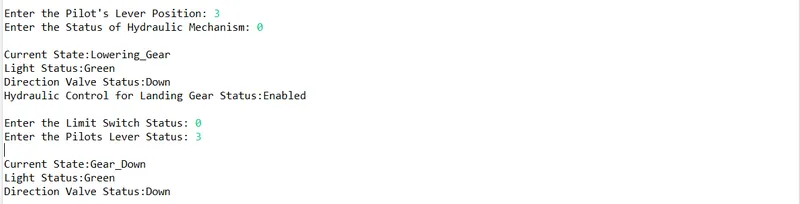
No Gear Up State :
Gear Down ---> Check Before Take Off ---> Raising Gear ---> Check Before Landing ---> Lowering Gear ---> Gear Down.
--------------------------------------------------------------------------------------------------------------------------
No Gear Down State :
Gear Down ---> Check Before Take Off ---> Raising Gear ---> Gear Up ---> Check Before Landing ---> Lowering Gear ---> Check Before Take Off.
---------------------------------------------------------------------------------------------------------------------------