Project 2 - Implement the Code for controlling the retraction and extension of Airplane’s landing gear
-Aim: To Implement the Code for controlling the retraction and extension of Airplane’s landing gear
-Overview of the Project:
- Here the project for controlling the retraction and extension of the Airplane’s landing gear can be implemented using Finite State Machine (FSM).FSM is the most efficient algorithm which is mathematical model of computation.
- Goals:
- Controlling the direction of Valve.
- Controlling the retraction and extension of the Airplane’s landing gear.
-Key Highlights of the Project:
- A direction valve is controlled by the software to allow the hydraulic pressure to either raise or lower the landing gear.
-----------------------------------------------------------------------------------------------
-Code:
#include  //Selection of standard input output library file

//Initializing Required function
void Init_State_Machine();   //Initializing Initial State Machine Function
void Gear_Down();            //Initializing Gear Down Function
void Check_Before_Takeoff(); //Initializing Check Before Take off Function
void Raising_Gear();         //Initializing Raising Gear Function
void Gear_Up();              //Initializing Gear Up Function
void Check_Before_Landing(); //Initializing Check Before Landing Function
void Lowering_Gear();        //Initializing Lowering Gear Function

//Initializing Enumerated State
typedef enum State
{
GEAR_DOWN,            //Gear Down State Type
CHECK_BEFORE_TAKEOFF, //Check Before Take Off State Type
RAISING_GEAR,         //Raising Gear State Type
GEAR_UP,              //Gear Up State Type
CHECK_BEFORE_LANDING, //Check Before Landing State Type
LOWERING_GEAR         //Lowering Gear State Type
}State_Type;          //Naming State as State Type

//Initializing Enumerated Switch
typedef enum Switch
{
Open,            //Turning ON a Switch
Close            //Turning OFF a Switch
}Switch_Status; //Naming Switch as Switch State

//Initializing Enumerated Pilot Lever
typedef enum Pilot_Lever
{
Raising, //Raising Function for Lever
Falling, //Falling Function for Lever
Up,      //Up Function for Lever
Down     //Down Function for Lever
}Pilot_Lever_Status; //Naming Pilot Lever as Pilot Lever Status

//Initializing Hydraulic Mechanism
typedef enum Hydraulic_Mechanism
{
Working,       //Turning ON Hydraulics
Malfunctioning //Fault in Hydraulics
}Hydraulic_Mechanism_Status; //Naming Hydraulic Mechanism as Hydraulic Mechanism Status

static volatile Switch_Status Squat_Switch; //Reading Data from Switch Status for Squat Switch
static volatile Switch_Status Limit_Switch; //Reading Data from Switch Status for Limit Switch
static volatile Pilot_Lever_Status Pilot_Lever; //Reading Data from Pilot Lever Status for Pilot Lever
static volatile Hydraulic_Mechanism_Status Hydraulic_Mechanism; //Reading Data from Hydraulic Mechanism Status for Hydraulic Mechanism

State_Type Current_State; //Defining Current State in State Types

//Initializing Structure
typedef struct
{
char* Current_State_Status; //Initializing Character as Current Status
char* Light_Status;        //Initializing Character as Light Status
char* Direction_Valve_Status; //Initializing Character as Direction Valve Status
char* Hydraulic_Pump_Control_Status; //Initializing Character as Hydraulic Pump Control Status
char* Gas_Pressurized_Spring_Status[2]; //Initializing Character Array as Gas Pressurized Spring Status
}State_Table; //Naming Structure as State Table

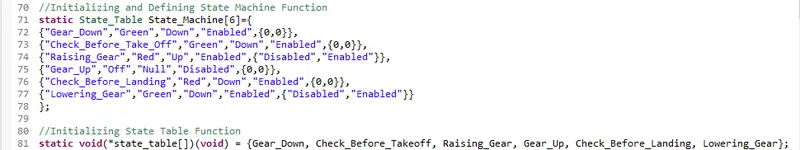
//Initializing and Defining State Machine Function
static State_Table State_Machine[6]={
{"Gear_Down","Green","Down","Enabled",{0,0}},
{"Check_Before_Take_Off","Green","Down","Enabled",{0,0}},
{"Raising_Gear","Red","Up","Enabled",{"Disabled","Enabled"}},
{"Gear_Up","Off","Null","Disabled",{0,0}},
{"Check_Before_Landing","Red","Down","Enabled",{0,0}},
{"Lowering_Gear","Green","Down","Enabled",{"Disabled","Enabled"}}
};

//Initializing State Table Function
static void(*state_table[])(void) = {Gear_Down, Check_Before_Takeoff, Raising_Gear, Gear_Up, Check_Before_Landing, Lowering_Gear};

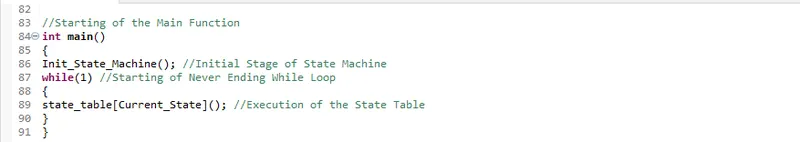
//Starting of the Main Function
int main()
{
Init_State_Machine(); //Initial Stage of State Machine
while(1) //Starting of Never Ending While Loop
{
state_table[Current_State](); //Execution of the State Table
}
}

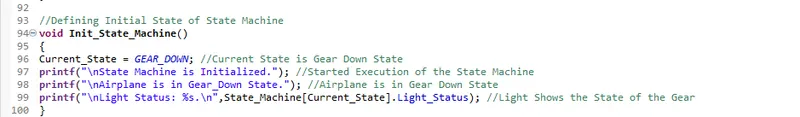
//Defining Initial State of State Machine
void Init_State_Machine()
{
Current_State = GEAR_DOWN; //Current State is Gear Down State
printf("\nState Machine is Initialized."); //Started Execution of the State Machine
printf("\nAirplane is in Gear_Down State."); //Airplane is in Gear Down State
printf("\nLight Status: %s.\n",State_Machine[Current_State].Light_Status); //Light Shows the State of the Gear
}

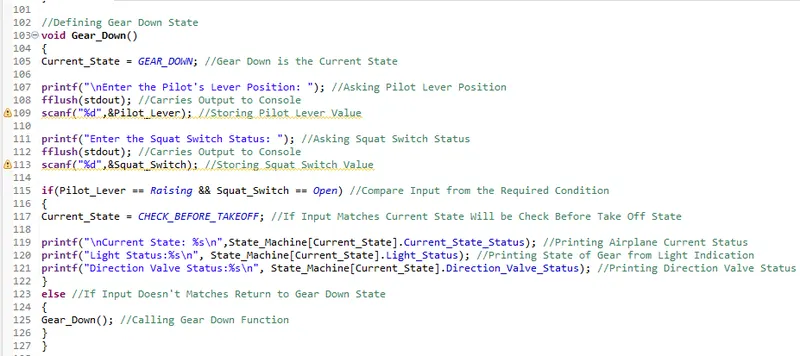
//Defining Gear Down State
void Gear_Down()
{
Current_State = GEAR_DOWN; //Gear Down is the Current State

printf("\nEnter the Pilot's Lever Position: "); //Asking Pilot Lever Position
fflush(stdout); //Carries Output to Console
scanf("%d",&Pilot_Lever); //Storing Pilot Lever Value

printf("Enter the Squat Switch Status: "); //Asking Squat Switch Status
fflush(stdout); //Carries Output to Console
scanf("%d",&Squat_Switch); //Storing Squat Switch Value

if(Pilot_Lever == Raising && Squat_Switch == Open) //Compare Input from the Required Condition
{
Current_State = CHECK_BEFORE_TAKEOFF; //If Input Matches Current State Will be Check Before Take Off State

printf("\nCurrent State: %s\n",State_Machine[Current_State].Current_State_Status); //Printing Airplane Current Status
printf("Light Status:%s\n", State_Machine[Current_State].Light_Status); //Printing State of Gear from Light Indication
printf("Direction Valve Status:%s\n", State_Machine[Current_State].Direction_Valve_Status); //Printing Direction Valve Status
}
else //If Input Doesn't Matches Return to Gear Down State
{
Gear_Down(); //Calling Gear Down Function
}
}

//Defining Check Before Take Off State
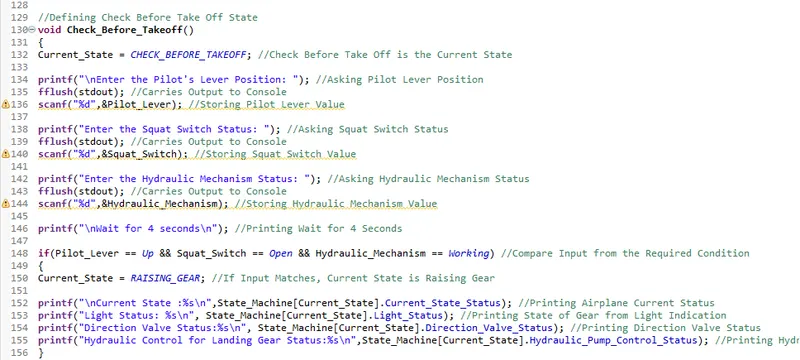
void Check_Before_Takeoff()
{
Current_State = CHECK_BEFORE_TAKEOFF; //Check Before Take Off is the Current State

printf("\nEnter the Pilot's Lever Position: "); //Asking Pilot Lever Position
fflush(stdout); //Carries Output to Console
scanf("%d",&Pilot_Lever); //Storing Pilot Lever Value

printf("Enter the Squat Switch Status: "); //Asking Squat Switch Status
fflush(stdout); //Carries Output to Console
scanf("%d",&Squat_Switch); //Storing Squat Switch Value

printf("Enter the Hydraulic Mechanism Status: "); //Asking Hydraulic Mechanism Status
fflush(stdout); //Carries Output to Console
scanf("%d",&Hydraulic_Mechanism); //Storing Hydraulic Mechanism Value

printf("\nWait for 4 seconds\n"); //Printing Wait for 4 Seconds

if(Pilot_Lever == Up && Squat_Switch == Open && Hydraulic_Mechanism == Working) //Compare Input from the Required Condition
{
Current_State = RAISING_GEAR; //If Input Matches, Current State is Raising Gear

printf("\nCurrent State :%s\n",State_Machine[Current_State].Current_State_Status); //Printing Airplane Current Status
printf("Light Status: %s\n", State_Machine[Current_State].Light_Status); //Printing State of Gear from Light Indication
printf("Direction Valve Status:%s\n", State_Machine[Current_State].Direction_Valve_Status); //Printing Direction Valve Status
printf("Hydraulic Control for Landing Gear Status:%s\n",State_Machine[Current_State].Hydraulic_Pump_Control_Status); //Printing Hydraulic Status
}
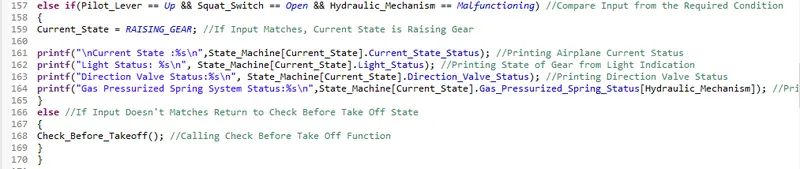
else if(Pilot_Lever == Up && Squat_Switch == Open && Hydraulic_Mechanism == Malfunctioning) //Compare Input from the Required Condition
{
Current_State = RAISING_GEAR; //If Input Matches, Current State is Raising Gear

printf("\nCurrent State :%s\n",State_Machine[Current_State].Current_State_Status); //Printing Airplane Current Status
printf("Light Status: %s\n", State_Machine[Current_State].Light_Status); //Printing State of Gear from Light Indication
printf("Direction Valve Status:%s\n", State_Machine[Current_State].Direction_Valve_Status); //Printing Direction Valve Status
printf("Gas Pressurized Spring System Status:%s\n",State_Machine[Current_State].Gas_Pressurized_Spring_Status[Hydraulic_Mechanism]); //Printing Gas Spring Status
}
else //If Input Doesn't Matches Return to Check Before Take Off State
{
Check_Before_Takeoff(); //Calling Check Before Take Off Function
}
}

//Defining Raising Gear State
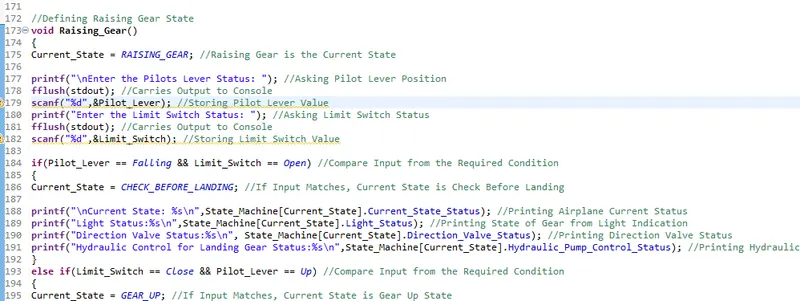
void Raising_Gear()
{
Current_State = RAISING_GEAR; //Raising Gear is the Current State

printf("\nEnter the Pilots Lever Status: "); //Asking Pilot Lever Position
fflush(stdout); //Carries Output to Console

scanf("%d",&Pilot_Lever); //Storing Pilot Lever Value
printf("Enter the Limit Switch Status: "); //Asking Limit Switch Status
fflush(stdout); //Carries Output to Console
scanf("%d",&Limit_Switch); //Storing Limit Switch Value

if(Pilot_Lever == Falling && Limit_Switch == Open) //Compare Input from the Required Condition
{
Current_State = CHECK_BEFORE_LANDING; //If Input Matches, Current State is Check Before Landing

printf("\nCurrent State: %s\n",State_Machine[Current_State].Current_State_Status); //Printing Airplane Current Status
printf("Light Status:%s\n",State_Machine[Current_State].Light_Status); //Printing State of Gear from Light Indication
printf("Direction Valve Status:%s\n", State_Machine[Current_State].Direction_Valve_Status); //Printing Direction Valve Status
printf("Hydraulic Control for Landing Gear Status:%s\n",State_Machine[Current_State].Hydraulic_Pump_Control_Status); //Printing Hydraulic Status
}
else if(Limit_Switch == Close && Pilot_Lever == Up) //Compare Input from the Required Condition
{
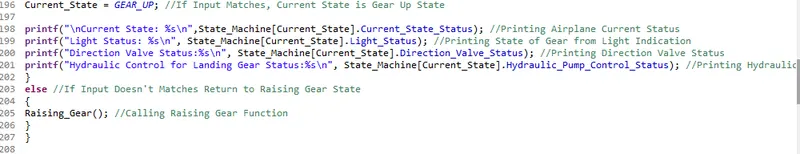
Current_State = GEAR_UP; //If Input Matches, Current State is Gear Up State

printf("\nCurrent State: %s\n",State_Machine[Current_State].Current_State_Status); //Printing Airplane Current Status
printf("Light Status: %s\n", State_Machine[Current_State].Light_Status); //Printing State of Gear from Light Indication
printf("Direction Valve Status:%s\n", State_Machine[Current_State].Direction_Valve_Status); //Printing Direction Valve Status
printf("Hydraulic Control for Landing Gear Status:%s\n", State_Machine[Current_State].Hydraulic_Pump_Control_Status); //Printing Hydraulic Status
}
else //If Input Doesn't Matches Return to Raising Gear State
{
Raising_Gear(); //Calling Raising Gear Function
}
}

//Defining Gear Up State
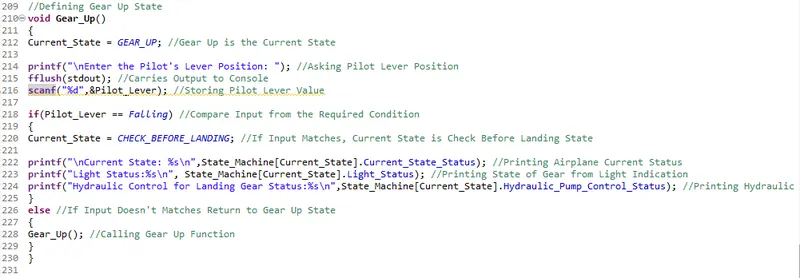
void Gear_Up()
{
Current_State = GEAR_UP; //Gear Up is the Current State

printf("\nEnter the Pilot's Lever Position: "); //Asking Pilot Lever Position
fflush(stdout); //Carries Output to Console
scanf("%d",&Pilot_Lever); //Storing Pilot Lever Value

if(Pilot_Lever == Falling) //Compare Input from the Required Condition
{
Current_State = CHECK_BEFORE_LANDING; //If Input Matches, Current State is Check Before Landing State

printf("\nCurrent State: %s\n",State_Machine[Current_State].Current_State_Status); //Printing Airplane Current Status
printf("Light Status:%s\n", State_Machine[Current_State].Light_Status); //Printing State of Gear from Light Indication
printf("Hydraulic Control for Landing Gear Status:%s\n",State_Machine[Current_State].Hydraulic_Pump_Control_Status); //Printing Hydraulic Status
}
else //If Input Doesn't Matches Return to Gear Up State
{
Gear_Up(); //Calling Gear Up Function
}
}

//Defining Check Before Landing State
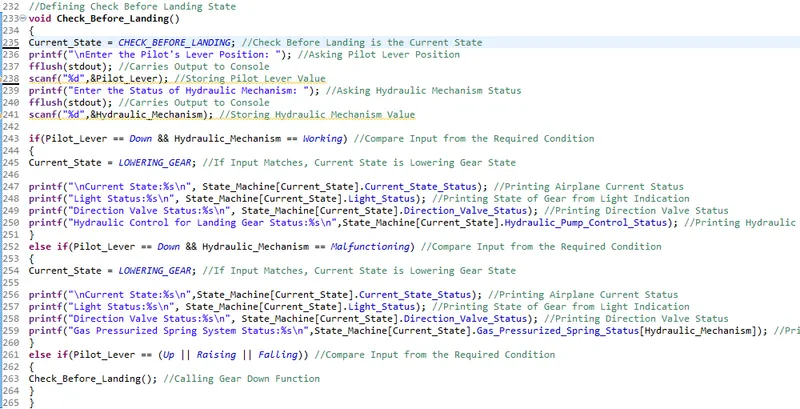
void Check_Before_Landing()
{
Current_State = CHECK_BEFORE_LANDING; //Check Before Landing is the Current State
printf("\nEnter the Pilot's Lever Position: "); //Asking Pilot Lever Position
fflush(stdout); //Carries Output to Console
scanf("%d",&Pilot_Lever); //Storing Pilot Lever Value
printf("Enter the Status of Hydraulic Mechanism: "); //Asking Hydraulic Mechanism Status
fflush(stdout); //Carries Output to Console
scanf("%d",&Hydraulic_Mechanism); //Storing Hydraulic Mechanism Value

if(Pilot_Lever == Down && Hydraulic_Mechanism == Working) //Compare Input from the Required Condition
{
Current_State = LOWERING_GEAR; //If Input Matches, Current State is Lowering Gear State

printf("\nCurrent State:%s\n", State_Machine[Current_State].Current_State_Status); //Printing Airplane Current Status
printf("Light Status:%s\n", State_Machine[Current_State].Light_Status); //Printing State of Gear from Light Indication
printf("Direction Valve Status:%s\n", State_Machine[Current_State].Direction_Valve_Status); //Printing Direction Valve Status
printf("Hydraulic Control for Landing Gear Status:%s\n",State_Machine[Current_State].Hydraulic_Pump_Control_Status); //Printing Hydraulic Status
}
else if(Pilot_Lever == Down && Hydraulic_Mechanism == Malfunctioning) //Compare Input from the Required Condition
{
Current_State = LOWERING_GEAR; //If Input Matches, Current State is Lowering Gear State

printf("\nCurrent State:%s\n",State_Machine[Current_State].Current_State_Status); //Printing Airplane Current Status
printf("Light Status:%s\n", State_Machine[Current_State].Light_Status); //Printing State of Gear from Light Indication
printf("Direction Valve Status:%s\n", State_Machine[Current_State].Direction_Valve_Status); //Printing Direction Valve Status
printf("Gas Pressurized Spring System Status:%s\n",State_Machine[Current_State].Gas_Pressurized_Spring_Status[Hydraulic_Mechanism]); //Printing Gas Spring Status
}
else if(Pilot_Lever == (Up || Raising || Falling)) //Compare Input from the Required Condition
{
Check_Before_Landing(); //Calling Gear Down Function
}
}

//Defining Lowering Gear State
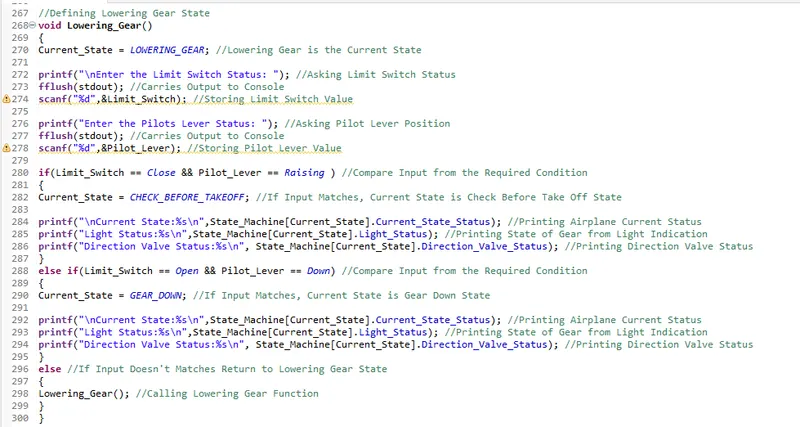
void Lowering_Gear()
{
Current_State = LOWERING_GEAR; //Lowering Gear is the Current State

printf("\nEnter the Limit Switch Status: "); //Asking Limit Switch Status
fflush(stdout); //Carries Output to Console
scanf("%d",&Limit_Switch); //Storing Limit Switch Value

printf("Enter the Pilots Lever Status: "); //Asking Pilot Lever Position
fflush(stdout); //Carries Output to Console
scanf("%d",&Pilot_Lever); //Storing Pilot Lever Value

if(Limit_Switch == Close && Pilot_Lever == Raising ) //Compare Input from the Required Condition
{
Current_State = CHECK_BEFORE_TAKEOFF; //If Input Matches, Current State is Check Before Take Off State

printf("\nCurrent State:%s\n",State_Machine[Current_State].Current_State_Status); //Printing Airplane Current Status
printf("Light Status:%s\n",State_Machine[Current_State].Light_Status); //Printing State of Gear from Light Indication
printf("Direction Valve Status:%s\n", State_Machine[Current_State].Direction_Valve_Status); //Printing Direction Valve Status
}
else if(Limit_Switch == Open && Pilot_Lever == Down) //Compare Input from the Required Condition
{
Current_State = GEAR_DOWN; //If Input Matches, Current State is Gear Down State

printf("\nCurrent State:%s\n",State_Machine[Current_State].Current_State_Status); //Printing Airplane Current Status
printf("Light Status:%s\n",State_Machine[Current_State].Light_Status); //Printing State of Gear from Light Indication
printf("Direction Valve Status:%s\n", State_Machine[Current_State].Direction_Valve_Status); //Printing Direction Valve Status
}
else //If Input Doesn't Matches Return to Lowering Gear State
{
Lowering_Gear(); //Calling Lowering Gear Function
}
}
------------------------------------------------------------------------------------------
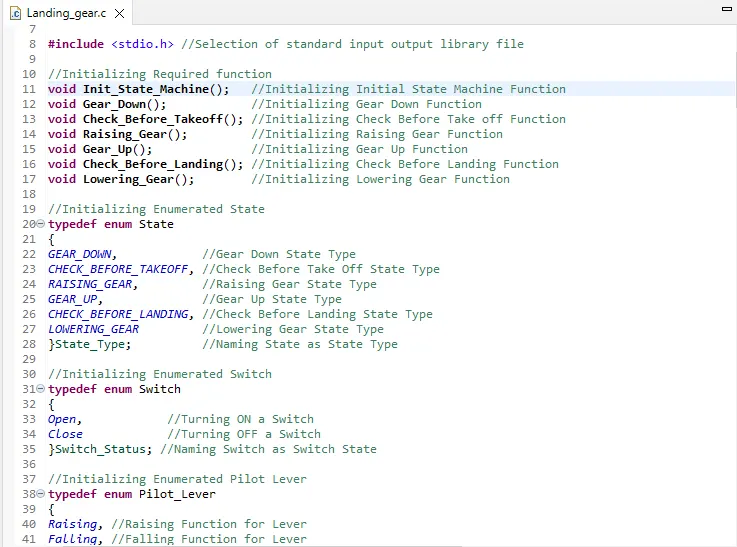
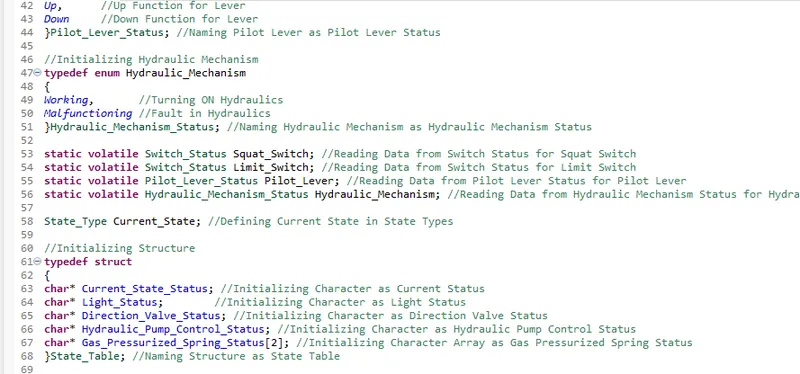
-Initializing States & State Table :
-Main Function:
-Initial State:
-Gear down State:
-Check before take Off State:
-Raising gear State:
-Gear up State:
-Check before landing State:
-Lowering gear State:
-------------------------------------------------------------------------------------------------
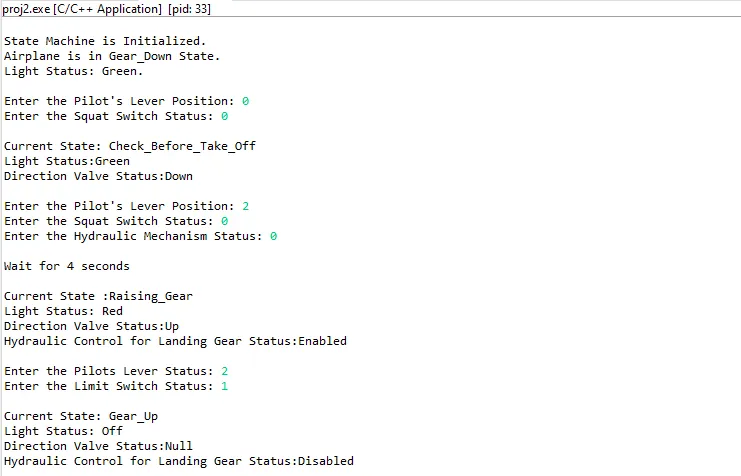
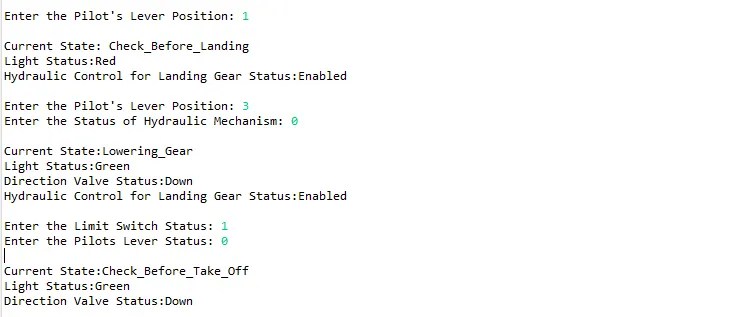
-Output:
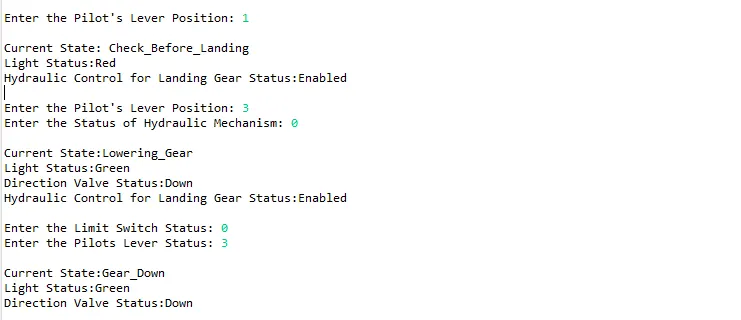
Full Code Execution From
>> Gear Down >> Check Before Take Off >> Raising Gear >> Gear Up >> Check Before Landing >> Lowering Gear >> Gear Down.
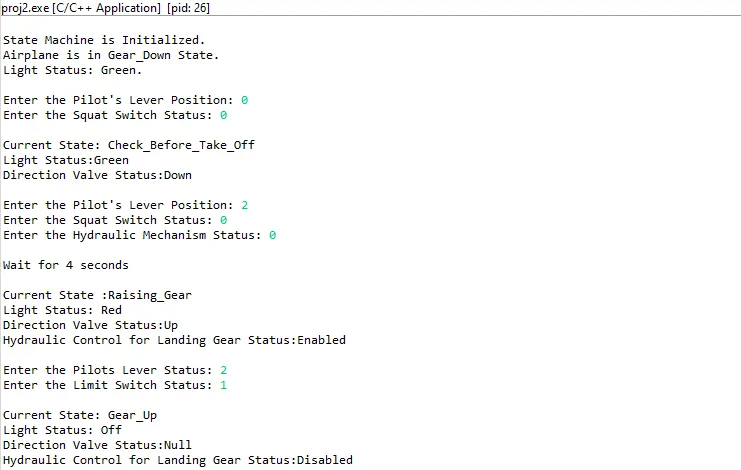
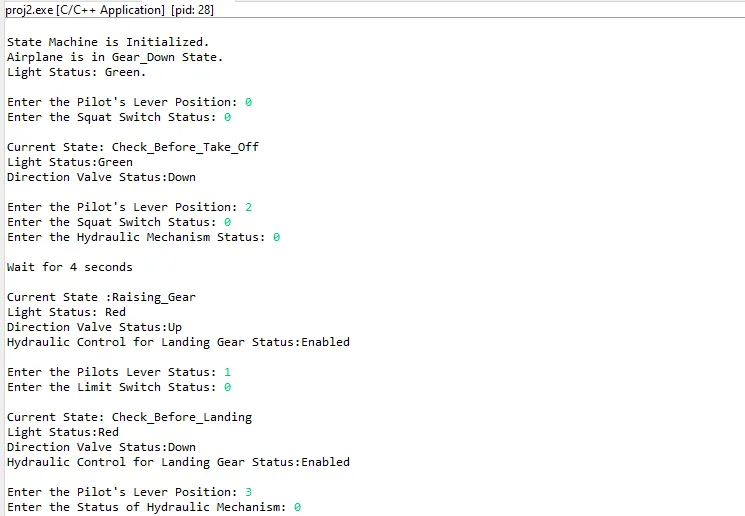
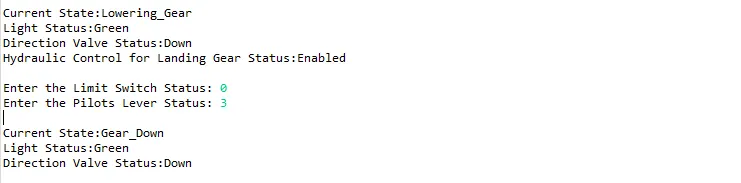
Full Code Execution From (No Gear Up State)
>>Gear Down >> Check Before Take Off >> Raising Gear >> Check Before Landing >> Lowering Gear >> Gear Down.
Full Code Execution From (No Gear Down State)
>>Gear Down >> Check Before Take Off >> Raising Gear >> Gear Up >> Check Before Landing >> Lowering Gear >> Check Before Take Off.