Project 2 - Implement the Code for controlling the retraction and extension of Airplane’s landing gear
Implement the Code for controlling the retraction and extension of Airplane’s landing gear.
#include <stdio.h>
#include<conio.h>
typedef enum { //Gear state
gr_down,
gr_chk_takeoff,
gr_raising,
gr_up,
gr_chk_landing,
gr_lowering
}state_type;
state_type current_state;
typedef enum { //Limit switch
open,
close
}Switch;
typedef enum { //Lever
down,
raising,
up,
falling
}
pilot_lever;
typedef enum { //hydraulic_mechanism
working,
malfunctioning
}hydraulic_mechanism;
typedef struct{ //state table
char* current_state_indication;
char* LED_indication;
char* direction_valve;
char* hydraulic_pump_status;
char* gas_pressurized_spring_status[2];
}state_table;
state_table state[6]={{"gear_down","green","down","enabled",{0,0}},
{"checking_before_takeoff","green","down","enabled",{0,0}},
{"raising_gear","red","up","enabled",{"enabled","disabled"}},
{"gear_up","off","Null","disabled",{0,0}},
{"checking_before_landing","red","down","enabled",{0,0}},
{"lowering_gear","green","down","enabled",{"enabled","disabled"}}};
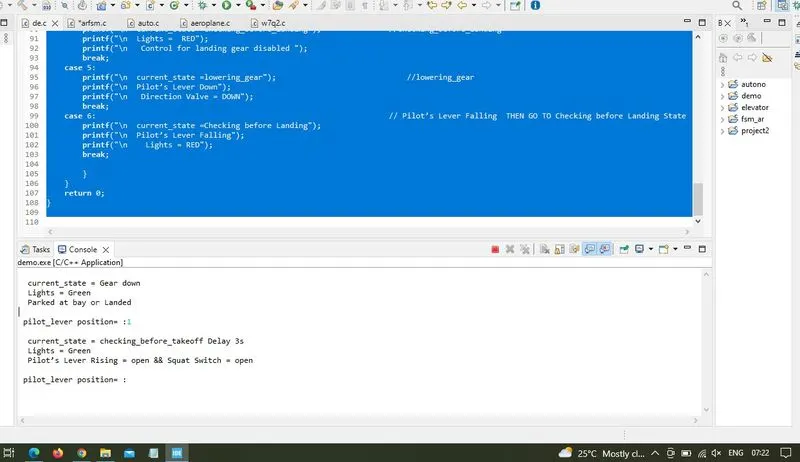
int main()
{

	printf("\n  current_state = Gear down");
			    printf("\n  Lights = Green ");
			    printf("\n  Parked at bay or Landed");
	while(1)
	{
	int pilot_lever;

	/*
	  pilot lever act as input pilot lever

raising=1,
up=2,
limit switch closed=3,
control enabled=4
falling=0

	*/
		    printf("\n\n pilot_lever position= :");
	fflush(stdout);
	scanf("%d",&pilot_lever);
	switch(pilot_lever)
		{

	case 0:
		printf("\n  Emergency state");
		    printf("\n  moving_state =Gear Down");
		    printf("\n  Pilot’s Lever Falling or Squat Switch = close ");
		    printf("\n    Lights = RED");
		    break;
	case 1:
		//checking_before_takeoff Delay 3s

	    printf("\n  current_state = checking_before_takeoff Delay 3s");
	    printf("\n  Lights = Green ");
	    printf("\n  Pilot’s Lever Rising = open && Squat Switch = open");
	    break;
	case 2:																	//raising_gear
		printf("\n current_state =raising_gear ");
		printf("\n  Lights =  RED");
	    printf("\n  Pilot’s Lever Rising  && Squat Switch = open");
        break;
	case 3:																		//gear_up
        printf("\n   current_state =gear_up ");
	    printf("\n  Lights =  OFF");
	    printf("\n   Control for landing gear disabled ");
	    break;
	case 4:
		printf("\n  current_state =checking_before_landing");               //checking_before_landing
		printf("\n  Lights =  RED");
	    printf("\n   Control for landing gear disabled ");
		break;
	case 5:
		printf("\n  current_state =lowering_gear");								//lowering_gear
		printf("\n  Pilot’s Lever Down");
		printf("\n   Direction Valve = DOWN");
		break;
	case 6:																	// Pilot’s Lever Falling  THEN GO TO Checking before Landing State
	    printf("\n  current_state =Checking before Landing");
		printf("\n  Pilot’s Lever Falling");
		printf("\n    Lights = RED");
		break;

		}
	}
	return 0;
}
output: