Project 2 Adaptive Cruise Control
Adaptive Cruise Control
aim:
* To develop the Adaptive Cruise Control feature as per the Requirement Document using MATLAB Simulink.
* To follow all the MBD related processes such as Requirement Tagging & Traceability, SLDD creation, Configuration Parameter changes, Model Advisor check & Code Generation.
FROM REQUIRMENT 1:
inside of the block creating chart with the help of requirement document.....
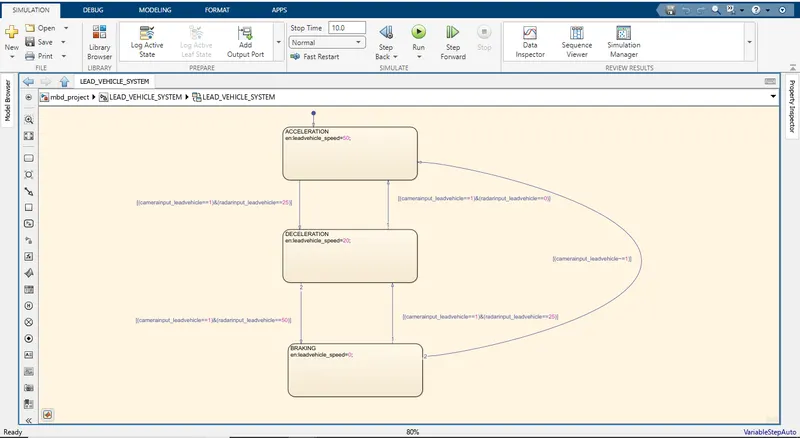
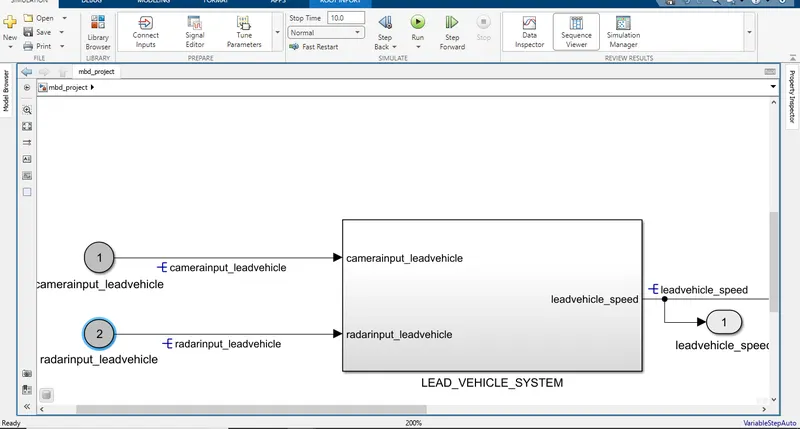
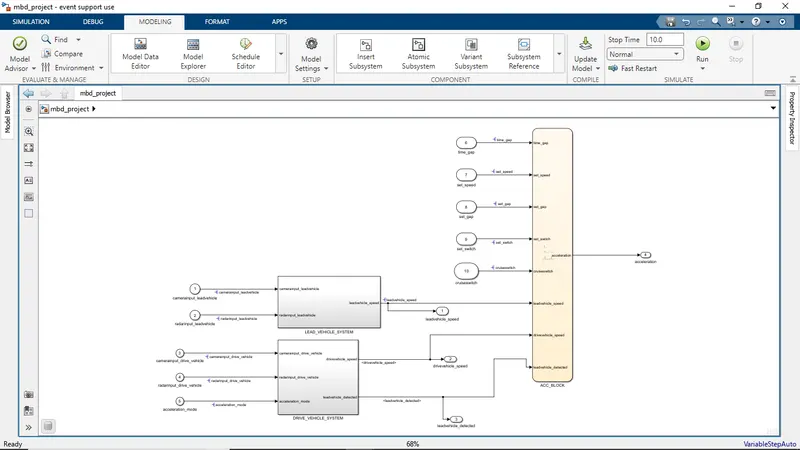
* Lead Vehicle is a vehicle which is driving in the road ahead of our drive vehicle. Two input signals (Signal Name: CameraInput_LeadVehicle & RadarInput_LeadVehicle).
* We can simply add both the radar & camera inputs & the corresponding output is read as Speed profile output (Signal Name: LeadVehicle_Speed).
FROM REQUIREMENT 2:
Creating one subsystem
inside of the block creating one flow chart with the help of the requirement document....
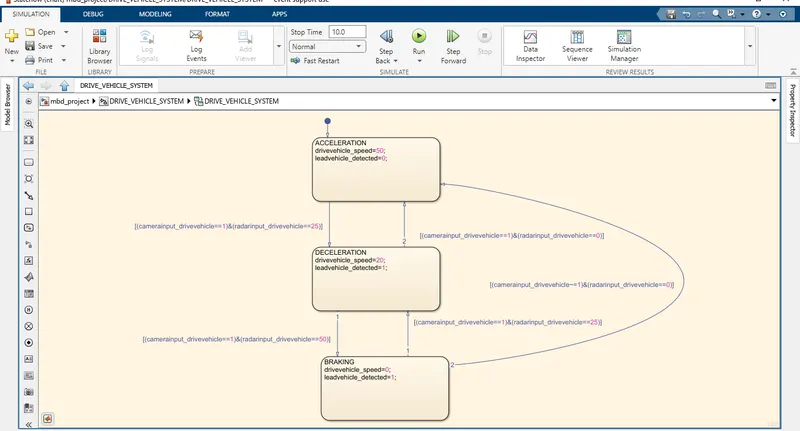
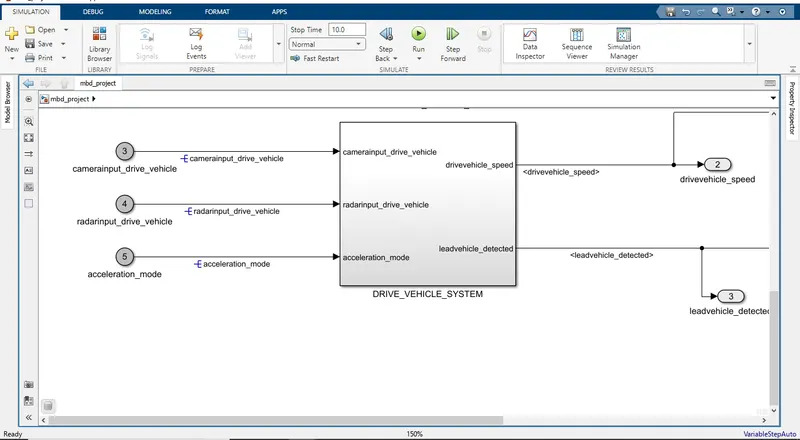
* Drive Vehicle is the vehicle driven by the user & this is the vehicle which has ACC algorithm in it.
* Like the Lead Vehicle, Drive Vehicle algorithm also has 2 input signals (Signal Name: CameraInput_DriveVehicle, RadarInput_DriveVehicle) & one signal coming as an Input to this subsystem (Signal Name: Acceleration_Mode) – three inputs into this requirement in total.
* Two output signals come from this subsystem (Signal Name: DriveVehicle_Speed & LeadVehicle_Detected).
FROM THE REQUIREMENT 3A:
TO CREATING OFF ALGORITHM....
* This is the default state inside state machine logic. Output signal Acceleration_Modeis at value 0 in this state.
* This state is governed by input signal CruiseSwitch.
* If CruiseSwitchis equal to 1, state ACC STANDBY mode will get activated. If CruiseSwitch is equal to 0, state ACC OFF mode will get activated, from either ACC ON mode or ACC STANDBY mode
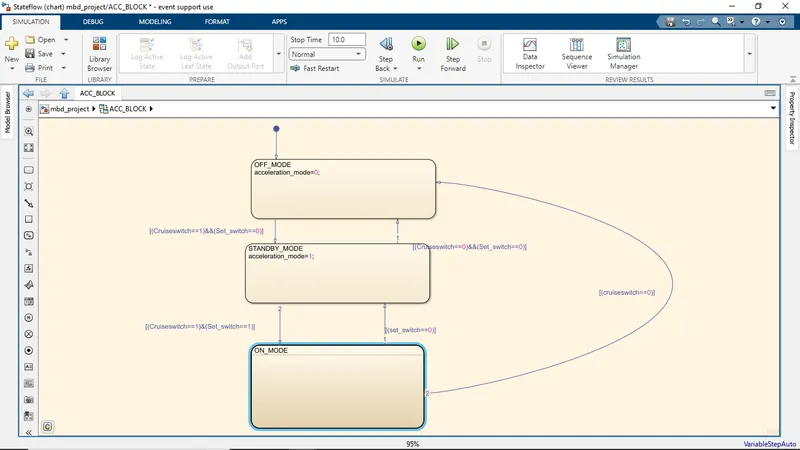
FROM THE REQUIREMENT 3B ....STANDBY MODE LOGIC ALSO CREATED
FROM THE REQUIREMENT 3C:: ON LOGIC
* this state will be activated when input signal SetSwitch is equal to 1. There are 6 sub states to this state logic
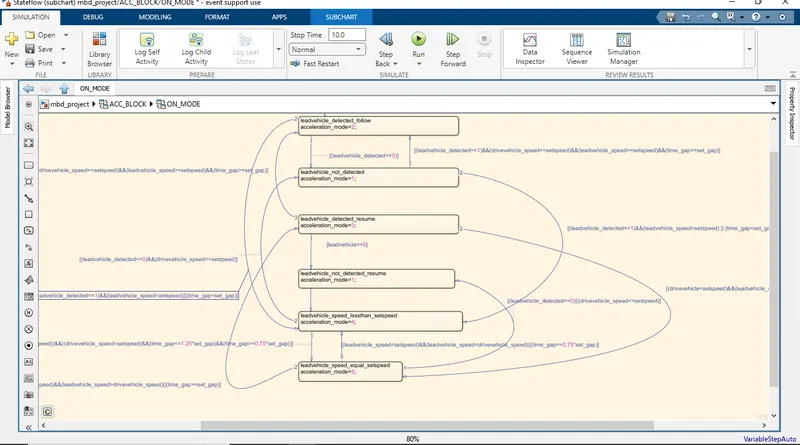
after creating all the requirements.....
final overall model is here..............
to creating SLDD file....
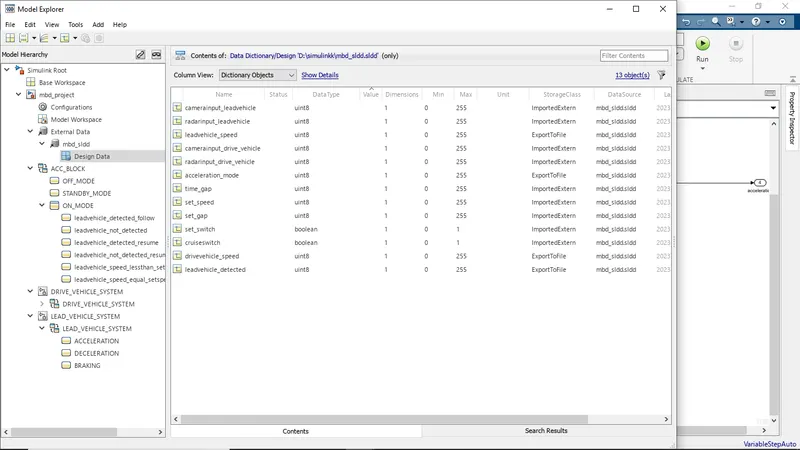
and generating code generation part.......
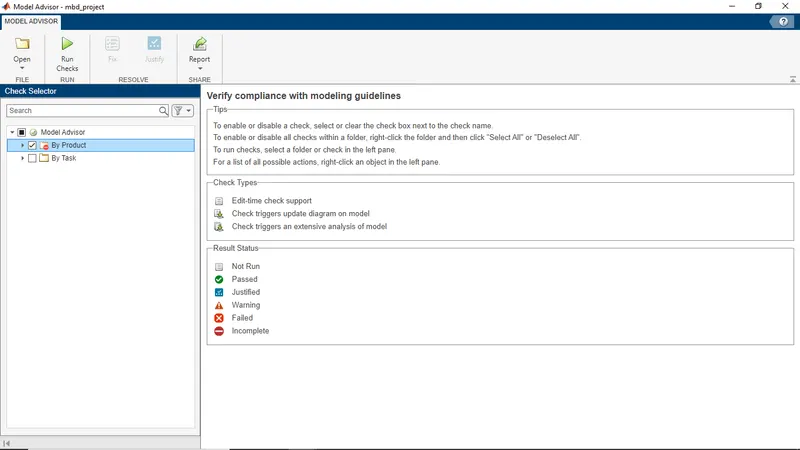
the main MODEL ADVISOR REPORT......
CONCLUSION:
The Adaptive cruise control is designed according to the requirements. The code is generated by using embedded coder. The model is checked for MAB test using Model Advisor and report is added....