Project 1 (Mini Project on Vehicle Direction Detection
Project 1 (Mini Project on Vehicle Direction Detection
Aim:
To create the Vehicle Direction Determination model according to the given requirements
blocks used:
constant
AND gate
compare to constant block
display
procedure:
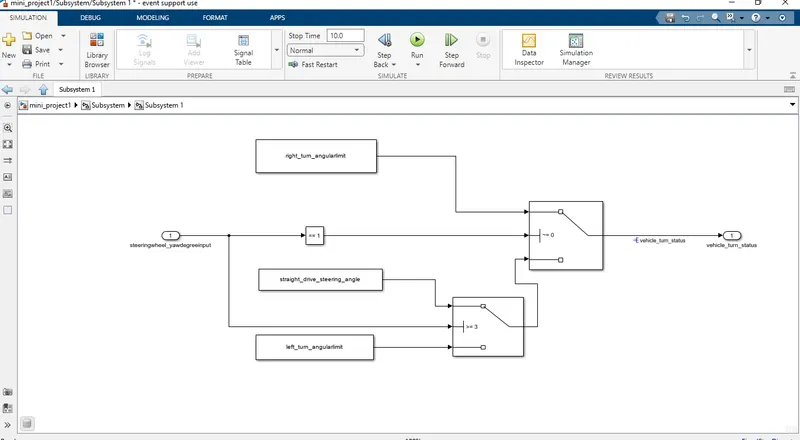
from the requirements 1
- Steering wheel input as yaw rate (Signal name: SteeringWheel_YawDegreeInput) is the input for this system.
- This is compared against 3 angular values, one each for left turn, right turn & straight drive (Calibration Values: Right_Turn_AngularLimit, Left_Turn_AngularLimit, Straight_Drive_Steering_Angle) to say which specific direction the steering wheel is turning towards.
- Use switch blocks to compare & develop this requirement. Keep this requirement in a subsystem & output of this requirement is a local signal (Signal Name: Vehicle_Turn_Status).
to creating one subsystem......
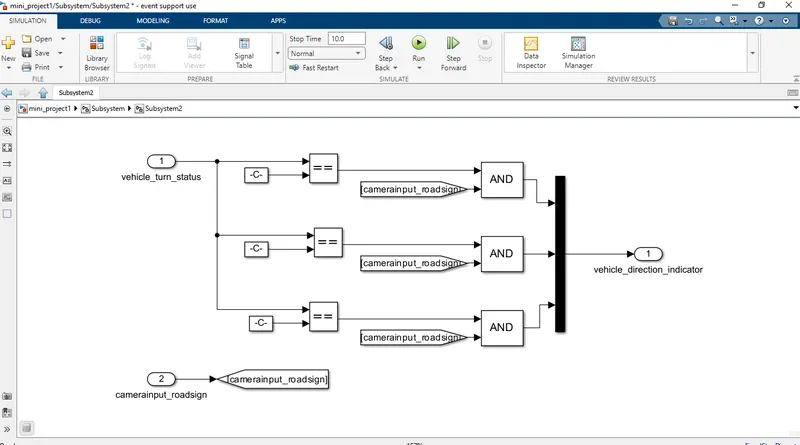
from the requirements 2
- Keep this requirement as a separate subsystem. Inputs to this requirement are local signal from requirement 1 (Signal Name: Vehicle_Turn_Status) & an input signal from camera (Signal Name: CameraInput_RoadSign), which confirms the occurrence of a road sign.
- Signal Vehicle_Turn_Status is compared against calibration values (Calibration Values: RightTurn_RoadSign, LeftTurn_RoadSign, Straight_RoadSign), if each of them is found equal, then each of the three corresponding output is compared against the camera input signal,
- Using a logical operator block, only one among them is finally given as output signal (Signal Name: Vehicle_Direction_Indicator).
to creating the subsystem 2......
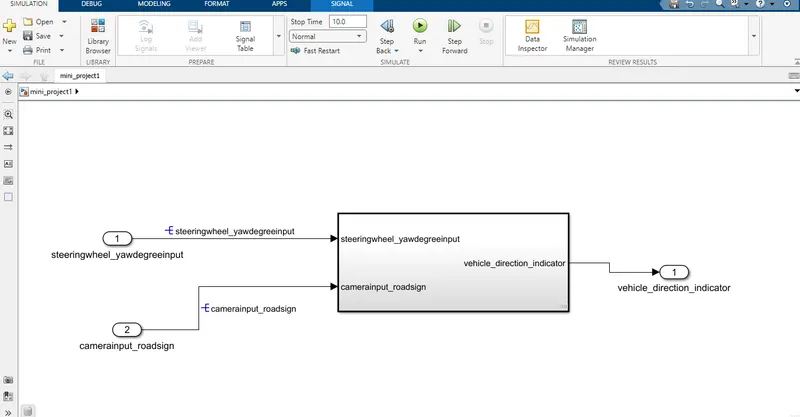
after creating susbystems....
* identifying the direction the vehicle is taking based on the camera input.
* The camera reads the road signs & stores them into its memory with unique values for a left turn, right turn & straight drive.
* Depending on the direction it is taking, the final indication is given to the driver
main model of the system.....
code generation part....
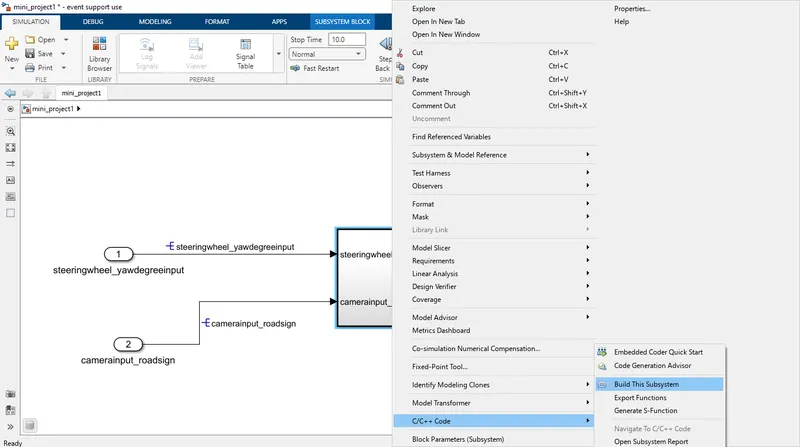
* right click on the subsytem ...goto the code generation part.
* solver settings are as per the requirements. sample time is 0.01
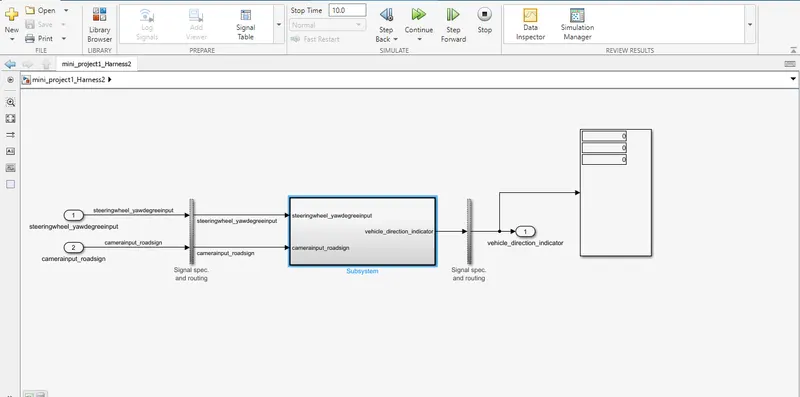
and the must be create the test harness.....
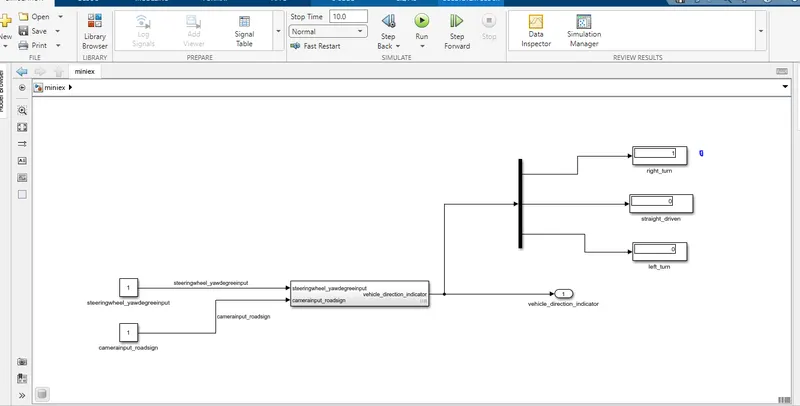
RIGHT_TURN_OUTPUT
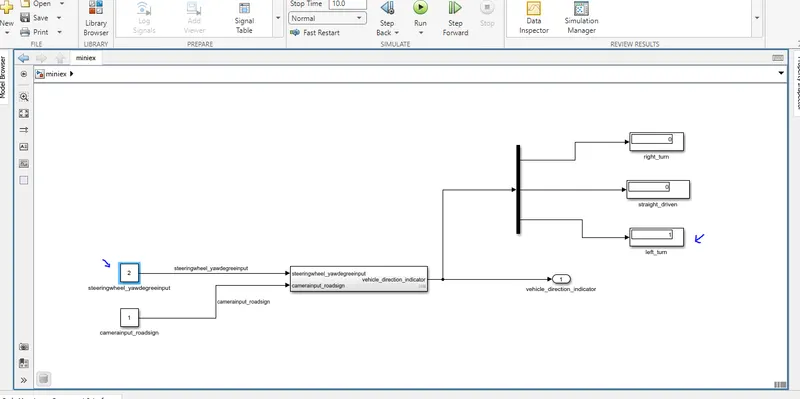
LEFT_TURN_OUTPUT
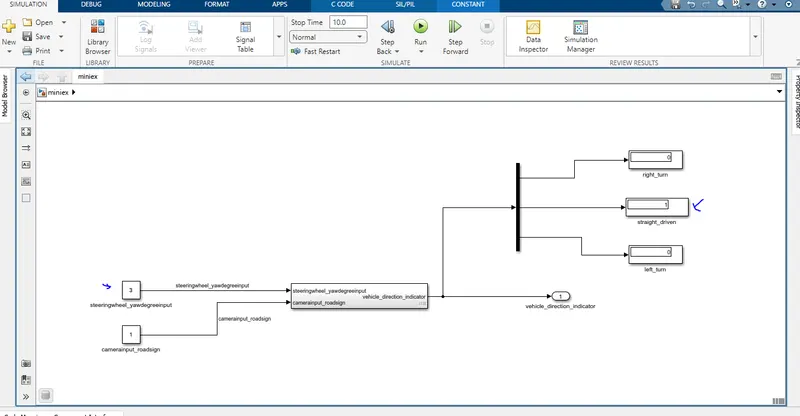
STRAIGHT_DRIVE_OUTPUT
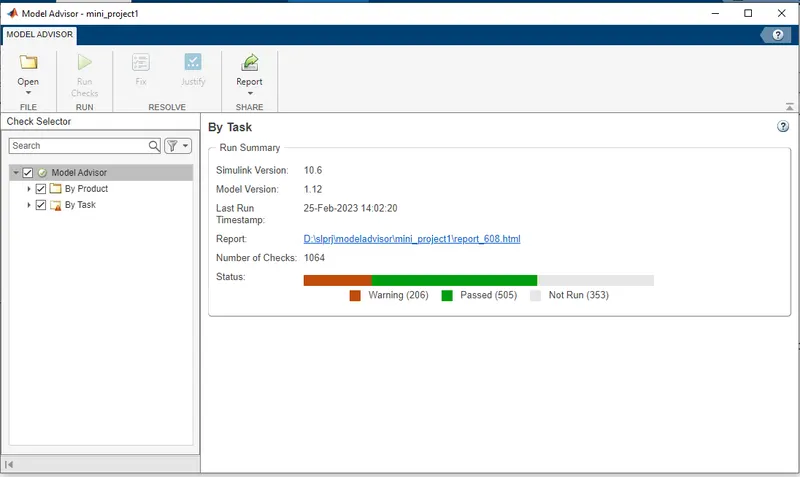
model advisor report
Conclusion:
Successfully created the model from the given requirement data and generated the code and advisor report.