Project 2 Adaptive Cruise Control
Aim -
To design and simulate Adaptive Cruise Control feature for a car which can reduce the strain on driver
A radar sensor is usually at the core of the Adaptive Cruise Control. Installed at the front of the vehicle, the system permanently monitors the road ahead. As long as the road ahead is clear, cruise control feature maintains the speed set by the driver. If the system spots a slower vehicle within its detection range, it gently reduces speed by releasing the accelerator or actively engaging the brake control system. If the vehicle ahead speeds up or changes lanes, the cruise control automatically accelerates to the driver’s desired speed.
file names
Model Advisor - "report"
simulink model "AdaptiveCruiseControl"
data dictionary "ACC_data"
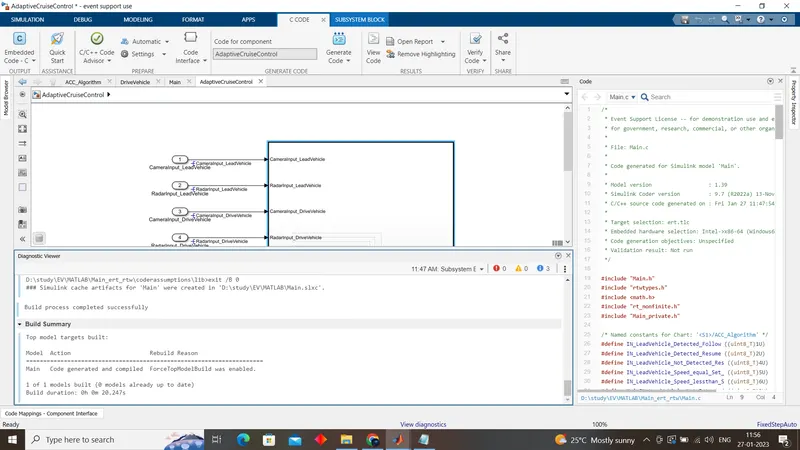
C code "AdaptiveCruiseControl_ert_rtw"
requirement doc "ACC_Requirement"
1)Adaptive Cruise Control feature as per the Requirement Document has been created
main model
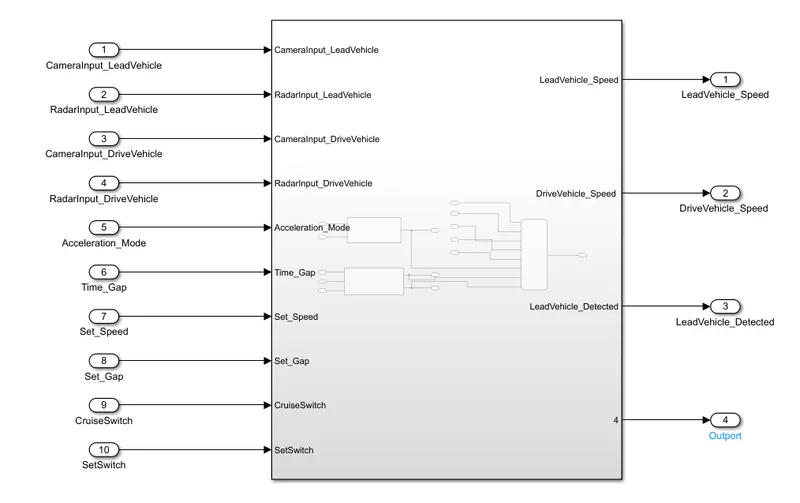
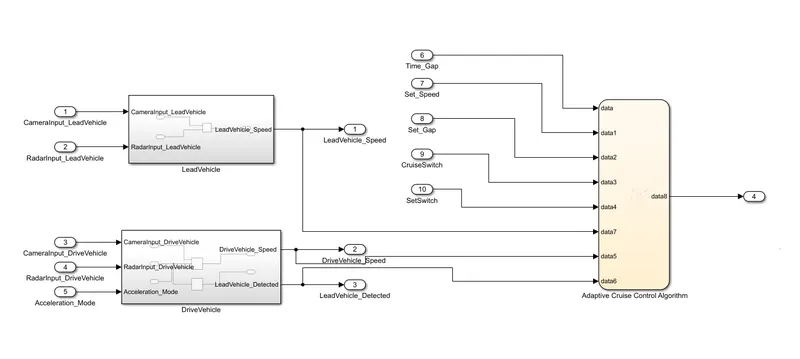
requirement 1
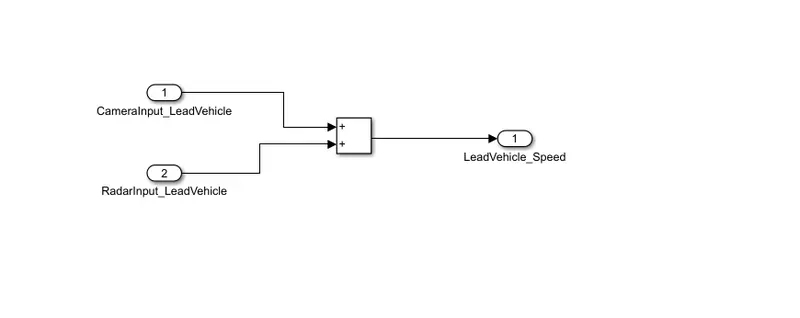
requirement 2
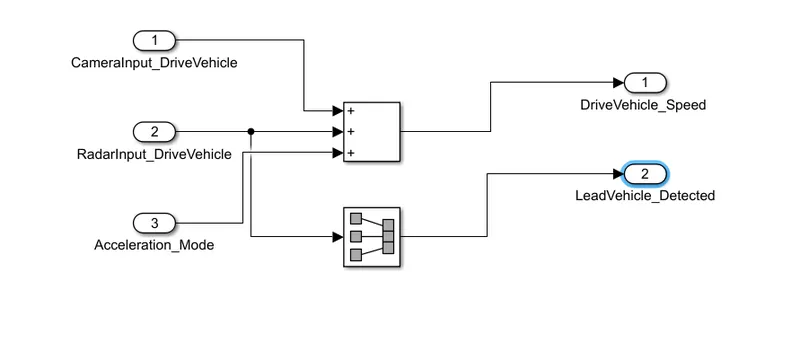
requirment 3
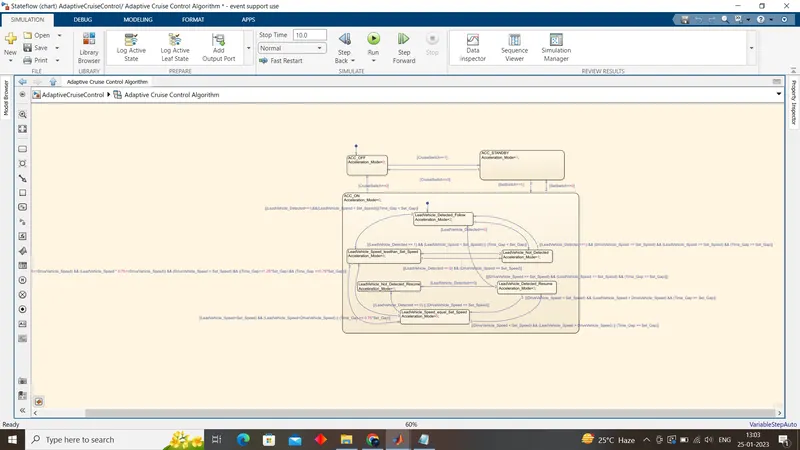
2)
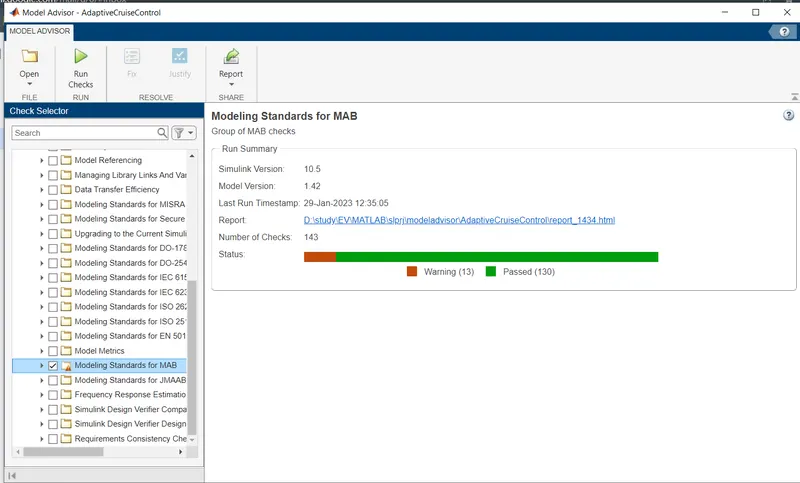
following MBD complient changes
before chages 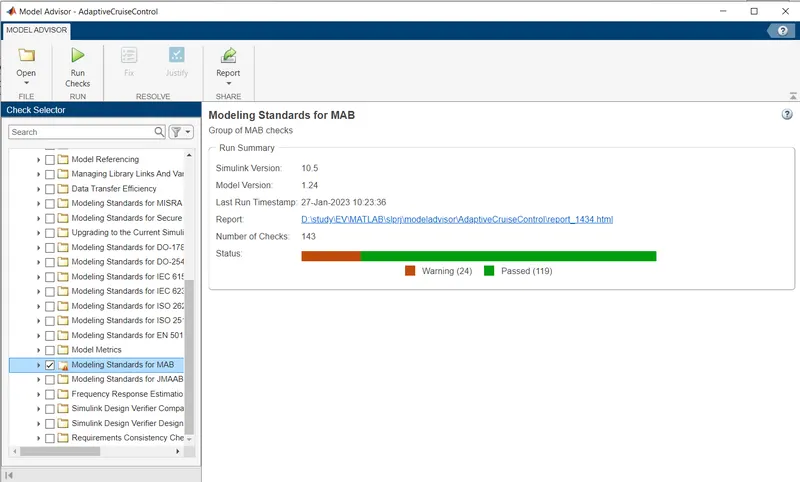
after changes
requirement 2
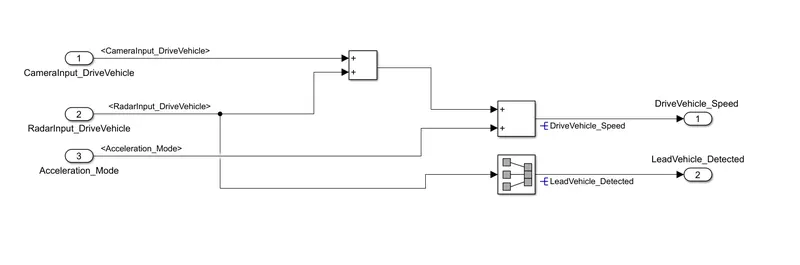
requirement3
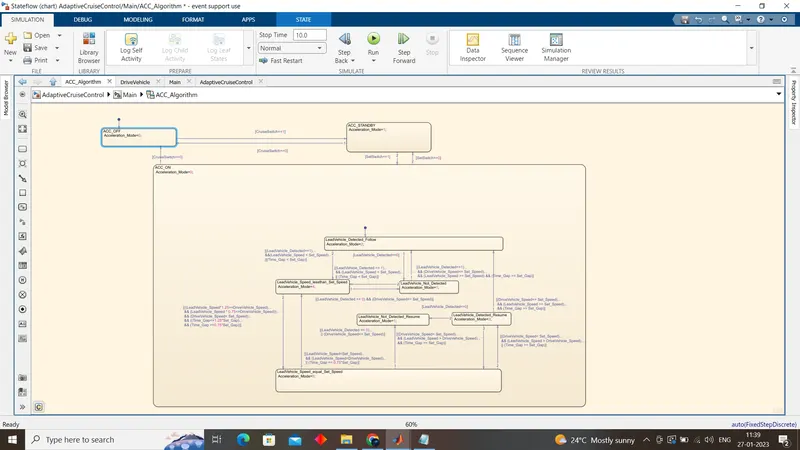
3)code generation