Project 1 (Mini Project on Vehicle Direction Detection
Aim:
Aim is the help a person driving a car in following the road signs using model designed using MATLAB and simulink.
Identifying the direction of vehicle is basically identifying the direction the vehicle is taking based on the camera input.
Camera reads the road signs & stores into its memory with unique values for left turn, right turn & straight drive. Depending on the direction it is taking, final indication is given to the driver – as an indication if he is driving in the recommended direction or not.
files
a)data dictionary "VehDirDetcSignals.sldd"
b)simulink model "VehDirDetc.slx"
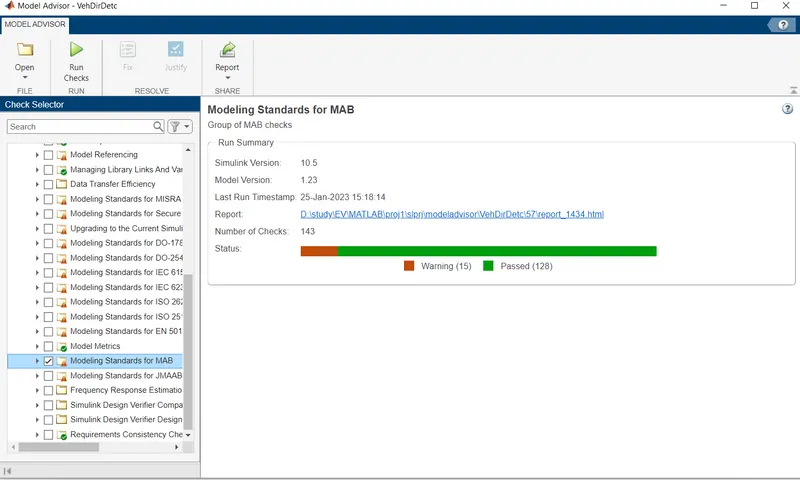
c)Model Advisor "Report"
d)c code "VehDirDetc_ert_rtw"
e)s-function
1)created data dictionary
2)Assumption
for 1st requirement
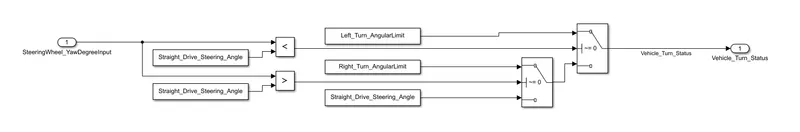
a)when the driver turns result in positive degrees that is more than 0 degree, its considered that the driver wants to turn right and the "Vehicle_Turn_Status" = 30
b) when the driver turns result in vegative degrees that is less than 0 degree, its considered that the driver wants to turn leftand the "Vehicle_Turn_Status" = -120
c) when the drivers is not turning and keeps the steering whell steady at 0, its considered that he wants to go stright and "Vehicle_Turn_Status" = 0
this is implemented using relational block and switch block.
for requirement 2
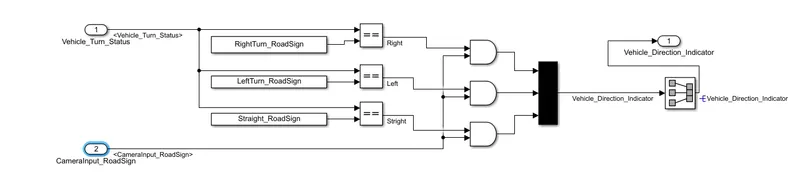
Vehicle_Turn_Status is compared with road sign values "RightTurn_RoadSign","LeftTurn_RoadSign" and "Straight_RoadSign"
and an and operation is performed to show which road sign was detected by the camera Right, Left or Stright
Input and output signals are resolved to simulink signal objects
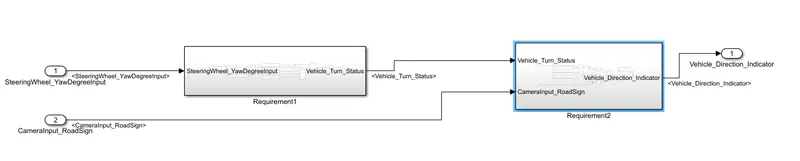
requirement 1 and 2 are build inside subsystem called requirement1 and requirement2 respectively and are atomic subsystem
3)
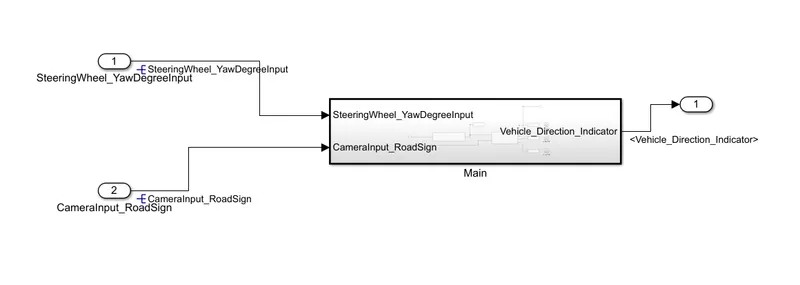
requirement1 and requirement2 are enclosed inside "Main" subsystem which is treated as atomic subsystem
4)Model Advisor report