Project 2 Adaptive Cruise Control
Aim: To develop an Adaptive Cruise Control feature using Matlab simulink/Stateflow as per the the requirement .
SLDD CREATION:
- Create a Simulink model and save it
- Create a new SLDD file under external data->new->create new sldd file
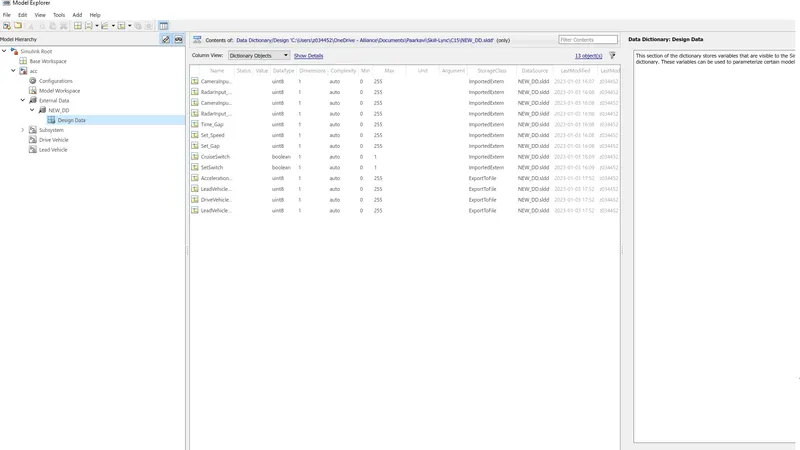
- Under Model Explorer->external data->new_DD>Design Data->Add the input ,output and constant signals and enter the range as specified in requirement
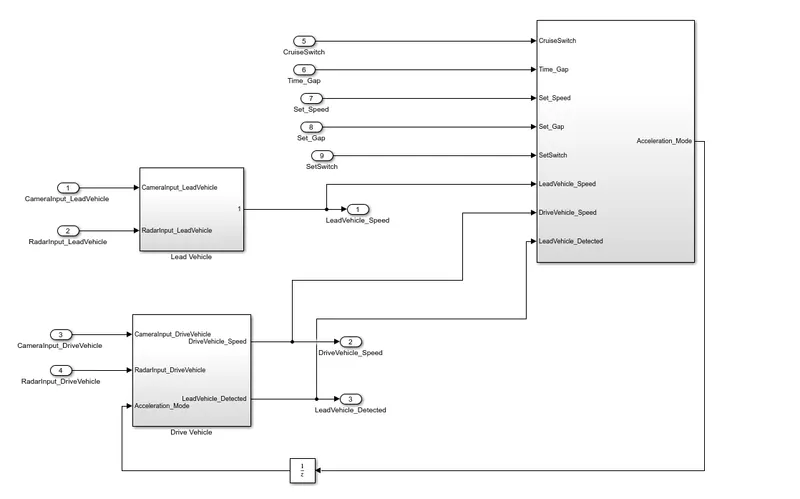
Creating Simulink model
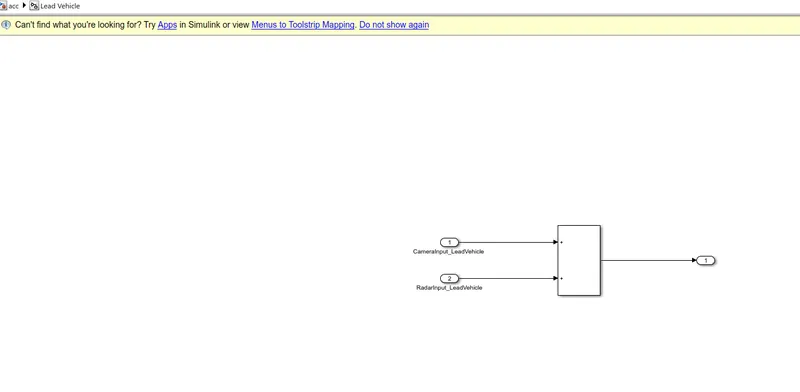
Lead_Vehicle subsystem: The camera and radar inputs values are the inputs and Lead vehicle speed will be the output [Requirement1]
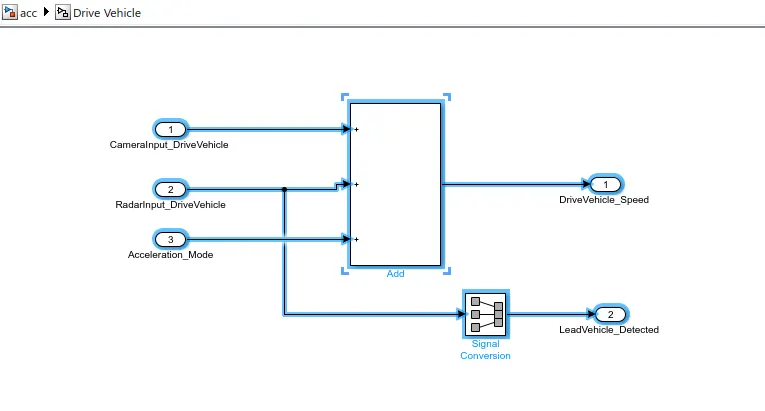
Drive vehicle subsystem: Camera input, radar input, and acceleration mode are the input signals. There will be 2 outputs namely drive vehicle speed and lead vehicle detection signal
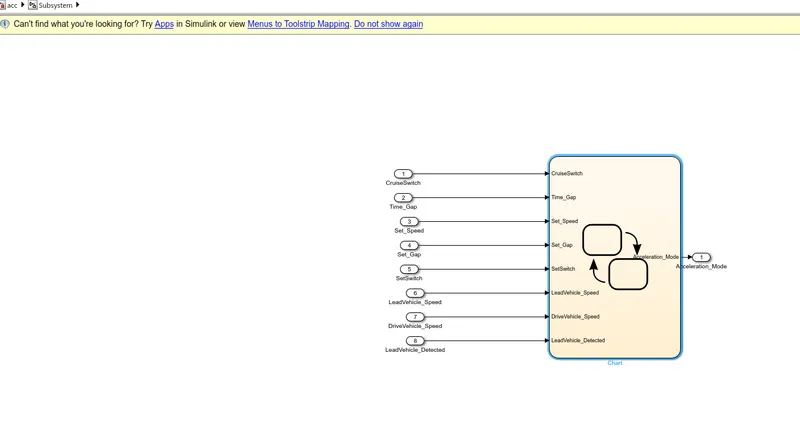
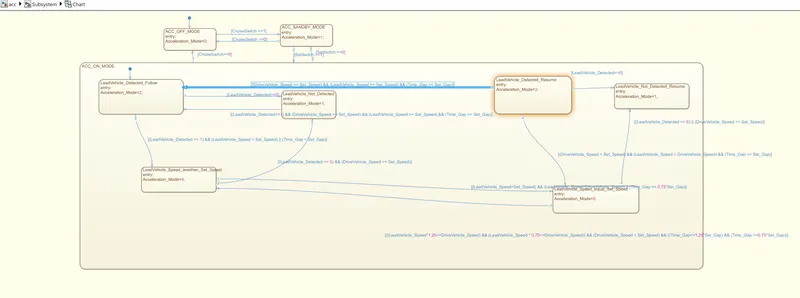
ACCAlgorithm subsystem: Acc logic is developed in stateflow.It contains 8 input and One output signals.
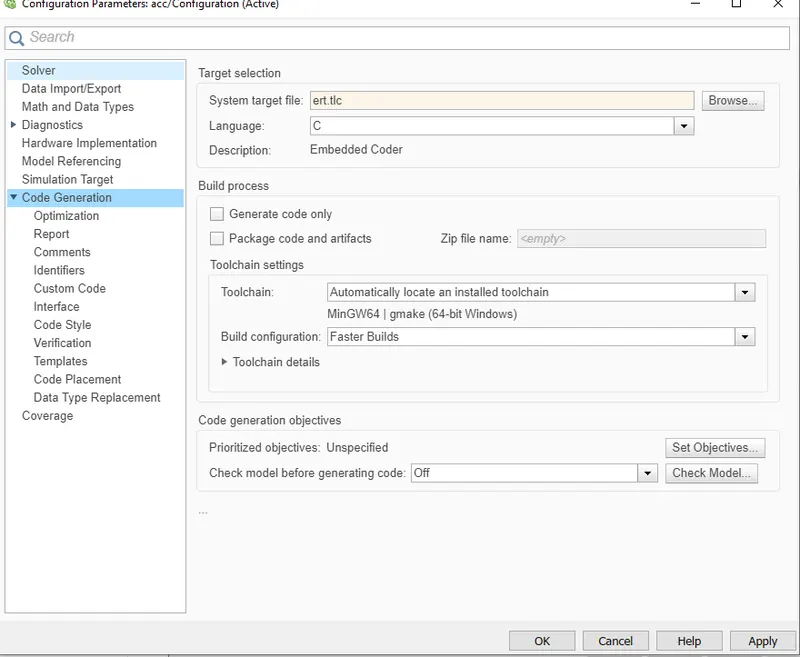
code generation:
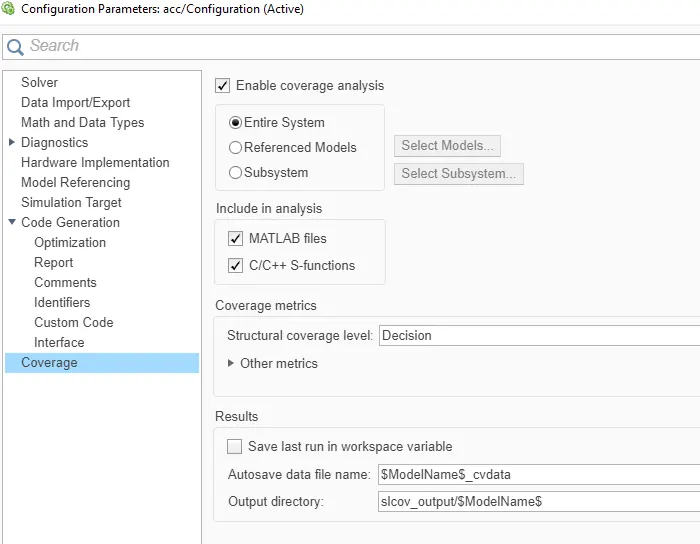
Coverage:
Model advisor check
- Run the model and check for any errors
- Go to model advisor > select the whole system >OK
- Model advisor > select "By task"
- Select "modeling standards for MAB
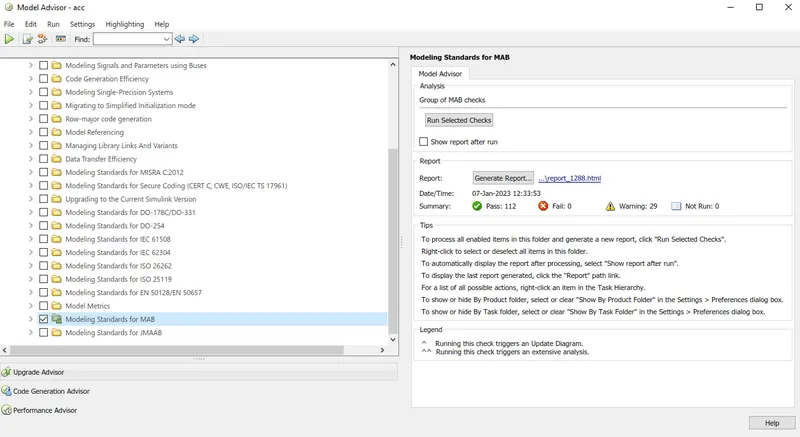
Result:
- The adaptive cruise control is modeled in Simulink as per the given requirements
- Solver and code generators are configured
- SLDD file is created and linked to the model
- Model advisor report is generated