Project 1 (Mini Project on Vehicle Direction Detection
Aim:
To determine the Vehicle direction(Right_Turn,Left_Turn or Stright ) and to confirm the occurrence of a road sign.
Requirement:
Requirement_1
If the SteeringWheel_YawDegreeInputis >=30 ,the vehicle will take the Right turn, else If the input is (~=0) the vehicle will take left_turn else stright_drive .The output for the Requirement_1 is "Vehicle_Turn_Status".
Requirement_2
Input :Vehicle_Turn_Status(Output of Requirement_1) and CameraInput_RoadSign(To confirm the road sign).
each RightTurn_RoadSign,LeftTurn_RoadSign and Straight_RoadSign is comared with Vehicle_Turn_Status and CameraInput_RoadSign.
One among the output is taken out using MUX block and final output will be updated in Vehicle_Direction_Indicator
Screenshot:
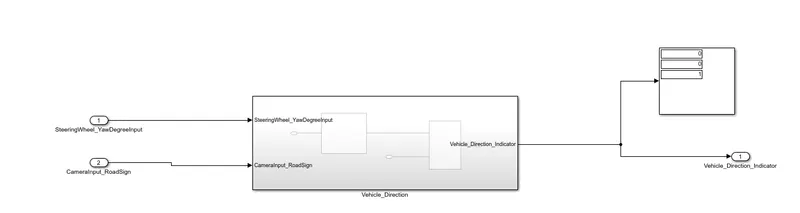
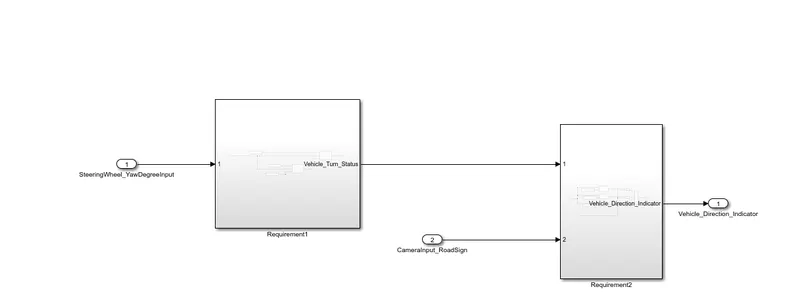
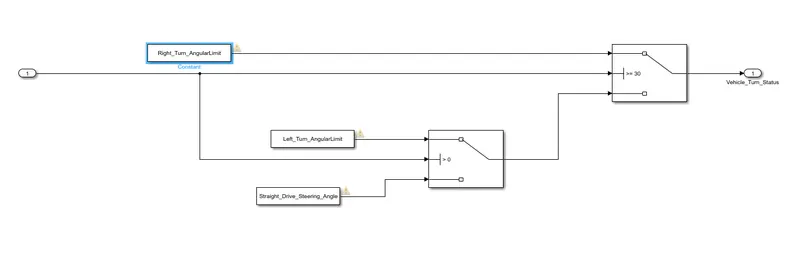
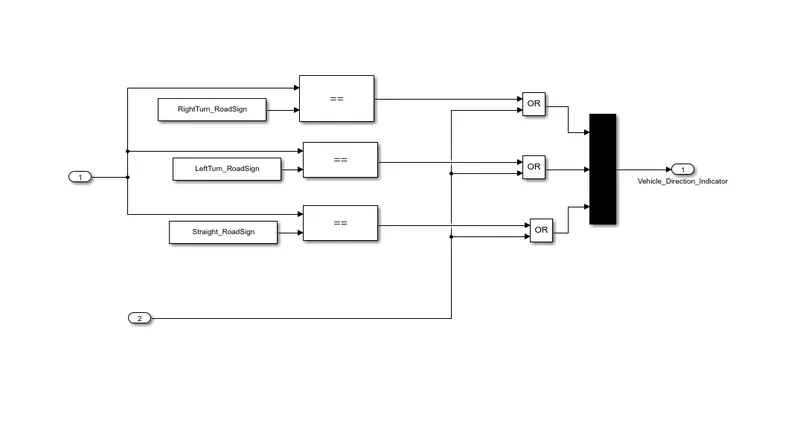
Output:
Results:
- If the output is [1,0,0], Then the vehicle will take the Right turn.
- If the output as [0,0,1], the vehicle will take the straight drive.
- If the output is [1,0,1], the vehicle will take the Left turn.