Project 2 Adaptive Cruise Control
The adaptive cruise control is used to control the speed of vehicle to avaiod the collision between vehicle.by this system we can avaoid the accident.here we use radar system.this will measure the distance between the vehicle.
The model files are attached below as project.
Steps and screenshots are given below.
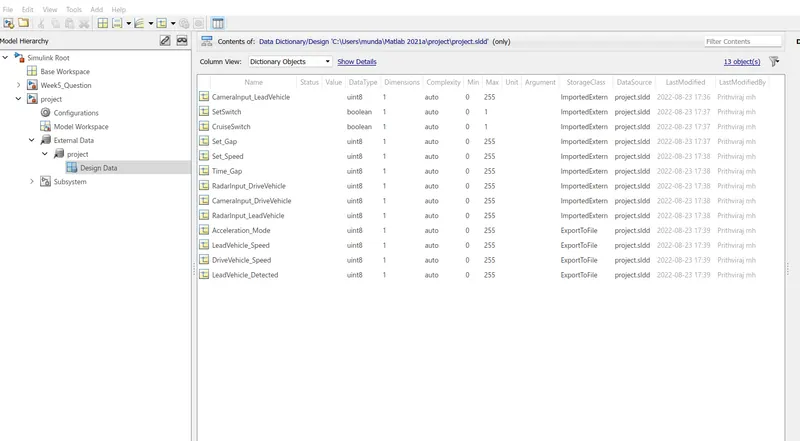
creating SLDD file.
In Modeling -model setting-Model properties-external data-click on new and select folder to save and apply.
then with use of given information create SLDD file as given below.
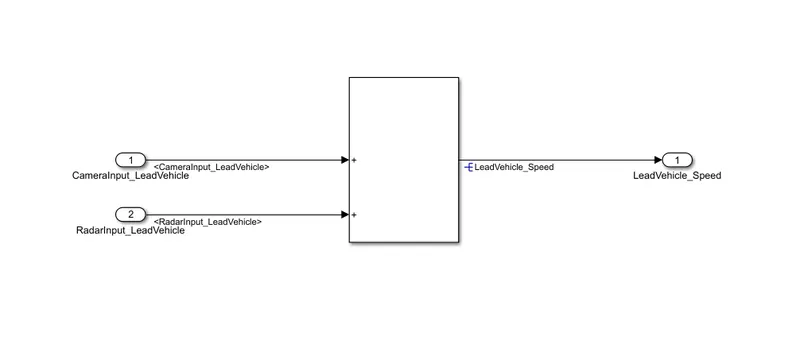
Requirement 1– Lead Vehicle:
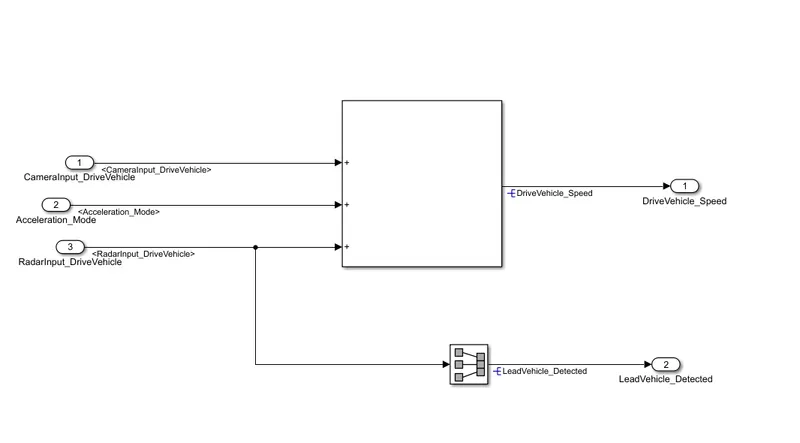
Requirement 2 – Drive Vehicle:
Requirement 3 – Adaptive Cruise Control Algorithm:
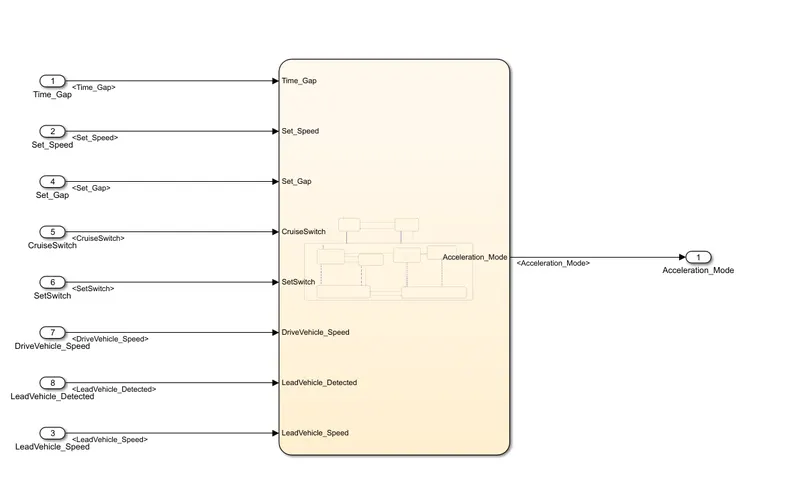
Requirement 3a – ACC OFF MODE state logic:
Requirement 3b – ACC STANDBY MODE state logic:
Requirement 3c – ACC ON MODE state logic:
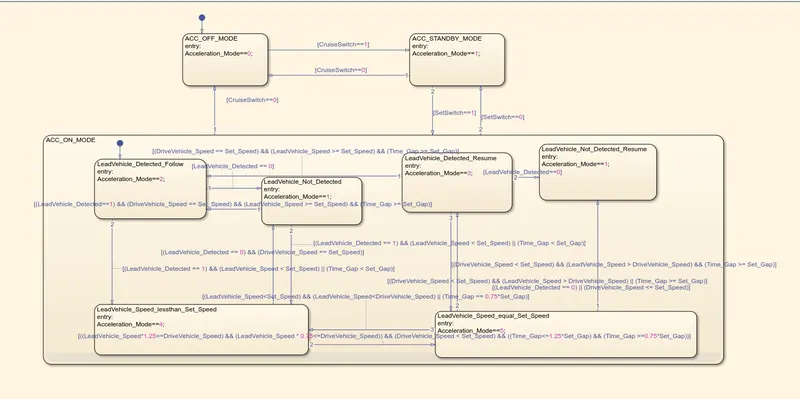
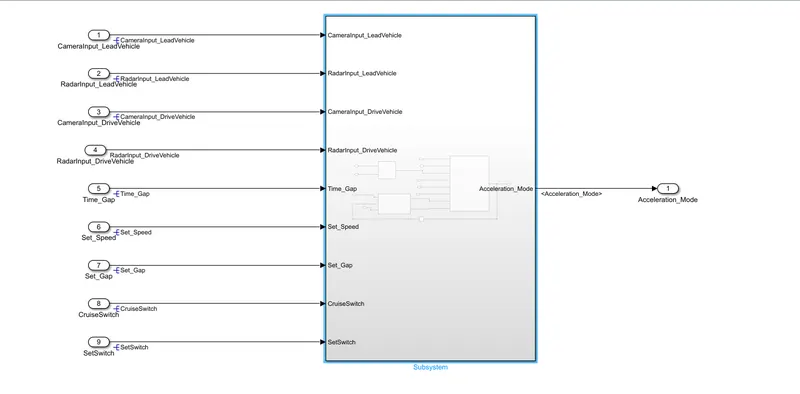
Subsystem.
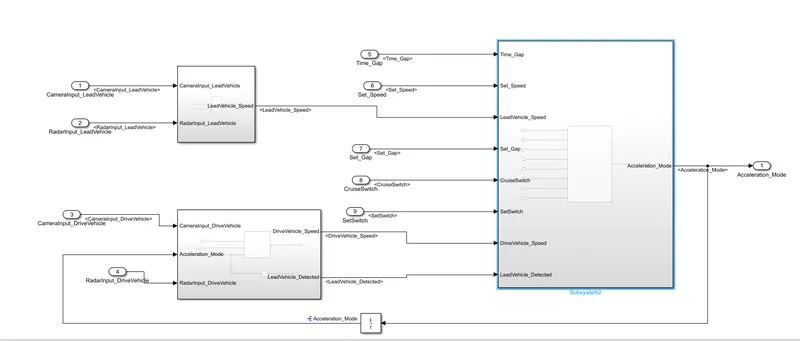
final model.
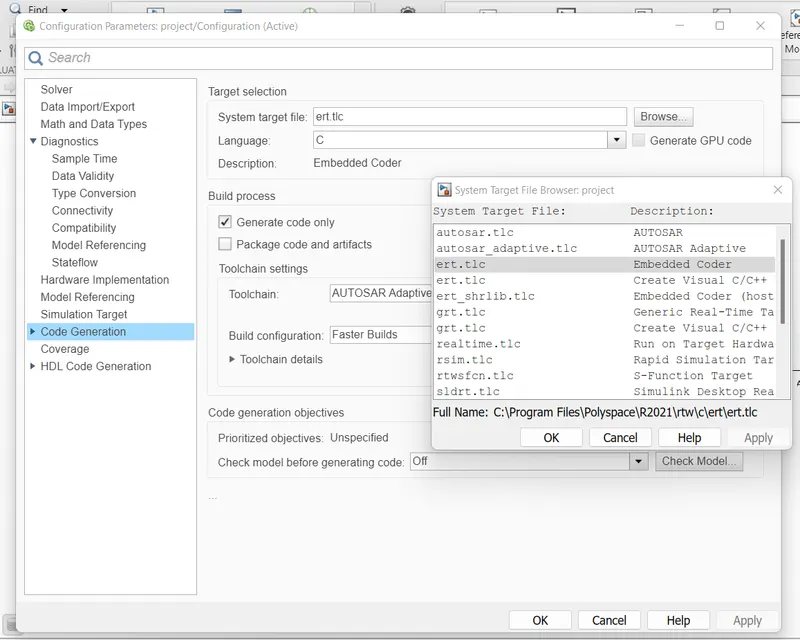
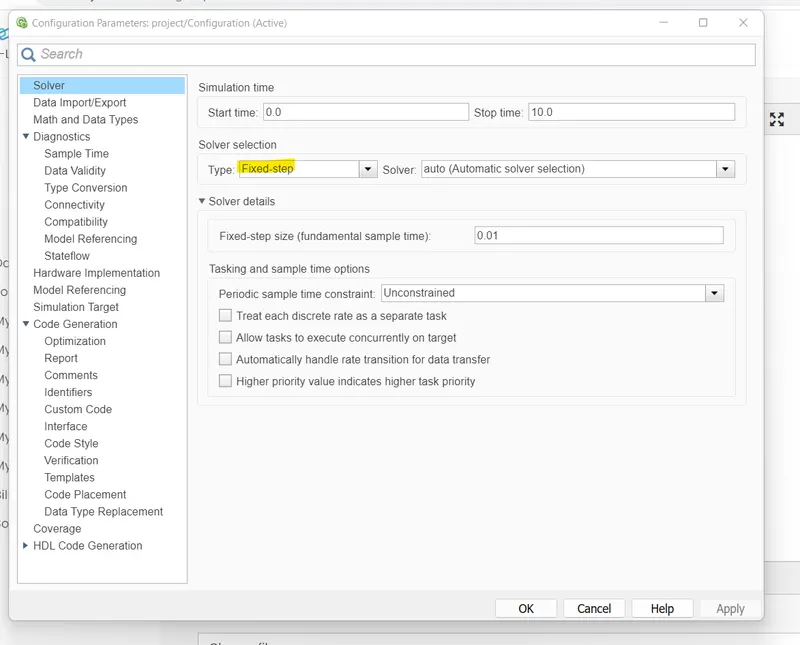
configuration parameters setting screenshot is given below.
in configuration parameters-code generation-ert.tlc-apply and ok
Tagging will be done by clicking right on subsystem and requirements-link to selection in word.
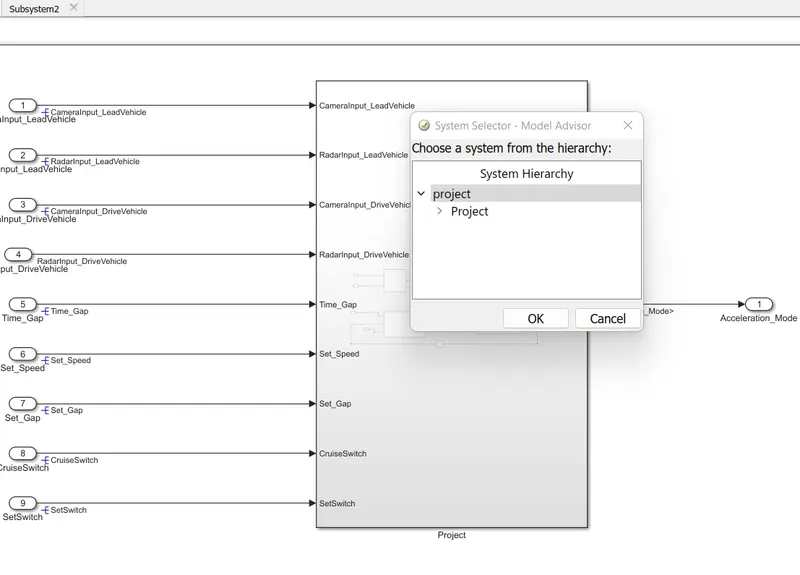
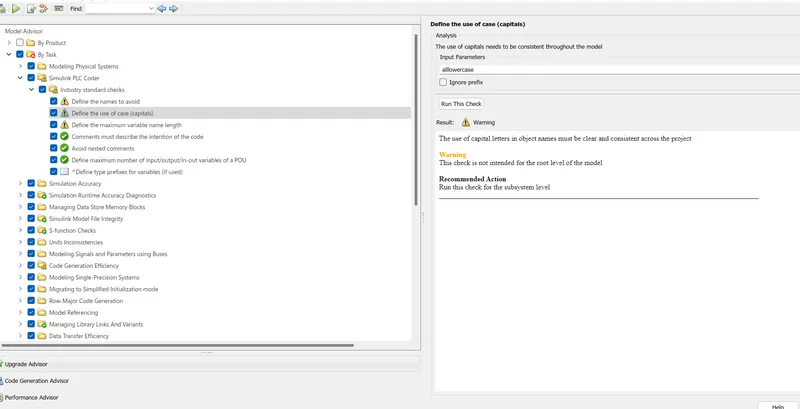
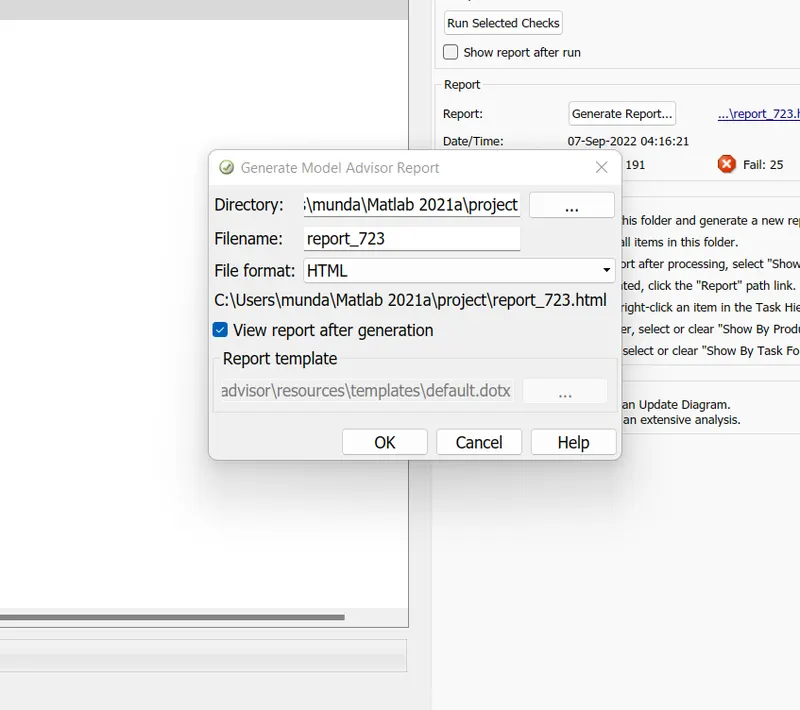
For model advisor check . click on model advisor - select the whole system -OK
by adaptive cruise control we can avoide the accident. this system is very usefull in traffic.by setting speed of vehicle we can avoide the collision .
the final model and reports are attached below.