Project 2 Adaptive Cruise Control
Aim:
To develop the Adaptive Cruise Control feature as per the Requirement using MATLAB Simulink.
Objective:
- Developing Adaptive Cruise Control feature as per the Requirement Document using MATLAB Simulink.
- Follow all the MBD-related processes: Requirement Tagging & Traceability, SLDD creation, Configuration Parameter changes, Model Advisor check & Code Generation.
- In Configuration Parameters: enable “Support Floating Numbers” under Code Generation settings.
- Use Embedded Coder to generate the code.
- If choosing code generation, Storage class for Input signals: ImportedExtern; Storage class for Output signal: Export to File; Storage class for local signals: localizable; Storage class for calibration signals: Const.
- Choose sample time for all signals as 0.01s
Procedure:
First of all, Initialize the model settings in the Simulink
In the model settings, Change the solver type to Fixed-step and Solver to discrete(no continuous states). Fixed-step size i.e, sample time to 0.01sec.
Change the system target file to ert.tlc i.e Embedded Coder
Now we have to make the Simulink Data Dictionary(SLDD) file and we have to link it with our model. So we have to go to modeling-->repositories and select the Link to Data Dictionary option.
Now a window will open and rename your SLDD file. And disable the option for model access to base workshop.
Next, go to model explorer and click vehicle_direction under that there is an option called Design data. Now we can enter the data into the sldd file according to our requirements,and here the data to be entered is given in the question.
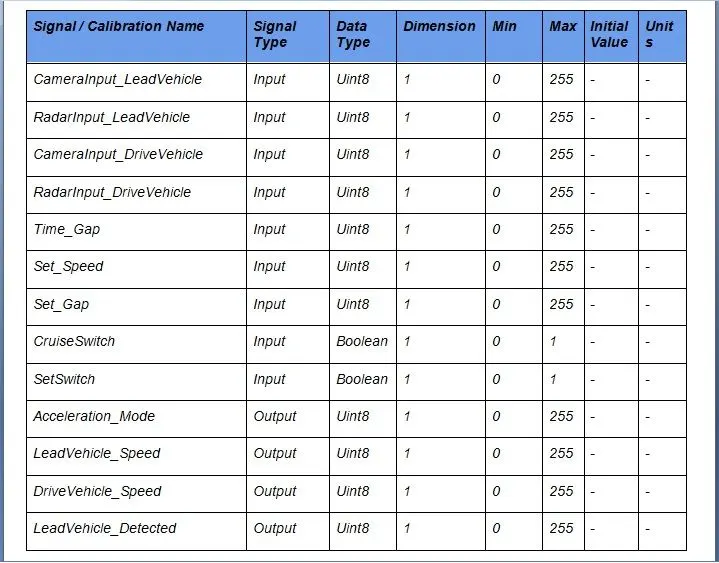
First, enter the given data into the SLDD file:
There are a total of 9 input signals,3 local signals, and 1 output signal. There is a total of 13 signals.
For Input signals give the storage class as Imported Extern, for local signals choose the storage class as Localizable, for output signals choose it as Export to File.
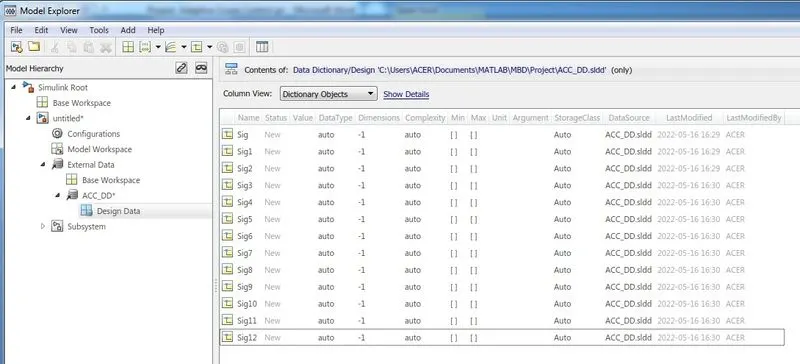
We can add a Simulink signal by selecting the Simulink Signal option.
There are three types of signals we are using in this model.
- Input Signal
- Output Signal
- Local Signal
For input signal set the storage class as an Imported extern. For output signal set the storage class as Export to File. For local signal select it as Localizable. Local signals are signals that are neither inputs nor output signals.
Calibration signals are from the constant blocks. For this, we have to select the Simulink Parameter option.
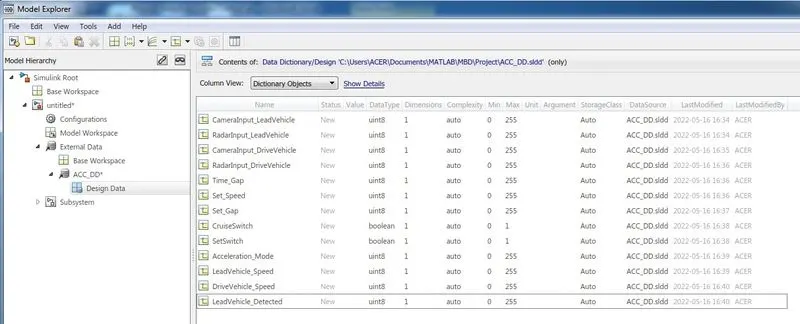
By adding the new signal to the design data , The input parameters looks like,
The Data type, dimension, Complexity,
The following details are defined in the SLDD file.
The use of the SLDD file is that when we define the signals in our model the characteristics and properties are assigned to these signals.
Requirement 1 subsystem: LEAD VEHICLE
Lead Vehicle is a vehicle that is driving on the road ahead of our drive vehicle. Two input signals (Signal Name: CameraInput_LeadVehicle & RadarInput_LeadVehicle).
- Ideally, sensor fusion techniques will be deployed to process & analyze data from cameras & radar. For complexity reasons, let’s not adapt to any such algorithms.
- We can simply add both the radar & camera inputs & the corresponding output is read as Speed profile output (Signal Name: LeadVehicle_Speed).
- Speed data of the lead vehicle is critical in implementing the Adaptive Cruise Control algorithm.
The input camera input of the lead vehicle and radar input of the lead vehicle is added to give the Speed of the Lead vehicle.
Requirement 2 subsystem: DRIVE VEHICLE
- Drive Vehicle is the vehicle driven by the user & this is the vehicle that has an ACC algorithm in it.
- Like the Lead Vehicle, the Drive Vehicle algorithm also has 2 input signals (Signal Name: CameraInput_
DriveVehicle, RadarInput_DriveVehicle) & one signal coming as an Input to this subsystem (Signal Name: Acceleration_Mode) – three inputs into this requirement in total. - Like the above requirement, sensor fusion techniques will also be deployed here, for complexity reasons we are ignoring them.
- Two output signals come from this subsystem (Signal Name: DriveVehicle_Speed & LeadVehicle_Detected).
- Signal DriveVehicle_Speed is the summation of three input signals mentioned above & LeadVehicle_Detected is renamed from Input Signal RadarInput_DriveVehicle
by mere use of Signal Conversion block.
Camera input of drive vehicle, radar input of drive vehicle, and acceleration mode is added to give the speed of drive vehicle.
Radar input of drive vehicle is then converted to lead vehicle detected signal using the signal conversion block.
Requirement 3: ACC (Adaptive Cruise Control) algorithm
Adaptive Cruise Control feature has 3 major modes of operation: OFF Mode, STANDBY Mode & ON Mode. This particular requirement has to be implemented as state machine logic in Simulink.
- The input signals to this state machine system are (Signal Name: Time_Gap, Set_Speed, Set_Gap, CruiseSwitch, SetSwitch).
- Also, the output signals (Signal Name: DriveVehicle_Speed & LeadVehicle_Detected) from requirement-2 are fed back as an input signal into this state machine block.
- Additionally, an output signal (Signal Name: LeadVehicle_Speed) from requirement-1 is given as an input signal to this state machine block as well.
- Output from this subsystem is a signal (Signal Name: Acceleration_Mode) which governs the vehicular speed of the drive vehicle which automatically adjusts its speed & velocity to match the lead vehicle.
In requirement 3 there are 6 sub-requirements.
- ACC off mode
- ACC standby mode
- ACC on mode
ACC on mode is again divided into:
- LeadVehicle_Detected_Follow (Default)
- LeadVehicle_Not_Detected
- LeadVehicle_Detected_Resume
- LeadVehicle_Not_Detected_
Resume - LeadVehicle_Speed_lessthan_
Set_Speed - LeadVehicle_Speed_equal_Set_
Speed
Requirement 3a – ACC OFF MODE state logic:
- This is the default state inside state machine logic. Output signal Acceleration_Mode is at value 0 in this state.
- This state is governed by the input signal CruiseSwitch.
- If CruiseSwitch is equal to 1, state ACC STANDBY mode will get activated. If CruiseSwitch is equal to 0, state ACC OFF mode will get activated, from either ACC ON mode or ACC STANDBY mode
Requirement 3b – ACC STANDBY MODE state logic:
- This is the second activated state inside state machine logic. Output signal Acceleration_Mode is at value 1 in this state.
- This state is governed by both input signals CruiseSwitch & SetSwitch.
- If CruiseSwitch is equal to 1, state ACC STANDBY mode will get activated. If CruiseSwitch is equal to 0, state ACC OFF mode will get activated, from either ACC ON mode or ACC STANDBY mode
- If SetSwitch is equal to 1, state ACC ON mode will get activated. If SetSwitch is equal to 0, state ACC STANDBY mode will get activated.
Requirement 3c – ACC ON MODE state logic:
This state will be activated when the input signal SetSwitch is equal to 1. There are 6 subsystems:
Requirement 3c (i) – LeadVehicle_Detected_Follow (ACC ON MODE):
- This is the default substate inside ACC ON MODE state. Output signal Acceleration_Mode is equal to 2.
- Condition to transit from LeadVehicle_Detected_
Follow to LeadVehicle_Not_ Detected; Input signal condition LeadVehicle_Detected == 0. - Condition to transit from LeadVehicle_Detected_
Follow to LeadVehicle_Speed_ lessthan_Set_Speed; Input Signals condition (LeadVehicle_ Detected == 1) && (LeadVehicle_Speed < Set_Speed) || (Time_Gap < Set_Gap).
Requirement 3c (ii) – LeadVehicle_Not_Detected (ACC ON MODE):
- Output signal Acceleration_Mode is equal to 1.
- Condition to transit from LeadVehicle_Not_Detected
to LeadVehicle_Detected_Follow ; Input signals condition [(LeadVehicle_ Detected==1) && (DriveVehicle_Speed == Set_Speed) && (LeadVehicle_Speed >= Set_Speed) && (Time_Gap >= Set_Gap)] - Condition to transit from LeadVehicle_Not_Detected
to LeadVehicle_Speed_lessthan_ Set_Speed; Input signals condition [(LeadVehicle_ Detected == 1) && (LeadVehicle_Speed < Set_Speed) || (Time_Gap < Set_Gap)]
Requirement 3c (iii) – LeadVehicle_Detected_Resume (ACC ON MODE):
- Output signal Acceleration_Mode is equal to 3.
- Condition to transit from LeadVehicle_Detected_
Resume to LeadVehicle_Detected_Follow; Input signals condition [(DriveVehicle_Speed == Set_Speed) && (LeadVehicle_Speed >= Set_Speed) && (Time_Gap >= Set_Gap)] - Condition to transit from LeadVehicle_Detected_
Resume to LeadVehicle_Not_Detected_ Resume; Input signal condition LeadVehicle_ Detected==0. - Condition to transit from LeadVehicle_Detected_
Resume to LeadVehicle_Speed_equal_ Set_Speed; Input Signal condition [(DriveVehicle_Speed < Set_Speed) && (LeadVehicle_Speed > DriveVehicle_Speed) && (Time_Gap >= Set_Gap)]
Requirement 3c (iv) - LeadVehicle_Not_Detected_
- Output signal Acceleration_Mode is equal to 1.
Requirement 3c (v) - LeadVehicle_Speed_lessthan_
- Output signal Acceleration_Mode is equal to 4.
- Condition to transit from LeadVehicle_Speed_
lessthan_Set_Speed to LeadVehicle_Not_Detected; Input signal condition [(LeadVehicle_ Detected == 0) && (DriveVehicle_Speed == Set_Speed)] - Condition to transit from LeadVehicle_Speed_
lessthan_Set_Speed to LeadVehicle_Speed_equal_ Set_Speed; Input signals condition [((LeadVehicle_ Speed*1.25>=DriveVehicle_ Speed) && (LeadVehicle_Speed * 0.75<=DriveVehicle_Speed)) && (DriveVehicle_Speed < Set_Speed) && ((Time_Gap<=1.25*Set_Gap) && (Time_Gap >=0.75*Set_Gap))]
Requirement 3c (vi) - LeadVehicle_Speed_equal_Set_
- Output signal Acceleration_Mode is equal to 5.
- Condition to transit from LeadVehicle_Speed_equal_
Set_Speed to LeadVehicle_Not_Detected_ Resume; Input signal conditions is [(LeadVehicle_Detected == 0) || (DriveVehicle_Speed <= Set_Speed)] - Condition to transit from LeadVehicle_Speed_equal_
Set_Speed to LeadVehicle_Detected_ Resume; Input signal conditions [(DriveVehicle_ Speed < Set_Speed) && (LeadVehicle_Speed > DriveVehicle_Speed) || (Time_Gap >= Set_Gap)] - Condition to transit from LeadVehicle_Speed_equal_
Set_Speed to LeadVehicle_Speed_lessthan_ Set_Speed; Input signals conditions [(LeadVehicle_Speed <Set_Speed) && (LeadVehicle_Speed< DriveVehicle_Speed) || (Time_Gap == 0.75*Set_Gap)]
Signal resolving & Signal Propogating:
For signal resolving right click on subsystem and select the properties and enter the signal name, then select signal name must resolve to simulink signal object
For signal propagating enter the signal name and select the show propagated signal option.
While signal propagation and signal resolving the port name and signal name must be the same. The signal resolving is done at the starting of every signal and propagating is done for continuing signals. This is done by giving properties from the SLDD file to the signals.
Requirement tagging:
We can understand a subsystem, how it works and what are its functionality only when the subsystem is tagged. This can be made by highlighting the heading of the required word document and after that select the requirements and click on the Link to selection in word.
Now we can see that the requirement tagging is done.
I have done requirement tagging for all the requirements.
Model advisor in Simulink:
It is a tool that automatically checks the models for errors using predefined checks. Here we can run the selected checks and know whether there are any errors, warnings, or test pass. Here we are doing only the MAAB(Mathworks Automotive Advisory Board ) checks. To know whether this model is obeying the MAAB guidelines.
For that go to Model Advisor under the modeling tab.
Select all and click ok.
The various tests offered are shown below:
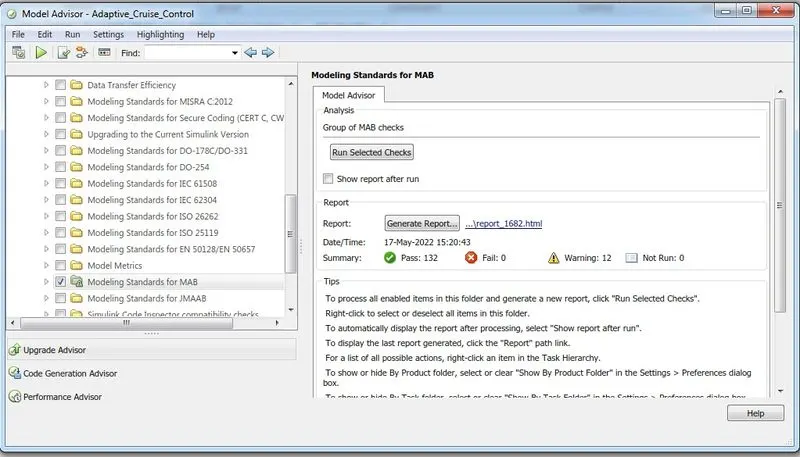
Select only Modeling Standards for MAB for running the checks
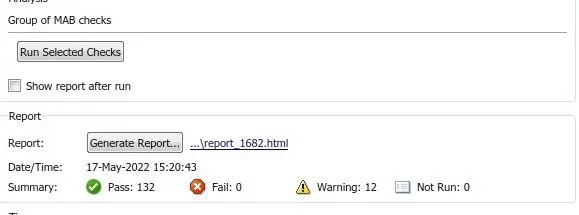
We can see that there is a total of 144checks, in that there are 132 passed and 12 warnings.
Model Advisor report:
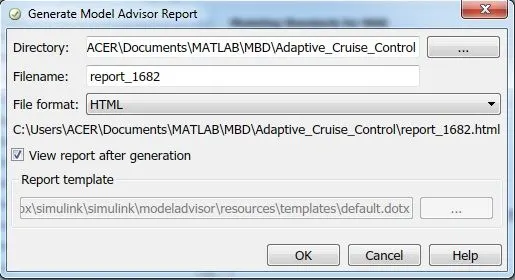
Now we can generate the Model Advisor Report. The model advisor report named 'MAAB_Model_Advisor_Report' is attached in the zip file below. It is in the form of an HTML document.
Code Generation:
Code generation is converting the Simulink model into a C-code. For this select the Embedded Coder option under the Apps.
And click the Build option.
The C-code is generated after a few minutes.
The Generated C-code:
This generated code is pasted in the attachment named 'Adaptive_Cruise_Control.c'.
This C-code is flashed into the hardware after MIL and SIL tests.