Challenge

Project 2

Project 2

INITIAL SCRIPT:
%% Vehicle Parameters
M = 1500; % Vehicle weight [kg]
Cr = 0.015; % Rolling resistance coefficient
Rw = 0.35; % Rolling radius [m]
Cd = 0.33; % Drag coefficient
Af = 2; % Frontal area [m2]
rhoa = 1.225; % Air density [kg/m3]
Vwind = 0; % Wind velocity [kmph]
g = 9.81; % Gravitational acceleration [m/s2]
theta = 0; % Slope [deg]
myu_road_tire = 1; % Coefficient of friction between tire - road interface
%% Powertrain Parameters
FDR = 3.73; % Final Drive Ratio / Diff Ratio
DiffEff = 0.99; % Differential efficiency (assumed independent of operating conditions)
NumGear = 4; % Number of gears in transmission
TransGear = [1:NumGear]; % Transmission Gears
TransRatio = [3.06, 1.62, 1, 0.7]; % Corresponding Transmission ratios
TransEff = 0.90; % Transmission efficiency (assumed independent of operating conditions)
TC_SR = [0, .5, .6, .7, .8, .87, .92, .94, .96, .97, 1]; % Torque Converter Speed Ratio (Matlab default) -> TurbSpd/PumpSpd
TC_TR = [2.232, 1.5462, 1.4058, 1.2746, 1.1528, 1.0732, 1.0192, 1, 1, 1, 1]; % Torque Converter Torque Ratio (Matlab default) -> TurbTrq/PumpTrq
TC_Cf = 1e-4 * [.72558, .66322, .63463, .59042, .51331, .4144, .29287, .22444, .12186, .04386, 0]; % Torque Converter Capacity Factor (Matlab default) -> PumpTrq/PumpSpd^2 [Nm/rpm^2]
load Vehicle_Data/Engine_data_1_9L_Saturn_95kW
load Vehicle_Data/Trans_Shift_map
load Vehicle_Data/EM_Honda_Insight_10kW
load Vehicle_Data/ESS_NiMH6
ESS_init_soc = 0.8;
ESS_soc_max = 0.9;
ESS_soc_min = 0.6;
%% Driver Parameters
Kp = 10; % P gain for driver PI model
Ki = 1; % I gain for driver PI model
Drive_Cycle_Select = 1; % Drive cycle selection
% Drive cycle values in m/s
if Drive_Cycle_Select == 1
load DriveCycles/UDDS;
elseif Drive_Cycle_Select == 2
load DriveCycles/HWFET;
elseif Drive_Cycle_Select == 3
load DriveCycles/FTP;
elseif Drive_Cycle_Select == 4
load DriveCycles/US06;
elseif Drive_Cycle_Select == 5
load DriveCycles/NEDC;
elseif Drive_Cycle_Select == 6
load DriveCycles/WLTP;
end
time_end = cyc_time(end);
vel_end = cyc_vel(end);
SIMULINK MODEL:
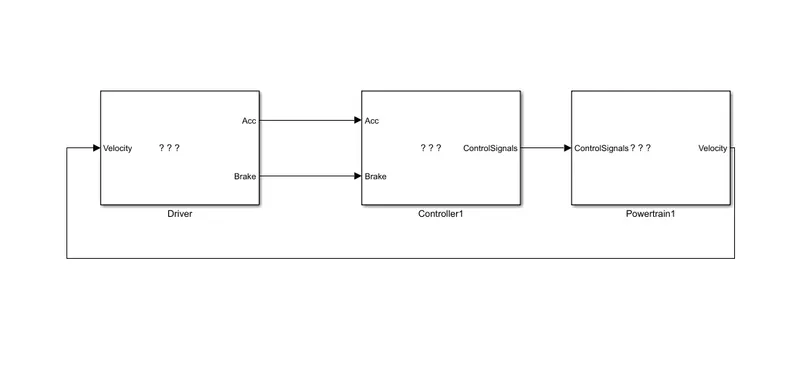
layout

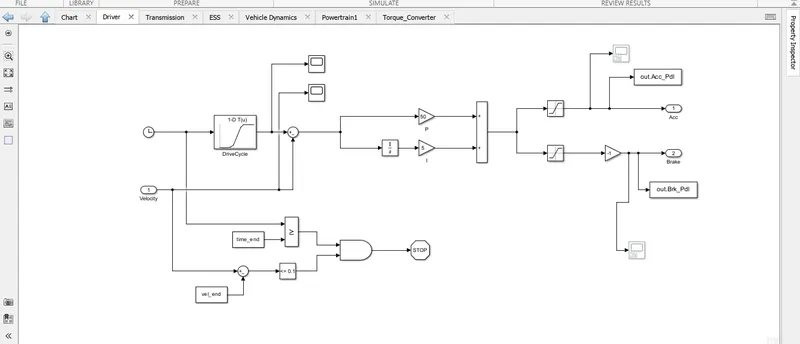
Driver:

It contains a PI controller to get the accelerator and brake pedal signals depending upon the drive cycle requirements.
Controller:
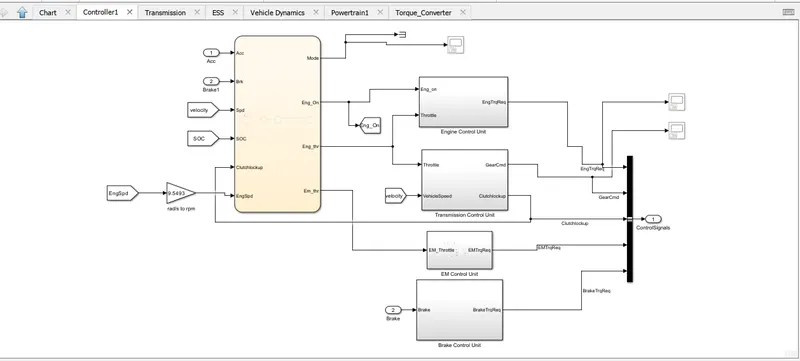
This is the brains of the vehicle

It generates desired engine and motor torque signals, gear signals, which are fed to the powertrain.

State flow – Mode Selection
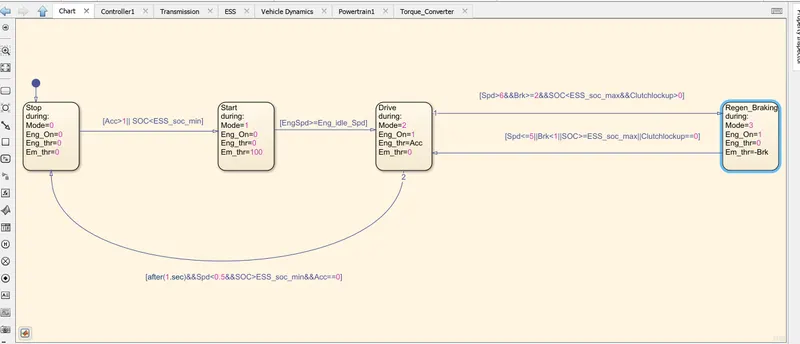
The chart has 4 states, namely Stop, Start, Drive and Regen Braking.

These states are indicated by a mode going from 0 to 3.

Eng_on represents whether the engine is on or off

Eng_thr and EM_thr are for the engine and EM throttle respectively

States

The first state indicates that the vehicle has stopped.

The second state indicates starting phase which is why only EM is used.

The third state is the driving state where the engine is on and the EM is off

The fourth state indicates regenerative braking where the engine throttle is o and the EM throttle is equivalent to the brake pedal signal.

Transitions

State 1 – 2

Acc>1 || SOC<SOC_min

For the starting phase if the accelerator signal is more than 1 or if the SOC has fallen below the minimum value

State 2 – 3

Eng_Spd>Eng_idle_spd

Between the starting and driving phase the transitions happens when the engine speed is greater than the engine speed at idle state.

State 3 - 4

Spd>6 && Brk>=2 && SOC<SOC_max ... && ClutchLockup>0

From driving to regenerative braking, if speed and brake signal are above certain values and SOC is less than its max value and the Clutch lock up is more than 0.

State 4 – 3

Spd<=5 || Brk<1 || SOC>=SOC_max ... || ClutchLockup==0

If any of the previous conditions are not met then the vehicle will go from regen braking to the driving state.

State 3-1

after(1,sec) && Spd<0.5 && SOC<SOC_min && Acc==0

Driving and stop condition, transition is indicated by checking the Speed values are below a certain threshold and the SOC value is less than its minimum and the acceleration is 0. This is checked after every second.

Engine Control Unit:
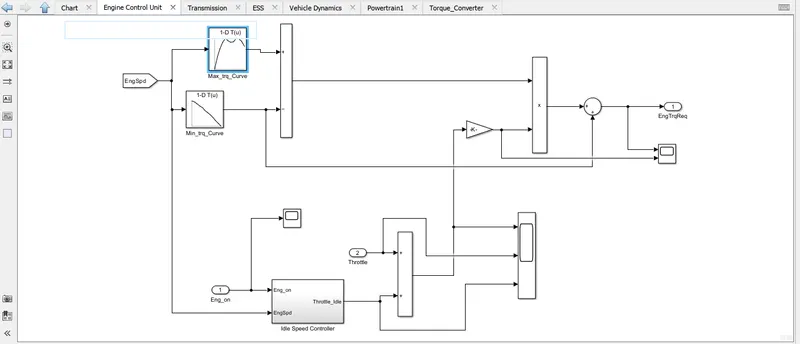
The idle speed controller keeps the speed above the idle speed and make sure that the engine is idling provided that the engine is on.

The accelerator pedal from the driver unit provides the throttle signal as an input.

It has two look up tables for maximum and minimum torque curves for various speed values.

The input to the tables is the engine speed. This input along with the throttle and idle speed controller signals are multiplied together to get the required engine torque.

Transmission control unit:
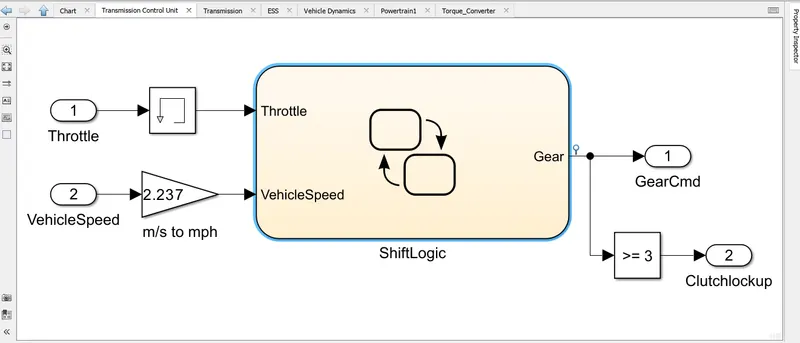
It uses state flow to determine gear shifting.

Velocity and throttle are taken as inputs and the gear used currently is given as an output

SHIFT LOGIC:
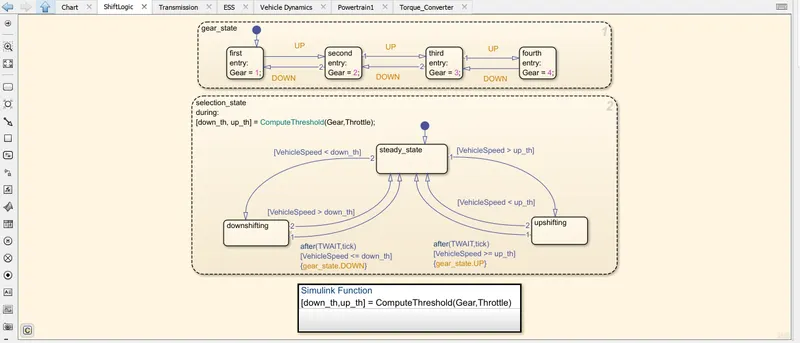
The Gear_state state block decides which gear to shift to using the UP and DOWN decision arrows.

The decision is done by the selection_state state block. Using the ComputeThreshold Simulink function it calculates the values of up_th and down_th which decide whether the gear state should be up or down.

Threshold Function;
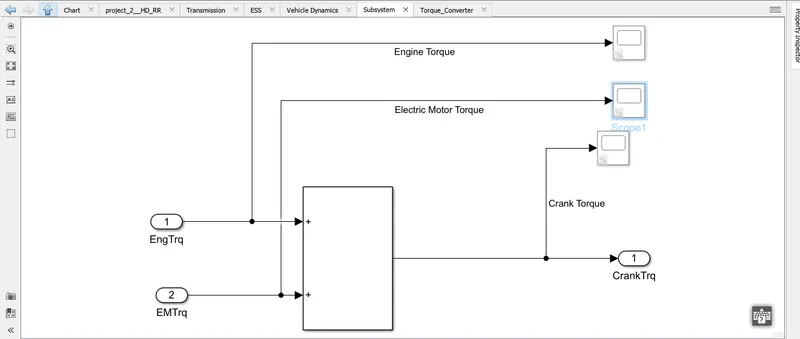
Electric motor control unit:
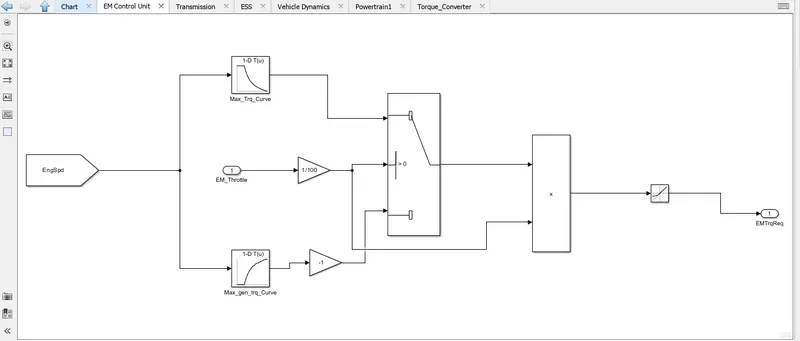
Brake control unit:
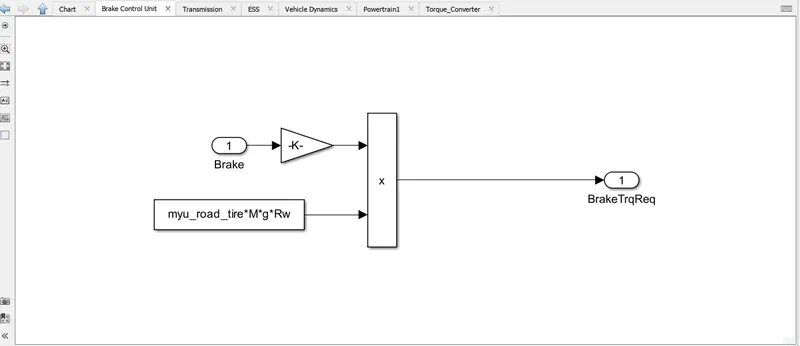
The brake torque is calculated analytically and multiplying it with the brake signal, the magnitude of the brake torque which is required is generated.

The above three signals are connected to a bus, which is transferred to the powertrain block

Power Train model:
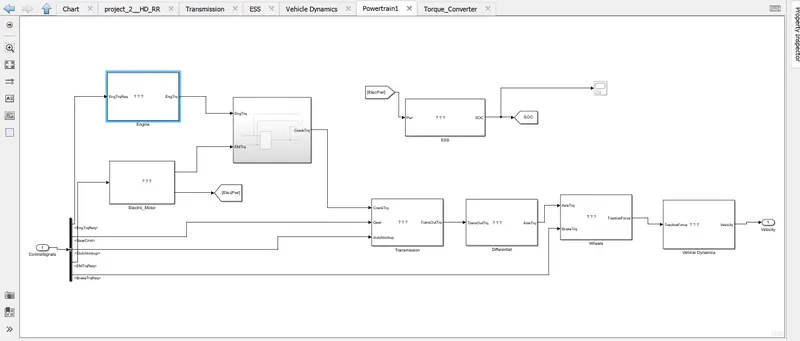
Engine:
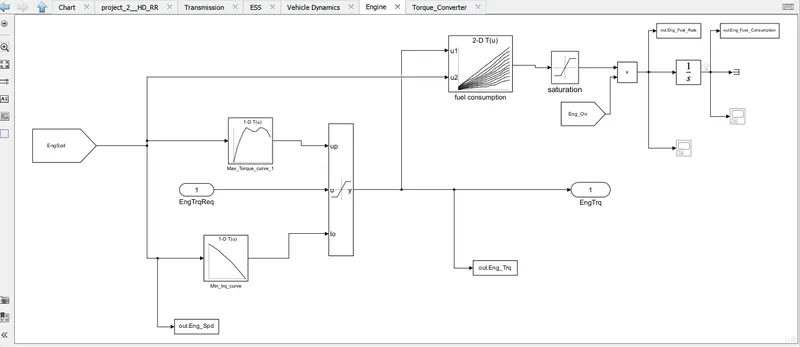
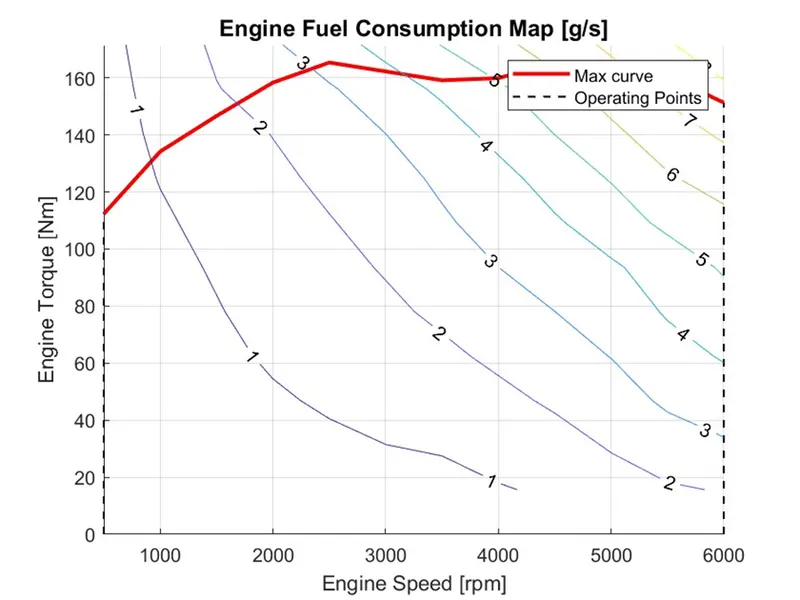
The max and min torque curves act as upper and lower bounds for the engine torque signal which is given to the 2D look up table of fuel consumption. The look up table gives the fuel flow rate and the integrator gives the total fuel consumed until that point.

Electric motor:
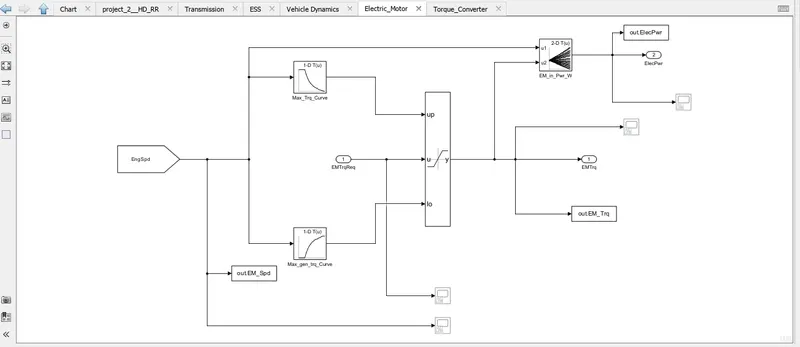
CRank Hub:
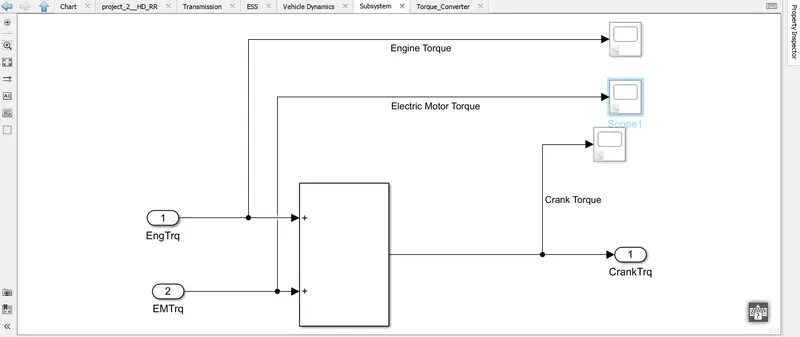
Transmission:
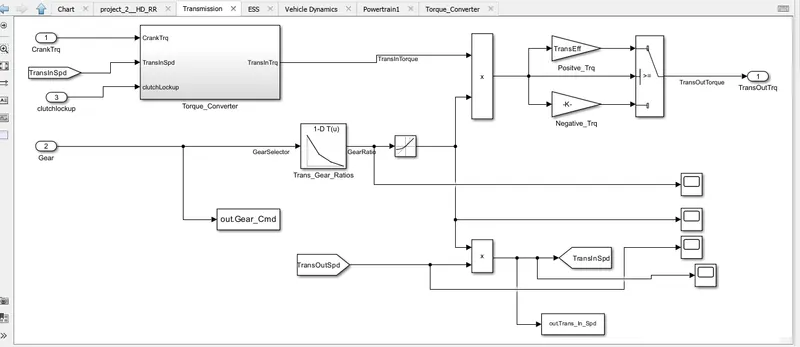
The engine torque, transmission speed and the clutch lock up signal go into the torque converter.

The gear output signals are sent to the transmission gear ratio look up table.

The gear ratio is then multiplied with the transmission torque and transmission efficiency to get the transmission output torque.

The gear ratio is also multiplied with the transmission speed to get the transmission output speed.

Torque converter:
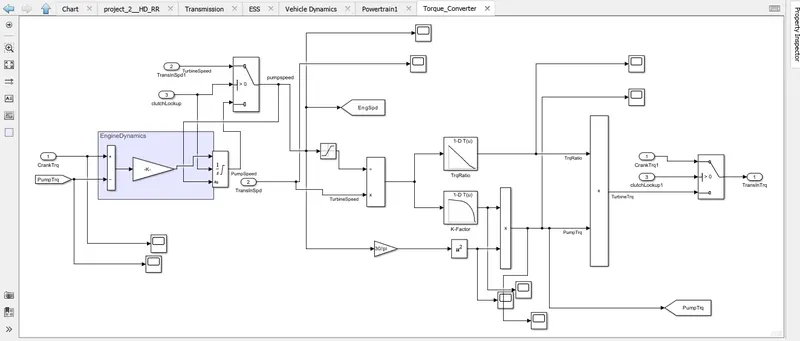
Differential:
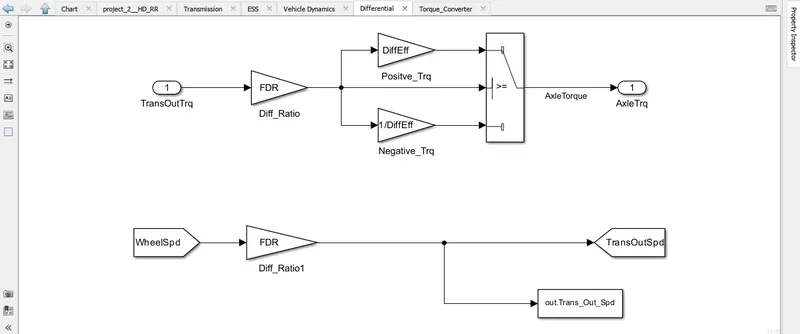
The wheel speed is multiplied by the differential ratio to get the output speed

Transmission torque is further multiplied or divided by the differential efficiency depending on whether the torque is positive or negative respectively.

The output is the axle torque.

Wheels:
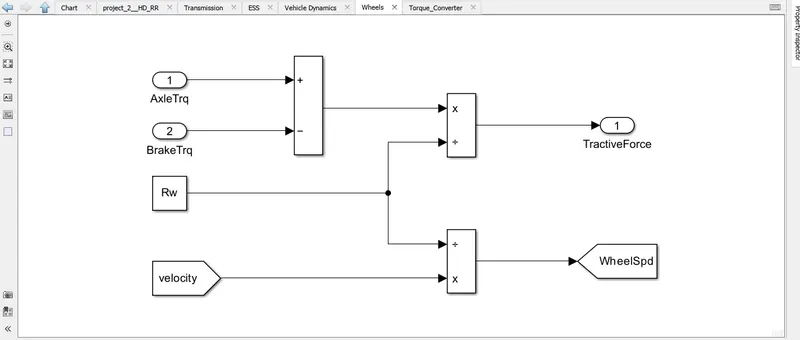
The brake torque is subtracted from the axle torque to get the net torque, which is then divided by the wheel radius to get the tractive force.

The velocity is divided by the wheel radius to get wheel speed.

vehicle dynamics:
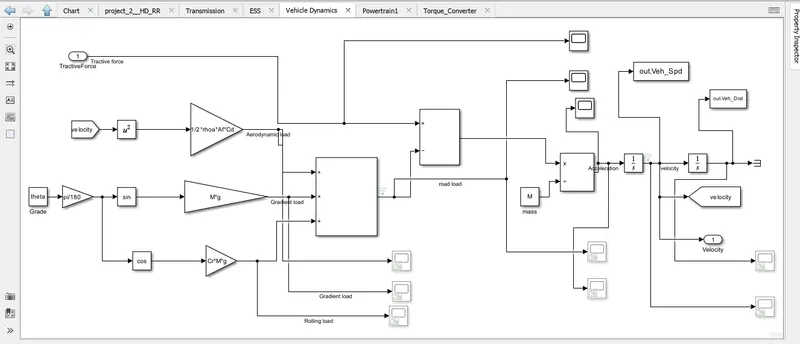
The dynamic equation for calculating the road load is
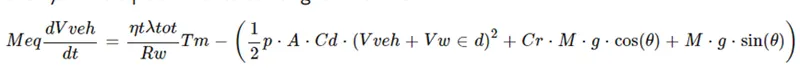
This equation is represented using the various mathematical blocks, which after integrating gives us the velocity.

Estimates Storage System model:
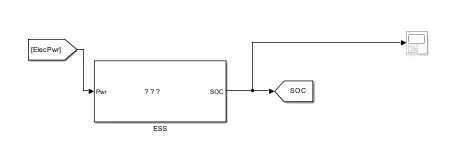
The input to the subsystem is the Electric Power.

The outputs are the SOC and the power.

Subsystem ESS:
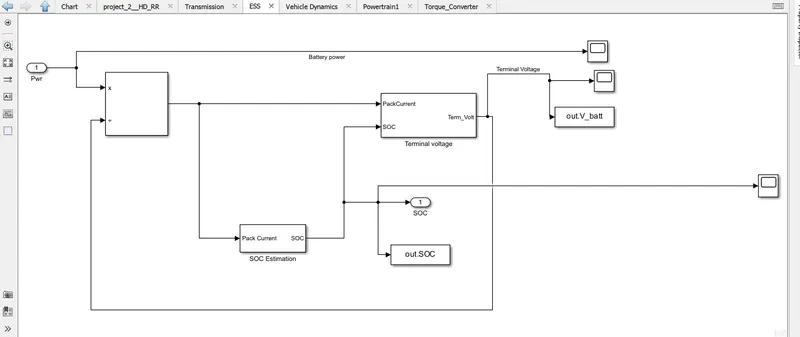
The pack current is calculated by dividing the power by the voltage.

The SOC estimation subsystem is used to calculate the SOC which is used as input to the terminal voltage subsystem.

The battery voltage multiplied by the pack current gives the power.

SOC estimation:
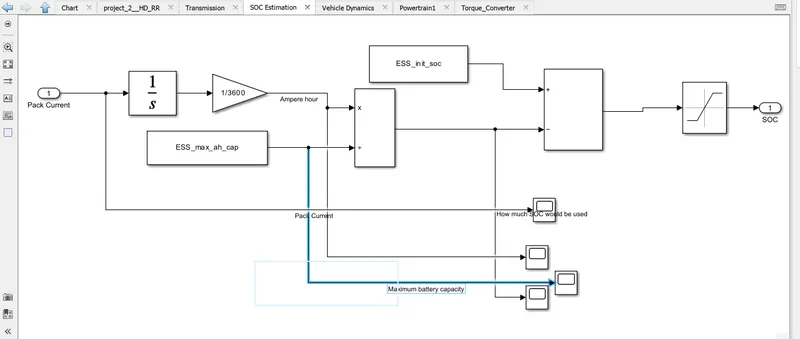
The pack current is integrated to get current in coulomb which is then divided by 3600 to get current in Ampere-hour.

This is divided by the max ampere hour capacity to get the current soc.

This after subtracting from the initial battery soc will give us the SOC value.

terminal voltage:
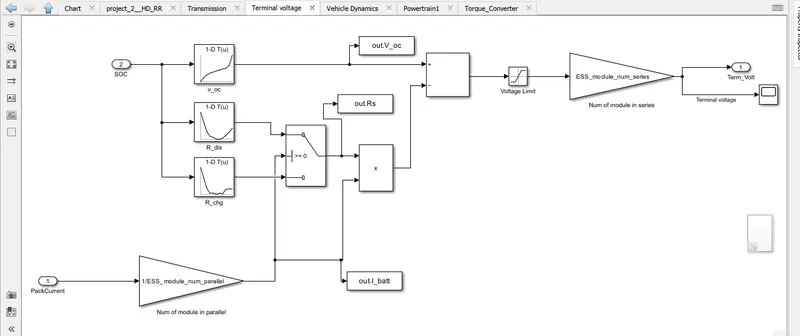
The pack current is divided by the no of parallel modules in the battery packs as the current in parallel is divided while the voltage remains the same. This gives us the current in one cell.

This current is connected to the control port of the switch block. The other two blocks are connected to the charging and discharging resistance look up tables. The criteria being, if the current is greater than zero than cell is discharging otherwise the cell is charging.

The input to the lookup tables is the SOC. The third lookup table gives us the open circuit voltage.

The switch block decides the internal resistance of the cell (R). This is multiplied by the current to get (IR). This when subtracted from the open circuit voltage gives us the battery pack voltage.

This battery pack voltage is divided but the no of modules in series to get the terminal voltage.

Post processin g script:

Acc_Pdl = out.Acc_Pdl; % Accelerator pedal [%]
Brk_Pdl = out.Brk_Pdl; % Brake pedal [%]
Gear_Cmd = out.Gear_Cmd; % Transmission gear
Trans_In_Spd = out.Trans_In_Spd*30/pi; % Transmission input speed [rpm]
Trans_Out_Spd = out.Trans_Out_Spd*30/pi; % Transmission output speed [rpm]
Eng_Trq = out.Eng_Trq.Data(:,1); % Engine brake torque [Nm]
Eng_Fuel_Consump = out.totalfuel.Data(:,1); % Engine fuel consumption [g]
Veh_Dist = out.VehDist.Data(:,1)/1000; % Distance traveled by vehicle [km]
Veh_Spd = out.VehSpd.Data(:,1)*(18/5); % Vehicle speed [kmph]
Eng_Fuel_rate = out.fuelflowrate.Data(:,1); % Engine Fuel Rate %
Wheel_Spd = out.WheelSpd.Data(:,1)*30/pi; % Wheel Speed
EM_Pwr = out.EM_Pwr.Data(:,1); % Electric motor power
EM_Trq = out.EM_Trq.Data(:,1); % Electric motor torque
EM_Spd = (18/5)*out.EM_Spd.Data(:,1); % Electric motor speed [kmph]
Term_volt = out.term_volt.Data(:,1); % Terminal voltage
SOC = out.SOC.Data(:,1); % state of charge
Pack_Current = out.Pack_Current.Data(:,1); % Pack Current
Eng_Spd = out.EngSpd.Data(:,1)*(30/pi); % Engine Speed RPM
%% Data Analysis
Eng_Pwr = Eng_Spd.*Eng_Trq.*((pi/30)/1000); % Engine brake power [kW]
rho_petrol = 0.7197; % Density of petrol [kg/L]
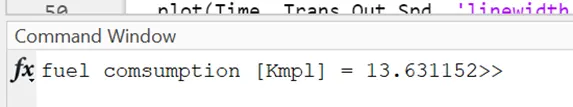
kmpl = Veh_Dist(end)/(Eng_Fuel_Consump(end)/1000/rho_petrol); % Fuel economy [kmpl]
fprintf('fuel comsumption [Kmpl] = %f',kmpl);
%% Plotting vehicle characteristics time trace
figure('Name','transmission IN/OUT speed')
hold on
plot(Time, Trans_In_Spd, 'linewidth', 1, 'Color', 'black');
plot(Time, Trans_Out_Spd, 'linewidth', 1, 'Color', 'red');
plot(Time, Wheel_Spd, 'linewidth', 1, 'Color', 'green');
plot(Time, Eng_Spd, 'linewidth', 1, 'Color', 'blue');
ylabel('Speed [rpm]')
xlim([0, Time(end)]);
ylim([0, 6000]);
legend('Trans Input','Trans Output','Wheel Speed','Engine Speed');
%% Plotting Engine charactesticks
figure('Name','Engine charactesticks');
subplot(2,2,1);
plot(Time, Eng_Trq, 'linewidth', 1, 'Color', 'black');
xlabel('Time [s]');
ylabel('Engine Torque (Nm)');
legend('Engine Torque');
grid on;
subplot(2,2,2);
plot(Time, Eng_Pwr, 'linewidth', 1, 'Color', 'blue');
xlabel('Time [s]');
ylabel('Engine Power (kW)');
legend('Engine Power');
grid on;
subplot(2,2,3);
plot(Time, Eng_Fuel_rate, 'linewidth', 1, 'Color', 'red');
xlabel('Time [s]');
ylabel('Engine Fuel Rate (%)');
legend('Engine Fuel Rate');
subplot(2,2,4);
plot(Time, Eng_Fuel_Consump, 'linewidth', 1, 'Color', 'green');
xlabel('Time [s]');
ylabel('Engine Fuel Consumption');
legend('Engine Fuel Consumption');
%% Plotting Fuel Economy
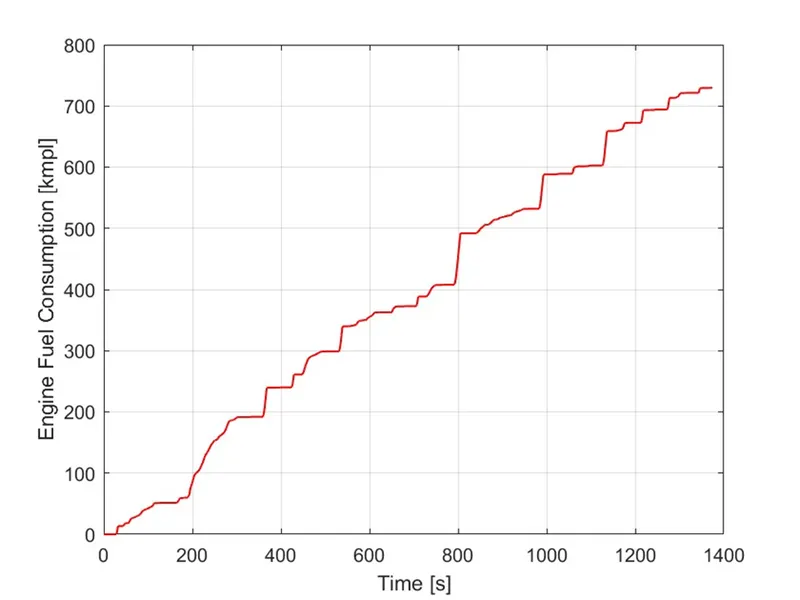
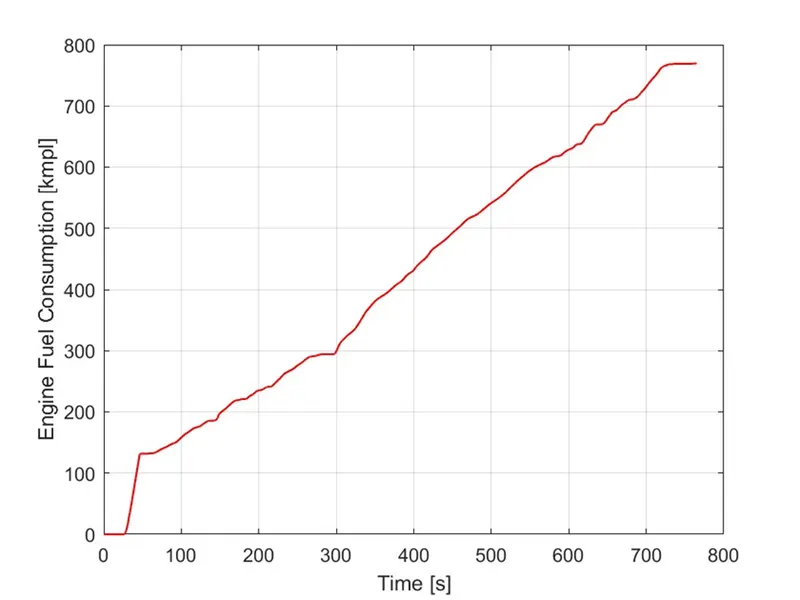
figure('Name','Fuel Economy ');
plot(Time, Eng_Fuel_Consump, 'linewidth', 1, 'Color', 'r');
xlabel('Time [s]');
ylabel('Engine Fuel Consumption [kmpl]');
grid on;
%% Plotting Accelerator brake pedals and gear CMD
figure('Name','Accelerator,brake,gear');
subplot(2,1,1);
hold on;
plot(Time, Acc_Pdl, 'linewidth', 1, 'Color', 'black');
plot(Time, Brk_Pdl, 'linewidth', 1, 'Color', 'blue');
xlabel('Time [s]');
ylabel('Pedal(%)');
legend('Accelearator vs Brake pedal');
grid on;
subplot(2,1,2);
plot(Time(1:height(Gear_Cmd)),Gear_Cmd, 'linewidth', 1, 'Color', 'blue');
xlabel('Time [s]');
ylabel('Gear CMD');
legend('Gear CMD');
grid on;
%% Plotting Gear CMD wrt speed and distance
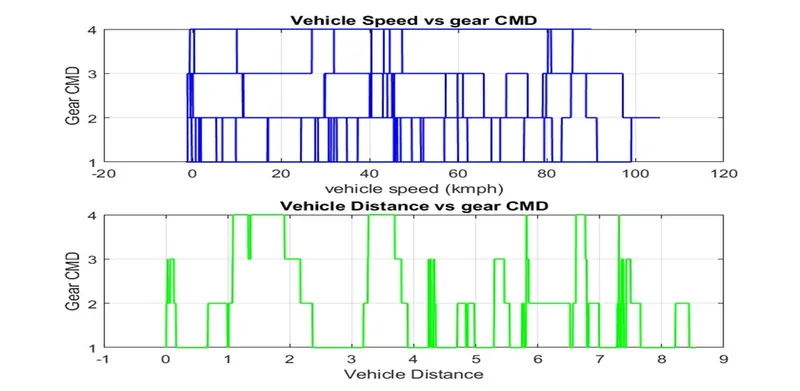
figure('Name','Gear command wrt Vehicle speed and distance');
subplot(2,1,1);
plot(Veh_Spd(1:height(Gear_Cmd)), Gear_Cmd, 'linewidth', 1, 'Color', 'blue');
xlabel('vehicle speed (kmph)');
ylabel('Gear CMD');
title('Vehicle Speed vs gear CMD');
grid on;
subplot(2,1,2);
plot(Veh_Dist(1:height(Gear_Cmd)), Gear_Cmd, 'linewidth', 1, 'Color', 'green');
xlabel('Vehicle Distance');
ylabel('Gear CMD');
title('Vehicle Distance vs gear CMD');
grid on;
%% Plotting engine operating points on engine fuel map
figure('Name','Engine Operating Points');
hold on
grid on
title('Engine Operating Points','fontsize',12);
p1=plot(Eng_map_spd*30/pi,Eng_max_trq,'linewidth',2,'color','r');
p2=line([Eng_map_spd(end)*30/pi Eng_map_spd(end)*30/pi],[0 Eng_max_trq(end)]);
set(p2,'linewidth',1,'linestyle','--','color','k');
p3=line([Eng_map_spd(1)*30/pi Eng_map_spd(1)*30/pi],[0 Eng_max_trq(1)]);
set(p3,'linewidth',1,'linestyle','--','color','k');
[c,h] = contour(Eng_map_spd'*30/pi,Eng_map_trq,Eng_fuel_map');
clabel(c,h);
xlabel('Engine Speed [rpm]');
ylabel('Engine Torque [Nm]');
title('Engine Fuel Consumption Map [g/s]');
legend([p1 p3],{'Max curve','Operating Points'});
axis([Eng_map_spd(1)*30/pi Eng_map_spd(end)*30/pi 0 Eng_map_trq(end)]);
%% Plotting SOC, pack Current and terminal voltage
figure('Name','SOC, Pack Current and Terminal Voltage');
subplot(3,1,1);
plot(Time, Pack_Current, 'linewidth', 1, 'Color', 'blue');
xlabel('Time[s]');
ylabel('Pack Current [A]');
title('Pack Current');
grid on;
subplot(3,1,2);
plot(Time, SOC, 'linewidth', 1, 'Color', 'red');
xlabel('Time[s]');
ylabel('State of Charge [%]');
title('State of Charge');
grid on;
subplot(3,1,3);
plot(Time, Term_volt, 'linewidth', 1, 'Color', 'm');
xlabel('Time[s]');
ylabel('Terminal Voltage [V]');
title('Terminal Voltage');
grid on;
%% Plotting Motor speed, motor torque , motor input power
figure('Name','Motor speed, motor torque , motor input power');
subplot(3,1,1);
plot(Time, EM_Pwr, 'linewidth', 1, 'Color', 'blue');
xlabel('Time [s]');
ylabel('Electric Motor Power [W]');
title('Electric Motor Power');
grid on;
subplot(3,1,2);
plot(Time, EM_Trq, 'linewidth', 1, 'Color', 'red');
xlabel('Time [s]');
ylabel('Electric Motor Torque [Nm]');
title('Electric Motor Torque');
grid on;
subplot(3,1,3);
plot(Time, EM_Spd, 'linewidth', 1, 'Color', 'm');
xlabel('Time [s]');
ylabel('Electric Motor Speed [RPM]');
title('Electric Motor Speed');
grid on;
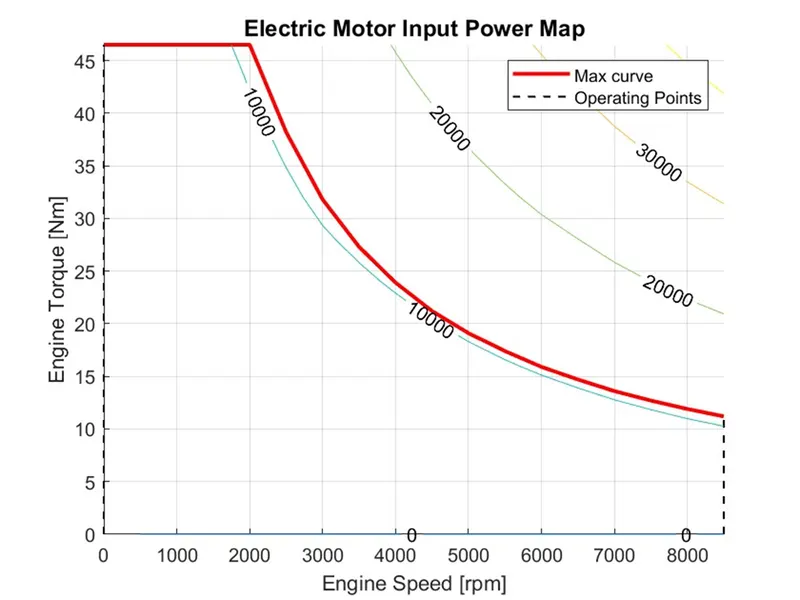
%% Plotting engine operating points on engine fuel map
figure('Name','Electric Motor Operating Points');
hold on
grid on
title('Electric Motor Operating Points','fontsize',12);
p1=plot(EM_map_spd*30/pi,EM_max_trq,'linewidth',2,'color','r');
p2=line([EM_map_spd(end)*30/pi EM_map_spd(end)*30/pi],[0 EM_max_trq(end)]);
set(p2,'linewidth',1,'linestyle','--','color','k');
p3=line([EM_map_spd(1)*30/pi EM_map_spd(1)*30/pi],[0 EM_max_trq(1)]);
set(p3,'linewidth',1,'linestyle','--','color','k');
[c,h] = contour(EM_map_spd'*30/pi,EM_map_trq,EM_inpwr_map');
clabel(c,h);
xlabel('Engine Speed [rpm]');
ylabel('Engine Torque [Nm]');
title('Electric Motor Input Power Map');
legend([p1 p3],{'Max curve','Operating Points'});
axis([EM_map_spd(1)*30/pi EM_map_spd(end)*30/pi 0 EM_map_trq(end)])

Results

Fuel Economy

UDDS

Project 1

Project2
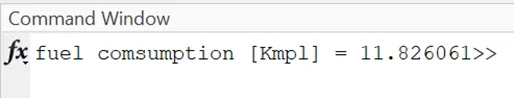
The fuel economy numbers are greater for the conventional vehicle model than the P1 hybrid EV because of the implementation of the Electric motor and the P1 hybrid architecture.

HWFET

Project 1
Project 2
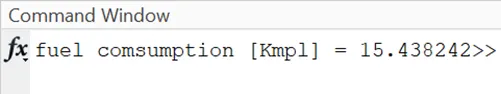
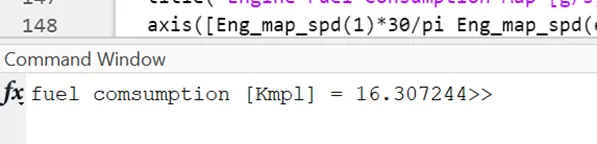
The fuel economy numbers are higher for highway driving as compared to urban city driving because of the lack of traffic which prevent any start stops.

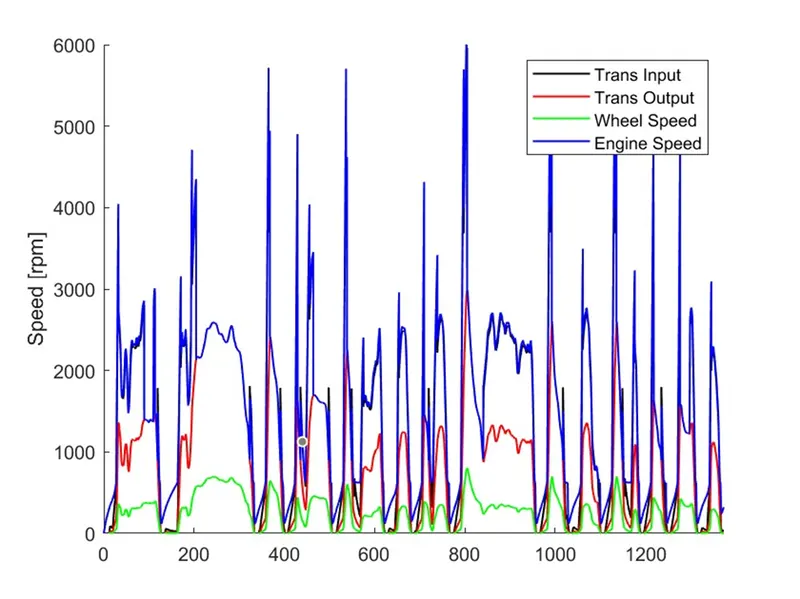
Speeds

UDDS
HWFET
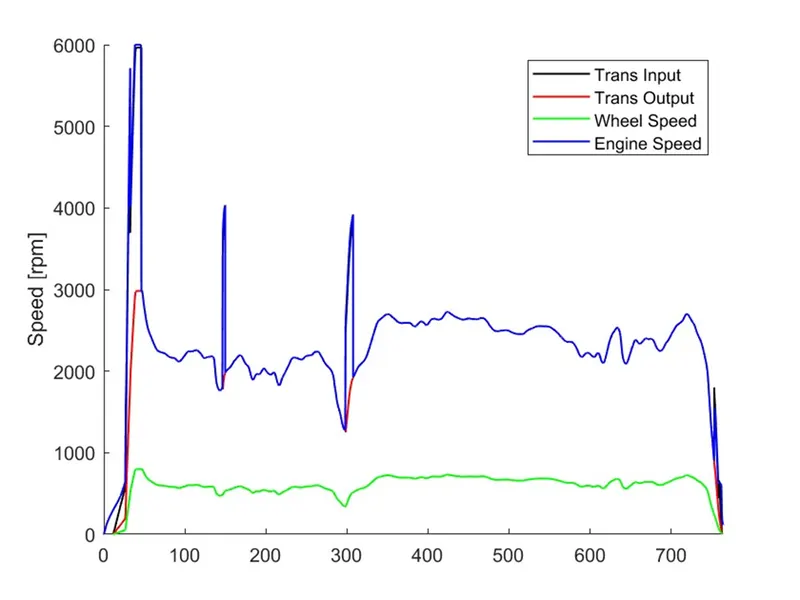
Speeds fluctuate more in urban drive cycle because of traffic intensity which causes the vehicle to start and stop at multiple places.

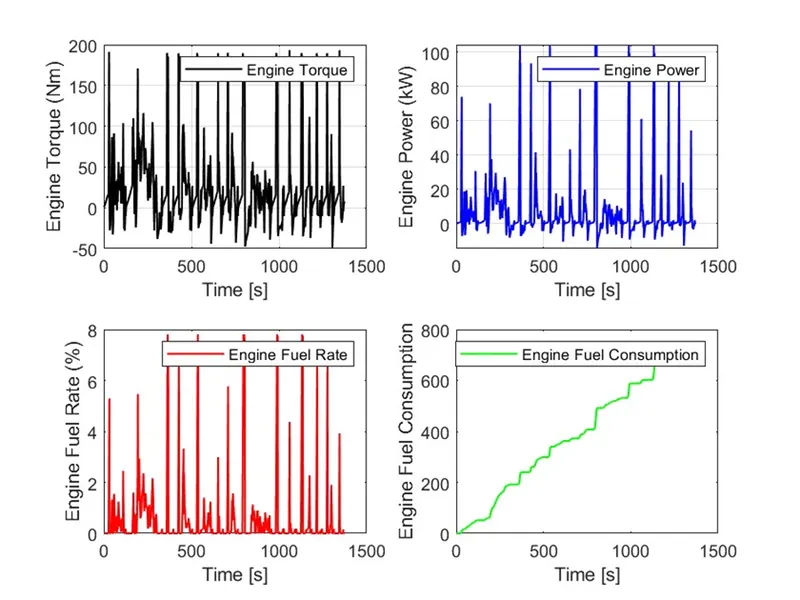
Engine characteristics

UDDS
HWFET
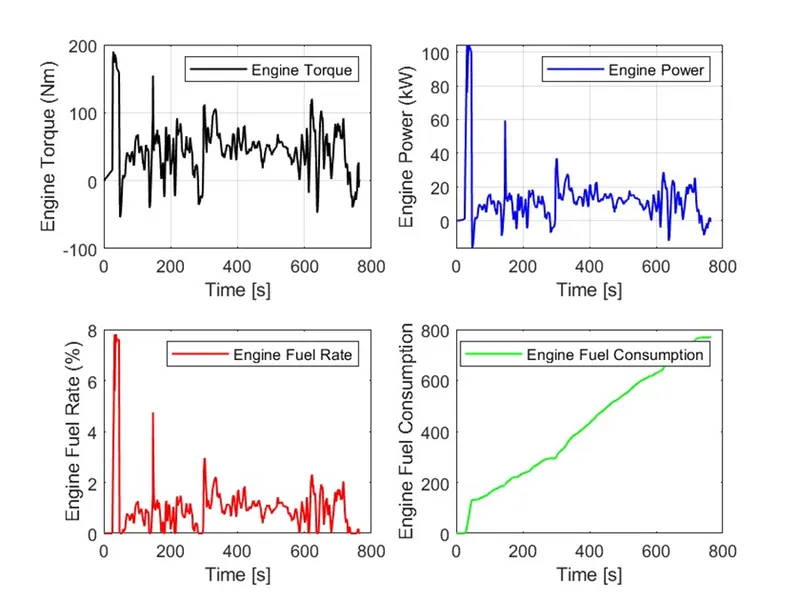
Power and torque for UDDS is more because of the drive cycle start stop nature as compared to HWFET.

Gear characteristics

UDDS
HWFET
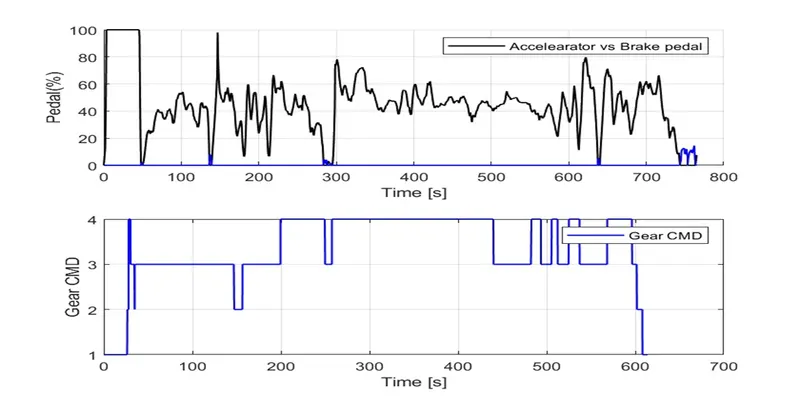
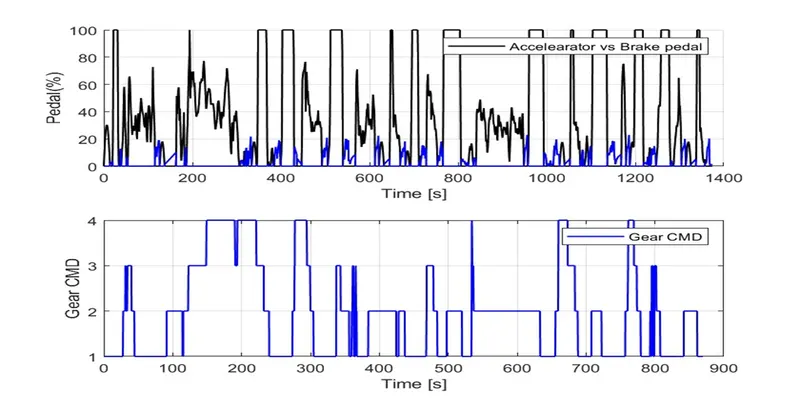
The accelerator and brake pedals fluctuate a lot in UDDS cycle because of frequent start-stops.

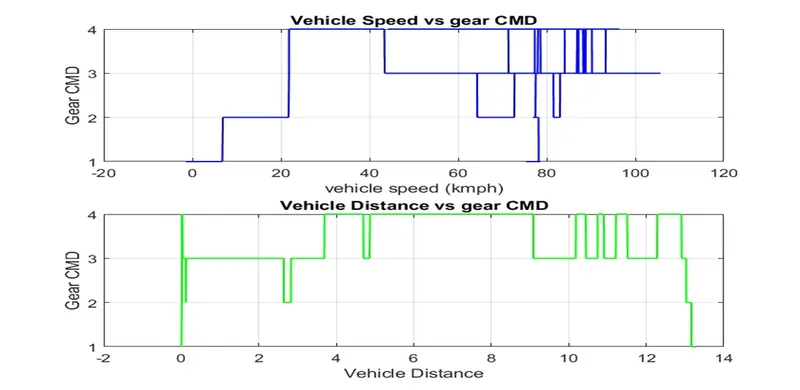
HWFET operates mostly in 3- 4 gear whereas the UDDS varies all over the place.

Engine Operating Points

UDDS
HWFET

Motor Characteristics

UDDS
HWFET
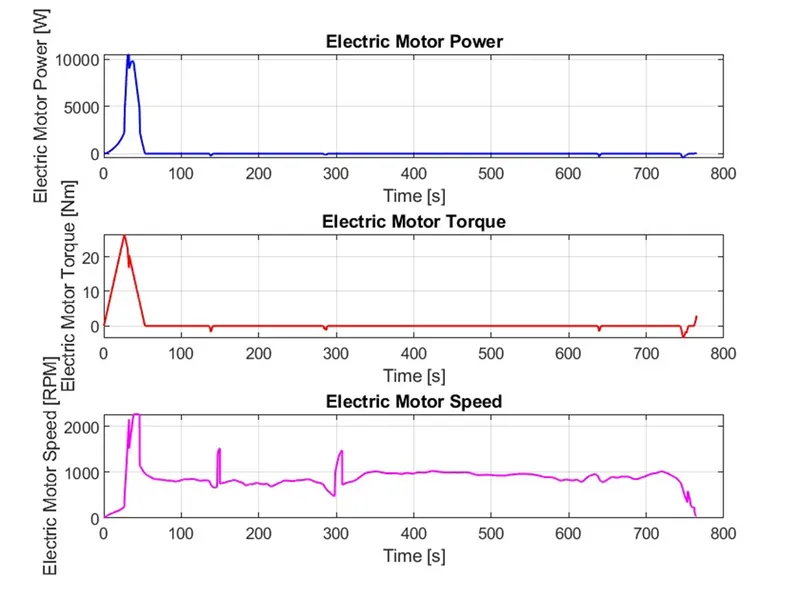
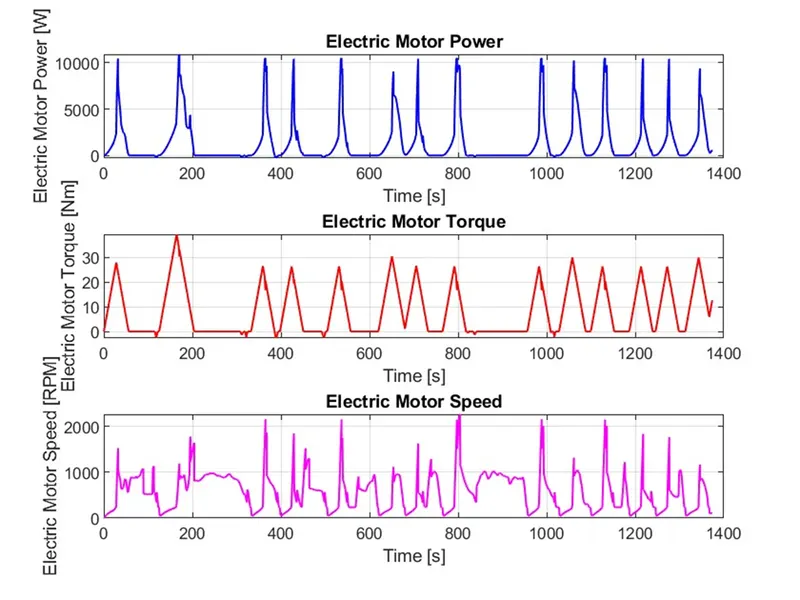
The motor in P1 hybrid is used as engine crank which is why It is used more in urban cycle because of all the start-stops.

The motor is used only at the start of the highway cycle as it never brakes until the end of the cycle.

SOC, current and voltage

UDDS
HWFET
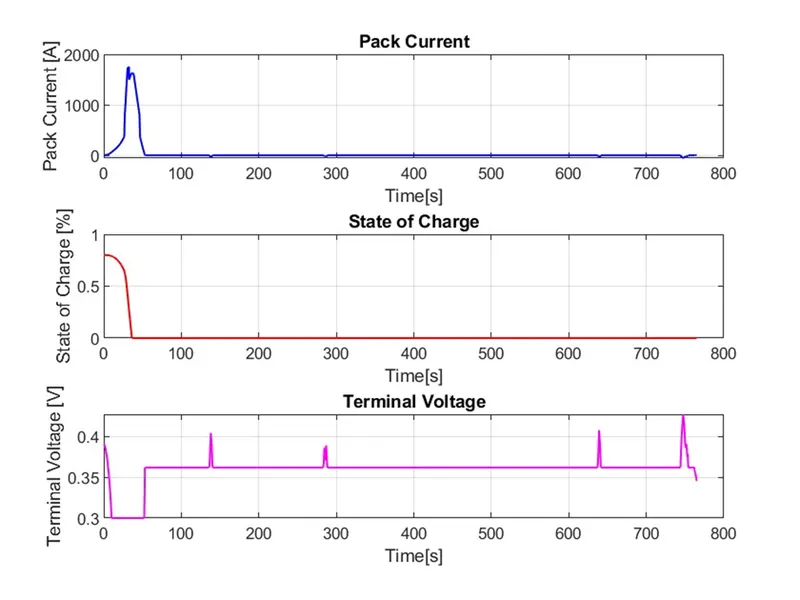
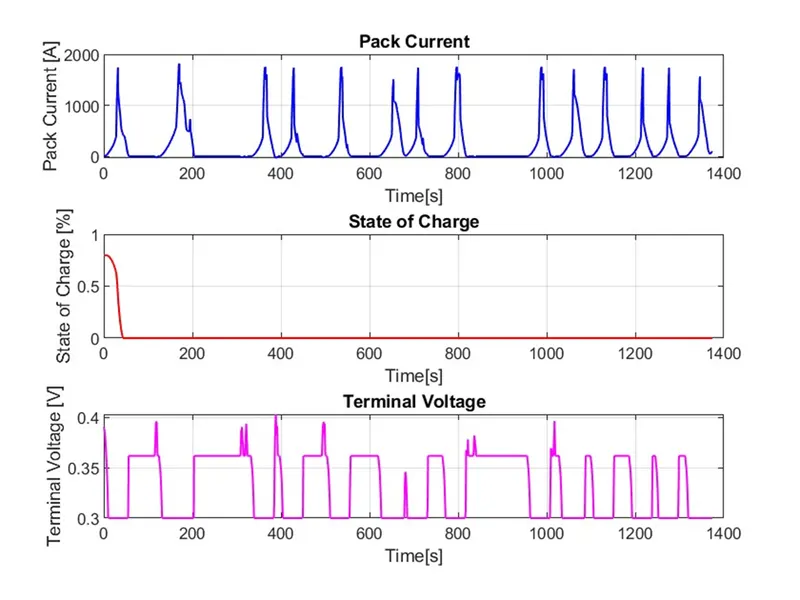
The pack current and voltage fluctuate more in UDDS because of start-stops as the vehicle goes to idle position and battery power is required to start the motor.

This happens once in HWFET at the start as there are no start stops.

Electric Motor Operating Points

UDDS
HWFET
end.

Your portfolio, next

Ship work like this
in your own course.

Talk to a career counsellor

Free 20-minute call. We'll map the right course to where you want to work.

By submitting you agree to our Terms and Privacy Policy.