Project
Aim: To study and analyze the BAJA All-Terrain Vehicle (ATV) using MATLAB Simulink.
Objective: To prepare a technical report explaining the model properties "BAJA ATV Model" & Also to explain the results in 4 different model set-ups that are:
-
Study the Baja ATV model without a dashboard
-
Study the Baja ATV model with a dashboard
-
Study the Baja ATV model using a lookup table without a dashboard
-
Study the Baja ATV model using a lookup table with a dashboard
Introduction:
An all-terrain vehicle (ATV), also known as a quad (cycle), three-wheeler, four-track, four-wheeler, or quadricycle, as defined by the American National Standards Institute (ANSI) is a vehicle that travels on low-pressure tires, with a seat that is straddled by the operator, along with handlebars for steering control. It is designed to handle a wider variety of terrain than most other vehicles. In this project, the type of ATV is a Baja one.
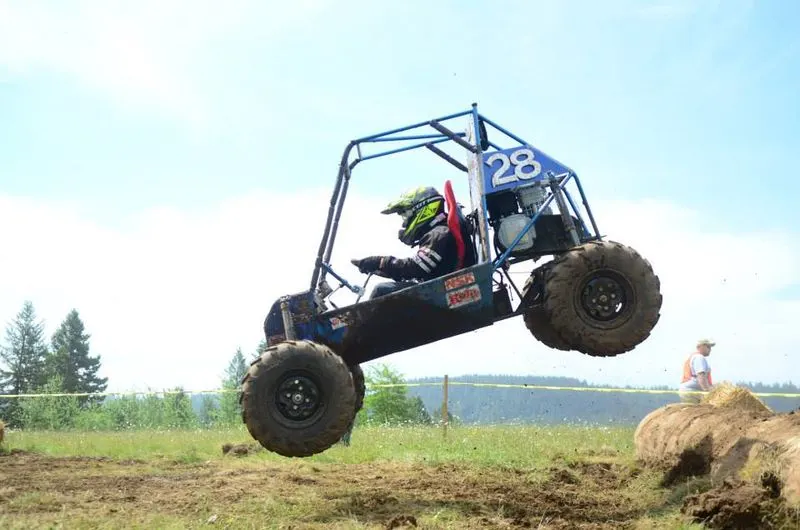
Baja SAE is an intercollegiate design competition run by the Society of Automotive Engineers (SAE). Teams of students from universities all over the world design and build small off-road cars. The cars all have engines of the same specifications. As of 2009, the engine has been an unmodified Briggs & Stratton Intek 20 single-cylinder with a displacement of 300cc and a power output of approximately 10 bhp (7.5 kW).
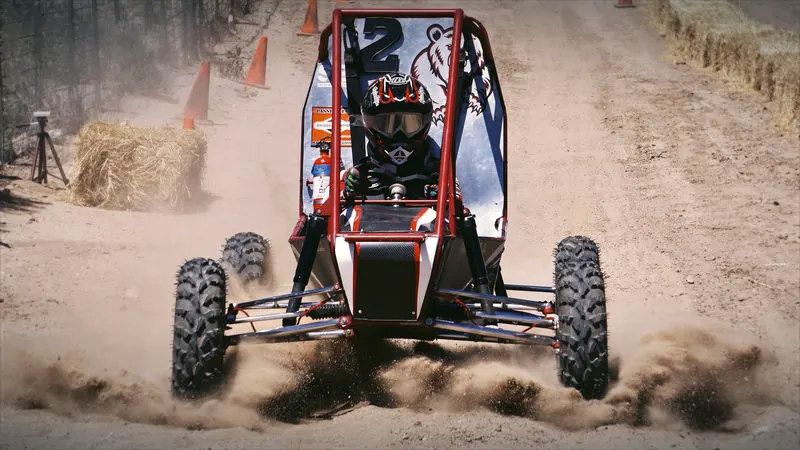
The goal in Baja SAE racing is to design, build and race off-road vehicles that can withstand the harshest elements of rough terrain. The vehicles used in Baja SAE racing are often similar in appearance to dune buggies. There are multiple dynamic events, usually four per event, as well as a single four-hour endurance race. The dynamic events include hill climbs, chain pulls, maneuverability events, rock crawls, and suspension & traction events. The Baja vehicle with CVT transmission is being evaluated and discussed here.
Major and Crucial Components :
(1) CVT: The meaning of the abbreviation CVT is Continuously Variable Transmission, and it is a type of single-speed automatic gearbox. The CVT gearbox has been used in various cars, but you'll usually find it fitted to a small car. Its compact size and simplicity of construction mean it's more cost-effective to use in a small car than a conventional automatic gearbox.
A CVT is an automatic, single-speed, and gearless transmission that can shift through an infinite number of gear ratios. A continuously variable transmission (CVT) is a transmission that operates on an ingenious pulley system that automatically varies the transmission ratio, allowing an infinite variability(theoretically) between highest and lowest gears with no discrete steps or shifts. CVTs provide more useable power, better fuel economy, and a smoother driving experience than traditional transmissions that use gearboxes with fixed numbers of gear sets.
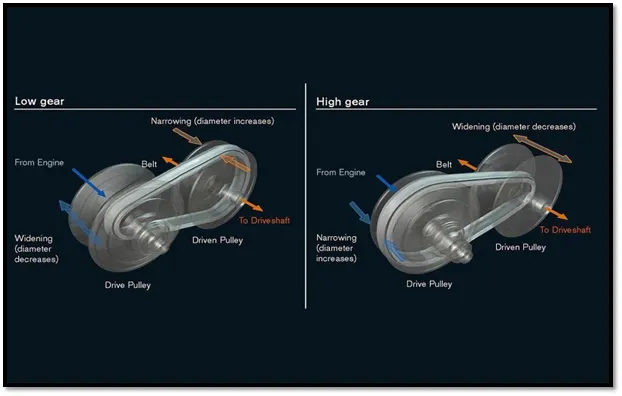
It has a relatively simple arrangement of two cone-shaped pulleys with a V-shaped drive belt connecting them. One pulley is attached to the engine, while the other is joined to the wheels. When you press the accelerator, the engine revs and the cone moves according to the amount of power asked for. The other cone adjusts accordingly so that the drive belt maintains the same tension, and this is what determines how the car accelerates.
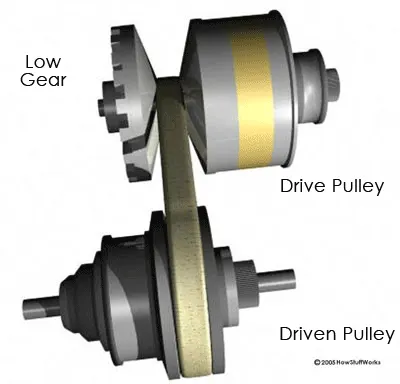
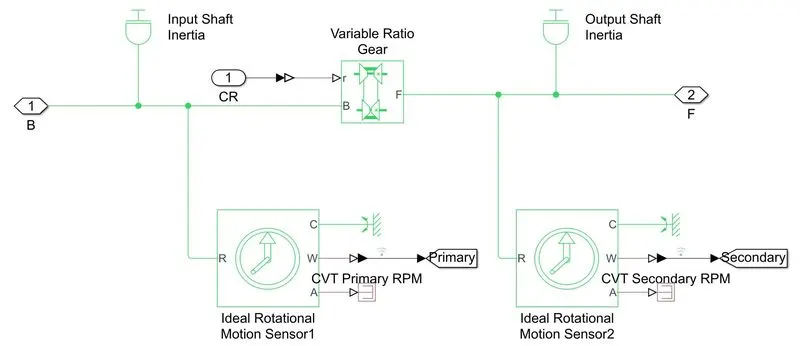
The variable gear arrangements of CVT in this model is represented by the Variable Ratio Gear Block :
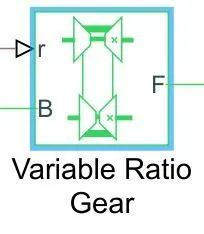
Where,
B – Base Pulley or Drive Pulley,
F – Follower Pulley or Driven Pulley
r – Variable Transmission Ratio (Input).
(2) Vehicle body: A Baja ATV of a Two-axle type vehicle with longitudinal dynamics and motion; has adjustable mass, geometry, and drag properties. The vehicle may have the same or a different number of wheels on each axle. For example, two wheels on the front axle and one wheel on the rear axle. The vehicle wheels are assumed identical in size. The vehicle can also have a center of gravity (CG) that is at or below the plane of travel so that it mitigates the chances of rolling over.
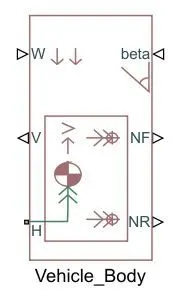
Where, NR – Rear Axle Normal Force (N),
NF – Front Axle Normal Force (N),
Beta – Road Incline Angle (rad),
V – Longitudinal Velocity (m/s),
W – Head Wind Speed (m/s) &
H – Horizontal Motion
(3) Generic Engine: The Generic Engine block represents a general Internal Combustion (IC) Engine which is a type of Compression Ignition (CI-Diesel) or Spark Ignition (SI-Petrol). The speed torque and speed power parameters are provided by the designer.
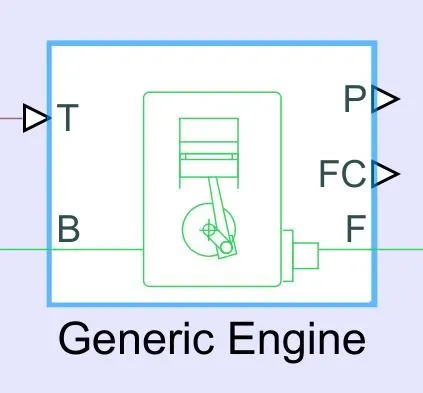
Where,
- B – Rotational Conserving Port representing the Engine Block
- F – Rotational Conserving Port representing the Engine Crankshaft
- T - Physical signal input port specifying the normalized engine throttle level
- P - Physical signal output port reporting the instantaneous engine power, in W
- FC - Physical signal output port reporting the fuel consumption rate, in kg/s
(4)Simple Gear: The simple gear is a combination of a driver and driven gear where the speed is reduced by the gear ratio. The gear ratio is defined as :
Simulink block is :
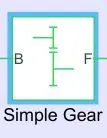
Where, B – Base Gear or Driver Gear & F – Follower Gear or Driven Gear.
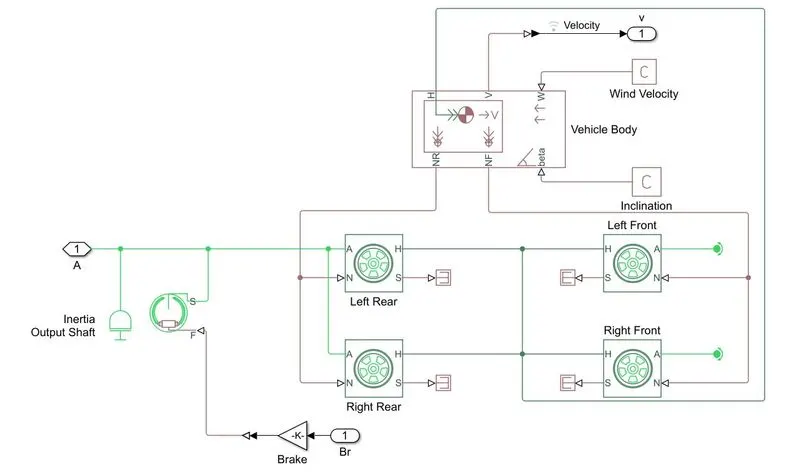
(5) Tires and Brakes: The vehicle body is connected to 4 tires each per axle to move the vehicle according to the power input to the axle.
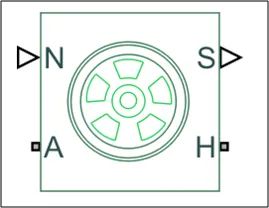
Where, N – Normal Force, S – Tire Slip, A – Axle and
H – Mechanical translational port associated with the wheel hub that transmits then the thrust generated by the tire to the remainder of the vehicle.
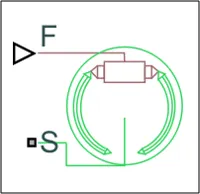 The Double-Shoe Brake block represents a frictional brake with two pivoted rigid shoes that press against a rotating drum, producing the braking action. The rigid shoes sit inside or outside the rotating drum in an opposed configuration. A positive actuating force causes rigid shoes to press against the rotating drum. Viscous and contact friction between the drum and the rigid shoe surfaces cause the rotating drum to decelerate.
Here, S - Rotational conserving port associated with the rotating drum shaft
F - Physical signal input port associated with the applied actuating force.
(I)Study the Baja ATV model without a dashboard:
Simulink Model:
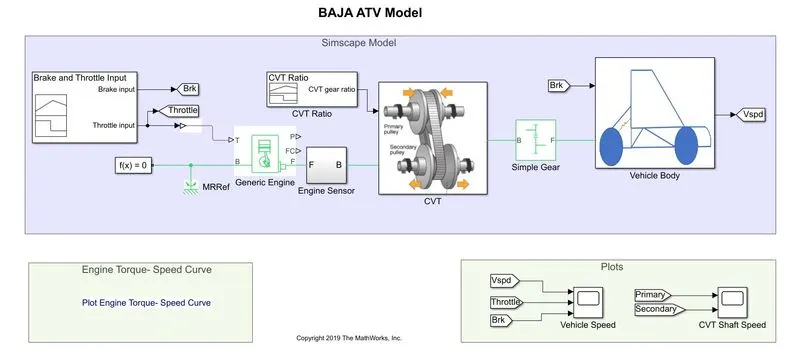
CVT Set-up Block:
Vehicle Body:
Inputs: One signal builder block is used to create signals for brake and throttle and another one is used to create the needed CVT ratio.
Throttle and Brake Input
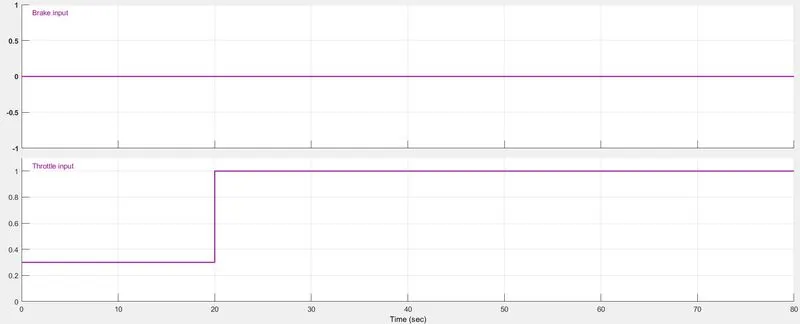
The Brake input remained at zero value for the entire simulation. The initial throttle was given 0.3 value and after 20 sec it was given value 1.
CVT Ratio
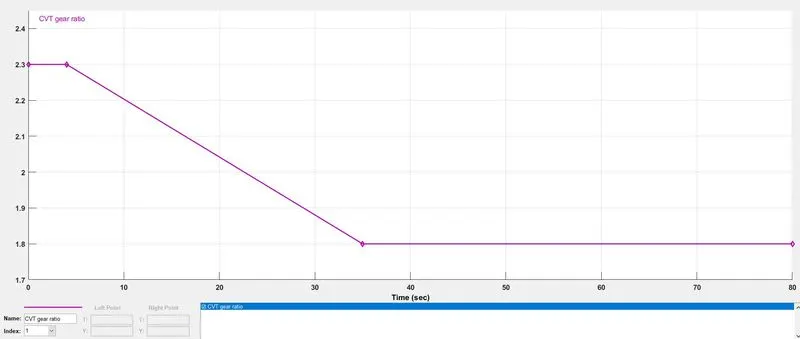
CVT ratio has been varied over a range of value 2.3 to 1.8 values throughout the simulation.
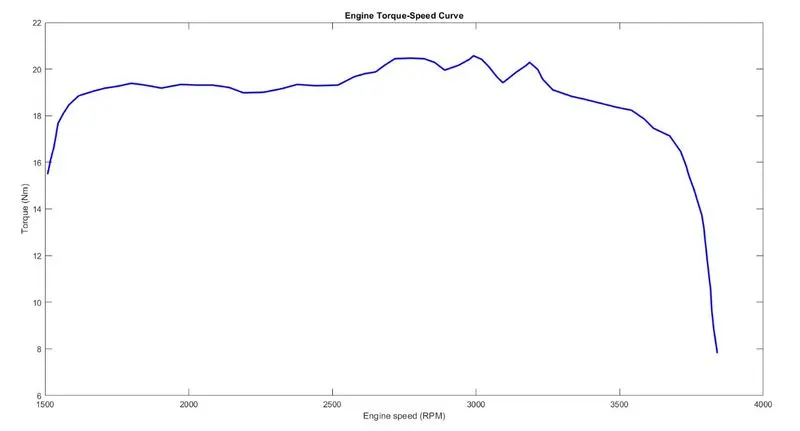
The engine Torque-Speed characteristics can be given by the following graph:
Output Results:
Vehicle Speed variations with Throttle and brake inputs
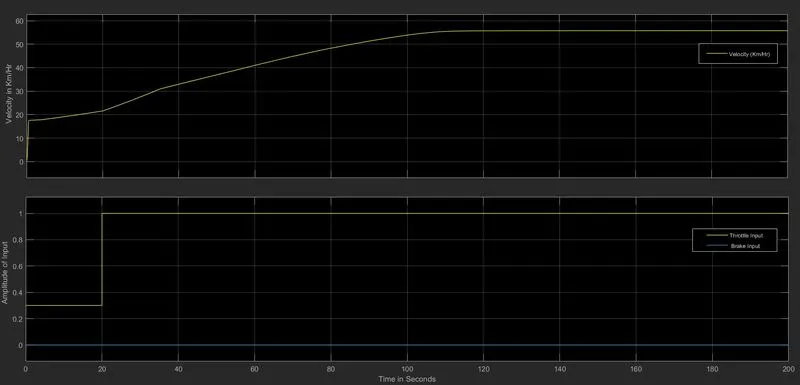
From the graph we can see, that the vehicle attains its maximum speed of 55 Km/Hr at full throttle = 1; at 120th seconds and then the speed remains constant. The brake input value is zero, hence it does not affect velocity.
CVT Primary and Secondary Speed
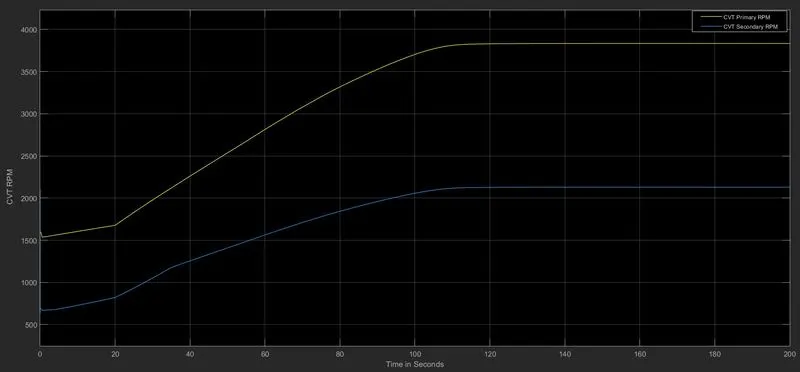
These graphs show the variation in angular velocities of Primary(Input) and Secondary(Output) shafts of the variable gear transmission system. These values differ from the gear ratio i.e. if the gear ratio changes the values of both will also change.
(II)Study the Baja ATV model with a dashboard:
Simulink model:
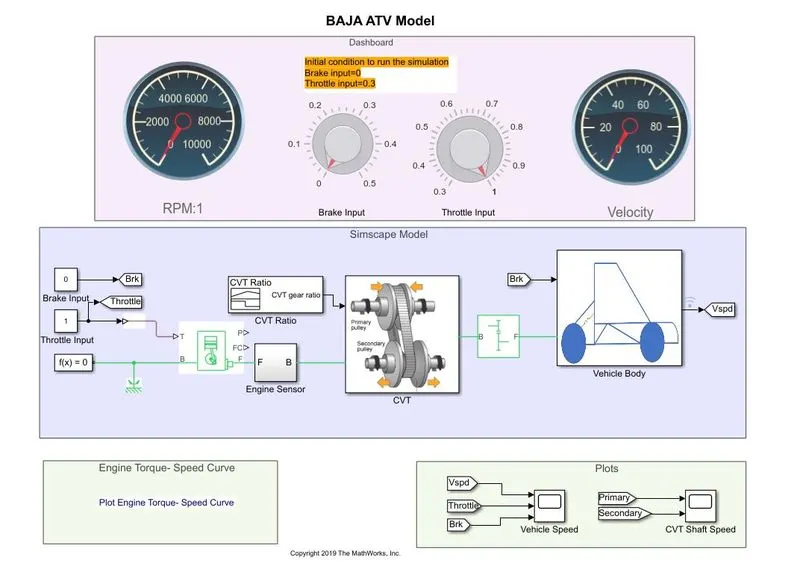
In this model, we have a dashboard that contains knobs to control the Throttle and Brake inputs. In this case, the inputs are not provided using the signal builder. A knob is provided to control both the parameters in real-time for the user. One can vary it as they want and will get the result according to that.
Output Results:
Vehicle Speed variations with Throttle and brake inputs
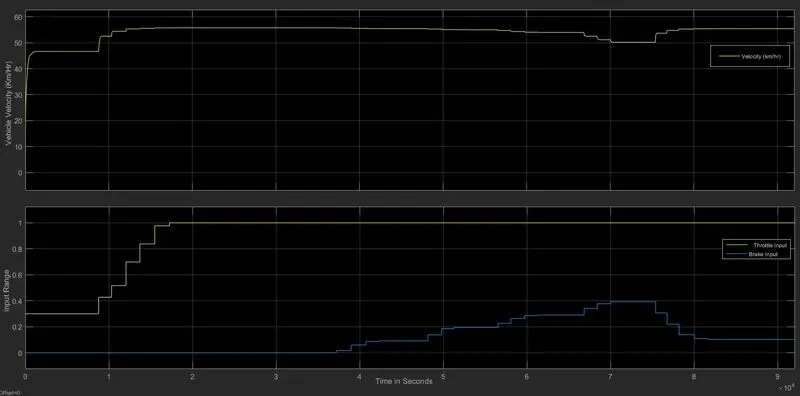
The graph shows that the inputs were given manually to observe the desired variations and the vehicle's speed response for that. The throttle is increased from 0.3 to 1 value in an increasing staircase manner and the brake was applied at different points of time after the throttle gets value 1. Increasing throttle input increases the speed over time and settles it at 55 Km/Hr, But after that instance where the brake was applied, there is a decrease in the vehicle velocity. The brake value of 0.4 was the highest. So, The graph properly justifies vehicle behavior.
CVT Primary and Secondary Speed
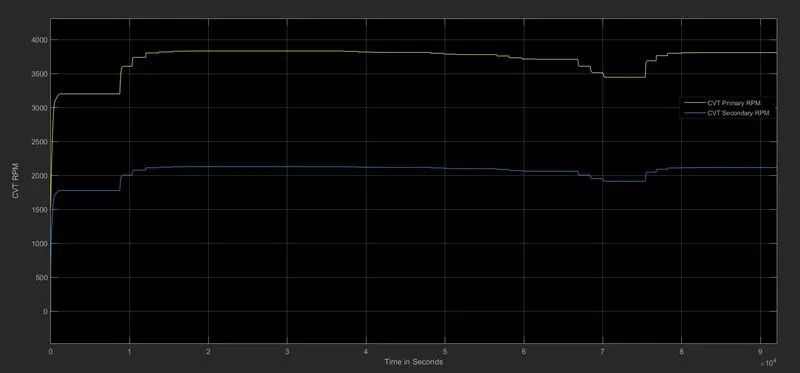
Here we have both the CVT primary and secondary RPMs; The Initial increase and settlement were for throttle value 0.3 when there is no brake applied yet. After that, the behavior is the result of variations in both the inputs. After the time when the throttle is having a constant value of 1, all the variations basically result from the application of the brake. The downsteps are when the brake is applied and the immediate upsteps are the result of releasing the brake.
(III)Study the Baja ATV model using a lookup table without a dashboard:
Simulink model:
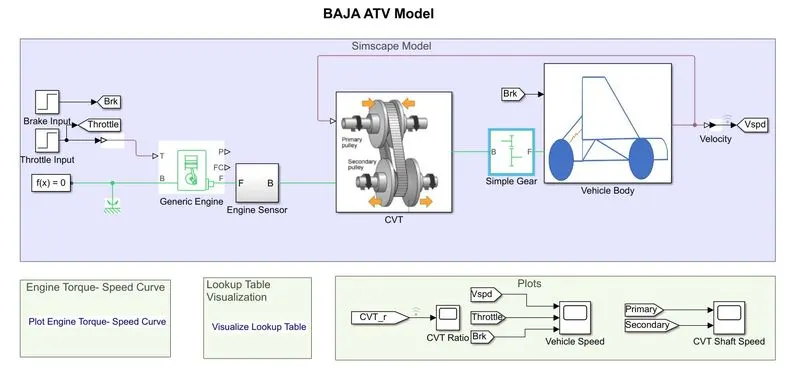
CVT Block:
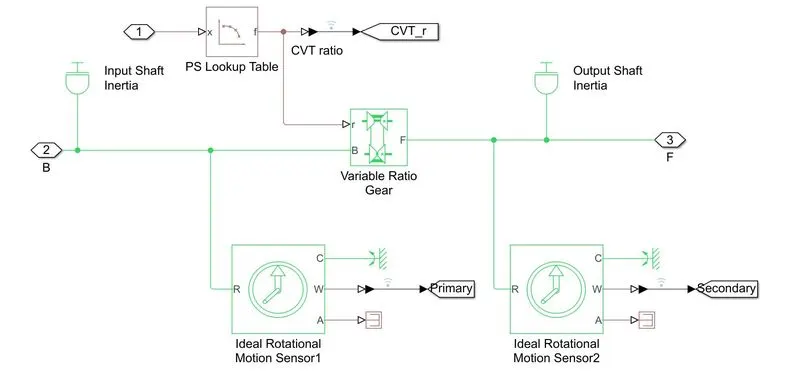
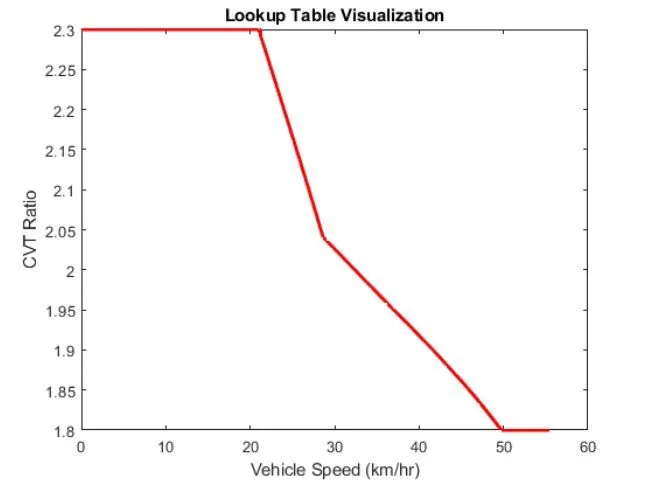
The only difference between this model and the two models before this is how we give the CVT ratio as inputs. The gear ratio input to CVT is provided using a lookup table. The vehicle velocity and shaft rpm outputs are the same as before.
CVT gear ratio:
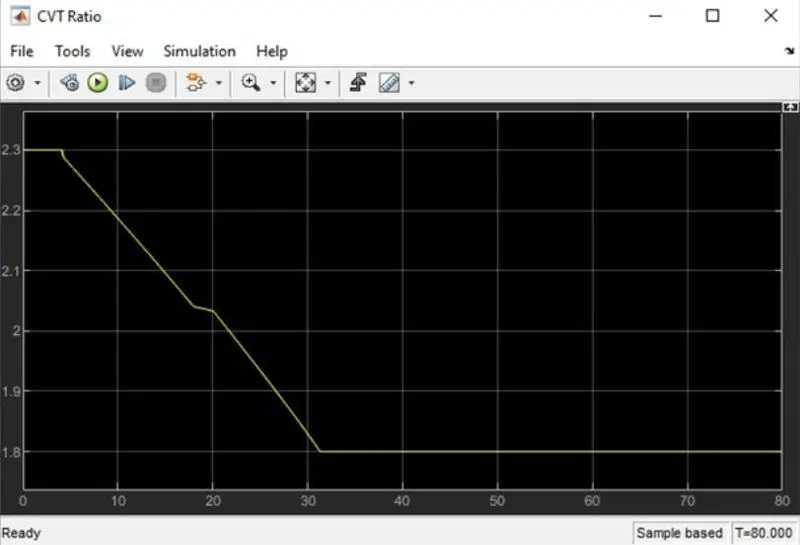
Look-up table visualization:
Output Results:
Vehicle Speed variations with Throttle and brake inputs
CVT shaft RPMs
Both results are the same as that of the first case that is the (I)Study the Baja ATV model without a dashboard. Because the input parameters are the same for both cases.
(IV)Study the Baja ATV model using a lookup table with a dashboard:
Simulink model:
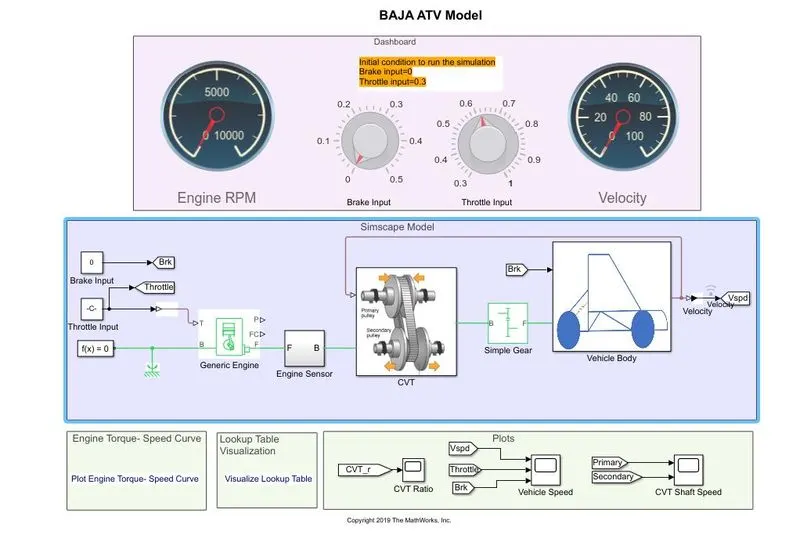
In this model, a dashboard with knobs is used to control both the inputs that are Throttle & Brake.
The visualization of CVT with the lookup table and overall modification of the CVT block is the same as the previous case Simulink model. To make it brief the same results are not being repeated here.
Output Results:
Vehicle Speed variations with Throttle and brake inputs
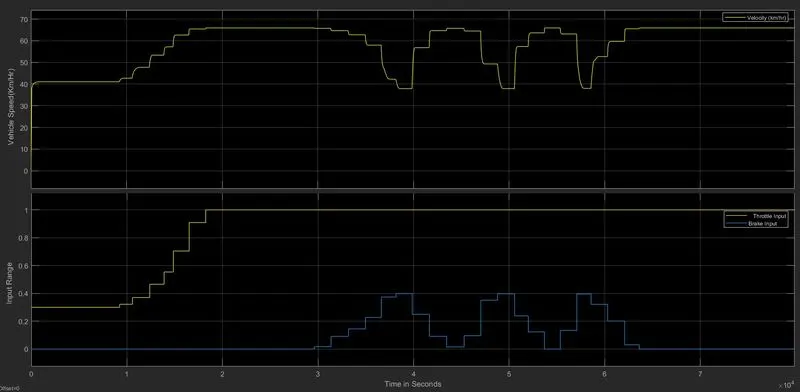
This graph is similar to that of the CVT dashboard case of (II). The variation in Baja vehicle velocity can be observed with the change in both the throttle and brake inputs. With an increase in braking value, the speed of the vehicle decreases. On the other hand, increasing the throttle leads to increased vehicle velocity.
The graph shows that the inputs were given manually to observe the desired variations and the vehicle's speed response for that. The throttle is increased from 0.3 to 1 value in an increasing staircase manner and the brake was applied at different points of time after the throttle gets value 1. Increasing throttle input increases the speed over time, But after that instances where the brake was applied, there is a decrease in the vehicle velocity. So, The graph properly justifies vehicle behavior. The maximum braking value is 0.4 and it hits this value three times in the graph. The highest speed of the Baja Vehicle was 65 Km/Hr.
CVT shaft RPMs
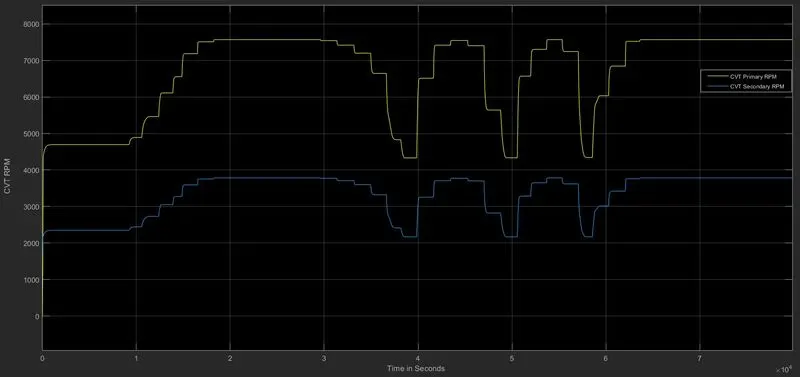
This graph indicates the variation in RPMs of the primary shaft and secondary shafts with variations of input parameters that is the throttle and brake. Here we have both the CVT primary and secondary RPMs; The Initial increase and settlement were for throttle value 0.3 when there is no brake applied yet. After that, the behavior is the result of variations in both the inputs. After the time when the throttle is having a constant value of 1, all the variations basically result from the application of the brake. The downsteps are when the brake is applied and the immediate upsteps are the result of releasing the brake. It shows basically the similar behavior as the case(II) in this project.
CONCLUSION:
Thus we have successfully analyzed 4 different models of BAJA ATV WITH CVT and recorded the outputs that are the Vehicle velocity & CVT shaft rpm, for different variations in input throttle and brake.
References:
- https://in.mathworks.com/videos/modeling-a-vehicle-with-continuously-variable-transmission-1554467867519.html?fbclid=IwAR2NqnIVVLAhrP3TNWoV1WkkmZd0UofkkTIu5fGI2XPwd5T7w7x4QF6oeiU
- https://in.mathworks.com/help/physmod/sdl/ref/doubleshoebrake.html#:~:text=Double%2Dshoe%20brakes%20provide%20high,brake%20geometry%20and%20friction%20parameters.
- https://in.mathworks.com/help/physmod/sdl/ref/vehiclebody.html
- https://in.mathworks.com/help/physmod/sdl/ref/genericengine.html#:~:text=Description,specifies%20the%20normalized%20engine%20torque.
- https://bajasaeindia.org/downloads.html
- https://images.app.goo.gl/oZWEAok88LF7cu7N6
- https://images.app.goo.gl/DDrC9BzCa2mLpwSV9
- https://en.wikipedia.org/wiki/Baja_SAE