Project
AIM:
To Carry out a system-level simulation of an all-terrain vehicle.
which the model is given with a download link.
download it and open it in the simulink environment.
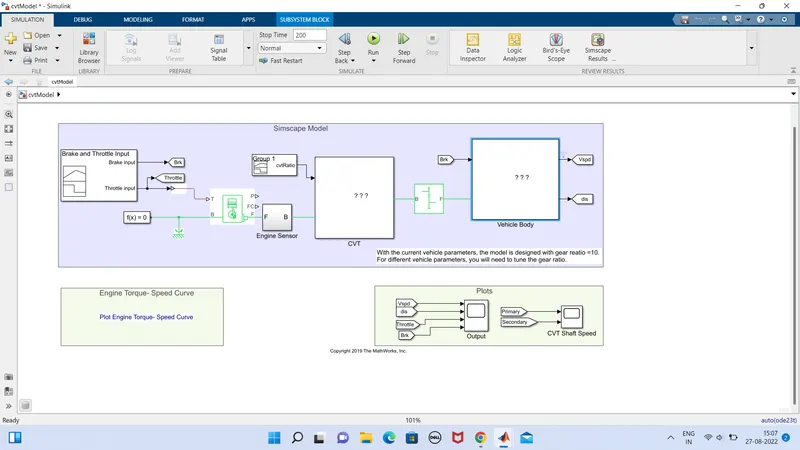
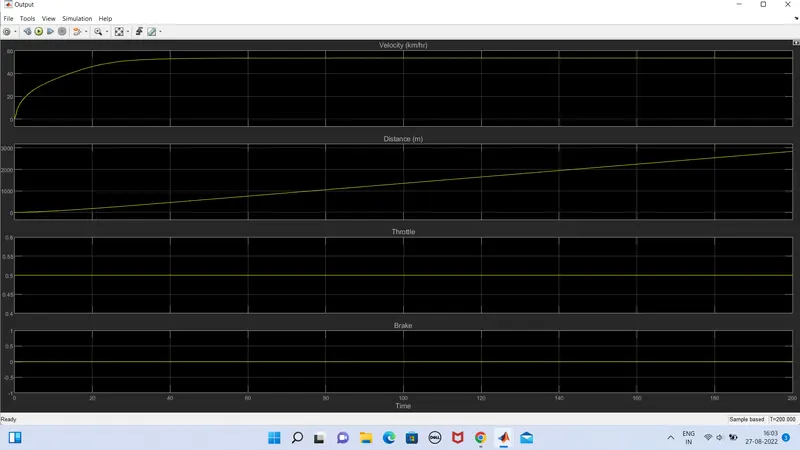
we can check the result by simply running,we can do that.
this is the scope result of velocity,distance,throat,brake of the atv.
we can check the output result of cvt (controlled variable transmission)shaft speed of the atv;
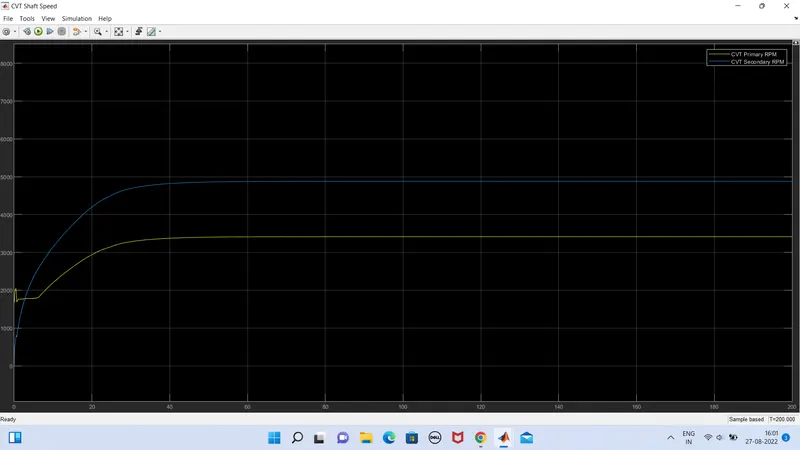
hence in this given default model the result are shown above.
now we can see the each parts or the each models and subsystems in details.
first a signal builder is provided and the inputs variables are provided as throttle and brake.
brake is initially at zero that means that the vehicle is moving without any breaking.
the throttle os about 0.5 of value that means 0.5 per sec.
brakes and throttle are outted as into and it is shown output as from.
signal builder input is connected to generic engine with simulink to ps convertor which is a simscape model.
generic engine is connected to a engine sensor.
and also to solver configuration and reference.
then it is connected to a cvt (continously variable transmission) which is a subsystem.
cvt subsystem shown here,
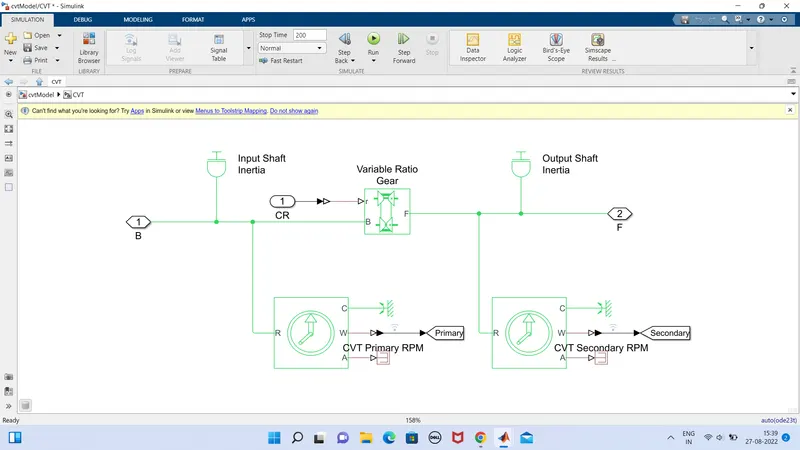
it contains
*input shaft inertia
*output shaft inertia
*variable gear ratio
*primary rpm sensor
*secondary rpm sensor
sensor outputs are 'into' made and is outted as 'from' to a scope to see the results.
then the cvt is connect to a simple gear.
then it is to the the vehicle body.
vehicle boady is a subsystem which is shown below.
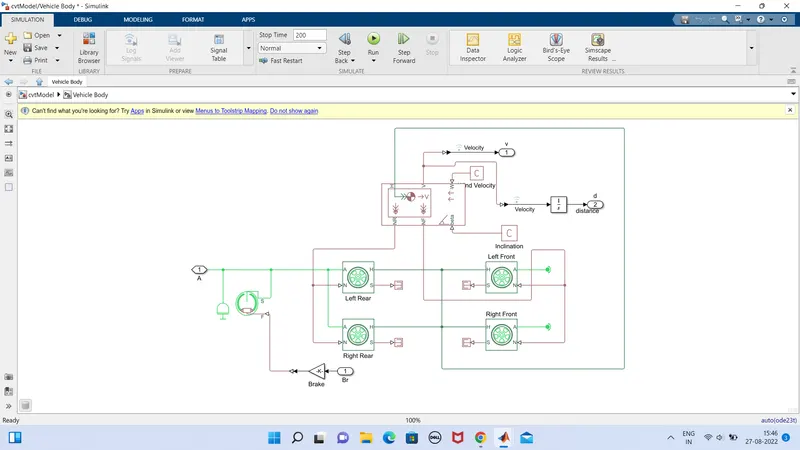
it contains four wheels of the atv and the inclimnation that the vehicle can go without fails and the velocity at each conditions are provided.
this contains mechanical and electrical models as well.
the distance is also measured by the integration of the velocity.
all the parameters corresponds to the vehicle motion are plotted .
so now the vehicle is moving at a constant speed wwe can change it by changing the parameters of speed.
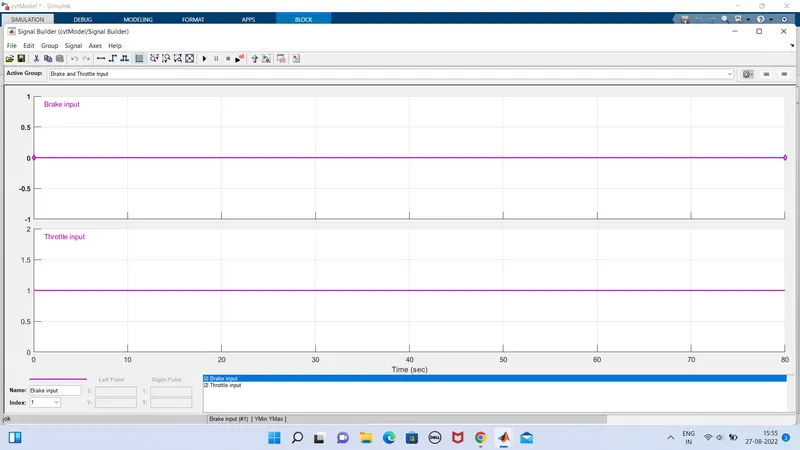
we increased the input throttle to 1 and breakings remains constant(=0).
this how the signal builder looks,
now we can see whats happened to the result;
this is the velocity,throttle,brake,distance output plot changes,
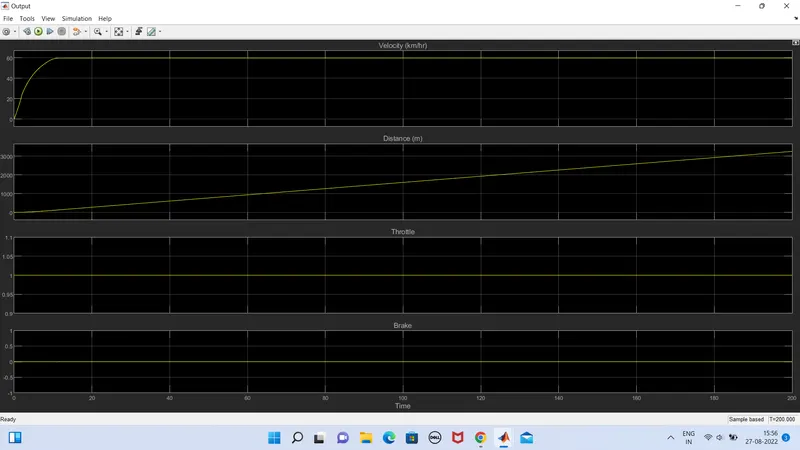
when compared to the earlier state the parameters values got increased .
and the output of cvt shaft speed outputs is ,
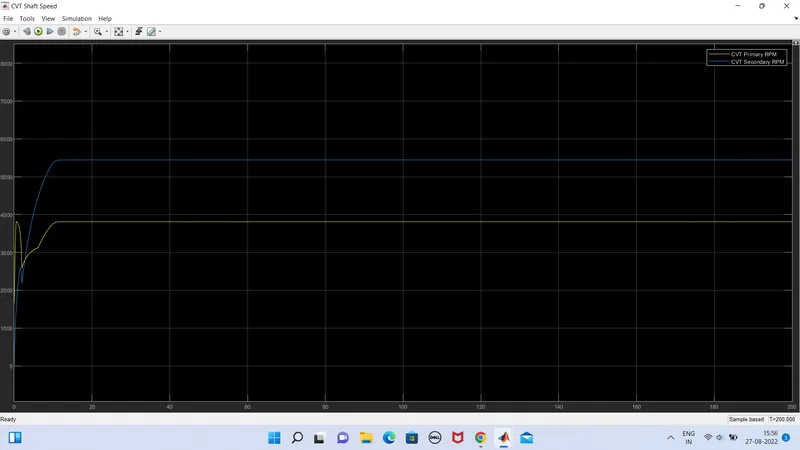
the rpm got increased. and remains constant at a time of 16 sec.
we can see refer some all terain vehicle (atv):
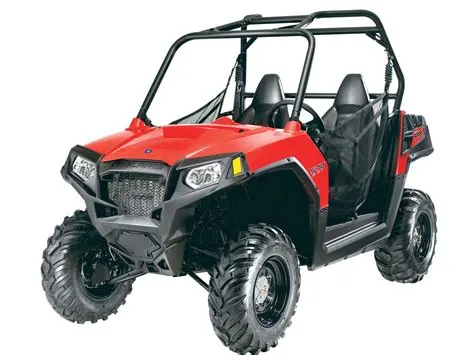
this atv shown in figure have 4 wheels and some other have more than 4 wheels.
conclution:
so we studied the given preprogrammed simulink object of a all terain vehicle (atv) and discussed all the states and all other parameters.and also we applied some different input values and studied the result of variaration.