Project 1 - Wiper control system and Vehicle speed calculation for ABS using Wheel Speed sensor
- Wiper control system
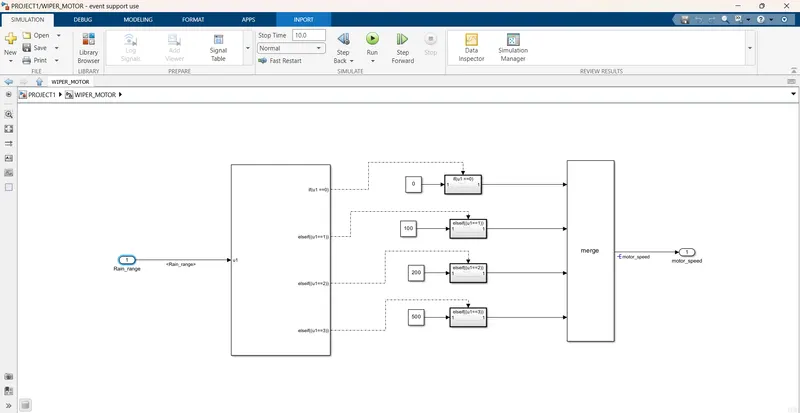
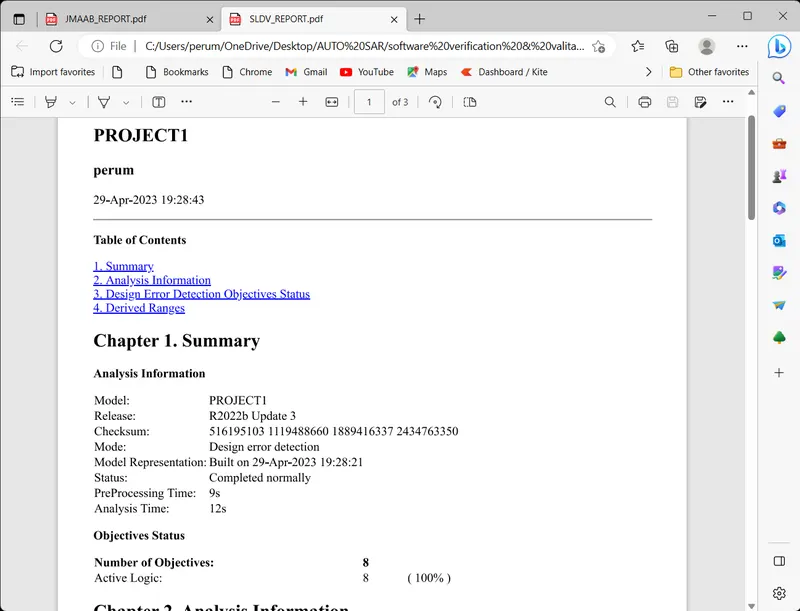
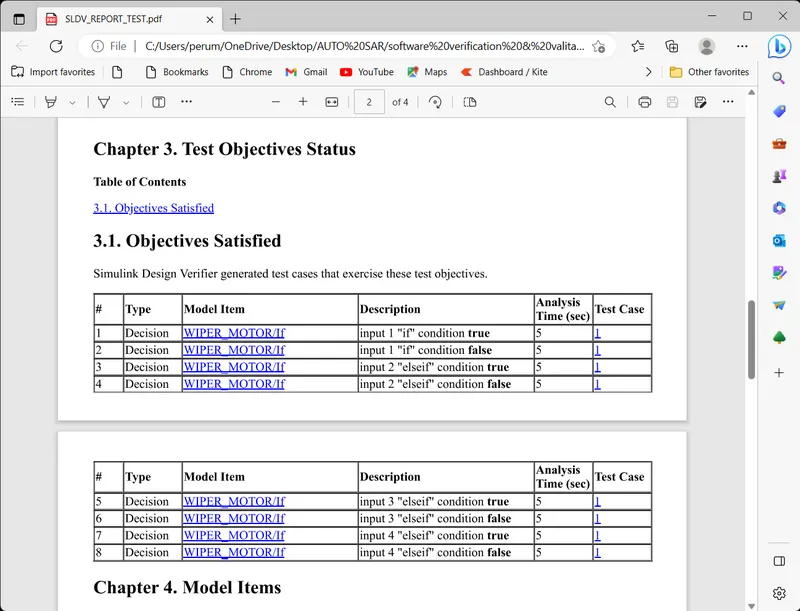
Develop Simulink/state flow model for wiper control system based on the given conditions.
Description of Challenge:
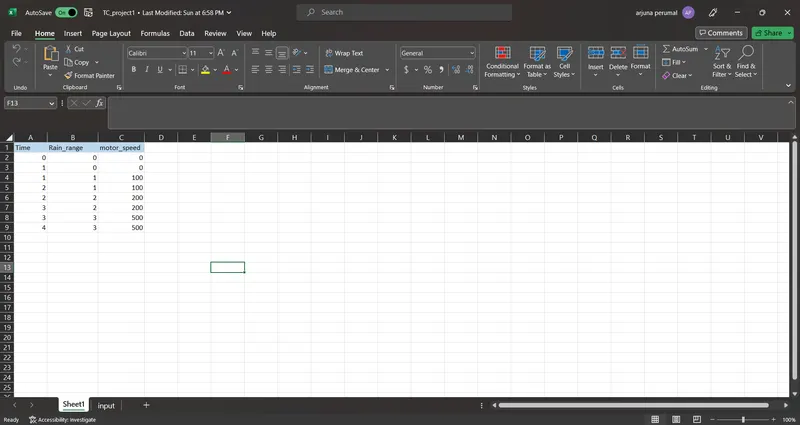
- If the density of the rain is low, then wiper rotates with low speed & the output signal should be 100rpm
- If the density of the rain is medium, then wiper rotates with medium speed & the output signal should be 200rpm
- If the density of the rain is high, then wiper rotates with high speed & the output signal should be 500rpm
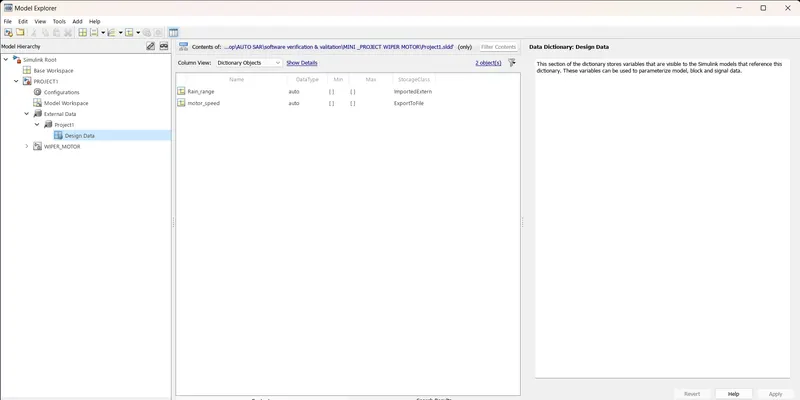
Note: Rain density input comes from the external sensor, for the simulation purpose constant block with knob can be taken.
POLYSPACE BUG FINDER:
In C and C++ embedded sofware polyspace bug finder detects run time errors softwre concurrency issuse data security vulnerabilities and other flows.
polyspace bug finder analyses software contorl and data flow behaviouer using static analysis techinques including semantic analysis.
it allow you to triage and fix bug early in the development process by highlighting defect as soon as detected.
polyspace bugg finder checks for MISRA C and MISRS C++ compliance as well as AUTOSAR C++I4,CERT C, CERT C++
and cutom nameing convention.
it generates bug report code rule violation report,and code quality metrics report.
POLYSPCE BUG FINDER TOOLS:
go to matlab and click the apps,
select the polysace and go to bug finder'
go to the seting configer tham.
start and new project and given porject name click to next.
porject source file ertw file and click next and finsh check box,
go to configer seting select target &compiler and traget processor type X86-64,
coding standards &code metring select MISRA C2004,
selsct the claculated code matrics,
reporting go to generat report,
All the seting done offter save the polyspace,
run the bug finder,
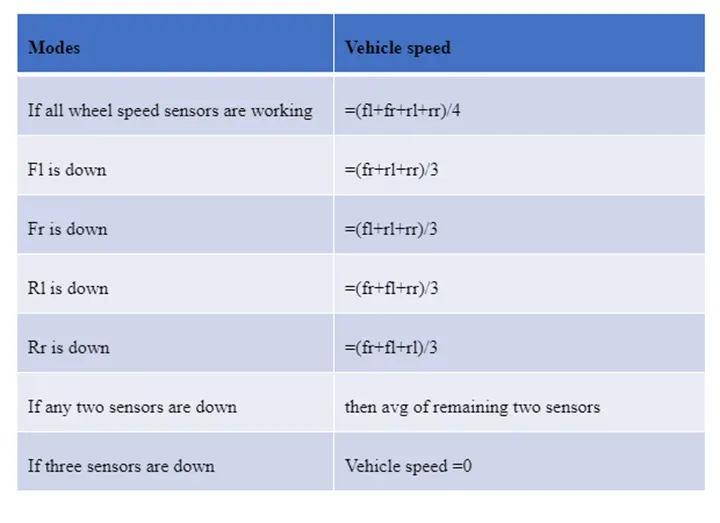
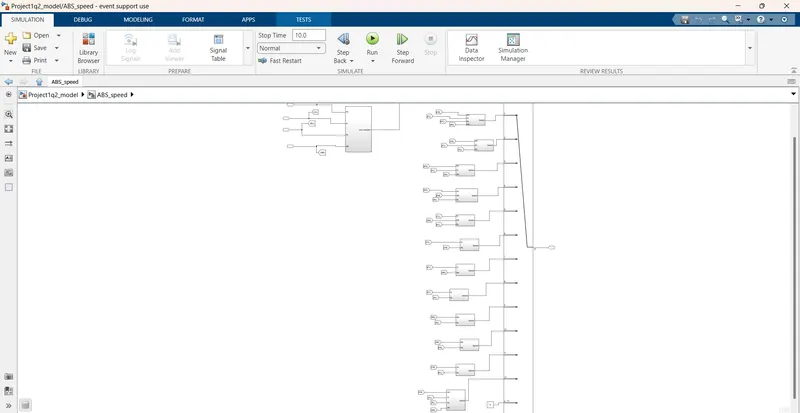
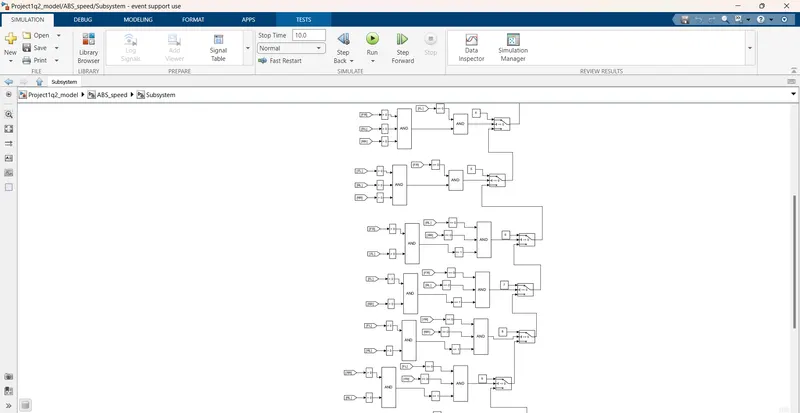
Develop Simulink/state flow model for the vehicle speed calculation unit inside the ABS system for the below conditions.
Description of Challenge:
fl, fr, rl and rr are the wheel speeds of front left, front right, rear left and rear right respectively.