Project-1: Powertrain for aircraft in runways
OBJECT:- Powertrain for aircraft in runways
AIM:-
- Search and list out the total weight of various types of aircrafts.
- Is there any difference between ground speed and air speed?
- Why is it not recommended to use aircraft engine power to move it on the ground at Airport?
- How an aircraft is pushed to runway when its ready to take off?
- Learn about take off power, tyre design, rolling resistance, tyre pressure, brake forces when landing.
- With necessary assumptions, calculate the force and power required to push / pull an aircraft by a towing vehicle.
7. Design an electric powertrain with type of motor, it’s power rating, and energy requirement to fulfill aircraft towing application. Estimate the duty cycle range to control the aircraft speed from zero to highest. Make all required assumptions. Prepare a table of assumed parameters. Draw a block diagram of powertrain.
STUDY-1
1. Search and list out the total weight of various types of aircrafts.
- Aircraft gross weight
The Aircraft Gross Weight (also known as the all-up weight and abbreviated AUW) is the total aircraft weight at any moment during the flight or ground operation.
An aircraft's gross weight will decrease during a flight due to fuel and oil consumption. An aircraft's gross weight may also vary during a flight due to payload dropping or in-flight refuelling.
At the moment of releasing its brakes, the gross weight of an aircraft is equal to its takeoff weight. During flight, an aircraft's gross weight is referred to as the en-route weight or in-flight weight.
1. Design weight limits (structural design weights)
An aircraft's gross weight is limited by several weight restrictions in order to avoid overloading its structure or to avoid unacceptable performance or handling qualities while in operation.
Aircraft gross weight limits are established during an aircraft's design and certification period and are laid down in the aircraft's type certificate and manufacturer specification documents.
The absolute maximum weight capabilities of a given aircraft are referred to as the structural weight limits. The structural weight limits are based on aircraft maximum structural capability and define the envelope for the CG charts (both maximum weight and CG limits).
An aircraft's structural weight capability is typically a function of when the aircraft was manufactured, and in some cases, old aircraft can have their structural weight capability increased by structural modifications.
2. Maximum design taxi weight (MDTW)
The maximum design taxi weight (also known as the maximum design ramp weight (MDRW)) is the maximum weight certificated for aircraft manoeuvring on the ground (taxiing or towing) as limited by aircraft strength and airworthiness requirements.
3. Maximum design takeoff weight (MDTOW)
Is the maximum certificated design weight when the brakes are released for takeoff and is the greatest weight for which compliance with the relevant structural and engineering requirements has been demonstrated by the manufacturer.
4. Maximum design landing weight (MDLW)
The maximum certificated design weight at which the aircraft meets the appropriate landing certification requirements. It generally depends on the landing gear strength or the landing impact loads on certain parts of the wing structure.
The MDLW must not exceed the MDTOW.
The maximum landing weight is typically designed for 10 feet per second (600 feet per minute) sink rate at touch down with no structural damage.
5. Maximum design zero-fuel weight (MDZFW)
The maximum certificated design weight of the aircraft less all usable fuel and other specified usable agents (engine injection fluid, and other consumable propulsion agents). It is the maximum weight permitted before usable fuel and other specified usable fluids are loaded in specified sections of the airplane. The MDZFW is limited by strength and airworthiness requirements. At this weight, the subsequent addition of fuel will not result in the aircraft design strength being exceeded. The weight difference between the MDTOW and the MDZFW may be utilised only for the addition of fuel.
6. Minimum flight weight (MFW)
Minimum certificated weight for flight as limited by aircraft strength and airworthiness requirements.
STUDY-2
Airspeed and Ground Speed
Airspeed is the vector difference between the ground speed and the wind speed. On a perfectly still day, the airspeed is equal to the ground speed. But if the wind is blowing in the same direction that the aircraft is moving, the airspeed will be less than the ground speed.
ground speed, which is defined as the speed at which an object travels relative to a fixed point on the Earth's surface. Mach number, however, is measured with respect to the velocity of the object through the air, or its airspeed. The difference between ground speed and airspeed is caused by the influence of winds on the overall velocity of the aircraft.
The relationship between ground speed, airspeed, and wind speed can be written in the following form:
3. Why is it not recommended to use aircraft engine power to move it on the ground at Airport?
Taxiing (rarely spelled taxying) is the movement of an aircraft on the ground, under its own power, in contrast to Towing or push-back where the aircraft is moved by a tug. The aircraft usually moves on wheels, but the term also includes aircraft with skis or float (for water-based travel).
An airplane uses taxiways to taxi from one place on an airport to another; for example, when moving from a hangar to the runway. The term "taxiing" is not used for the accelerating run along a runway prior to takeoff, or the decelerating run immediately after landing, which are called the takeoff roll and landing rollout, respectively.
STUDY-4
4. How an aircraft is pushed to runway when its ready to take off?
Taxiing refers to the movement of an aircraft on the ground, under its own power. The aircraft moves on wheels. An airplane uses taxiways to taxi from one place on an airport to another; for example, when moving from a terminal to the runway.
The aircrafts always moves on the ground following the yellow lines, to avoid any collision with the surrounding buildings, vehicles or other aircrafts. The taxiing motion has a speed limit. Before making a turn, the pilot reduces the speed further to prevent tire skids. Just like cars, there is a certain list of priorities during taxiing. The aircrafts that are landing or taking off have higher priority. The other aircrafts have to wait for these aircrafts before they start or continue taxiing.
The thrust to propel the aircraft forward comes from its propellers or jet engines. Steering is achieved by turning a nose wheel or tail wheel/rudder; the pilot controlling the direction travelled with their feet. The use of engine thrust near terminals is restricted due to the possibility of jet blast damage. This is why the aircrafts are pushed back from the buildings by a vehicle before they can start their own engines for taxiing.
Take-Off
Takeoff is the phase of flight in which an aircraft goes through a transition from moving along the ground (taxiing) to flying in the air, usually starting on a runway. Usually the engines are run at full power during takeoff. Following the taxi motion, the aircraft stops at the starting line of the runway. Before takeoff, the engines, particularly piston engines, are routinely run up at high power to check for engine-related problems. This makes a consid- erable noise. When the pilot releases the brakes, the aircraft starts accelerating rapidly until the necessary speed for take-off is achieved.
The takeoff speed required varies with air den- sity, aircraft weight, and aircraft configuration (flap and/or slat position, as applicable). Air density is affected by factors such as field ele- vation and air temperature.
Operations with transport category aircraft employ the concept of the takeoff V-Speeds, V1 and V2. These speeds are determined not only by the above factors affecting takeoff perform- ance, but also by the length and slope of the runway. Below V1, in case of critical failures, the takeoff should be aborted; above V1 the pilot continues the takeoff and returns for land- ing. After the co-pilot calls V1, Then, V2 (the safe takeoff speed) is called. This speed must be maintained after an engine failure to meet per- formance targets for rate of climb and angle of climb.
The speeds needed for takeoff are relative to the motion of the air (indicated airspeed). A head wind will reduce the ground speed needed for takeoff, as there is a greater flow of air over the wings. This is why the aircrafts always take off against the wind. Side wind is not preferred as it would disturb the stability of the aircraft. Typical takeoff air speeds for jetliners are in the 130–155 knot range (150–180 mph, 240–285 km/h). For a given aircraft, the takeoff speed is usually directly proportional to the aircraft weight; the heavier the weight, the greater the speed needed. Some aircraft have difficulty generating enough lift at the low speeds encountered during takeoff. These are therefore fitted with high-lift devices, often including slats and usually flaps, which increase the camber of the wing, making it more effective at low speed, thus creating more lift. These have to be deployed from the wing before performing any maneuver.
At the beginning of the climb phase, the wheels are retracted into the aircraft and the undercarriage doors are closed. This operation is audible by the passengers as a noise coming from below the floor.
Climb
Following take-off, the aircraft has to climb to a certain altitude (typically 30,000 ft or 10 km) before it can cruise at this altitude in a safe and economic way. A climb is carried out by increasing the lift of wings supporting the aircraft until their lifting force exceeds the weight of the aircraft. Once this occurs, the aircraft will climb to a higher altitude until the lifting force and weight are again in balance. The increase in lift may be accomplished by increasing the angle of attack of the wings, by increasing the thrust of the engines to increase speed (thereby increasing lift), by increasing the surface area or shape of the wing to produce greater lift, or by some combination of these techniques. In most cases, engine thrust and angle of attack are simultaneously increased to produce a climb.
Because lift diminishes with decreasing air density, a climb, once initiated, will end by itself when the diminishing lift with increasing altitude drops to a point that equals the weight of the aircraft. At that point, the aircraft will return to level flight at a constant altitude. During climb phase, it is normal that the engine noise diminishes. This is because the engines are operated at a lower power level after the take-off. It is also possible to hear a whirring noise or a change in the tone of the noise during climb. This is the sound of the flaps that are retracting. A wing with retracted flap produces less noise.
Cruise
Cruise is the level portion of aircraft travel where flight is most fuel efficient. It occurs between ascent and descent phases and is usually the majority of a journey. Technically, cruising consists of heading (direction of flight) changes only at a constant airspeed and altitude. It ends as the aircraft approaches the destination where the descent phase of flight commences in preparation for landing.
For most commercial passenger aircraft, the cruise phase of flight consumes the majority of fuel. As this lightens the aircraft considerably, higher altitudes are more efficient for additional fuel economy. However, for operational and air traffic control reasons it is necessary to stay at the cleared flight level. Typical cruising speed for long-distance commercial passenger flights is 475-500 knots (878-926 km/h; 547-578 mph).
Commercial or passenger aircraft are usually designed for optimum performance at their cruise speed. There is also an optimum cruise altitude for a particular aircraft type and conditions including payload weight, center of gravity, air temperature, humidity, and speed. This altitude is usually where the drag is minimum and the lift is maximum. As in any phase of the flight, the aircraft in cruise mode is always in communication with an Air Traffic Control (ATC) station. Although the general tendency is to follow a straight line towards the destination, there may be some deviations from the flight plan for weather, turbulence or air traffic rea- sons, after receiving clearance from ATC.
Descent
A descent during air travel is any portion where an aircraft decreases altitude. Descents are an essential component of an approach to landing. Other partial descents might be to avoid traffic, poor flight conditions (turbulence or bad weather), clouds (particularly under visual flight rules), to see something lower, to enter warmer air (in the case of extreme cold), or to take advantage of wind direction of a different altitude. Normal descents take place at a con- stant airspeed and constant angle of descent (3 degree final approach at most airports). The pilot controls the angle of descent by varying engine power and pitch angle (lowering the nose) to keep the airspeed constant.
At the beginning of and during the descent phase, the engine noise diminishes further as the engines are operated at low power settings. However, towards the end of the descent phase, the passenger can feel further accelerations and an increase in the noise. This is to realize the “final approach” before taking “landing posi- tion”
Landing
Landing is the last part of a flight, where the aircraft returns to the ground. Aircraft usually land at an airport on a firm runway, generally constructed of asphalt concrete, concrete, gravel or grass. To land, the airspeed and the rate of descent are reduced to where the object descends at a slow enough rate to allow for a gentle touch down. Landing is accomplished by slowing down and descending to the runway. This speed reduction is accomplished by reducing thrust and/or inducing a greater amount of drag using flaps, landing gear or speed brakes. As the plane approaches the ground, the pilot will execute a flare (roundout) to induce a gentle landing. Although the pilots are trained to perform the landing operation, there are “Instrument Landing Systems” in most of the airports to help pilots land the aircrafts. An instrument landing system (ILS) is a ground-based instrument approach system that provides precision guid- ance to an aircraft approaching and landing on a runway, using a combination of radio signals and, in many cases, high-intensity lighting arrays to enable a safe landing during instrument meteorological conditions (IMC), such as low ceilings or reduced visibility due to fog, rain, or blowing snow.
At the beginning of the landing phase, the pas- sengers will hear the opening of the doors of the landing gears. As the landing gears are deployed, they will create an additional drag and an additional noise. Immediately after touch-down, the passengers can hear a blowing sound, sometimes with increasing engine sound. This is the engine’s thrust reverses, helping the aircraft to slow down to taxi speeds by redirecting the airflow of the engines for- ward. Once the aircraft is decelerated to low speed, it can taxi to the terminal building.
Youtube Link-https://www.youtube.com/watch?v=F077WDnB8P8
STUDY-5
5. Learn about take off power, tyre design, rolling resistance, tyre pressure, brake forces when landing.
1. Take Off Power: The power required by the aircraft engines to use to lift them into a horizonatal takeoff is known as takeoff power. Usually this term is also known as takeoff thrust. Pilot use less amount of thrust at takeoff to decrease engine wear at takeoff. Reduced power ar dreated takeoff are normal and frequently used. The performance is carefully calculated prior to each takeoff, ensure that the proper speed, power setting and flapes are used for the weight of the takeoff on the runwayintended and at the proper temperature. When using this method during takeoff, it is always possible to increase to full power if the situation requires.
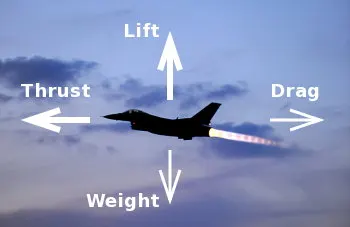
2. Aircraft Tyre | Design and Construction
When it comes to safely, tyres are one of the most important components of aircraft. They help to absorb the shock of landing and provide cushioning. It also provides the necessary traction for braking and stopping of an aircraft.
An aircraft tyre is designed to withstand extremely heavy loads while landing, take off, taxing and parking. The number of wheels required for aircraft increases with the weight of the aircraft, as the weight of the aeroplane needs to be distributed more evenly.
- Let’s go through some technical aspects of the tyre.
- Retreading – Retreading is methods of restoring a worn tyre by renewing the tread area or by renewing the tread area plus one or both sidewalls. Repairs are included in the tyre retreading process.
-
Load Rating – Load rating is the maximum permissible load at a specified inflation pressure.
-
Ply Rating – Ply Rating is used to identify the maximum recommended load rating and inflation pressure for a specified tyre. It is an index of tyre strength.
-
Speed Rating – The speed rating is the maximum takeoff speed to which the tyre has been tested.
-
Skid Depth – Skid depth is the distance between the tread surface and the deepest groove as measured in the mould.
Aircraft tyres must have an approved speed and load rating and have sufficient clearance when retracted through landing gear to allow for tyre growth. Tyre growth is the increase in the size of the tyre due to centrifugal forces at high speed.
-
Aircraft tyres may be Tube-type or Tubeless
Tubeless tyres are more advantageous over tube-type. There is no longer the use of tube-type tyre in recent aviation. Nowadays all airliners are using tubeless tyres. Tubeless that are meant to be used without a tube has the word TUBELESS on the sidewall of the tyre.
3. Rolling Resistance: It is the resistance that the tires offer against motion whileon ground. in case of aircraft rolling resistance can be experienced while take off and while landing. The rolling resistance force is given by the following expression-
Frr=μrr×m.gFrr=μrr×m.g
Frr=μrr×m.gFrr=μrr×m.g
mm = Mass of aircraft
μrrμrr = Coefficient of rolling resistance
4. Tyre Pressure: Aircraft tires are usually inflated with nitrogen to minimize expansion and contraction from extreme changes in ambient temperature and pressure experienced during flight. Dry nitrogen expands at the same rate as other dry atmospheric gases (normal air is about 80% nitrogen), but common compressed air sources may contain moisture, which increases the expansion rate with temperature.
The requirement that an inert gas, such as nitrogen, be used instead of air for inflation of tires on certain transport category airplanes was prompted by at least three cases in which the oxygen in air-filled tires combined with volatile gases given off by a severely overheated tire and exploded upon reaching autoignition temperature. The use of an inert gas for tire inflation will eliminate the possibility of a tire explosion.
Aircraft tires generally operate at high pressures, up to 200 psi (14 bar; 1,400 kPa) for airliners, and even higher for business jets.
5. Brake Forces When Landing: All The commercial aircraft have automatic brake systems. Juat like a car, these systems also have Anti-Lock Braking System(ABS) that prevents the tires from sliding down a wet runway. The advantage of the automatic brake system is that the aircraft brakes comfotably at a constant deceleretion. Pessengers experience a constant force that presses them into their seats. The brake system automatically applies the wheel brakes just enough to create a constant deceleration independent of the air resistance, spoilers and reversers. It is only in the last phase of brakes by pressing on both brake pedals. This deactivates the automatic brake system. Immediately after landing, the aircraft is still moving fast enough that aerodynamic devices are much more efficient that the brakes.
The brake units are powered by the hydraulics system. An electrical signal is sent from the flight deck to hydraulic actuators near the main landing gear. Here, hydraulic fluid at 3,000 pound per square inch is used to force the brake unit against the wheel, thus slowing it down.
STUDY-6
6. With necessary assumptions, calculate the force and power required to push / pull an aircraft by a towing vehicle.
Let us Assume:
Weight of the Aircraft (Airbus A-380) = 575000kg
Rolling Resistance Coefficient of an aircraft tire(μrrμrr) = 0.004
Wight of the Towing Tractor = 50000kg
Rolling Resistance Coefficient of Towing Vehicle(μrrμrr) = 0.001
Then,
Rolling Resistance Force of Tow Tractor = μrr×m.g=0.001×50000×9.81=0.49KNμrr×m.g=0.001×50000×9.81=0.49KN
Rolling Resistance Force of aircraft = μrr×m.g=0.004×575000×9.81=22.56KNμrr×m.g=0.004×575000×9.81=22.56KN
Total Rolling Resistance Force = Rolling Resistance Force of aircraft + Towing Tractor = 0.49 + 22.56
Total Rolling Resistance Force = 23.05KN
Air Drag Force-
The drag force is the force that occures due to the Air Strike effect on the vehicle when it moves. The vehicle moves through a air medium of particular dencsity value with certain speed this causes the air strike against the vehicle body and it causesDrag Force on the vehicle.
The Aerodynamic Drag is given by the following expression-
fad=12⋅ρ⋅A⋅V2⋅Cdfad=12⋅ρ⋅A⋅V2⋅Cd
Where,
ρρ = Density of Air Medium
A = Frontal Area Of the Vehicle which strike the Air
V = Velocity with the vehicle moves
CdCd = Coefficient of Dragwhich varies different shapes of the frontal area.
Calculation:
Let us assume
The Velocity of the Aircraft while Towing = 30KMPH = 8.33m/s
Dnsity of Air medium(ρρ) = 1.225
The Frontal area of the Aircraft = 20m2m2
The Coefficient of Drag of the Aircraft = 0.026
Air drag force = 0.5*rho*A*V^2*Cd = 0.022KN
The Air Drag Force of the Aircraft = 0.022KN
Therefore the total force that the motor needs to overcome = Rolling Resistance of the aircraft + Drad Force Acting on the Aircraft hence the total forces acting = 23.05 + 0.022
The Total Force that the Motor needs to overcome in order to push/pull the Aircraft = 23.07KN
The Power Required-
The power required by the motor is given by the velocity with which the towing operation takes place.
The average speed of push/pull = 20 kmph = 5.5m/s
Power required by the motor = Total Force*Velocity = 23.07*5.5
Power Required by The Motor = 126.8kw
The torque output of the towing tractor can also be calculated by the below steps-
Fte=T.GrFte=T.Gr
Where,
FteFte = The Total Tractive Force(Rolling resistance force + Air drag force)
T = Torque Output
r = Radius of Tire
G = Gear Ratio
For Heavy Duty Towing Tractor we Assume,
G = 11(for delivering high torque)
r = 25inches = 0.635m
T=Fte⋅rG=23000⋅0.63511T=Fte⋅rG=23000⋅0.63511
The Torque required to Push/Pull for the above stated condition = 1.327 KNm
STUDY-7
7. Design an electric powertrain with type of motor, it’s power rating, and energy requirement to fulfill aircraft towing application. Estimate the duty cycle range to control the aircraft speed from zero to highest. Make all required assumptions. Prepare a table of assumed parameters. Draw a block diagram of powertrain.
The parameters assumed for designing this vehicle is taken from online references
S.No. Assumed Parameters Assumed Values
1. Weight of the Aircraft 575000 kg
2. Weight of the Towing Tractor 50000 kg
3. Rolling Resistance Coefficient of Aircraft 0.004
4. Rolling Resistance Coefficient of Towing Tractor 0.001
5. The velocity of the Aircraft while Towing 8.33 m/s
6. Density of Air medium(rho) 1.225 kg/m^3
7. The Frontal area of the Aircraft 20 m^2
8. The Coefficient of Drag of the Aircraft 0.026
9. Towing Tractor Gear ratio(G- for high torque output) 11
10. Towing Tractor tyre radus(r) 0.635 m
11. Operational time of the Towing for one cycle 0.33 Hour
12. The Battery Armature Voltage 350 V
13. The Battery Armature Current 350 A
14. The Motor Terminal Voltage for full power output 630 V @ motor terminals
15. Power converters used Bidirectional DC-DC Boost Converter
16. The maximum duty ratio for acieving full power 70%
Assuming the operational time of the Towing Truck is around 20 minuts for one cycle
20 minuts = 0.33 hour
Energy(kwh) = power(kw)*Time(h) = 162.8*0.33
Energy(kwh) = 41.8 kwh
Therefore the battery must be able to store the energy 41.8 kwh and should deliver the energy throughout the run time in order for the motor to produce the 1.32 KNm of torque instantaneously. Thus the storage of energy in batteries with high performance Ultracapacitors are selected to fulfill the required power deliver.
Motor Selection:
Here we have selected a BLDC Motor type that has a power rating of 126.8kw and with the gear ratio and the transmission it should be able to deliver 1.32KNm of torque instantaneously.
The Battery Armature Voltage (V) 350 V
The Battery Armature Current (A) 350 A
Power Converter:
A boost converter (step-up converter) is a DC-to-DC power converter that steps up voltage (while stepping down current) from its input (supply) to its output (load). It is a class of switched-mode power supply (SMPS) containing at least two semiconductors (a diode and a transistor) and at least one energy storage element: a capacitor, inductor, or the two in combination. To reduce voltage ripple, filters made of capacitors (sometimes in combination with inductors) are normally added to such a converter's output (load-side filter) and input (supply-side filter).
Speed Control of the Vehicle:
The Electric Vehicle uses power from the battery source to drive the motor and then further to drive the wheels in order to move the vehicle. The speed and torque generated from the motor is very important to drive the vehicle as per the driver's desire. If we connect the battery directly to the motor the motor will spin with a speed and torque characteristics which will be based on the full power of the battery voltage. We does not require full power in all the driving conditions so we need to adopt a power controller between the bettery and the motor so that the motor speed may be controlled by the driver to drive the vehicle as desired. For controlling the vehicle power we use the soft switching operation technique here. The amount of power can be controlled by changing the Duty Cycle value. Considering the losses we take 70% of the duty cycle to deliver the maximum power of the motor.
Motor Terminal Voltage = Armature Voltage * Duty Cycle = 900*0.7
With 70% Duty Cycle the voltage at motor terminals = 630V, Which gives the full power with all the gearings instantaneously. Thus by varying the Duty Cycle value the speed of the vehicle is controlled.
Block Diagram of Powertrain:
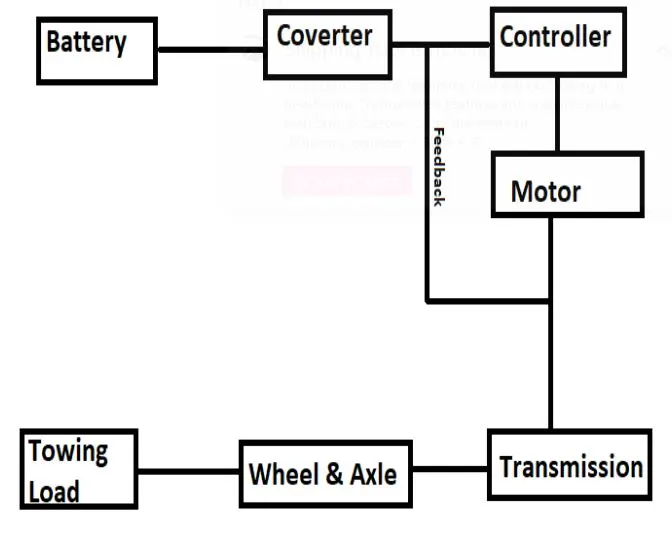
Conclusion:
The reference Aircraft taken here is the Heavy Aircraft build and so our designed towing tractor is a heavy duty operational vehicle.The power requirements are calculated for the particular load to be pushed/pulled and to achieve this power at the motor output, the motor type and its voltage at the terminals are discussed.
Then the power converters are used to upscale the battery armature voltage to thr desired high voltage value so that the motor may spin at full power and required torque can be achieved using a Bidirectional DC-DC Converter. Finally the speed control of the vehicle is done with switching techniques where the Duty Cycle adjustment can change the motor speed from the minimum to maximum.