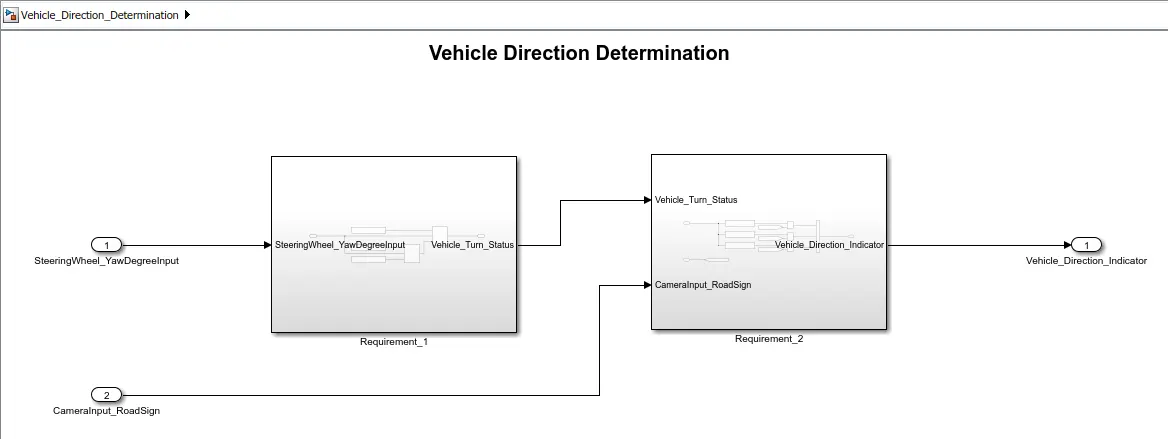
Project 1 (Mini Project on Vehicle Direction Detection
Aim:
The main aim is to create the Vehicle Direction Determination logic with the given requirements, using Data Dictionaries in Simulink.
Theory:
Identifying the direction of the vehicle is one of the important & diverse features in Autonomous driving & Advanced Driver Assistance Features. This particular sub-feature of identifying the direction of a vehicle is basically identifying the direction the vehicle is taking based on the camera input.
The camera reads the road signs & stores them in its memory with unique values for a left turn, right turn & straight drive. Depending on the direction it is taking, the final indication is given to the driver – as an indication if he is driving in the recommended direction or not.
Vehicle Direction Determination can also be coupled alongside features like GPS systems to identify whether the vehicle is reaching its destination in an optimized manner. This sub-feature can also be used along with Lane Detection, Highway Warning, Ramp Entry / Exit in Wrong Way Detection etc.
Requirement - 1:
- Steering wheel input as yaw rate (Signal name: SteeringWheel_YawDegreeInput) is the input for this system.
- This is compared against 3 angular values, one each for left turn, right turn & straight drive (Calibration Values: Right_Turn_AngularLimit, Left_Turn_AngularLimit, Straight_Drive_Steering_Angle) to say which specific direction the steering wheel is turning towards.
- Use switch blocks to compare & develop this requirement. Keep this requirement in a subsystem & the output of this requirement is a local signal (Signal Name: Vehicle_Turn_Status).
Requirement – 2:
- Keep this requirement as a separate subsystem. Inputs to this requirement are a local signal from requirement 1 (Signal Name: Vehicle_Turn_Status) & an input signal from the camera (Signal Name: CameraInput_RoadSign), which confirms the occurrence of a road sign.
- Signal Vehicle_Turn_Status is compared against calibration values (Calibration Values: RightTurn_RoadSign, LeftTurn_RoadSign, Straight_RoadSign), if each of them is found equal, then each of the three corresponding outputs is compared against the camera input signal,
- Using a logical operator block, only one among them is finally given as the output signal (Signal Name: Vehicle_Direction_Indicator).
Signals & Calibration Data List:
|
Signal / Calibration Name |
Signal Type |
Data Type |
Dimension |
Min |
Max |
Initial Value |
Units |
|
SteeringWheel_YawDegreeInput |
Input |
Int16 |
1 |
-180 |
180 |
- |
Deg |
|
CameraInput_RoadSign |
Input |
Boolean |
1 |
0 |
1 |
- |
- |
|
Vehicle_Turn_Status |
Local |
Int16 |
1 |
-180 |
180 |
- |
Deg |
|
Right_Turn_AngularLimit |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
30 |
Deg |
|
Left_Turn_AngularLimit |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
-120 |
Deg |
|
Straight_Drive_Steering_Angle |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
0 |
Deg |
|
RightTurn_RoadSign |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
30 |
- |
|
LeftTurn_RoadSign |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
-120 |
- |
|
Straight_RoadSign |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
0 |
- |
|
Vehicle_Direction_Indicator |
Output |
Boolean |
1 |
0 |
1 |
- |
- |
Procedure:
Creating a Data Dictionary:
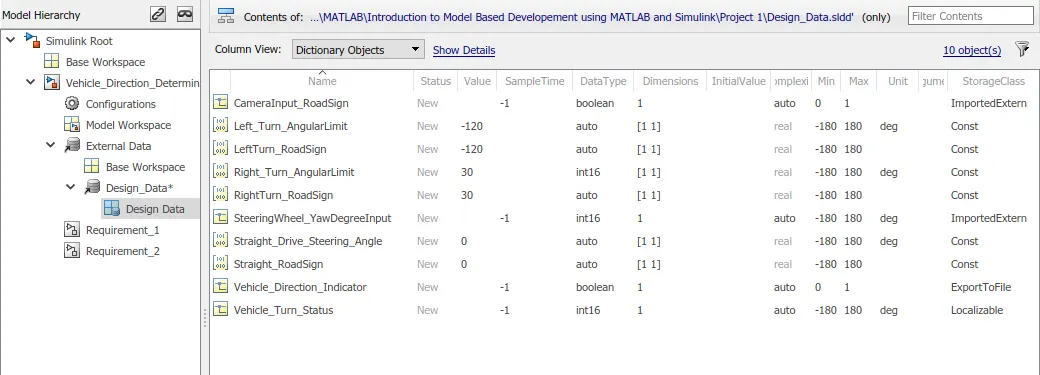
Create a data dictionary with the inputs, output, Local variable and calibration parameters.
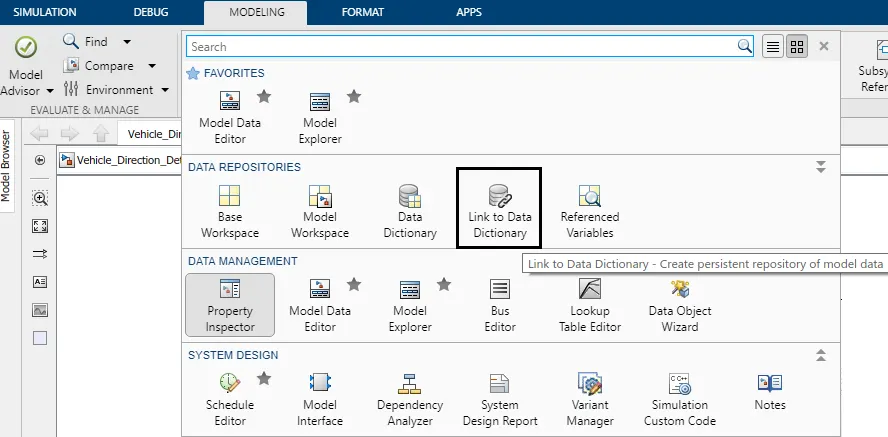
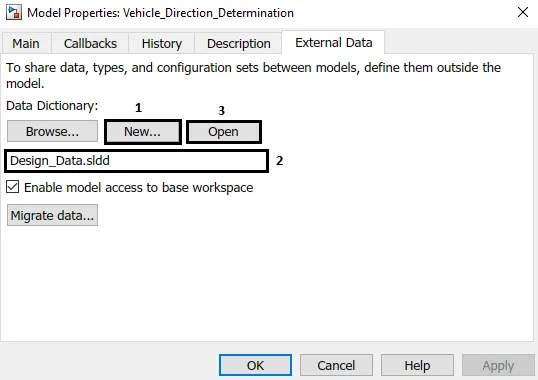
To create the Data-Dictionary Open Simulink, Under Modelling Tab, Select Link to Data Dictionary >> Model Properties opens, Under External Data, Select New and provide the name as ‘Design_Data.sldd’ and Click Open >> Model Explorer opens.
Under Model Explorer, Add the Simulink Parameters and Simulink Signals as described.
Requirement-1:
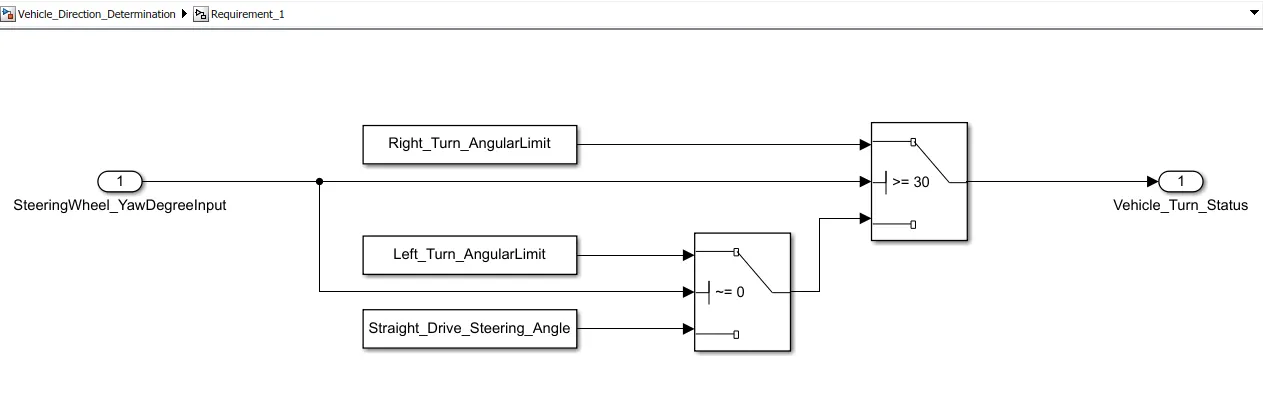
As provided in the requirements sheet, SteeringWheel_YawDegreeInput is considered as input and this input is connected to the control input of the Switch block with the condition if the control input >= 30 then it triggers true condition and returns the value of Right_Turn_AngularLimit as the Vehicle Turn Status output else it will trigger to the other Switch block with the same control input provided the condition if the SteeringWheel_YawDegreeInput ~= 0 then it returns Left_Turn_AngularLimit value otherwise it will return Straight_Drive_Steering_Angle value to the Vehicle Turn Status.
The process follows in a way that When the Steering wheel Yaw degree is more than 30 then it considers the Right turn angular limit as the vehicle turn status. If the Steering wheel Yaw degree is zero then the Straight Drive Steering Angle is taken else it will take the Left Turn Angular Limit.
Requirement-2:
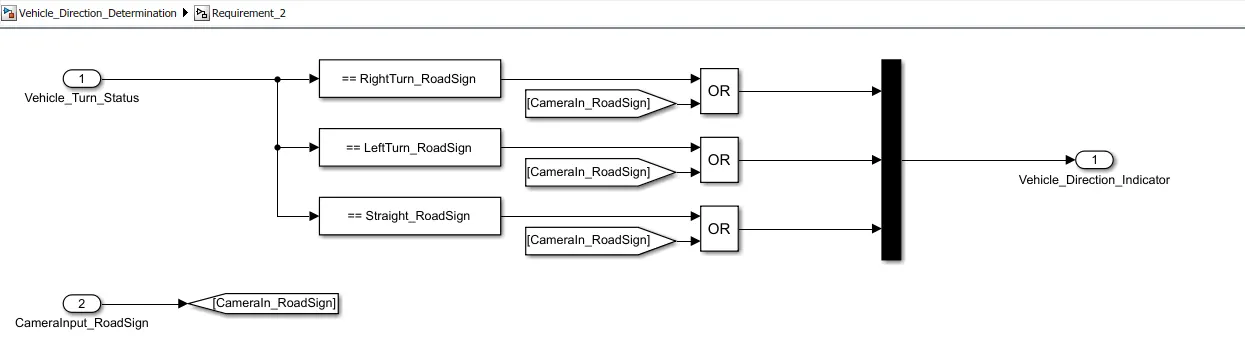
The vehicle turn status is connected to multiple Relational operators (==) such as Right Turn Road Sign, Left Turn Road Sign and Straight Road Sign. This is connected to a Logical operator (OR) with another input as Camera Road Sign where if any of the triggers are true, the Vehicle Direction indicator will return these values in the form of 0 and 1.
Result:
The Vehicle Direction Determination logic with the given requirements, using Data Dictionaries in Simulink is created.