Project 1 (Mini Project on Vehicle Direction Detection
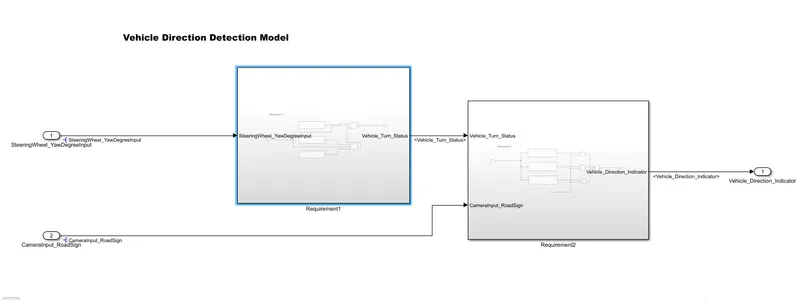
The objective is to create a model to determine the direction of the vehicle as per the requirement.
So there are two requirements which are as follows.
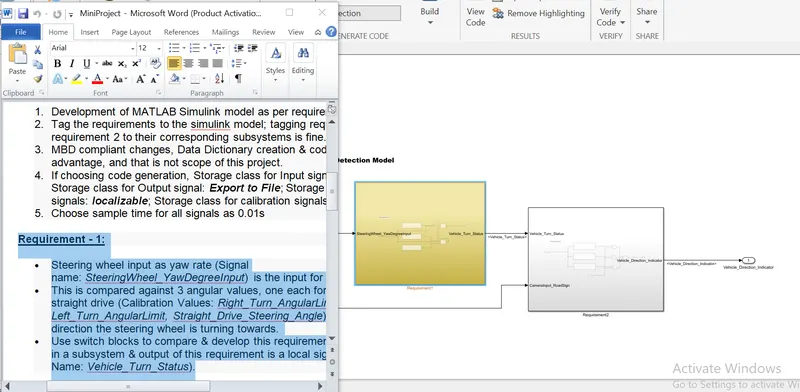
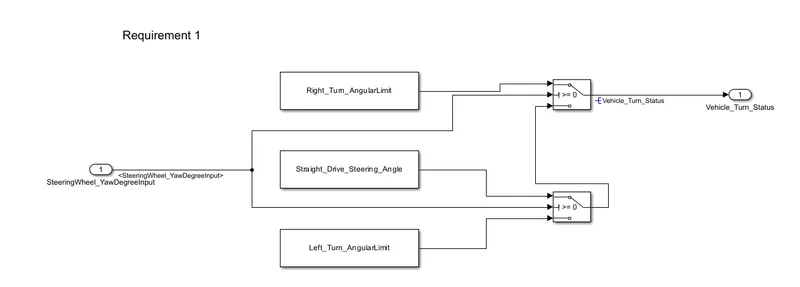
Requirement - 1 :- 1) In this requirement, there is a Steering wheel input name as SteeringWheel_YawDegreeInput.
2) Determine the direction of the vehicle using block name as Right_Turn_AngularLimit, Left_Turn_AngularLimit, Straight_Drive_Steering_Angle.
3) To compare these blocks use a switch block.
By following these requirements build a model as follows:
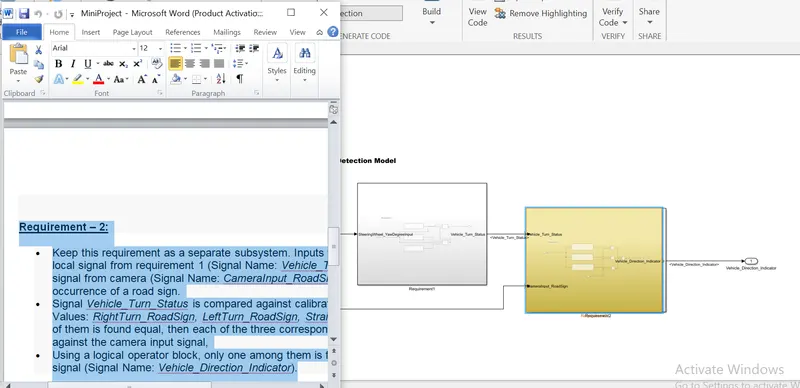
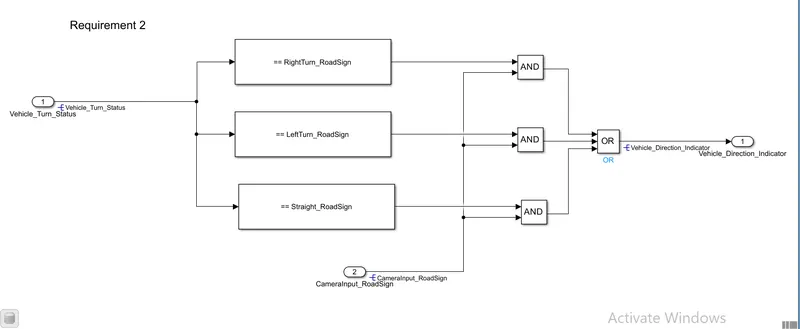
Requirement – 2: 1)For requirement2 take input from requirement1 name as Vehicle_Turn_Status and another input signal from camera name as CameraInput_RoadSign.
2) then these inputs with Calibration Values: RightTurn_RoadSign, LeftTurn_RoadSign, Straight_RoadSign.
By this we get model as follows :
by combining both requirements we get single subsystem as
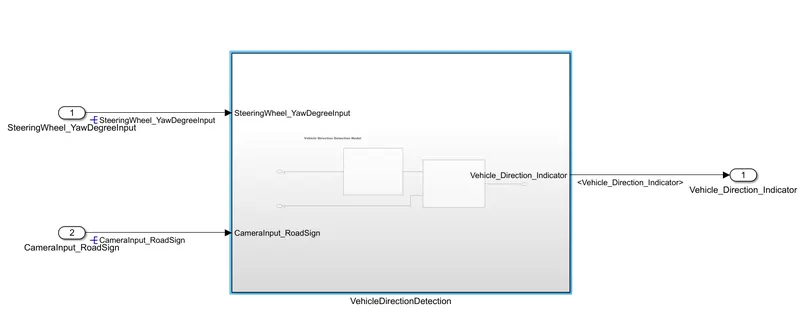
while creating a model we have to name signals,block also tagging requirements to word file as follows: