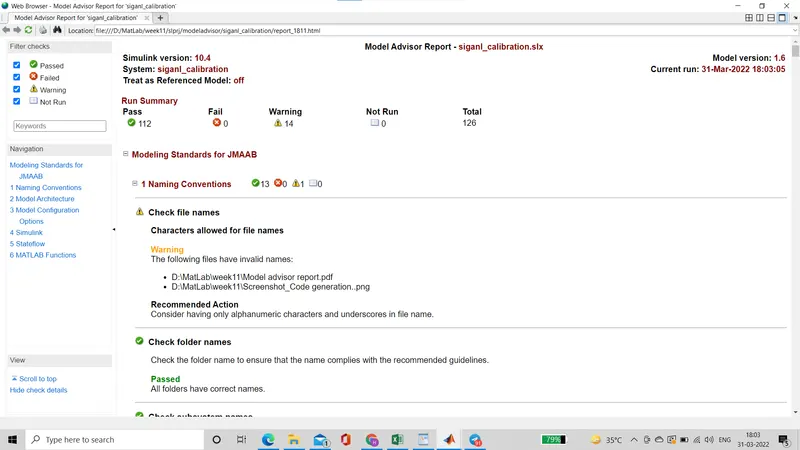
Project 1 (Mini Project on Vehicle Direction Detection
Mini Project.
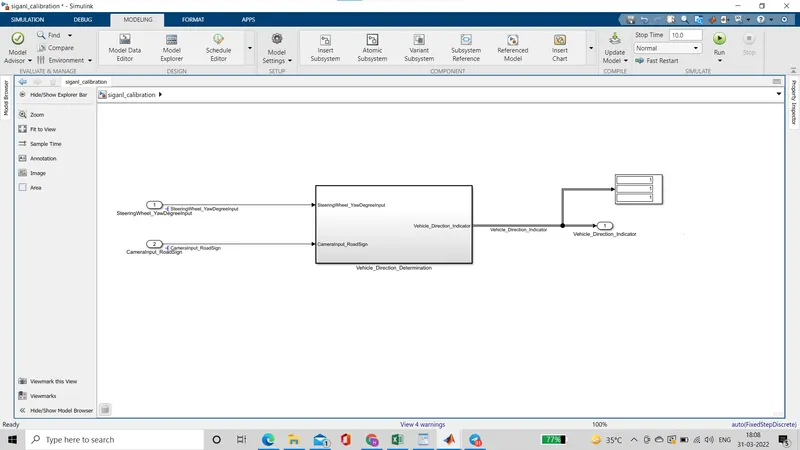
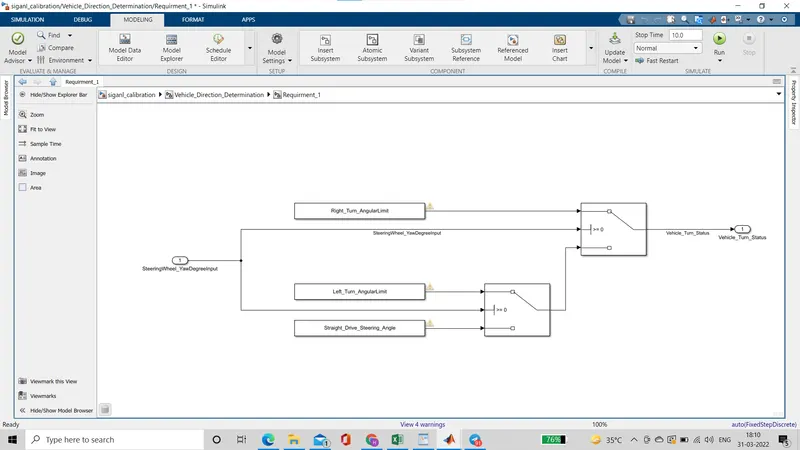
Subsystem Requirment_1
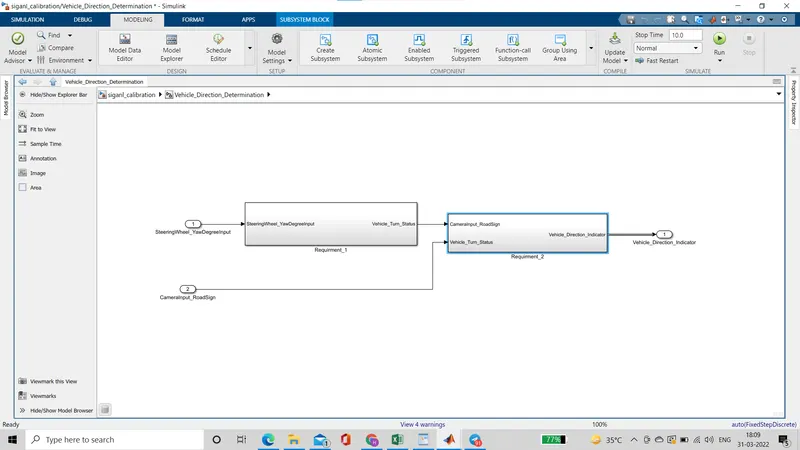
Subsystem Requirment_2
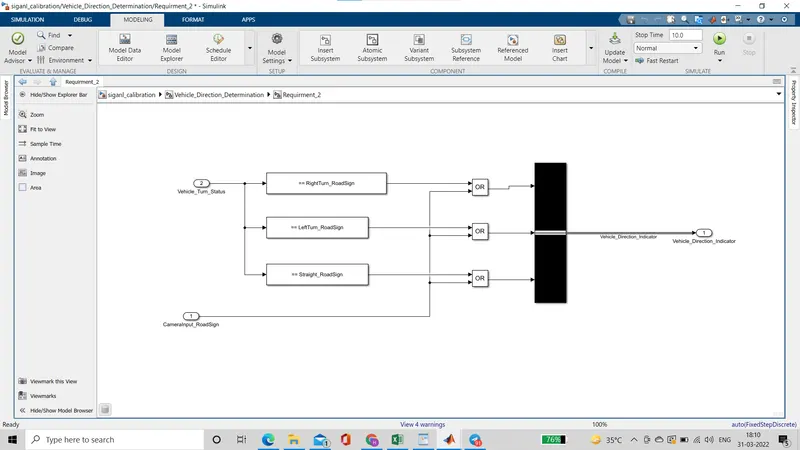
- Signal name_steering wheel is a niput for this system.
- Compared with three angular value:- left turn, right turn, and straight drive with the respected calibration value, to define which specific direction the steering wheel turning toward.
- Use switch block to compare and develop requirment as a subsistem and give output is a local signal.
- Keep this requirment as a separate subsystem. Input this requirment are with local siganl from requirment_1 as Signal neme: Vehicle_Turn_Status and an input from the camara as Signal name: Camarainput_Roadsign, which confirms the occurrences of a road sign.
- Signal vehicle_Turn_Staus is compared against calibration value, if each of them found equal, then each of the three corresponding output is compared against the camara input signal.
- Used the logical opretor block only one among them is finally given as output signal.(Signal Name:- Vehicle_Direction_Indicator)
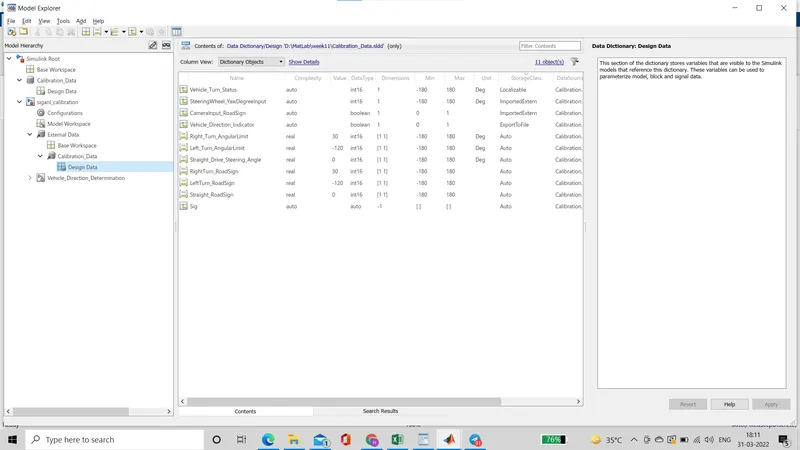
SLDD File
Code Generation
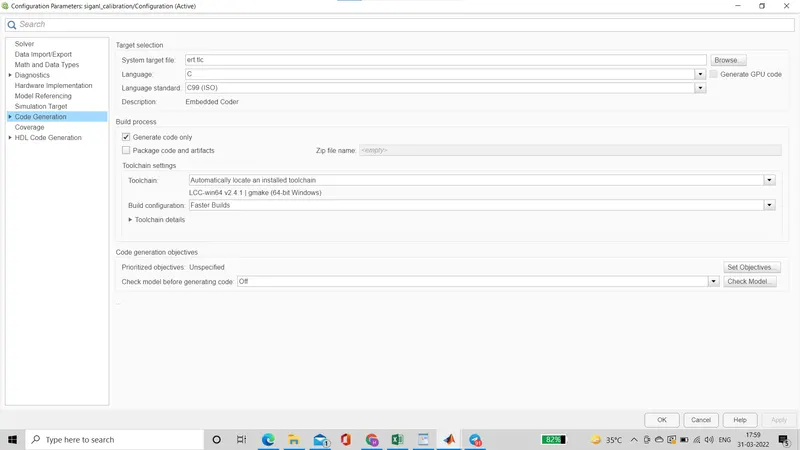
Configuration Parameter_Solver
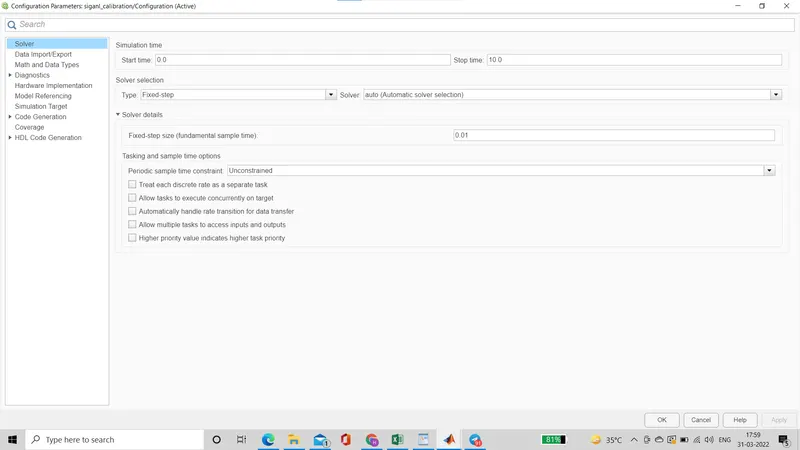
Configuration Parameter_Code Genetation
Model Advisor