Project 1 (Mini Project on Vehicle Direction Detection
- AIM OF THE PROJECT:
THE MAIN AIM OF THE PROJECT IS TO IDENTIFY THE DIRECTION OF THE VEHICLE & DIVERSE FEATURES IN AUTONOMOUS DRIVING & ADAS FEATURES.THE DIRECTION OF VEHICLE IS BASICALLY IDENTIFIED WITH THE HELP OF STEERING VEHICLE YAW DEGREE INPUT & CAMERA INPUT ROAD SIGN,WHICH IS USED TO READ THE SIGNALS AND INDICATE THE SAME TO DRIVER TO CHECK IF THE DRIVING STATE IS IN RECOMMENDED DIRECTION OR NOT.
DESCRIPTION OF THE PROJECT:
The main subsystem which consists of two more subsystems which is requirement1 & requirement2, which is described in the following:
REQUIREMENT 1:
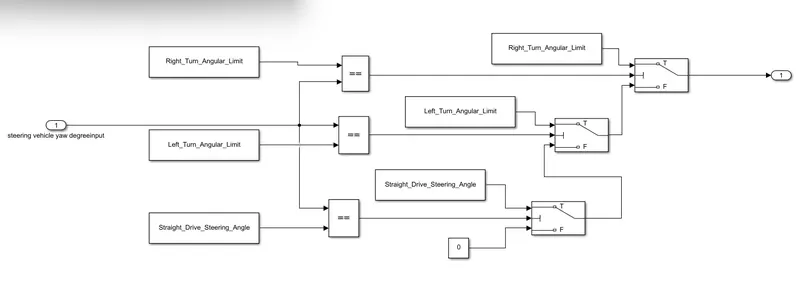
- Steering wheel yaw degree is the input to the subsystem of requirement 1.
- the steering wheel yaw degree input is compared with three different values such as Right_Turn_Angular_Limit, Left_Turn_Angular_Limit & Straight_Drive_Steering_Limit
- These values are compared using relational operator which is connected to a switch, if the input value is equal to right turn angular limit then the condition gets satisfied and returns a true statement. if the condition did not satisfy then fed to false statement and checks the next condition.The process contineous till the given statements.
REQUIREMENT 2:
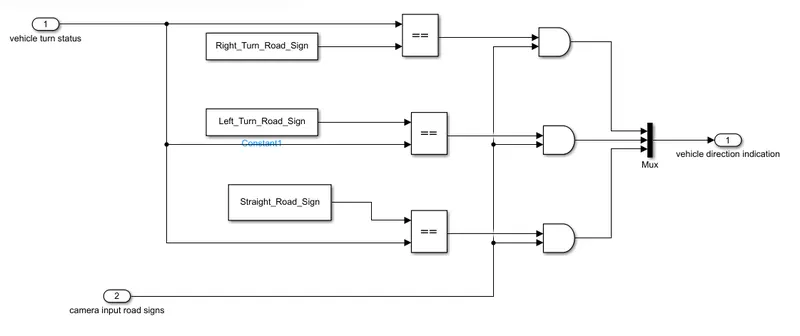
- It consists of two inputs one is vehicle turn input which is taken from the requirement 1 & the other is camera input road sign.
- camera input road sign is used to capture a signal & indicates the driver to check the direction of the road sign is same or not.
- These two inputs are fed to relational operator & logical AND blocks and fed to mux.
- Here the vehicle turn input is compared with three different values such as Right_Turn_Road_Sign, Left_Turn_Road_Sign & Straight_Road_Sign by using relational operator and fed to logical AND operator.
- The camera input road sign is also fed to logical AND operator which compares both the vehicle turn status and camera input road sign and displays the output.
CREATION OF SSLD:
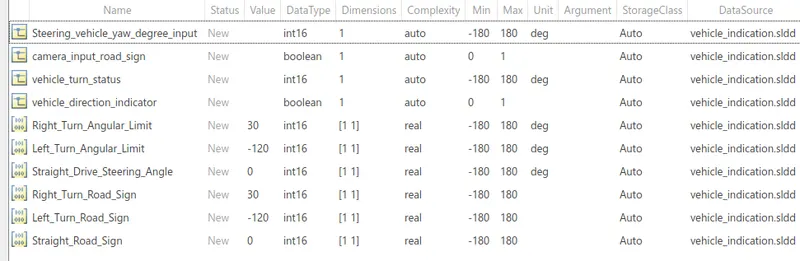
Modelling,modelling properties,create new file & save it, disable the model access & ok, go to model explorer,external data view saved file & design data now enter the data.
RESULTS:
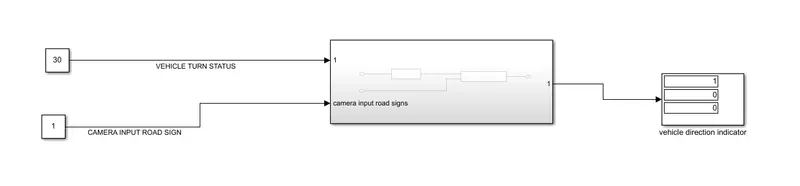
Here, value 30 is taken as input for vehicle turn status and which goes to requirement 1 and compares the value with the 3 different values using relational operator the value 30 is compared with right turn anglular limit and fed to switch which executes true statement and gives this output value to the requirement 2 as an input and compares with 3 different values and fed to AND operator & camera input road signal reads the input value as 1 and fed to AND operator which compares both inputs and displays an output in the form of boolean values.