Project 1 (Mini Project on Vehicle Direction Detection
AIM:- To create simulink model of vehical direction detectionas per the requirement data.
Requirement - 1:
- Steering wheel input as yaw rate (Signal name: SteeringWheel_YawDegreeInput) is the input for this system.
- This is compared against 3 angular values, one each for left turn, right turn & straight drive (Calibration Values: Right_Turn_AngularLimit, Left_Turn_AngularLimit, Straight_Drive_Steering_Angle) to say which specific direction the steering wheel is turning towards.
- Use switch blocks to compare & develop this requirement. Keep this requirement in a subsystem & output of this requirement is a local signal (Signal Name: Vehicle_Turn_Status).
Requirement – 2:
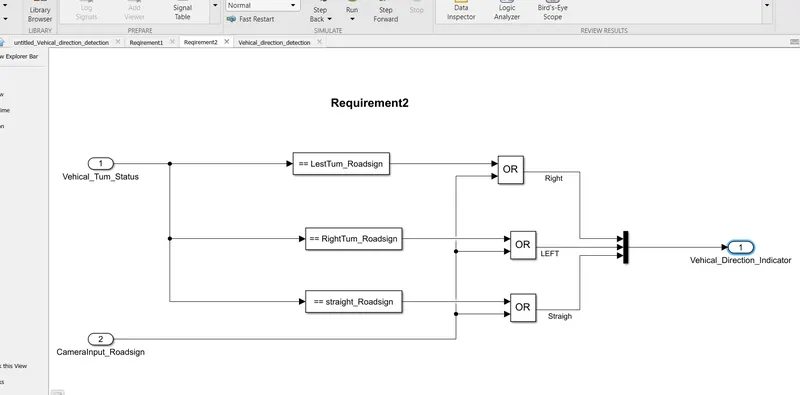
- Keep this requirement as a separate subsystem. Inputs to this requirement are local signal from requirement 1 (Signal Name: Vehicle_Turn_Status) & an input signal from camera (Signal Name: CameraInput_RoadSign), which confirms the occurrence of a road sign.
- Signal Vehicle_Turn_Status is compared against calibration values (Calibration Values: RightTurn_RoadSign, LeftTurn_RoadSign, Straight_RoadSign), if each of them is found equal, then each of the three corresponding output is compared against the camera input signal,
- Using a logical operator block, only one among them is finally given as output signal (Signal Name: Vehicle_Direction_Indicator).
Objective of Mini Project:
- Development of MATLAB Simulink model as per requirement.
- Tag the requirements to the simulink model; tagging requirement 1 & requirement 2 to their corresponding subsystems is fine.
- MBD compliant changes, Data Dictionary creation & code generation is added advantage, and that is not scope of this project.
- If choosing code generation, Storage class for Input signals: ImportedExtern; Storage class for Output signal: Export to File; Storage class for local signals: localizable; Storage class for calibration signals: Const.
Choose sample time for all signals as 0.01s
Signals & Calibration Data List:
|
Signal / Calibration Name |
Signal Type |
Data Type |
Dimension |
Min |
Max |
Initial Value |
Units |
|
SteeringWheel_YawDegreeInput |
Input |
Int16 |
1 |
-180 |
180 |
- |
Deg |
|
CameraInput_RoadSign |
Input |
Boolean |
1 |
0 |
1 |
- |
- |
|
Vehicle_Turn_Status |
Local |
Int16 |
1 |
-180 |
180 |
- |
Deg |
|
Right_Turn_AngularLimit |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
30 |
Deg |
|
Left_Turn_AngularLimit |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
-120 |
Deg |
|
Straight_Drive_Steering_Angle |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
0 |
Deg |
|
RightTurn_RoadSign |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
30 |
|
|
LeftTurn_RoadSign |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
-120 |
|
|
Straight_RoadSign |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
0 |
|
|
Vehicle_Direction_Indicator |
Output |
Boolean |
1 |
0 |
1 |
- |
- |
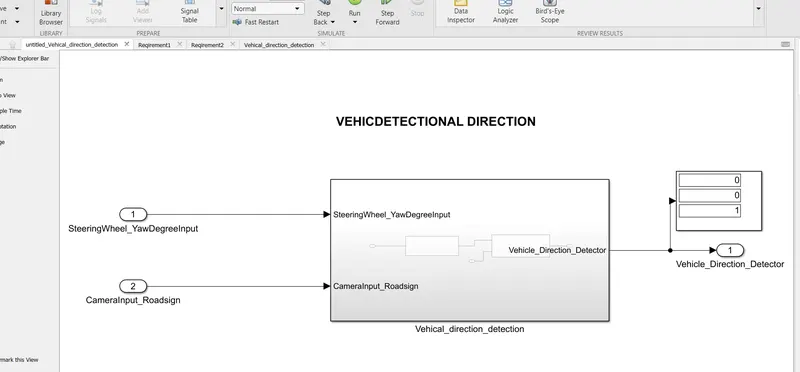
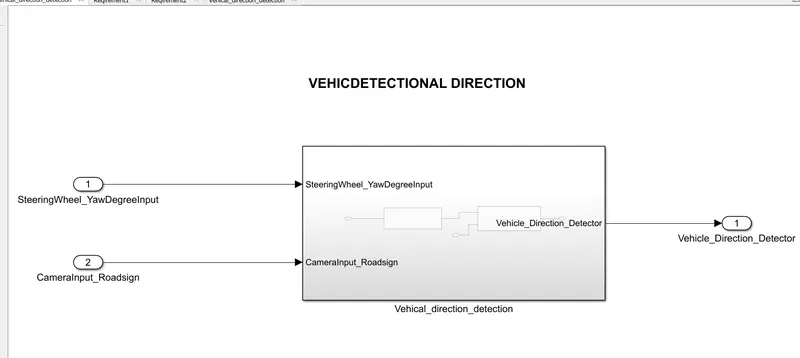
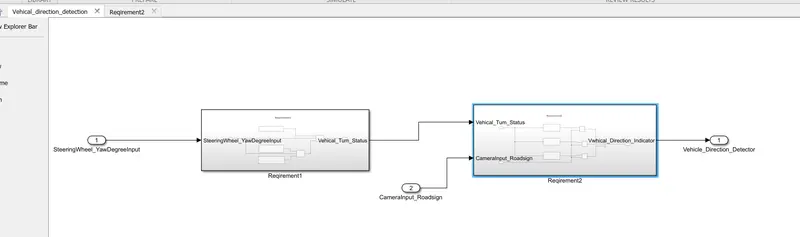
SIMULINK MODEL:-
SLDD file:-
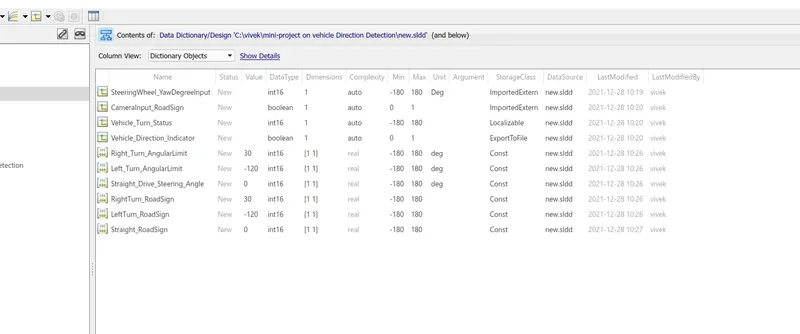
The SLDD file is create to store the calibration values and input and output signals.
Block used:-
Block used to dreate a model are
Input block: To provide the input signals
Output block : To provide the output signal
Constant block : To defone the calibration values
Logical operator blocks: OR blocks are used to compare and road sign with camera input to get boolean output
Switch block: To compare the input with the calibration values
Mux block : To combile the signals
Display block : To display the result
Procedure:-
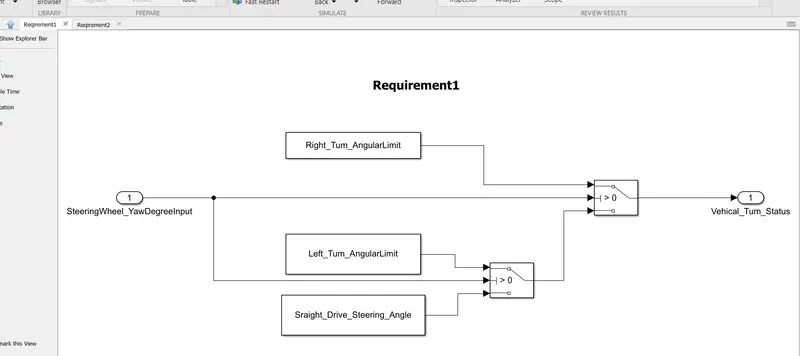
The logical in the requirement_1 is, if the input is>=30(becuse the initial value is 30)the vehicale will take the Right turn,else if the input is not_equal to zero (~=0) the vwhicale left turm,else stright_drive (if the input is equal to zero)
The input yaw rate is given to the middle port of the switch, and the threshold value is 30. if the input is greater than threshold value then the switch will takes the True condition (Right_turn_AngularLimit)else false condition .In the second switch the threshold value is zero ,if the threshold value is not equal to zero then the switch will takes the true condition(Left_Turn_AngularLimit)else take the false condition(Stright_Drive streeing_angle).This output from the second switch is given as a false condition to the frist switch.andthe output for the Requirement_1is"Vehical_Turn_status".
The logic in the Requirement_2 is to copare the "Vehicle_Turn_Status"(Output of requirement_1)with "Roadsign"and an input signal from camera to get the vehicle direction indication.
After comparision the "Vehicle_Turn_Status"if each of them is found qual,then each of the three corresponding output is compared against the camera input signal ,by using the 'logical OR' Block will get the true case and to take only one among them as output,the'Mux' block is used.
and the final output from the vehicle_detection model will indicates the vehicle_direction indication.
Next by adding the SLDD_file to model and by loading the calibration value and input/output values are defined.
By running the simulation will get the vehicle direction.
Result:-
- The signs are in way that Right, Left and straight respectively.
- As the ouput is boolean,if we get the output as(0,0,1),Then the vehicle is moving in the straight drive.
- If the output as(1,0,0),Then the vehicle is taking in the Right turn
- If the output as(1,0,1),Then the vehicle is taking in the Right turn