Project 1
PROJECT1:
Code of the 'Project1_IntiFile':
clear all
close all
clc
%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%
%% Skill-Lync -> Hybrid Drives Development
% Project 1 - Conventional Vehicle Model
% By - Himalaya Singh
% Description:
%% Initialization File
% Initialization file for loading the variables for the Conventional vehicle simulation model
%% Vehicle Parameters
M = 1500; % Vehicle weight [kg]
Cr = 0.015; % Rolling resistance coefficient
Rw = 0.35; % Rolling radius [m]
Cd = 0.33; % Drag coefficient
Af = 2; % Frontal area [m2]
rhoa = 1.225; % Air density [kg/m3]
Vwind = 0; % Wind velocity [kmph]
g = 9.81; % Gravitational acceleration [m/s2]
theta = 0; % Slope [deg]
myu_road_tire = 1; % Coefficient of friction between tire - road interface
%% Powertrain Parameters
FDR = 3.73; % Final Drive Ratio / Diff Ratio
DiffEff = 0.99; % Differential efficiency (assumed independent of operating conditions)
NumGear = 4; % Number of gears in transmission
TransGear = [1:NumGear]; % Transmission Gears
TransRatio = [3.06, 1.62, 1, 0.7]; % Corresponding Transmission ratios
TransEff = 0.90; % Transmission efficiency (assumed independent of operating conditions)
TC_SR = [0, .5, .6, .7, .8, .87, .92, .94, .96, .97, 1]; % Torque Converter Speed Ratio (Matlab default) -> TurbSpd/PumpSpd
TC_TR = [2.232, 1.5462, 1.4058, 1.2746, 1.1528, 1.0732, 1.0192, 1, 1, 1, 1]; % Torque Converter Torque Ratio (Matlab default) -> TurbTrq/PumpTrq
TC_Cf = 1e-4 * [.72558, .66322, .63463, .59042, .51331, .4144, .29287, .22444, .12186, .04386, 0]; % Torque Converter Capacity Factor (Matlab default) -> PumpTrq/PumpSpd^2 [Nm/rpm^2]
load Vehicle_Data/Engine_data_1_9L_Saturn_95kW
load Vehicle_Data/Trans_Shift_map
%% Driver Parameters
Kp = 10; % P gain for driver PI model
Ki = 1; % I gain for driver PI model
Drive_Cycle_Select = 1; % Drive cycle selection
% Drive cycle values in m/s
if Drive_Cycle_Select == 1
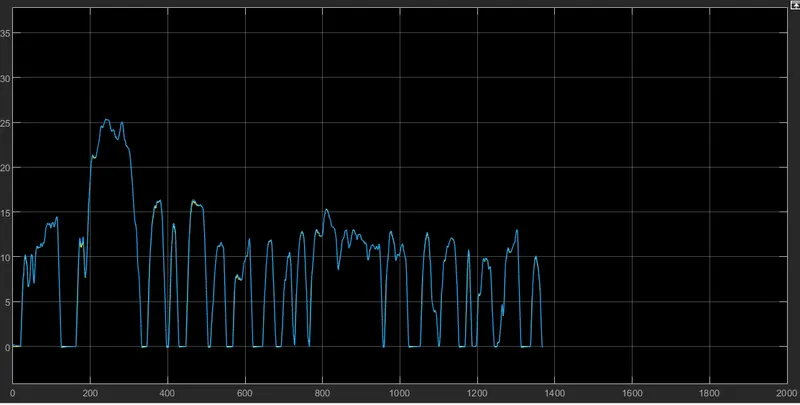
load DriveCycles/UDDS;
elseif Drive_Cycle_Select == 2
load DriveCycles/HWFET;
elseif Drive_Cycle_Select == 3
load DriveCycles/FTP;
elseif Drive_Cycle_Select == 4
load DriveCycles/US06;
elseif Drive_Cycle_Select == 5
load DriveCycles/NEDC;
elseif Drive_Cycle_Select == 6
load DriveCycles/WLTP;
end
time_end = cyc_time(end);
vel_end = cyc_vel(end);
Vehicle Model:
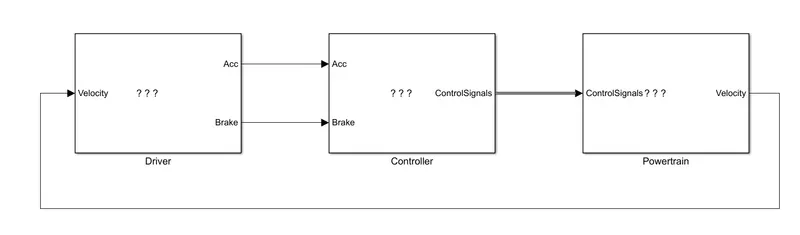
Driver:
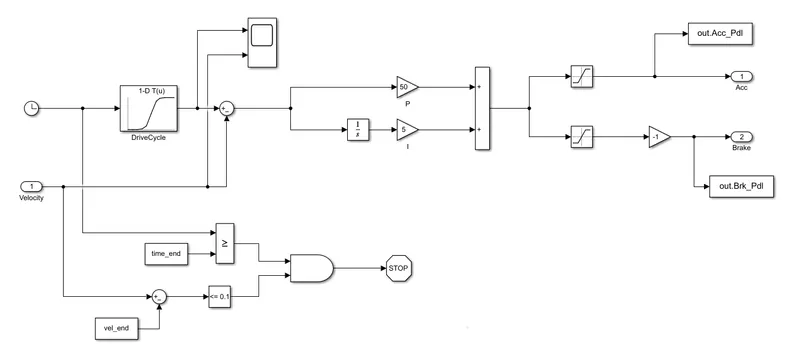
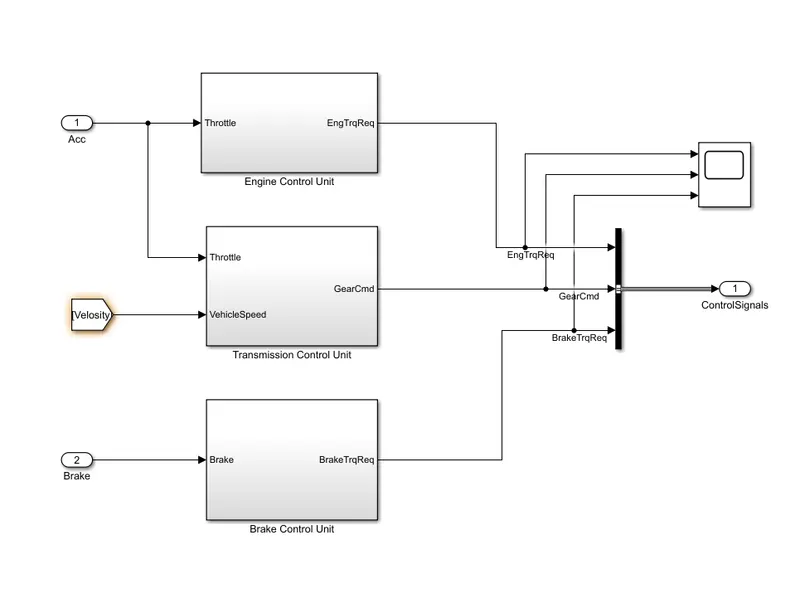
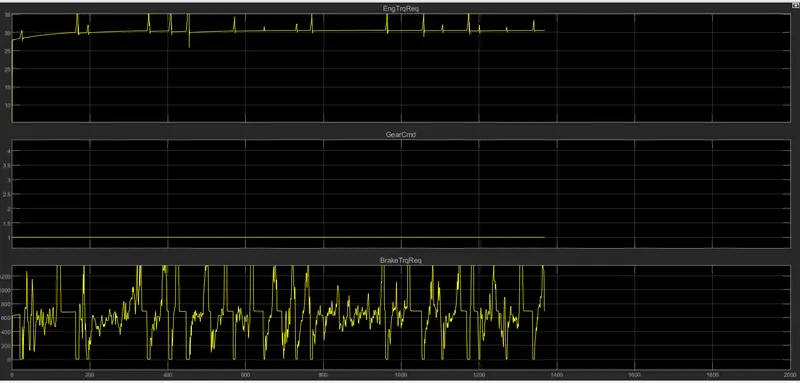
Controller:
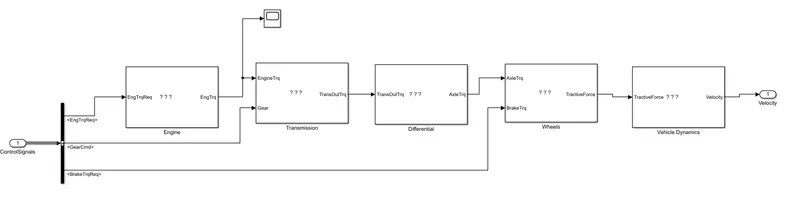
Power Train:
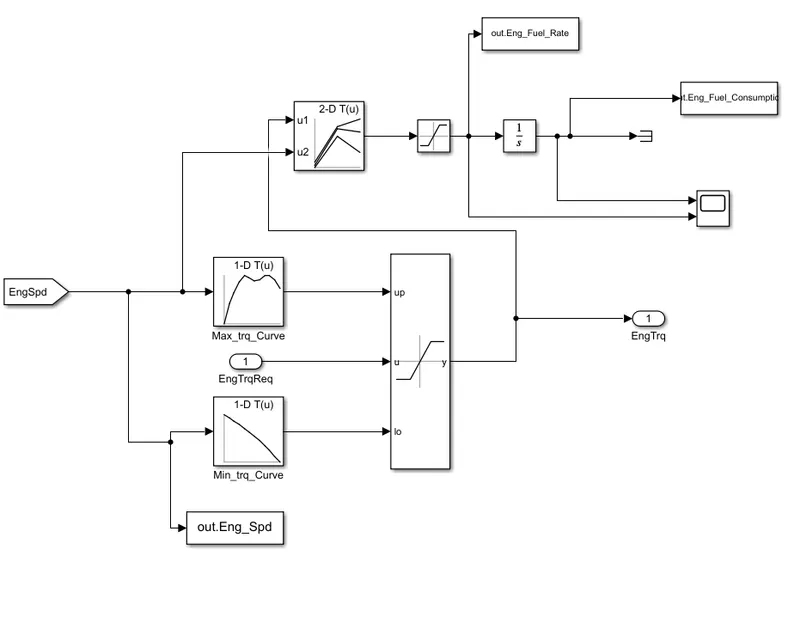
Engine:
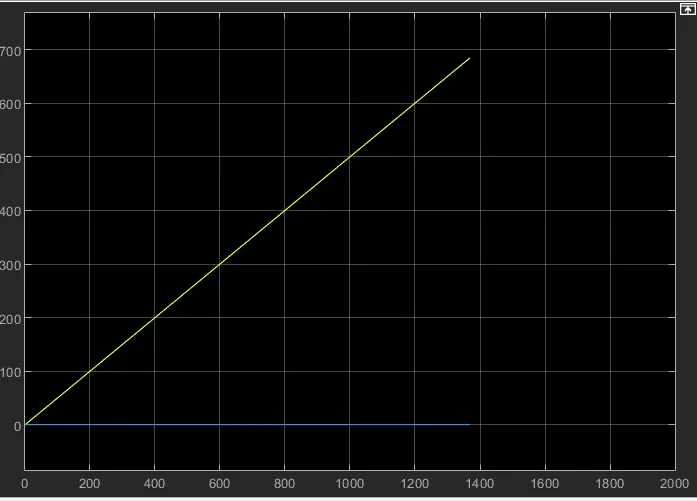
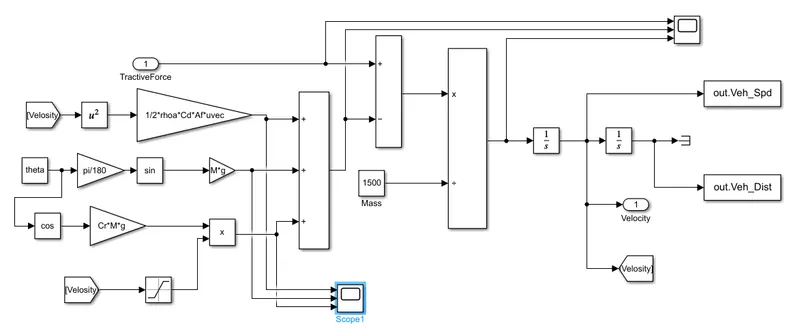
Now, the Vehicle dynamics block is developed using the equations
Equations for aerodynamic drag, rolling resistance, and gradient are created and summed up to get the road load
Road load is subtracted from the tractive force to get the force
This force is then divided by the mass to get the acceleration component
Integrator is used to integrate the acceleration and get the velocity component
Road load and velocity are multiplied to get the power required for the vehicle
Power is then multiplied by the total time to get the energy required
All the blocks of velocity, acceleration, road load, the power required, and energy required are attached to the 'scope' block to see the output variations with respect to the time
Vehicle Dynamics:
Transmission:
Differential:
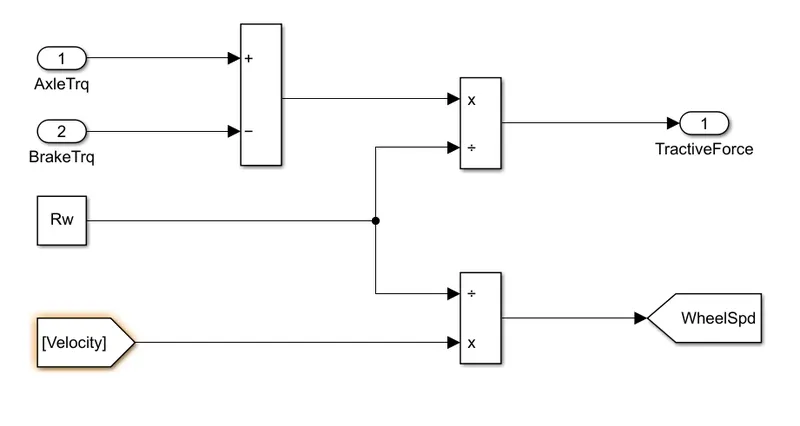
Wheels:
Code of 'Project1_ProcessingFile':
%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%
%% Skill-Lync -> Hybrid Drives Development
% Project 1 - Conventional Vehicle Model
% By - Himalaya Singh
% Description:
% The following file is to use with the Initialization file and Simulink
% results for post-processing of the data.
% The file is incomplete and has some examples of how the data is imported
% into a readable format, data analysis, and plotting examples.
% Based on the project task, use commands in a similar format as given
% below, to analyze the data and generate the required plots.
% You can change variable names if desired
%% Post-Processing File
% File for post-processing the Conventional vehicle simulation model data
%% Renaming variables
Time = out.tout;
Acc_Pdl = out.Acc_Pdl; % Accelerator pedal [%]
Brk_Pdl = out.Brk_Pdl; % Brake pedal [%]
Gear_Cmd = out.Gear_Cmd; % Transmission gear
Trans_In_Spd = out.Trans_In_Spd*30/pi; % Transmission input speed [rpm]
Trans_Out_Spd = out.Trans_Out_Spd*30/pi;% Transmission output speed [rpm]
Eng_Trq = out.Eng_Trq; % Engine brake torque [Nm]
Eng_Spd = out.Eng_Spd*30/pi; % Engine speed [rpm]
Eng_Fuel_Consump = out.Eng_Fuel_Consumption; % Engine fuel consumption [g]
Veh_Dist = out.Veh_Dist/1000; % Distance traveled by vehicle [km]
Veh_Spd = out.Veh_Spd*18/5; % Vehicle speed [kmph]
Eng_Speed = Eng_Spd*30/pi;
Veh_Distance = Veh_Dist/1000;
Veh_Speed = Veh_Spd*18/5;
Eng_Spd=0.1;
Eng_Trq=10;
%% Data Analysis
Eng_Pwr = Eng_Spd*pi/30*Eng_Trq/1000; % Engine brake power [kW]
rho_petrol = 0.7197; % Density of petrol [kg/L]
kmpl = Veh_Dist(end)/(Eng_Fuel_Consump(end)/1000/rho_petrol); % Fuel economy [kmpl]
%% Plotting vehicle characteristics time trace
figure()
subplot(3,1,1)
hold on
grid on
plot(Time, Acc_Pdl, 'linewidth', 1, 'Color', 'black');
plot(Time, Brk_Pdl, 'linewidth', 1, 'Color', 'red');
ylabel('Pedal [%]')
xlim([0, Time(end)]);
legend('Accel','Brake');
subplot(3,1,2)
hold on
grid on
plot(Time, Trans_In_Spd, 'linewidth', 1, 'Color', 'black');
plot(Time, Trans_Out_Spd, 'linewidth', 1, 'Color', 'red');
ylabel('Speed [rpm]')
xlim([0, Time(end)]);
ylim([0, 6000]);
legend('Trans Input','Trans Output');
subplot(3,1,3)
hold on
grid on
plot(Time, Gear_Cmd, 'linewidth', 1, 'Color', 'black');
xlim([0, Time(end)]);
xlabel('Time [s]');
ylabel('Gear');
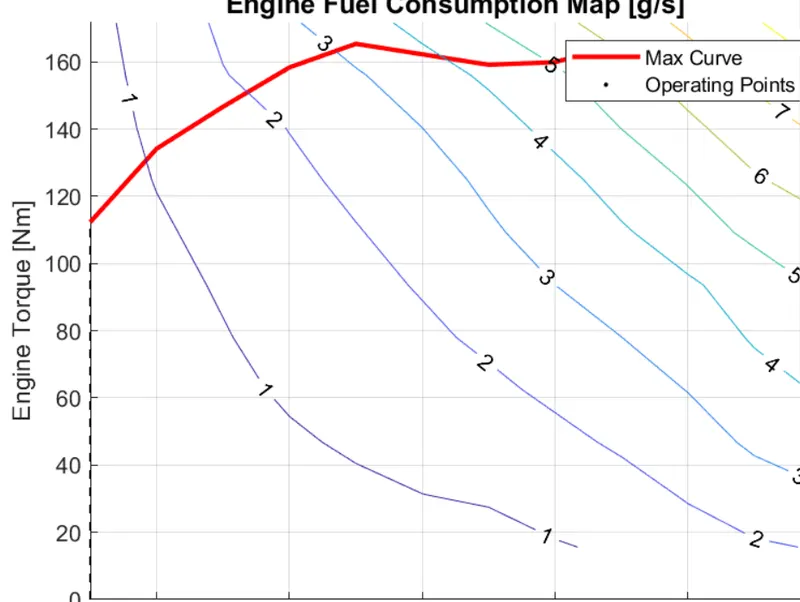
%% Plotting engine operating points on the engine fuel map
figure('Name','Engine Operating Points');
hold on
grid on
title('Engine Operating Points','fontsize',12);
p1=plot(Eng_map_spd*30/pi,Eng_max_trq,'linewidth',2,'color','r');
p2=line([Eng_map_spd(end)*30/pi Eng_map_spd(end)*30/pi],[0 Eng_max_trq(end)]);
set(p2,'linewidth',1,'linestyle','--','color','k');
p3=line([Eng_map_spd(1)*30/pi Eng_map_spd(1)*30/pi],[0 Eng_max_trq(1)]);
set(p3,'linewidth',1,'linestyle','--','color','k');
[c,h] = contour(Eng_map_spd'*30/pi,Eng_map_trq,Eng_fuel_map');
clabel(c,h);
xlabel('Engine Speed [rpm]');
ylabel('Engine Torque [Nm]');
title('Engine Fuel Consumption Map [g/s]');
p4 = plot(Eng_Spd,Eng_Trq,'.','color','k');
legend([p1 p4],{'Max Curve','Operating Points'});
axis([Eng_map_spd(1)*30/pi Eng_map_spd(end)*30/pi 0 Eng_map_trq(end)]);
The fuel economy number (kmpl) is found from that program using the formula
Engine, transmission input, transmission output, and wheel speed are plotted on one graph with respect to the time
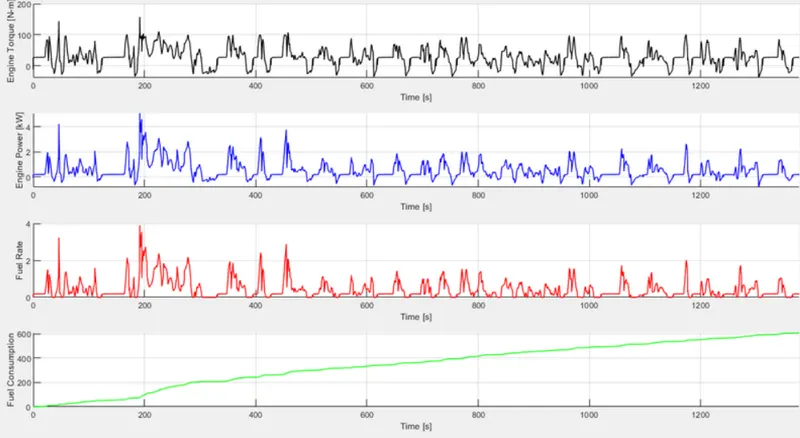
Engine torque, engine power, fuel rate, and fuel consumption are plotted wrt the time using subplots
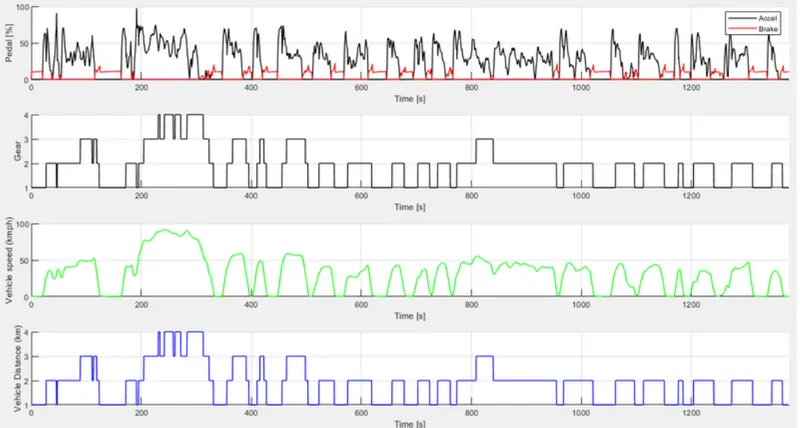
Accelerator and brake pedal, gear command, vehicle speed, and vehicle distance are plotted wrt the time using subplots
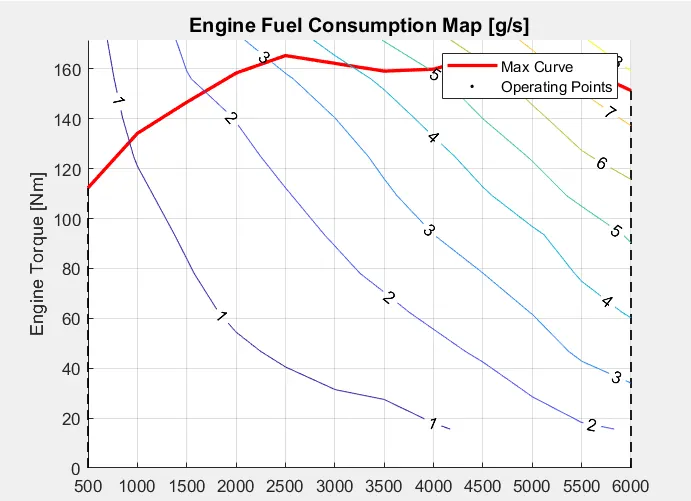
The engine operating points are plotted on the engine fuel map
A similar procedure is followed by changing the drive cycle to 2 i.e. HWFET
Results:
Fuel economy numbers:
As we see, the fuel economy is high in HWFET compared to UDDS, it is because, in urban driving, the vehicle encounters more
traffic and it has to stop for fewer distances and it consumes more fuel at the starting. In HWFET, the vehicle encounters no
traffic and it moves without the use of too much braking, so it will have more fuel economy number
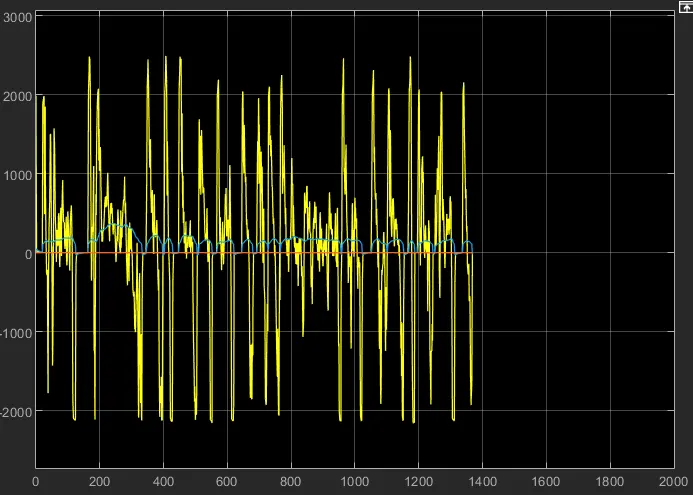
Engine, transmission input, transmission output, and wheel speed plot
UDDS drive cycle:
HWFET drive cycle:
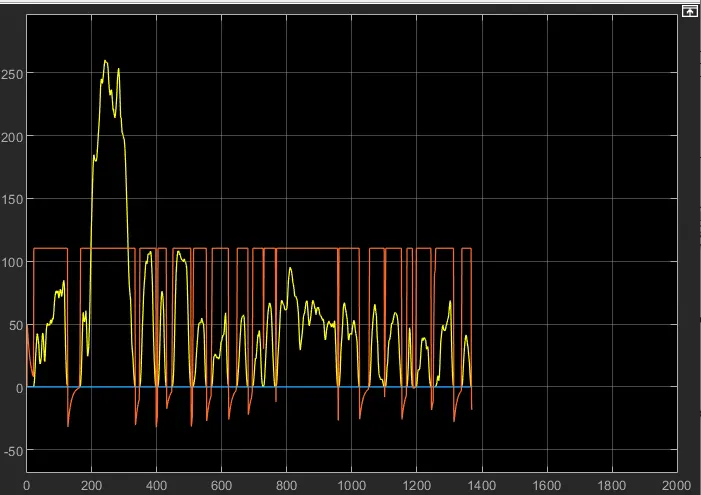
We can see that the graph has more fluctuations in UDDS compared to the HWFET cycle because UDDS has more starts and
stops but HWFET does not have too many starts and stops
Braking is high in UDDS when compared to HWFET due to traffic
Peak engine power reached in UDDS is nearly 4800 RPM and that in HWFET is 3800 RPM at the start, because, in UDDS, the vehicle requires more power to start from the initial condition.
Engine torque, engine power, fuel rate, and fuel consumption plot:
UDDS drive cycle:
HWFET drive cycle:
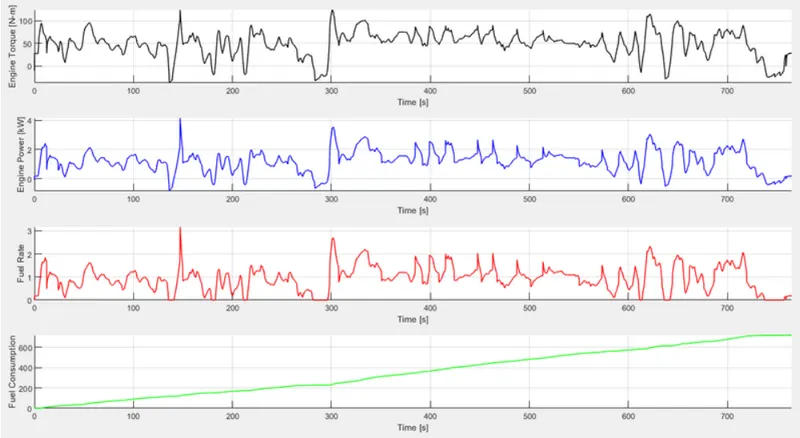
Vehicle consumed more power in the UDDS compared to the HWFET cycle because it has too many starts and stops compared to
HWFET. When starting from the initial condition vehicle requires more power
Engine torque is also high in UDDS because while starting from rest, the vehicle requires more torque to overcome the static
friction
The fuel rate is high in HWFET because the vehicle will be in continuous movement, it consumes more fuel
But, fuel economy will be high in HWFET compared to UDDS because there are many stops and starts in UDDS and more fuel is consumed when the vehicle is in an idle position
Accelerator and brake pedal, gear command, vehicle speed, vehicle distance plot
UDDS drive cycle:
HWFET drive cycle:
For UDDS, the accelerator and the brake pedal have more fluctuations because of frequent starts and stops. But in HWFET, the
brake pedal fluctuations are almost near to the zero line as there will be no frequent stops
UDDS cycle mostly runs on 1st, 2nd gears, and uses 3rd, 4th gears very rarely as it does not achieve high speeds in that traffic. In the HWFET cycle, the vehicle mostly runs on 3rd, 4th gears as it will be moving at high speeds. It uses 1st, 2nd gears very frequently when braking is required
Obviously, the vehicle speeds will be high in HWFET compared to UDDS. UDDS also has more fluctuations in the speed due to
frequent braking
The distance travelled in the given time will be high in HWFET than UDDS because of the traffic barrier in UDDS
Engine operating points on the engine fuel map
UDDS drive cycle:
HWFET drive cycle: