Project 1
Aim
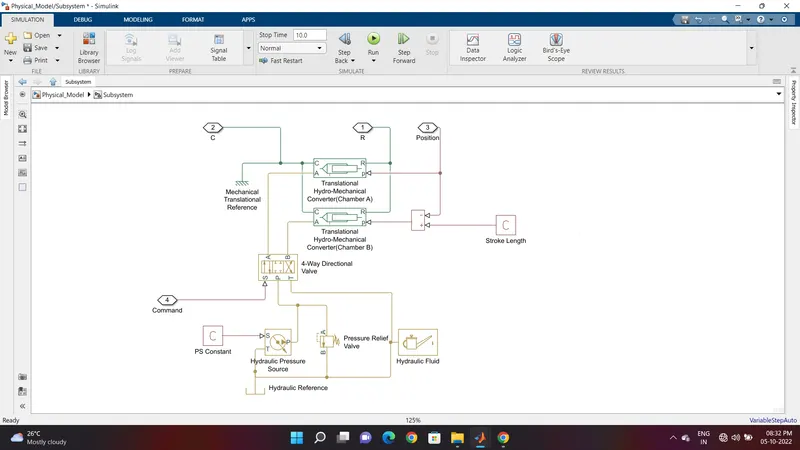
Develop a double-acting actuator model using Simscape Multibody and Simscape components. The mechanical system of the cylinder needs to be built using Simscape Multibody library components/blocks, and the hydraulic system needs to be modeled using Simscape library physical components.
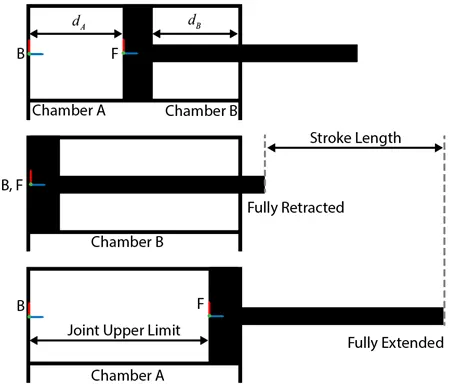
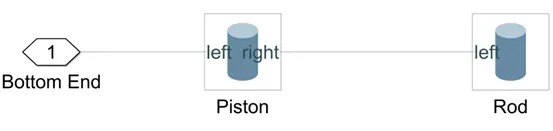
The mechanical part of the system in Simscape Multibody.To provide the translational degree of freedom for the piston, use a Prismatic Joint block. To easily calculate the lengths of the chambers A and B, you can attach the base frame (B) and follower frame (F) of the joint to the centers of the left inner surface of the chamber A and the left surface of the piston, respectively. Make sure that the Z-axes of the B and F frames are aligned and both point toward chamber B. The length of the chamber A, dA, is the position output of the joint block, and the length of the chamber B, dB, equals the difference of the stroke length and dA. To ensure that the piston does not travel beyond the ends of the cylinder, you can specify the upper and lower position limits of the Prismatic Joint block.
Double Acting Hydraulic Actuator System
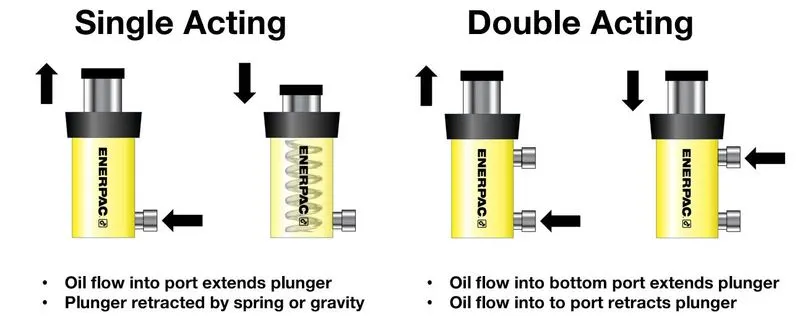
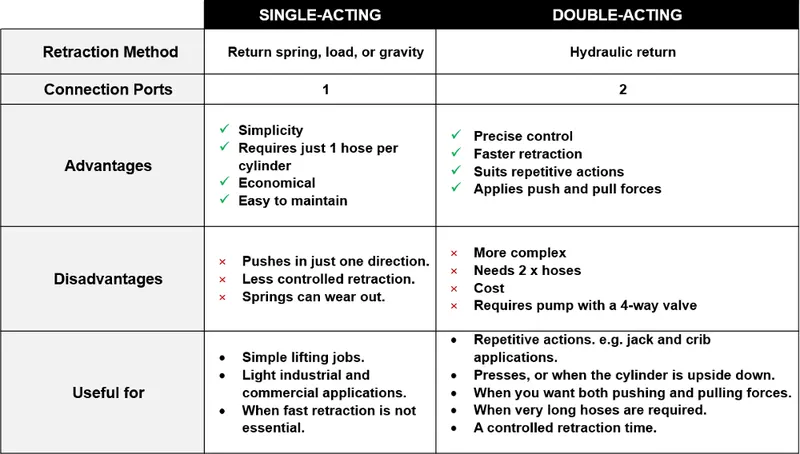
In a double-acting hydraulic cylinder, the plunger retracts when hydraulic fluid is pumped under high pressure into the top port, forcing the plunger back to its original position. This can be done quickly, if required, or very gradually with precise control.
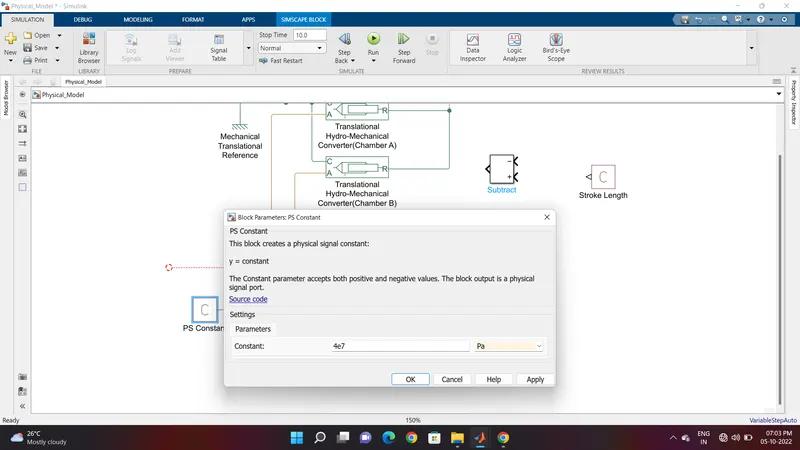
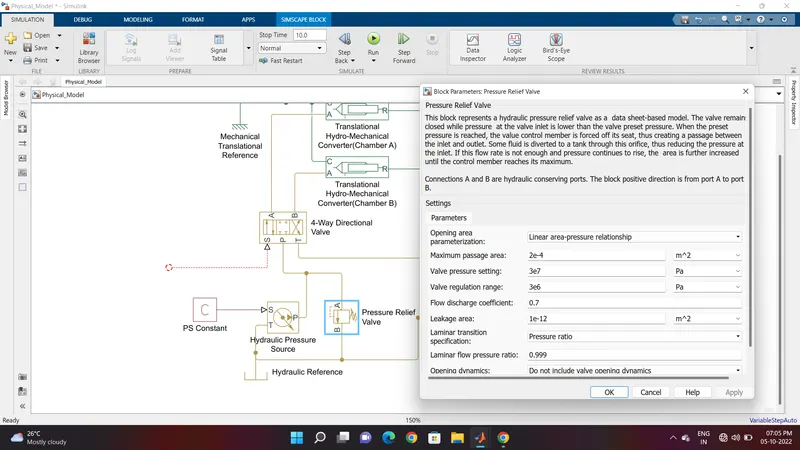
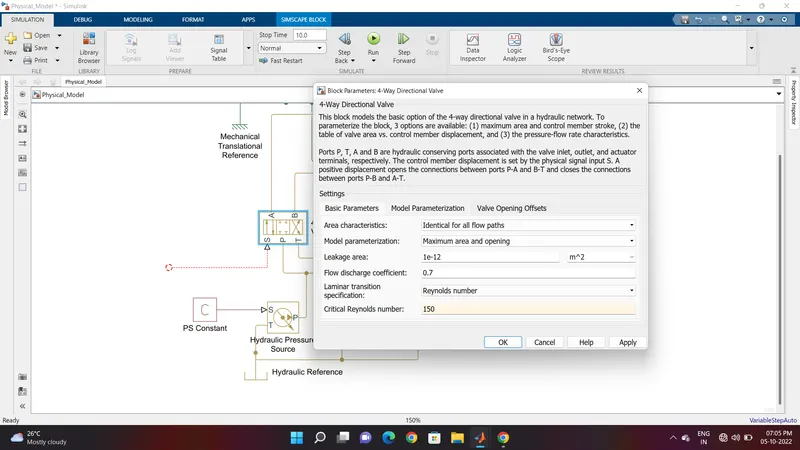
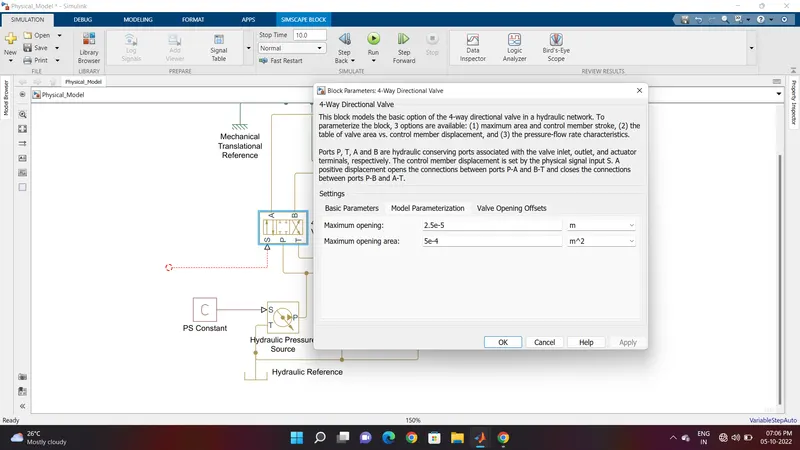
Physical Model
Define Part Parameters
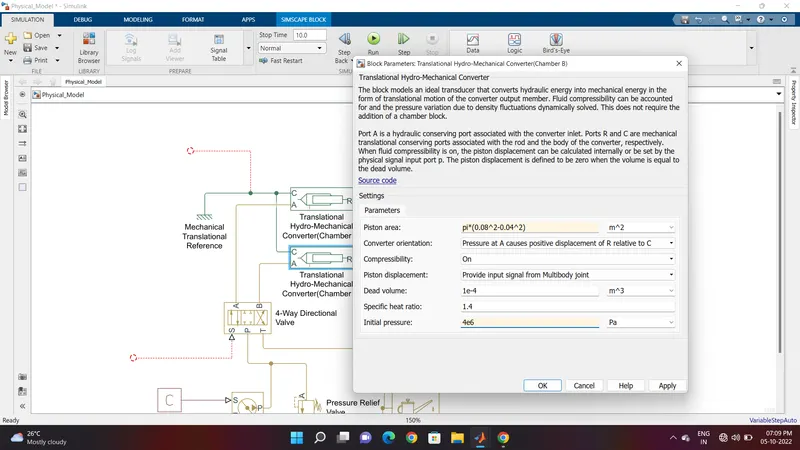
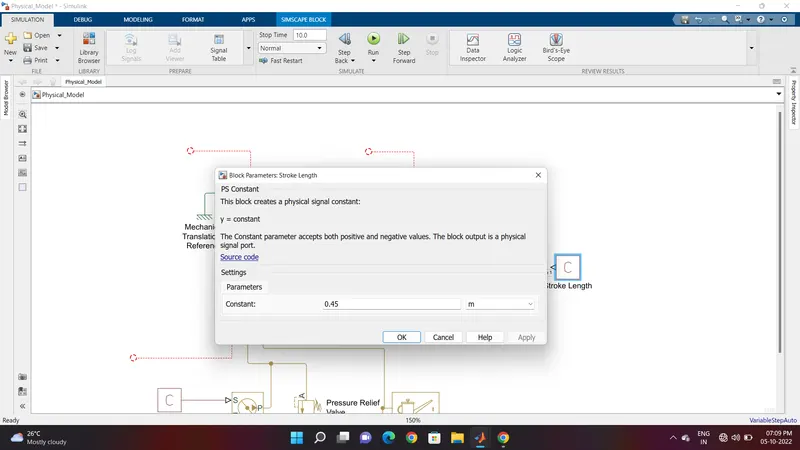
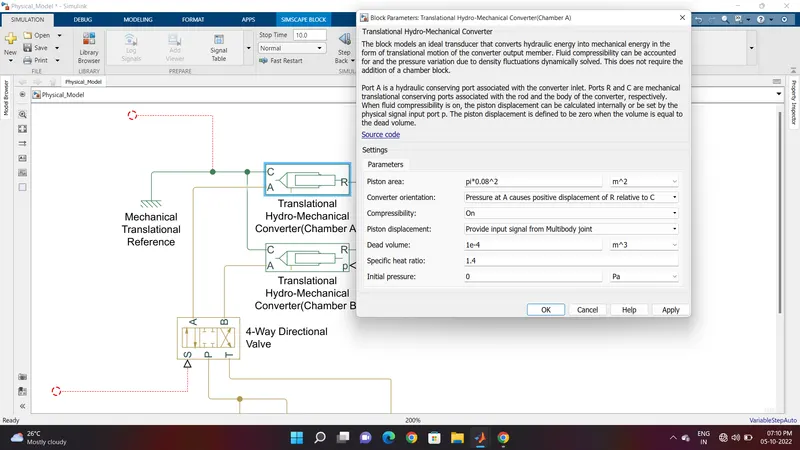
Mechanical Model
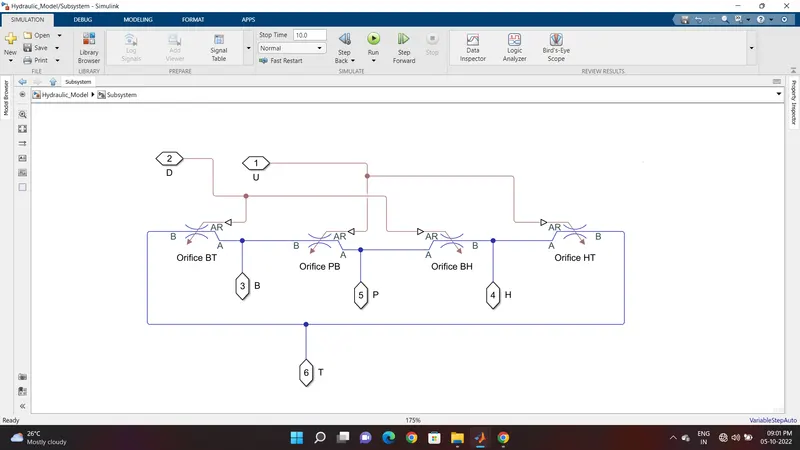
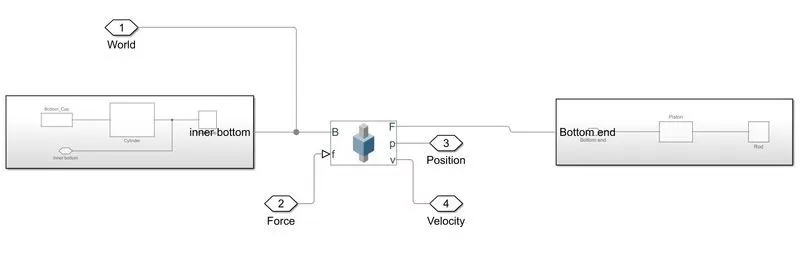
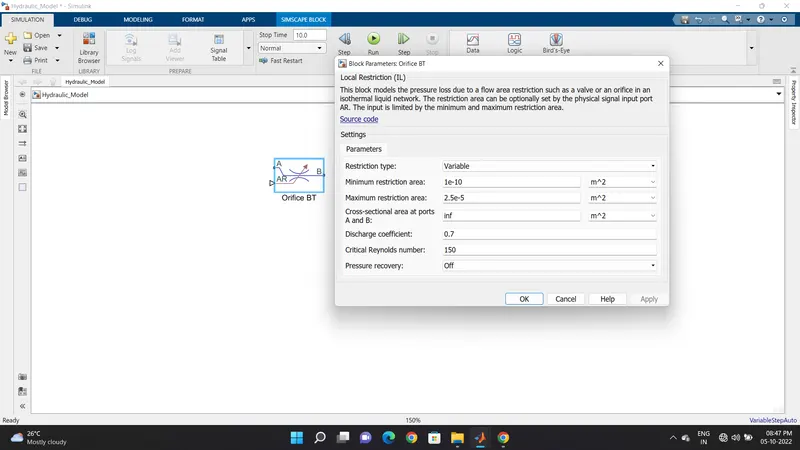
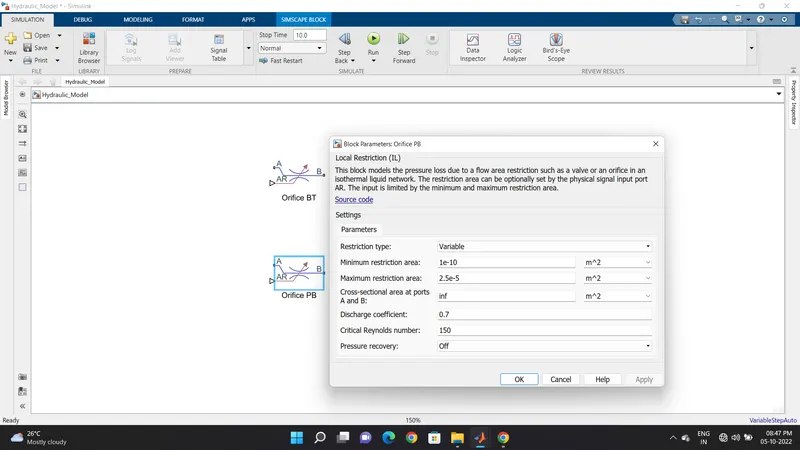
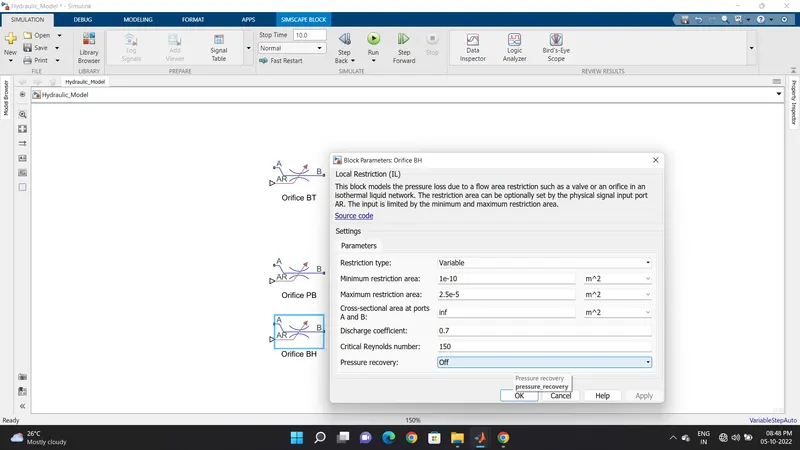
Cylinder Assembly
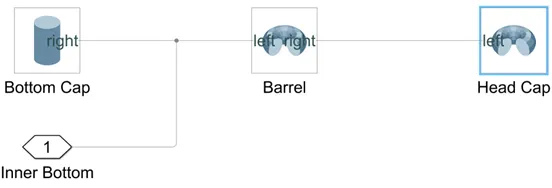
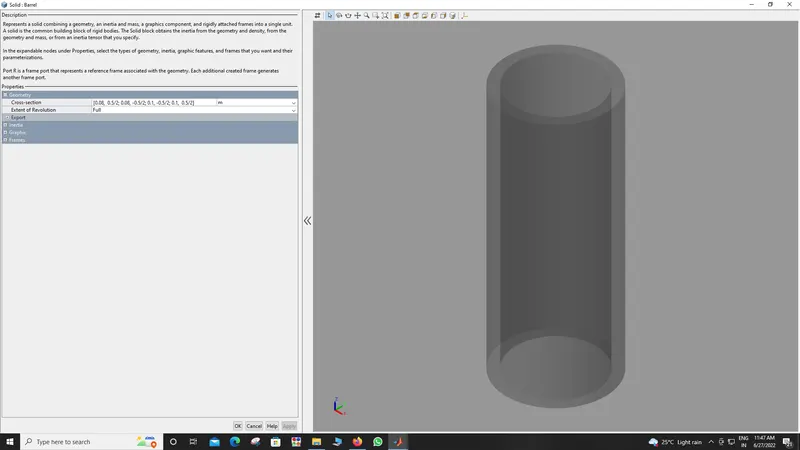
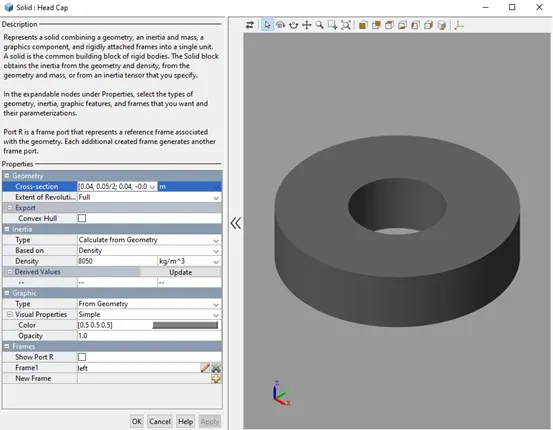
Define Part Parameters
Piston Assy
Position Of Actuation
Moment Attach In File