Project 1
Develop a Double-acting actuator model in SIMULINK using Simscape blocks. The mechanical system of the cylinder needs to be built using Simscape Multibody library components / blocks and the hydraulic system needs to be modelled using Simscape Hydraulics library physical components / blocks.
Objectives:
- Design the mechanical and hydraulic systems of the double-acting actuator.
- Simulate its behavior in Simulink using Simscape components and Mechanics Explorer using Multibody.
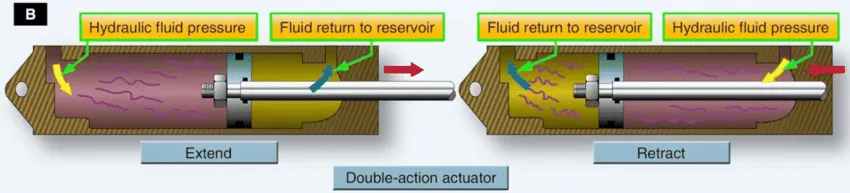
A Double-Acting Hydraulic Actuator uses hydraulic pressure to control both extension and retraction of the piston inside a cylinder. This actuator type is widely used in systems like construction machinery, industrial robots, and aircraft control surfaces, where precise control over motion is needed.
Cylinder Model :
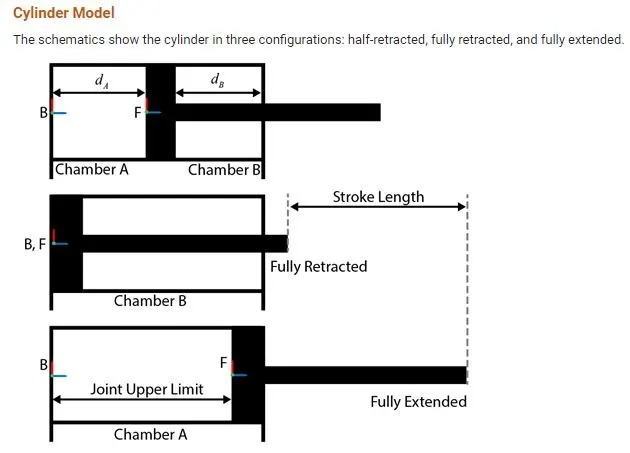
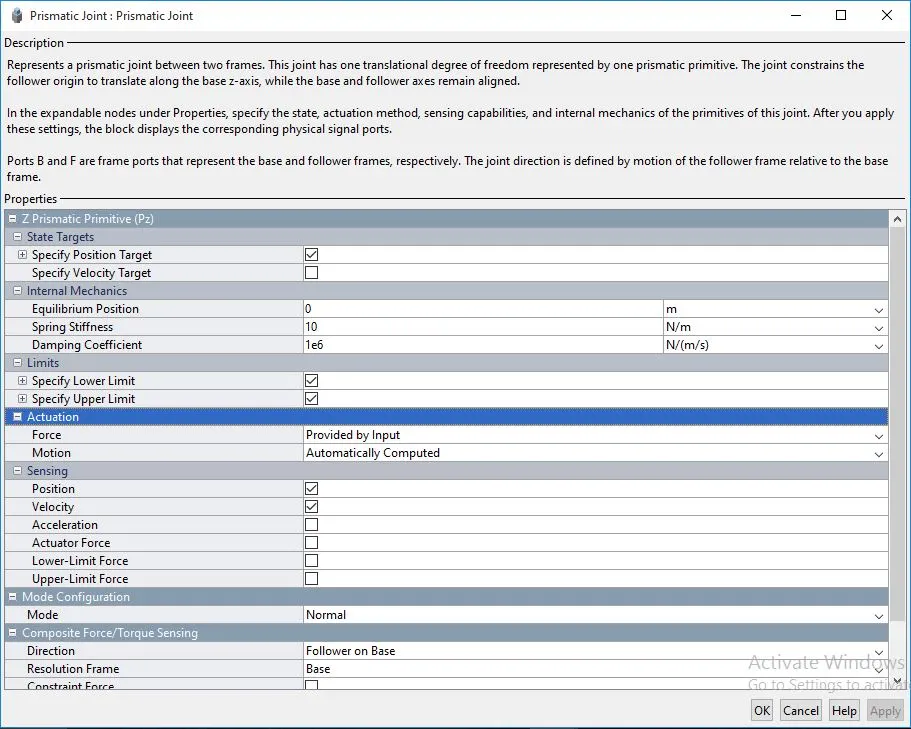
The Double-Acting Hydraulic Cylinder block contains mechanical and hydraulic subsystems. The mechanical subsystem models the piston and barrel. A Prismatic Joint block provides the translational degree of freedom needed for piston extension and retraction. The piston's range of motion is constrained using joint limits. The hydraulic subsystem contains two Translational Mechanical Converter blocks from the Isothermal Liquid (IL) foundation library in Simscape. These blocks exchange velocity and force information with the prismatic joint via a Translational Multibody Interface block. In addition, both of the converter blocks are configured to accept a physical position signal from the prismatic joint. These connections ensure that the state of the hyraulic chambers in the converter blocks are always consistent with the state of the prismatic joint.
SimScape Model
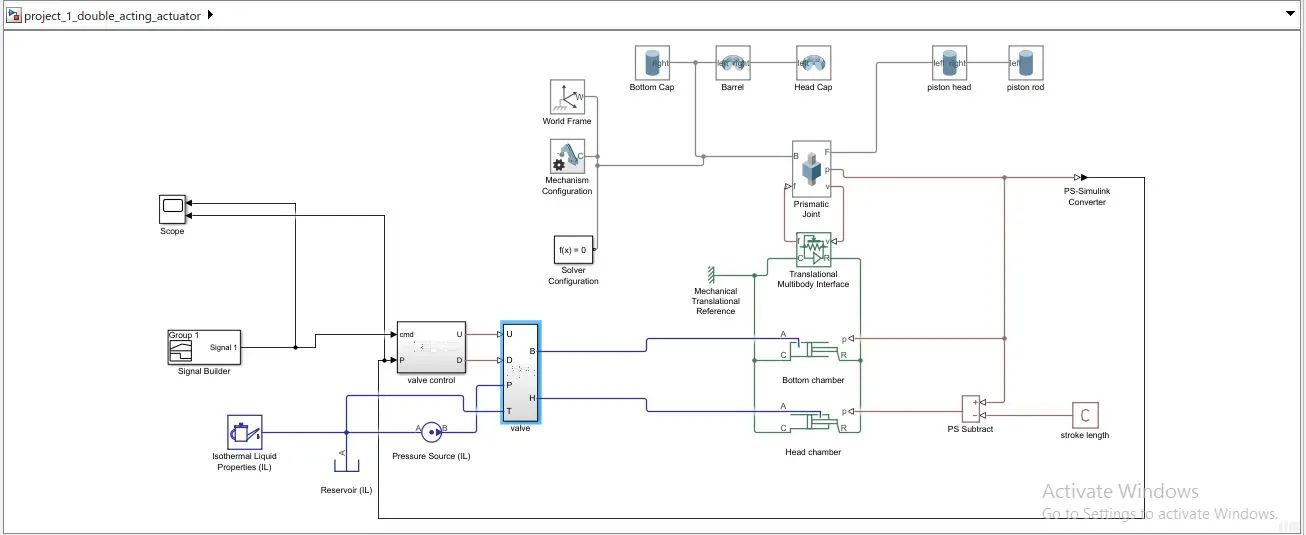
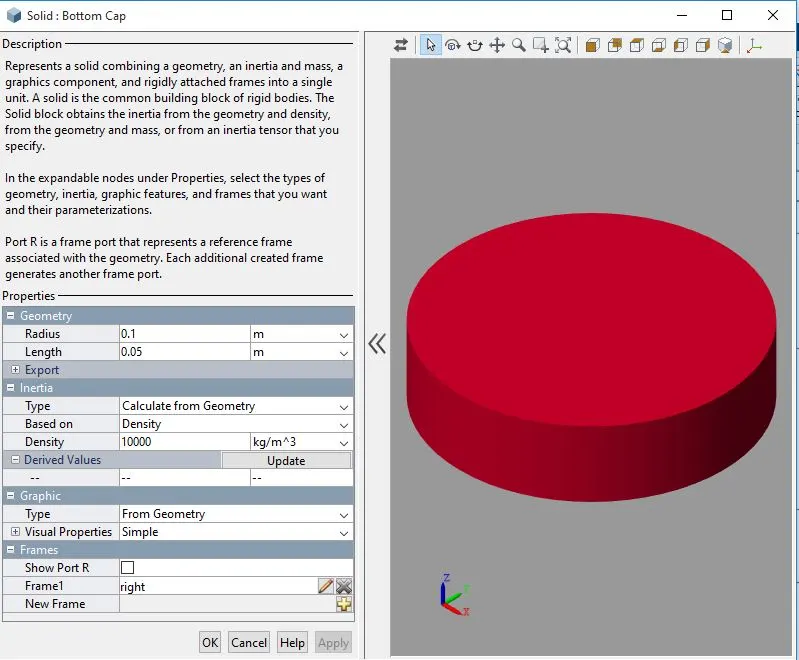
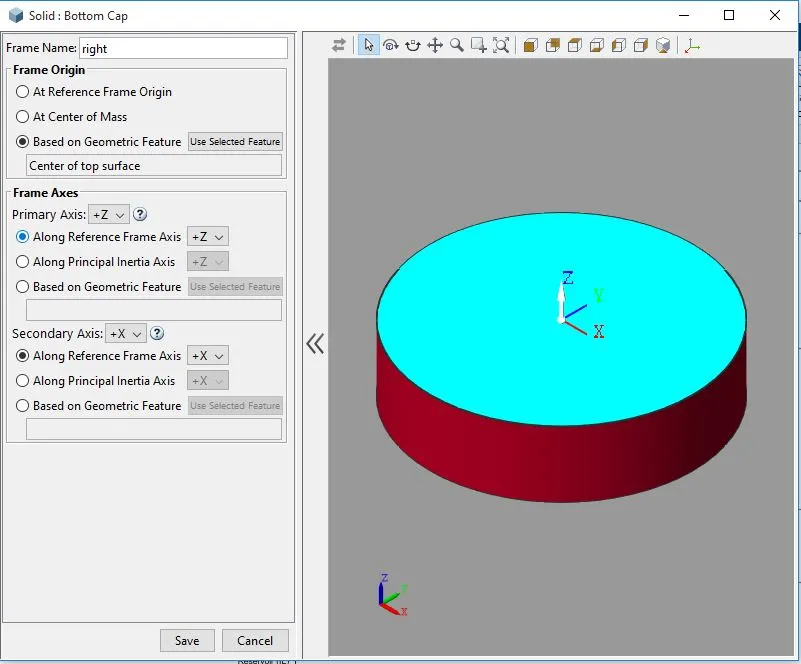
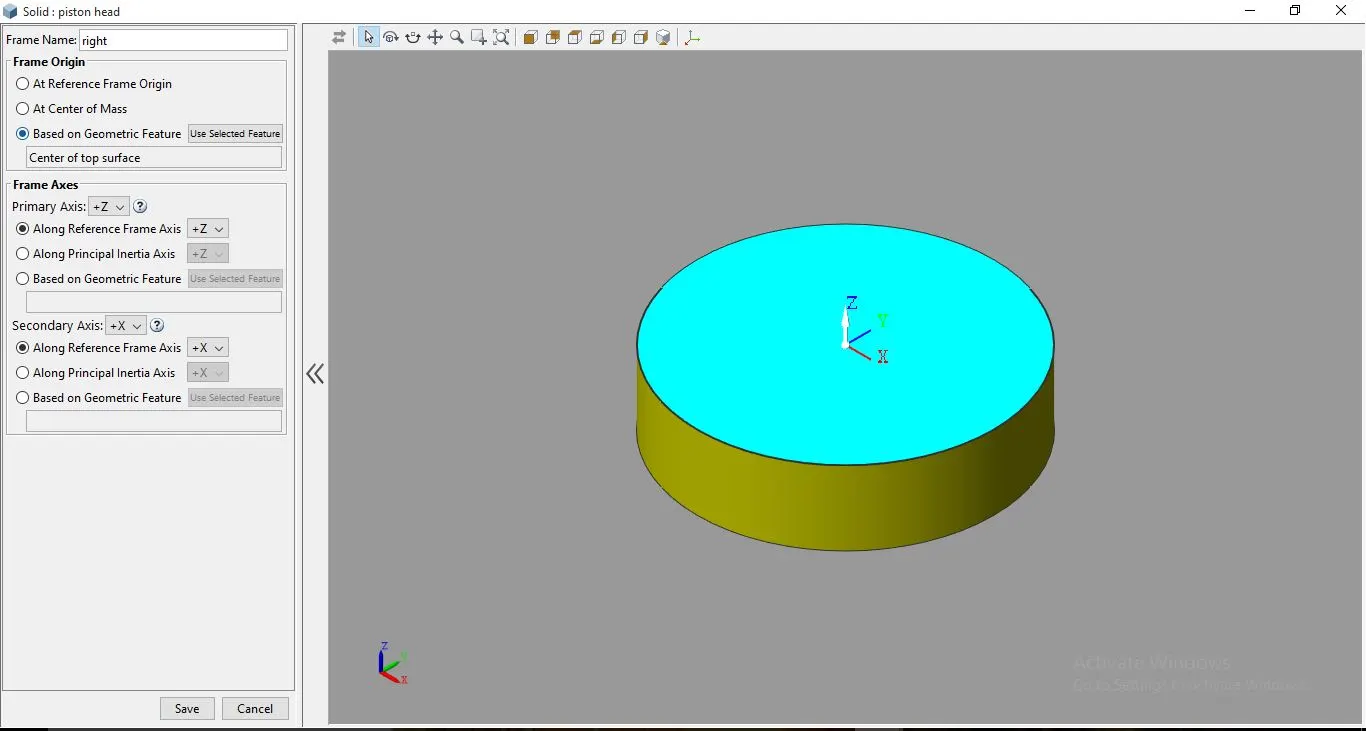
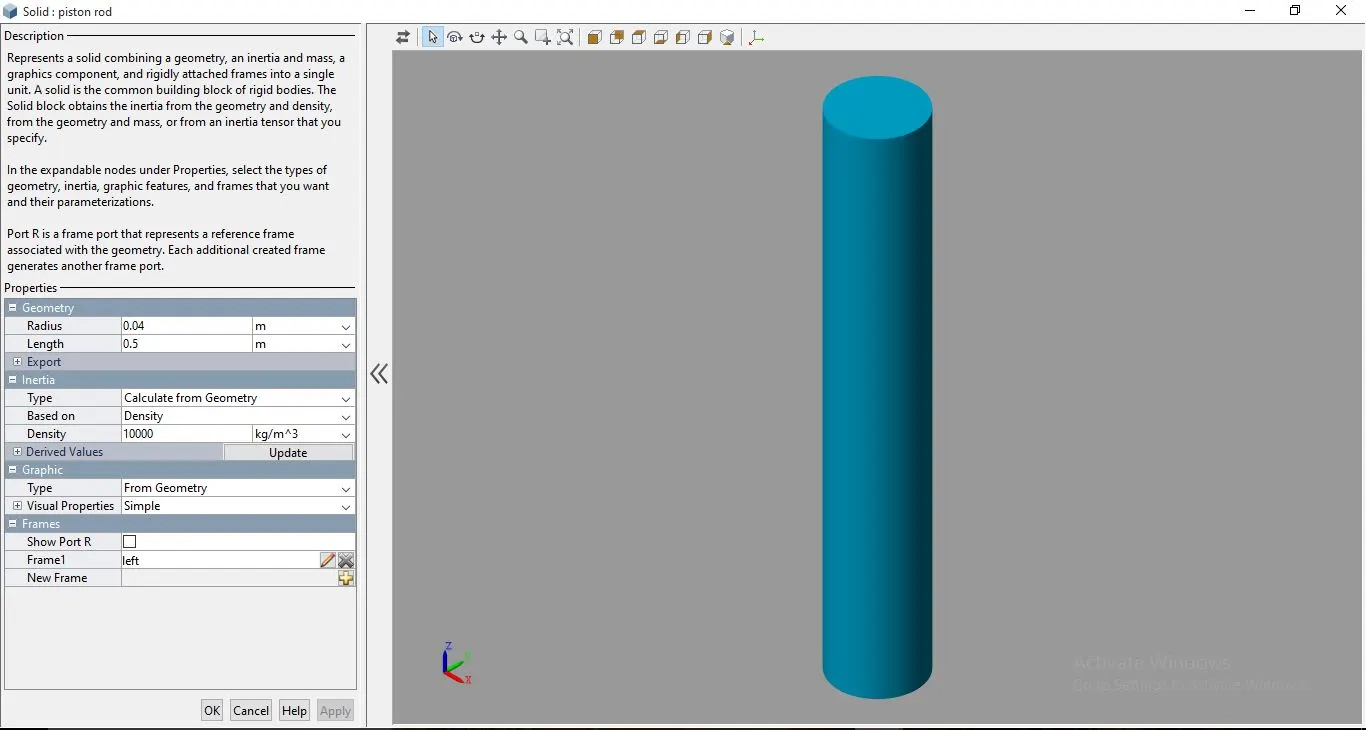
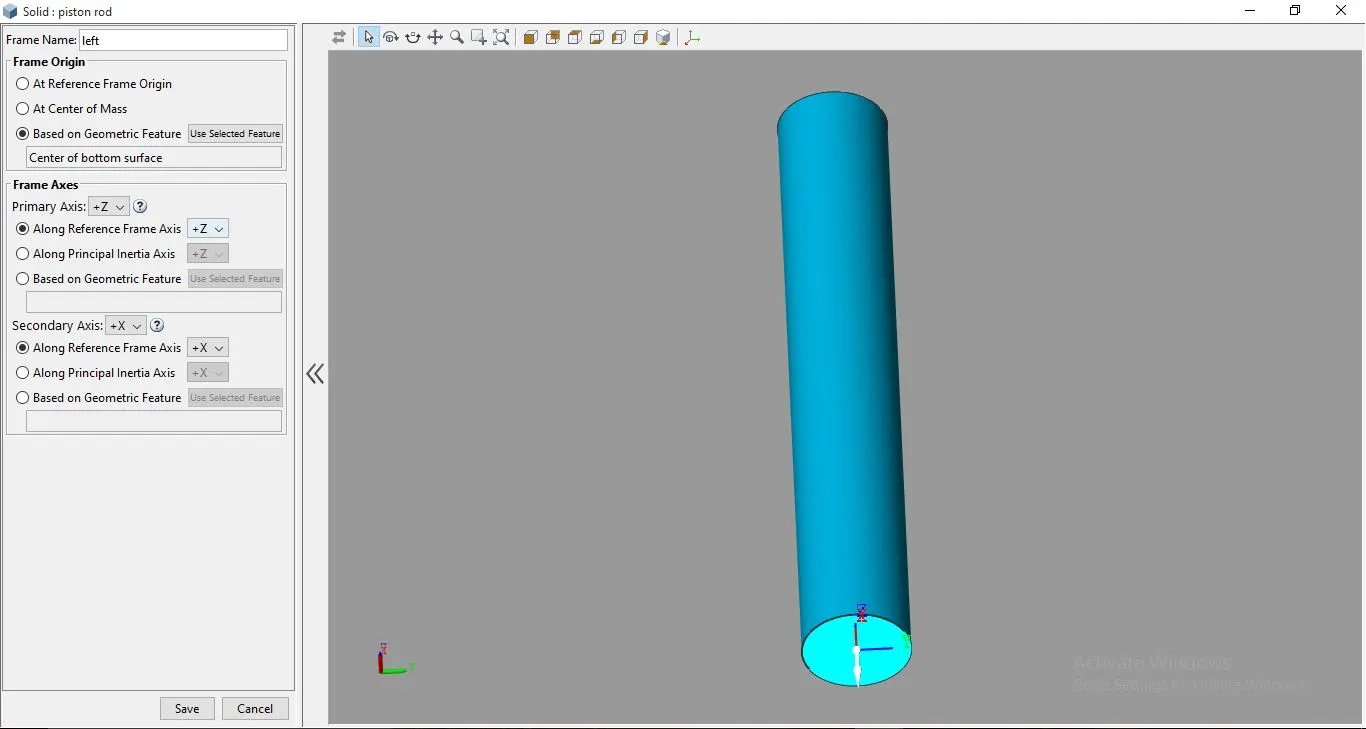
In multibody components Solid cylinder blocks are used for the Bottom cap and Head cap of the actuator following solid revolute as Barrel in which the piston will move . here for results observation opacity is taken as less. Piston head and Piston rod are also made from solid block using Multibody components.
The multibody components are connected with the prismatic joint and Translational multibody interface .This block is an interface between a Simscape Multibody joint and a Simscape mechanical translational network. Ports R and C are mechanical translational conserving ports that connect to the two nodes in the mechanical translational network which share the same force and relative velocity as a primitive in the Multibody joint. Ports v and f are physical signal ports that connect to the Multibody joint.
Bottom Cap
Barrel
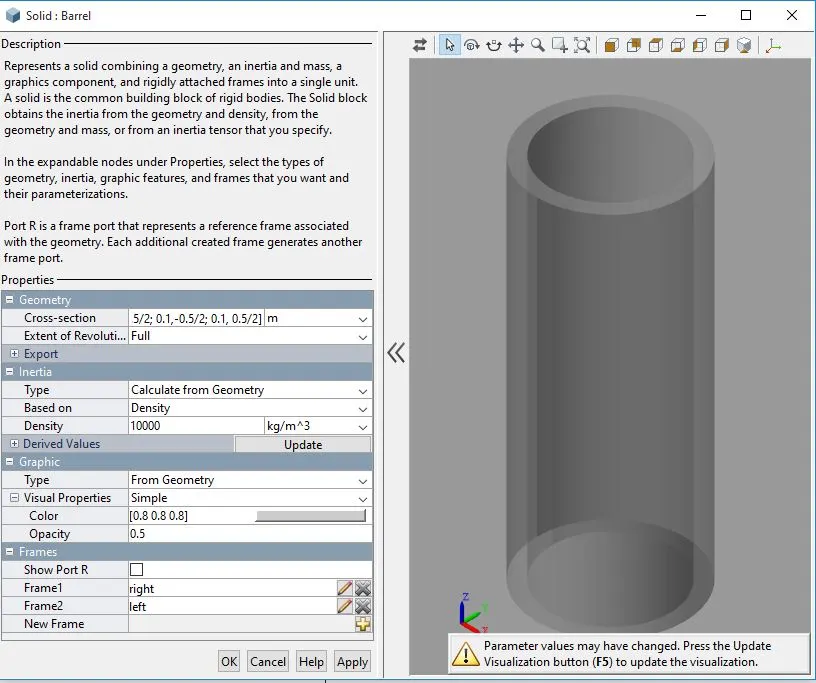
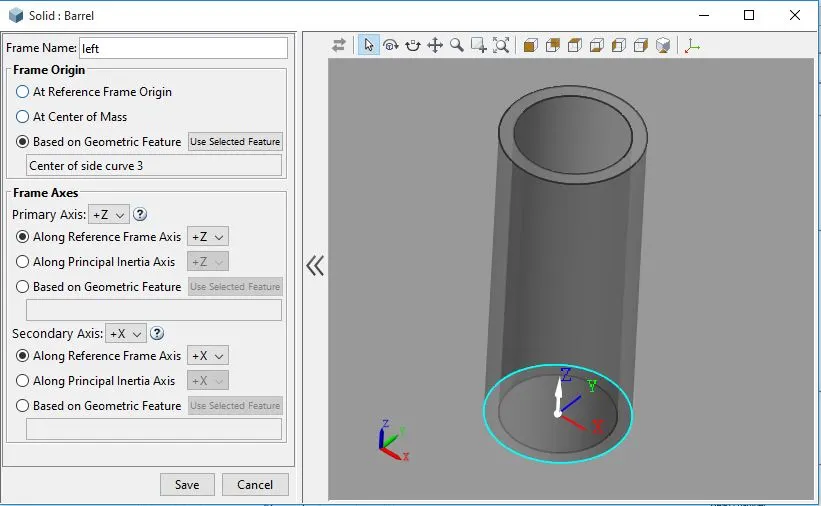
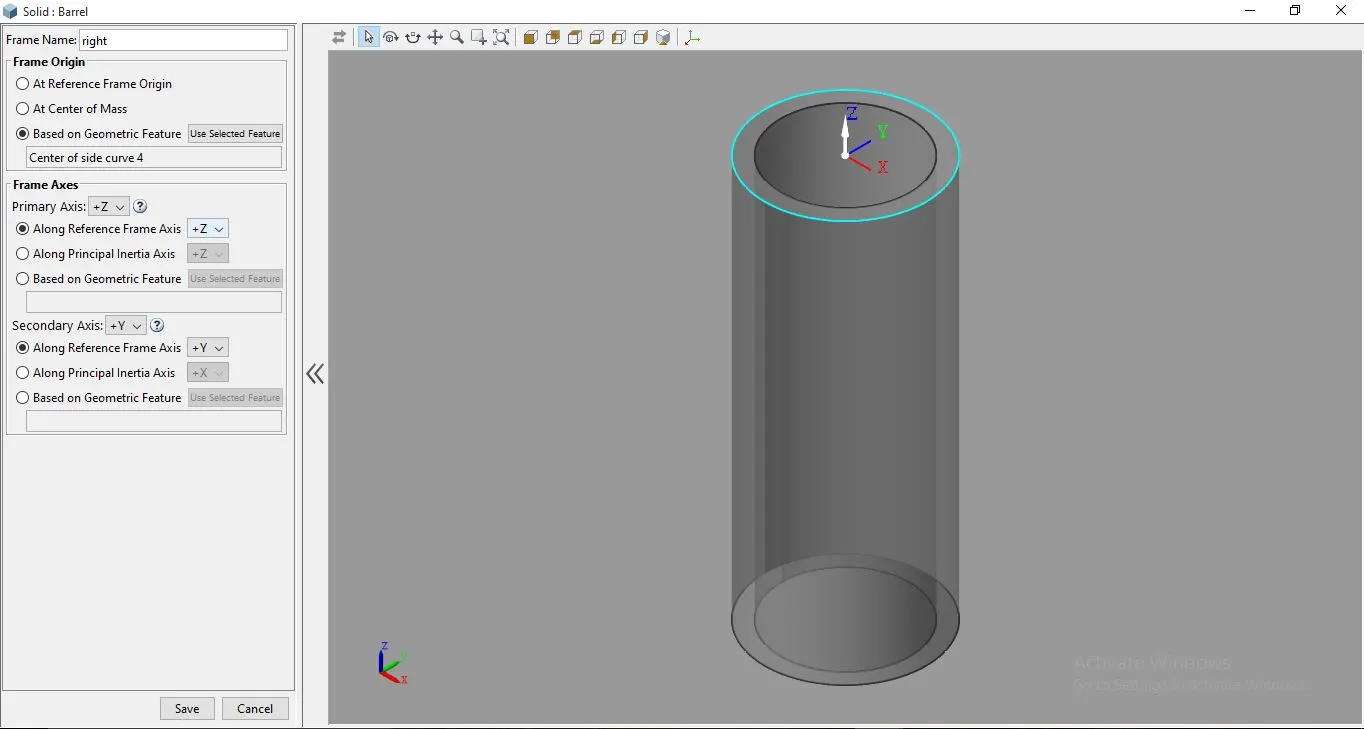
Head Cap
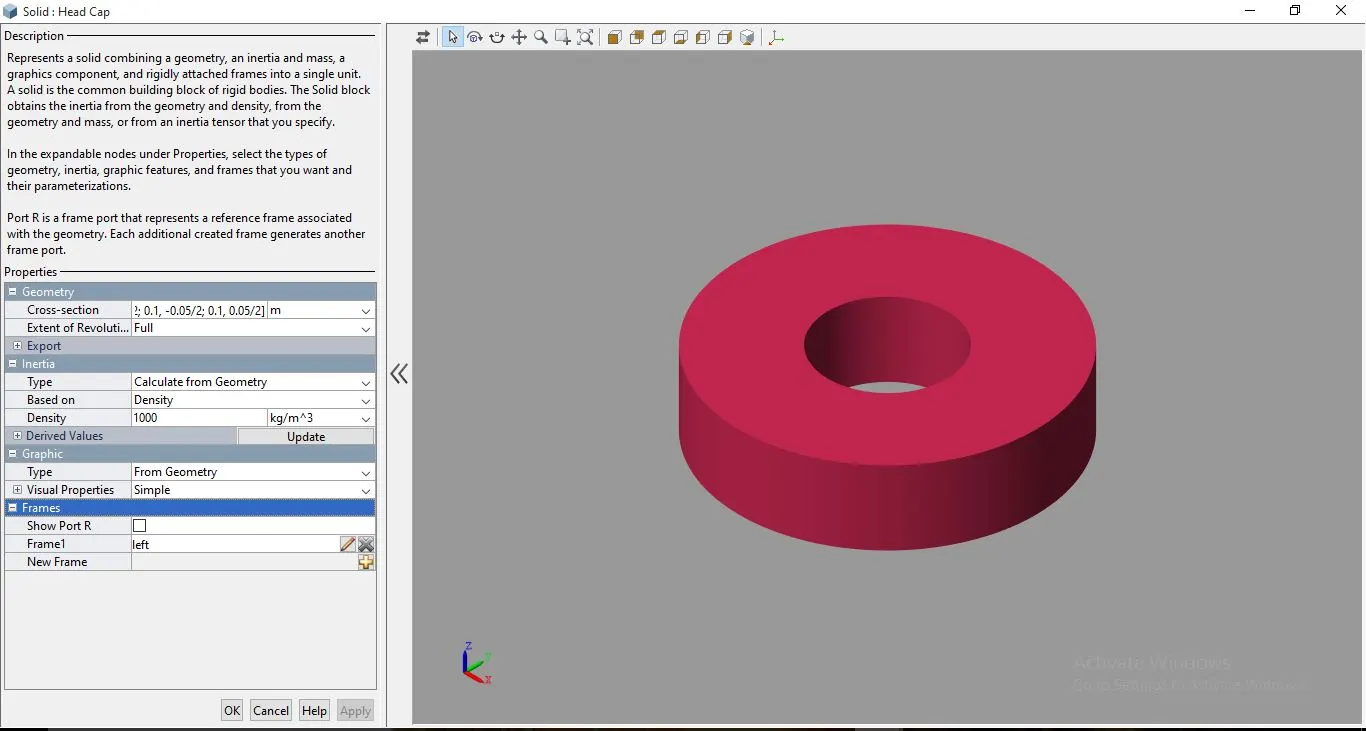
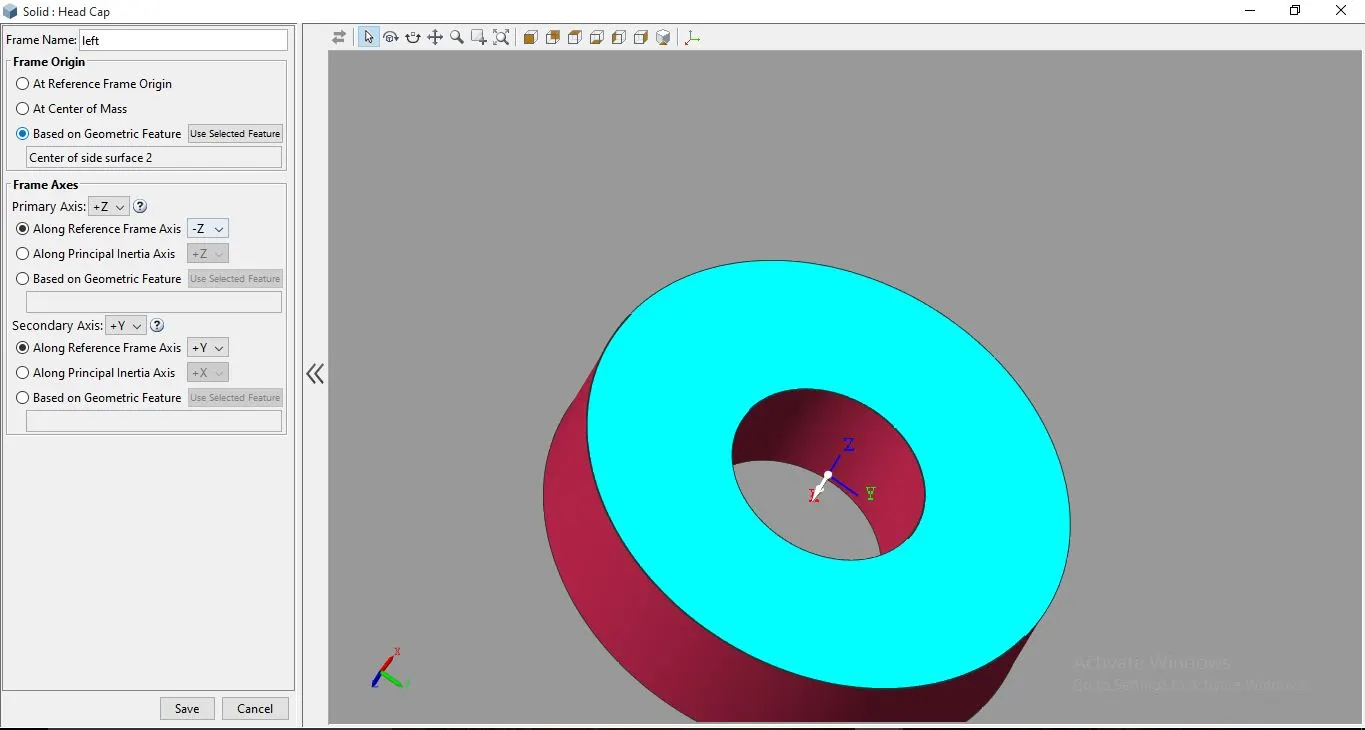
Piston
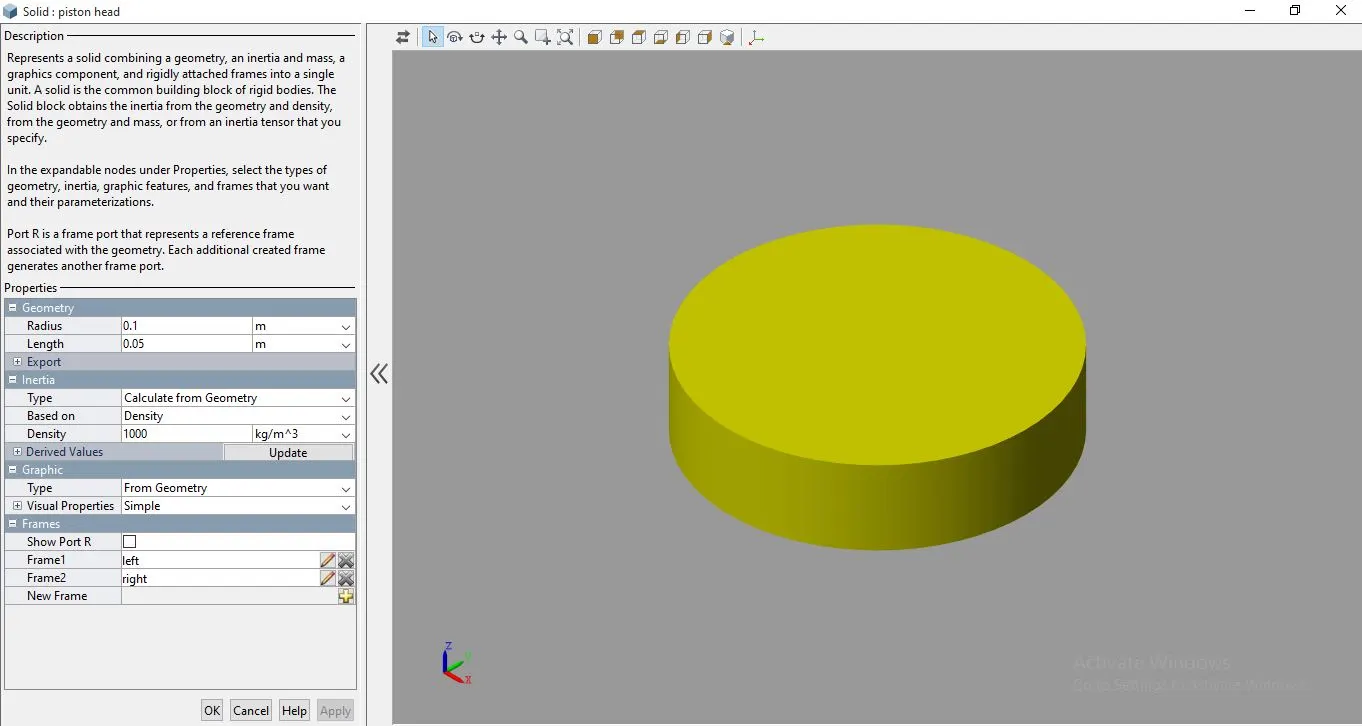
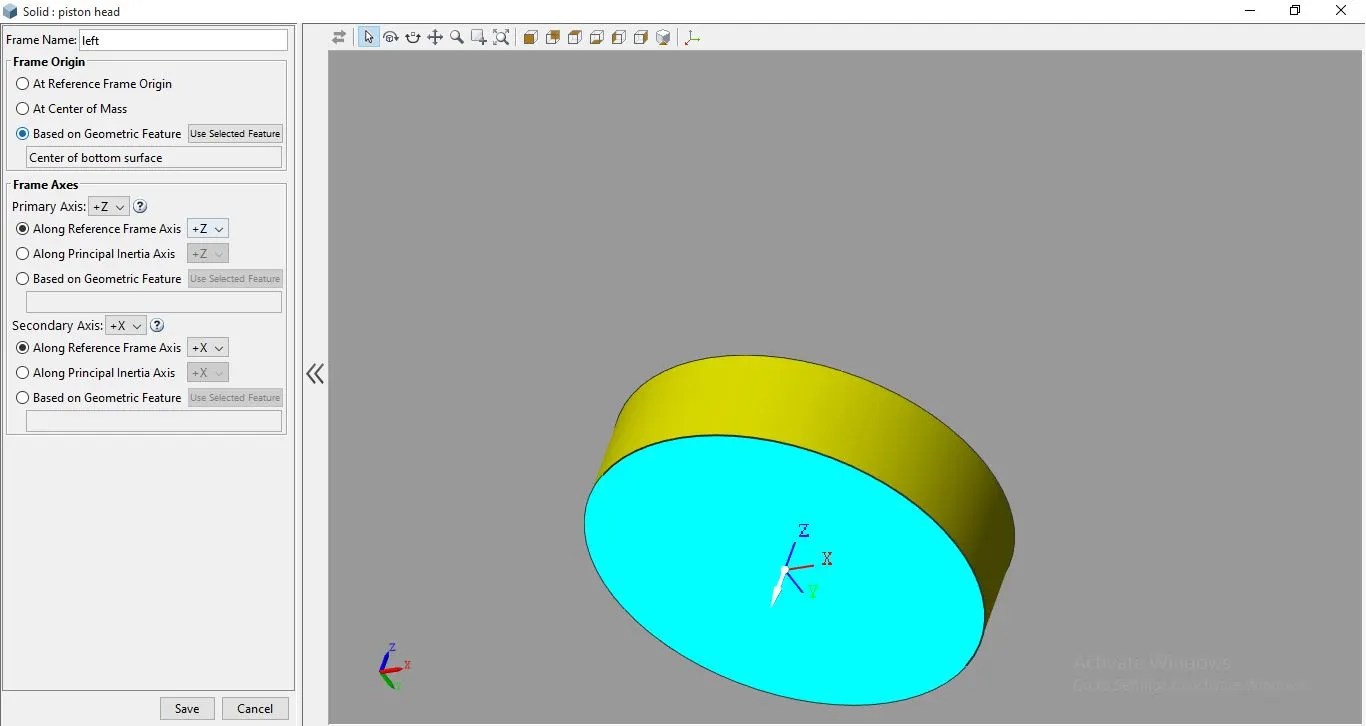
Piston Rod
Prismatic Joint
Valve Control
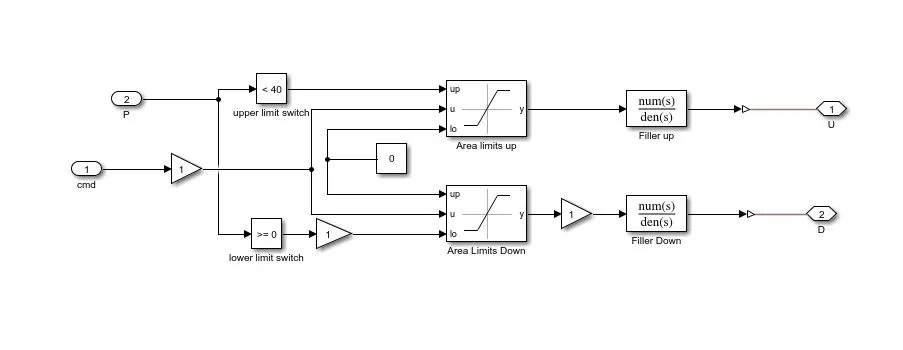
Valve
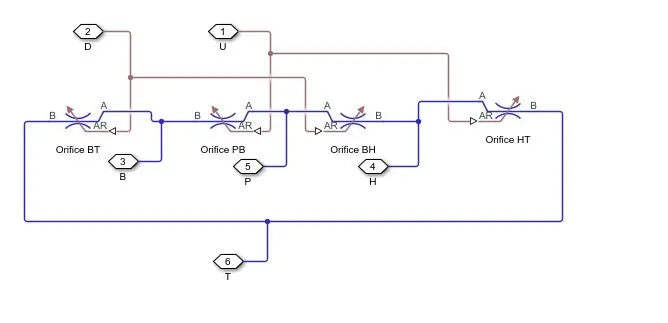
Orifice
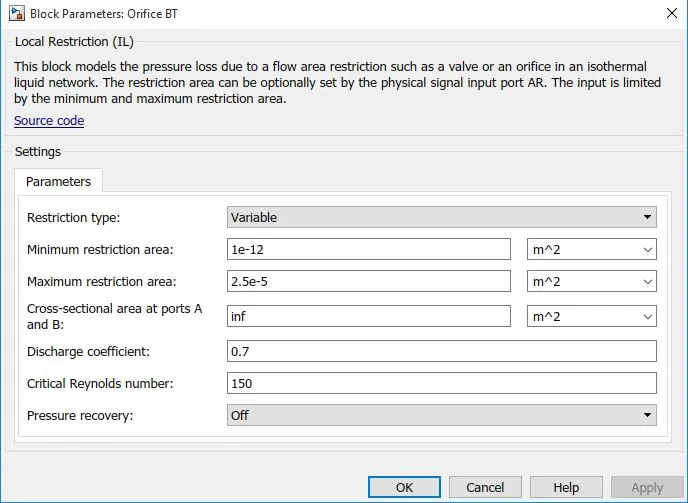
here the parameters are similar for all the orifice blocks BT, PB, BH, HT.
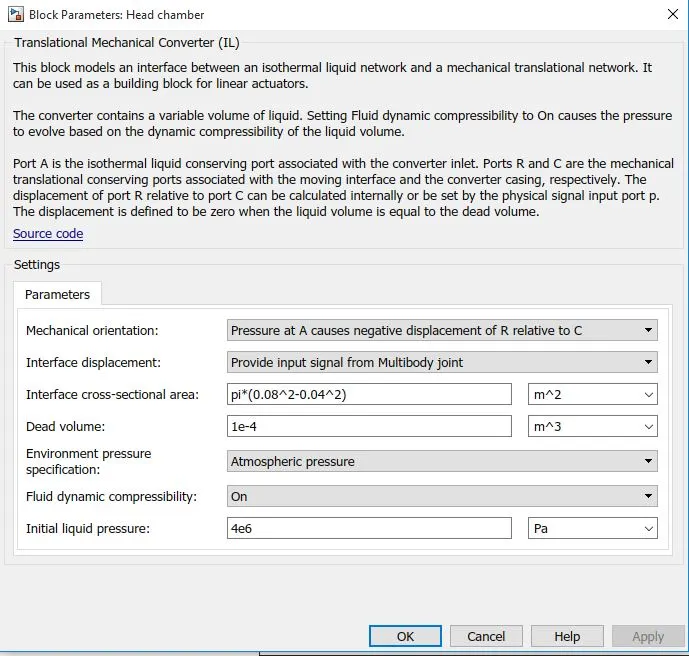
Bottom Chamber
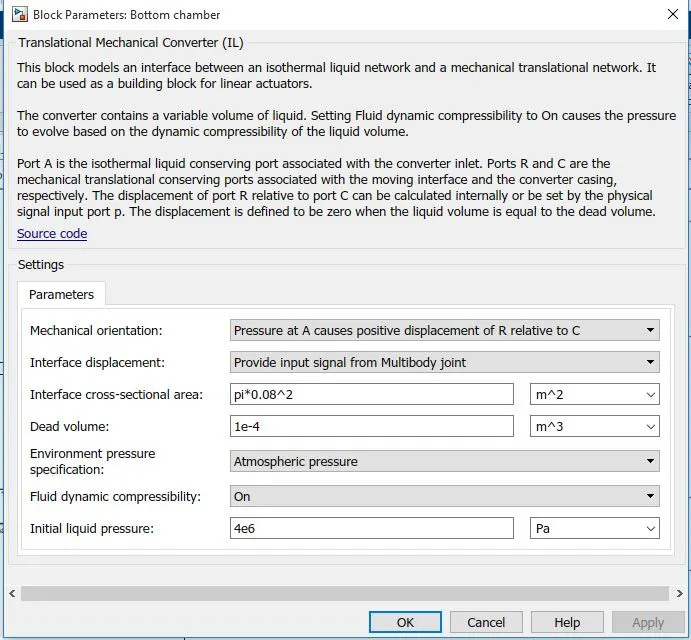
Head Chamber
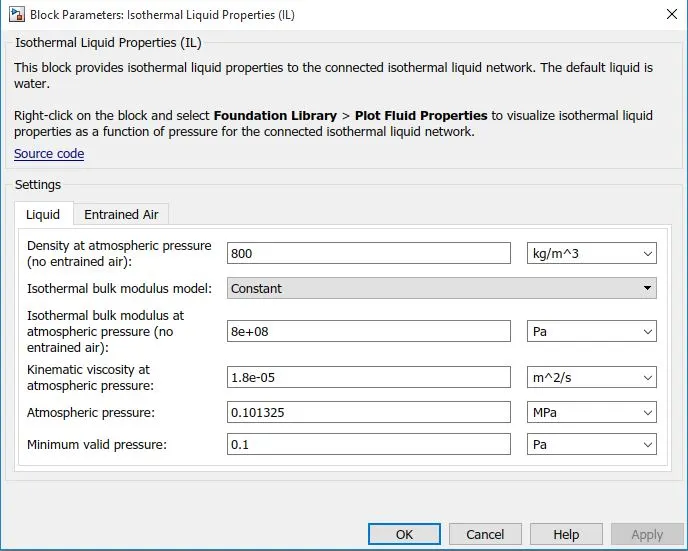
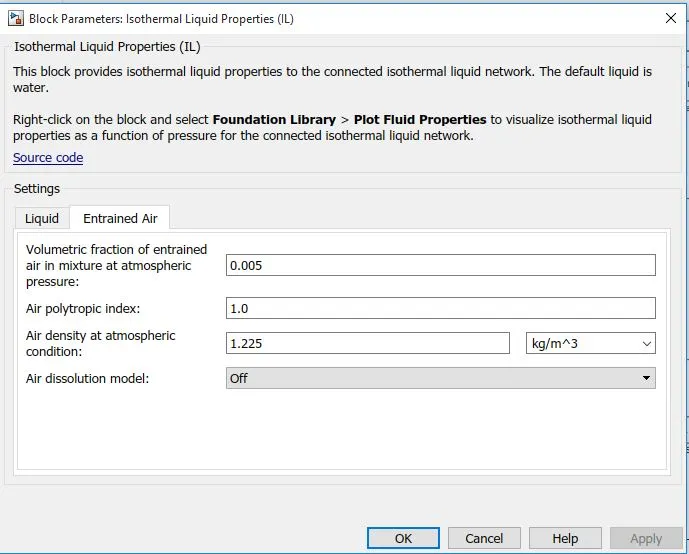
Isothermal Liquid
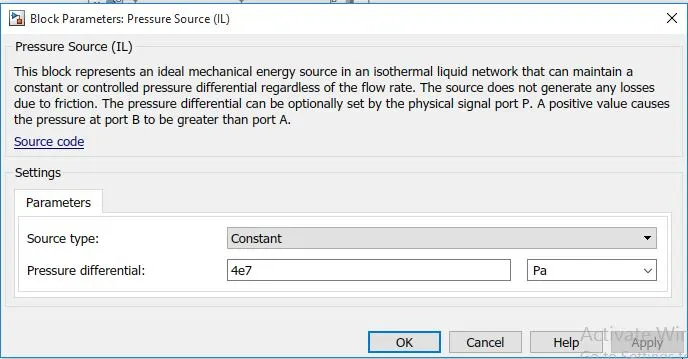
Pressure Source
Scope Results
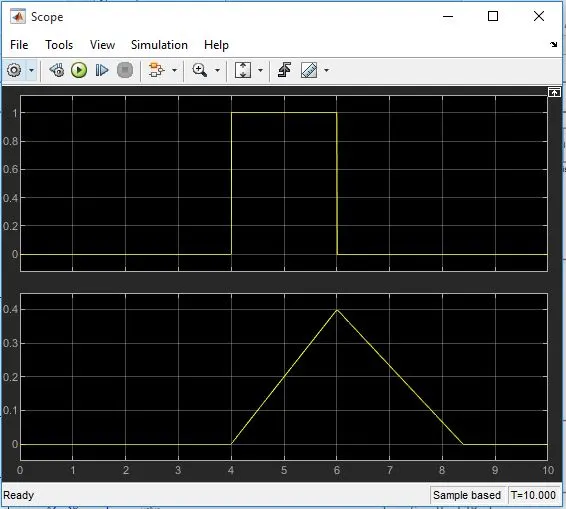
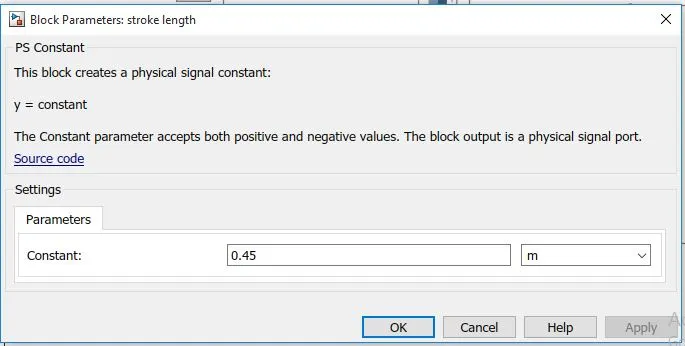
Stroke Length
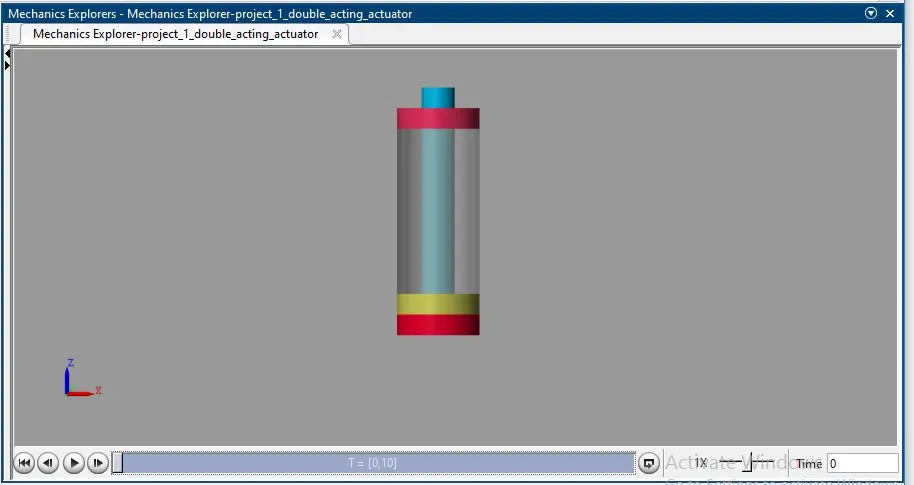
Mechanics Explorer
for t = 0
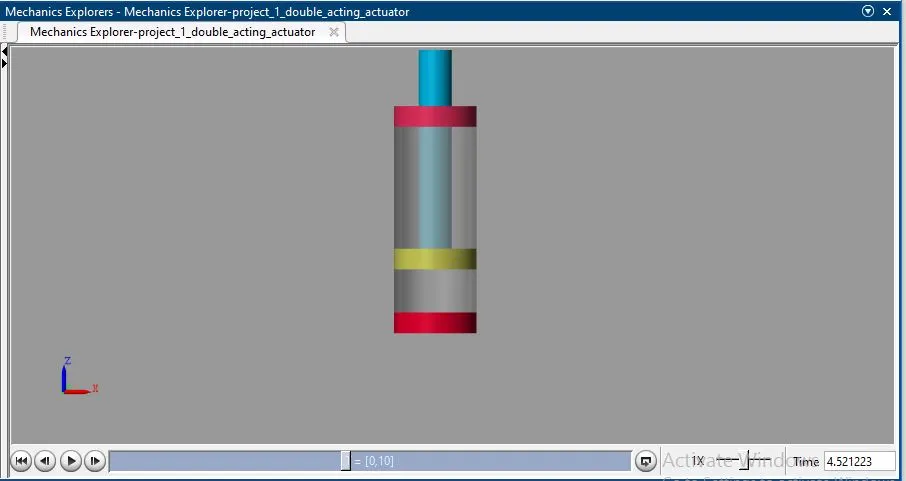
now the piston starts moving from bottom at t= 4
the piston reaches head of the cylinder at t = 6
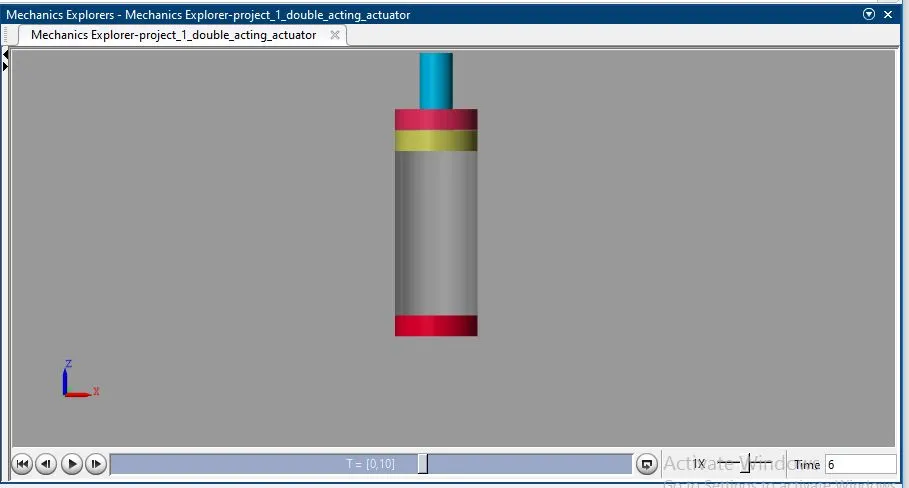
the piston starts moving towards bottom from head
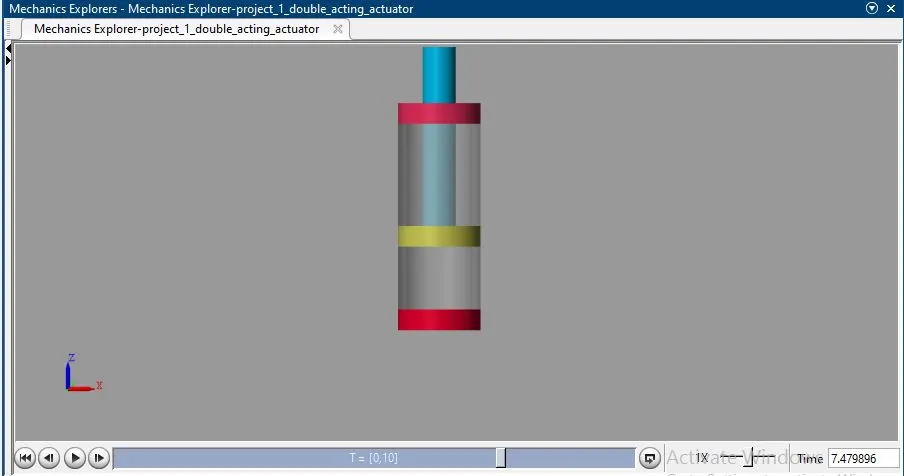
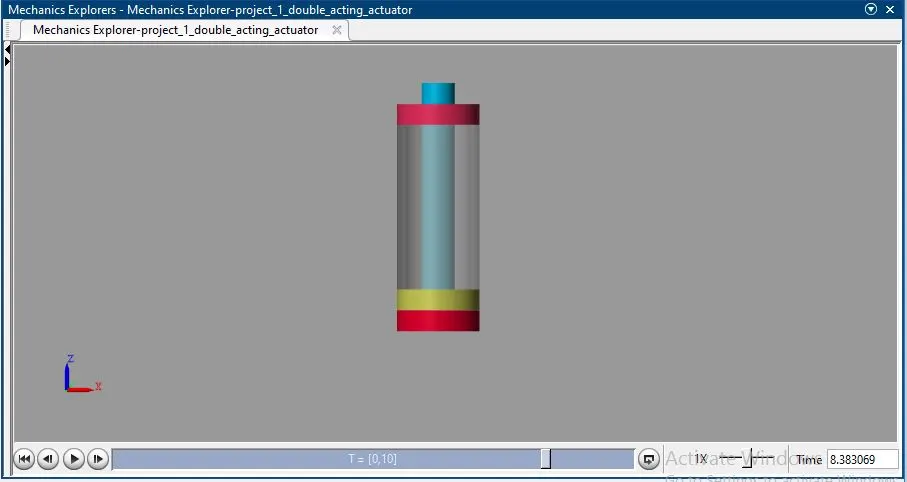
the piston reaches bottom at t= 8
Conclusion
The double-acting hydraulic actuator model developed using Simulink's Simscape Multibody and Simscape Hydraulics libraries successfully demonstrates the integration of mechanical and hydraulic systems in simulating the behavior of an actuator. The hydraulic system, powered by a pressure source and controlled by a directional valve, applies fluid pressure to either side of the actuator's piston, resulting in precise motion control.
Through the simulation, we observed the actuator’s response ,the mechanical system's behavior, driven by hydraulic pressure, was visualized using Mechanics Explorer, providing a clear understanding of the piston’s movement.
Reference :
https://in.mathworks.com/help/sm/ug/hydraulic-interface-dump-trailer-with-hydraulic-cylinder.html