Multibody Dynamics of Planetary Gear Mechanism using SOLIDWORKS
AIM
Design a carrier for planet gear based on inputs and analyse planetary gear assembly using SOLIDWORKS Multibody dynamics.
OBJECTIVES
- Understand input parameter for designing sun, planet and ring gear.
- Calculate missing parameters for designing sun, planet and ring gear.
- Model Planetary Gear assembly with carrier using SOLIDWORKS.
- Perform a Multibody Dynamics of Planetary Gear
BASIC STUDY
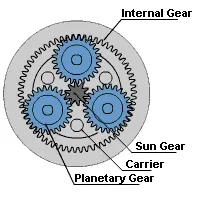
The planetary gearbox got its name because of how the different gears move together. In a planetary gearbox we see a sun (solar) gear, satellite (ring) gear and two or more planet gears.
A planetary gearbox is a gearbox with the input shaft and the output shaft aligned. A planetary gearbox is used to transfer the largest torque in the most compact form (known as torque density).
ANALYTICAL CALCULATION
- Willis equation for planetary gears
The Willis equation generally applies to all planetary gears. Although the planet gears of a classic planetary gearbox are enclosed by a ring gear, this does not change the derived relationships between sun gear, planet gear and carrier. The only question that arises is how the motion of the planet gears is transferred to the ring gear.
Note:
Analytical Calculations are done using PTC MathCad
PLANETARY GEAR SOLIDWORKS ASSEMBLY
INPUTS AND CONSTRAINS
Input Speed of the Gear = 200 rpm.
Case Input Output Fixed
1 Sun Gear Carrier Ring Gear
2 Ring Gear Carrier Sun Gear
3 Sun Gear Ring Gear Carrier
EXPLANATION
Step 01: From input parameter calculate missing parameters for designing sun, planet and ring gear.
Step 02: Calculate Analytical solution for each case of Model Planetary Gear assembly.
Step 03: Model based on parameters calculated for designing sun, planet and ring gear.
Step 04: Assemble Planetary Gear assembly using SOLIDWORKS.
Step 05: Using Top-Down Design Approach Design Carrier Planetary Gear assembly.
Step 06: Perform a Multibody Dynamics of Planetary Gear for three different cases.
Step 07: Compare and validate results from SOLIDWORKS Multibody dynamics with Analytical solution.
RESULTS
Case Input Speed Output Speed Fixed
1 Sun Gear 200 rpm Carrier 46.667 rpm Ring Gear
2 Ring Gear 200 rpm Carrier 153.333 rpm Sun Gear
3 Sun Gear 200 rpm Ring Gear -60.87 rpm* Carrier
* The negative sign is representing rotation reversed.
** The negative velocity is because of direction as per right hand rule.
CONCLUSION
Carrier for planet gear was designed and analysed using SOLIDWORKS Multibody dynamics.
REFERENCES