Multibody Dynamics of Internal Geneva Mechanism using SOLIDWORKS
AIM
Simulate Multibody Dynamics of Internal Geneva Mechanism using SOLIDWORKS.
OBJECTIVES
- Create cad models of Internal Geneva Mechanism in SOLIDWORKS
- Create an assembly of Internal Geneva Mechanism in SOLIDWORKS
- Simulate Multibody Dynamics of Internal Geneva Mechanism using SOLIDWORKS at 10 rpm and 20 rpm.
BASIC STUDY
Geneva mechanism, also called Geneva Stop, one of the most commonly used devices for producing intermittent rotary motion, characterized by alternate periods of motion and rest with no reversal in direction. It is also used for indexing (i.e., rotating a shaft through a prescribed angle).
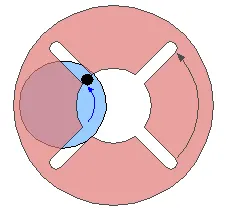
EQUATIONS
`"Distance between axis of driving and driven component, L in [mm]"`
`L = r / sin(180/n)`
here
`r = "radius of the driver member in [mm]"`
`n = "Number of slots in driven component"`
INITIAL CONDITION
Case 1 :
- Drive speed: 10 rpm
- Contact Precision : No
- Simulation Frames per Second : 60 fps.
Case 2 :
- Drive speed: 10 rpm
- Contact Precision : Yes
- Simulation Frames per Second : 60 fps
Case 3 :
- Drive speed: 20 rpm
- Contact Precision : No
- Simulation Frames per Second : 120 fps
Case 4 :
- Drive speed: 20 rpm
- Contact Precision : Yes
- Simulation Frames per Second : 120 fps
RESULTS
The negative velocity is because of direction and on intermittent rotary motion velocity is maximum at middle of intermittent rotary motion. The spikes in above graph are because of impact from intermittent rotary motion to another and there are sudden velocity changes because of impact.
The Contact Force between driving and driven component are shown above. The spikes in above graph are because of impact from intermittent rotary motion to another.
CONCLUSION
Internal Geneva Mechanism has simulated SOLIDWORKS Multibody Dynamics.
REFERENCES