Final Project: Electric Rickshaw modelling
Overview of simulink model
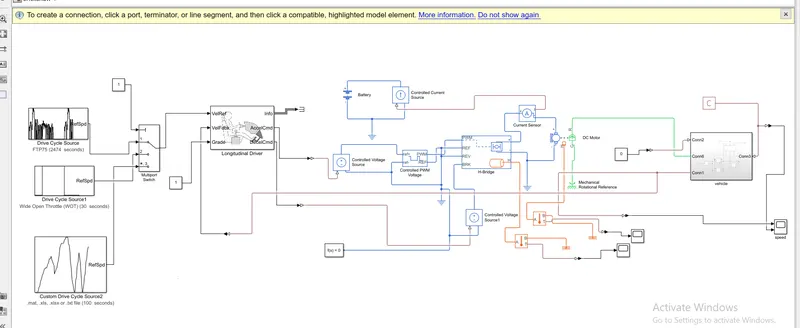
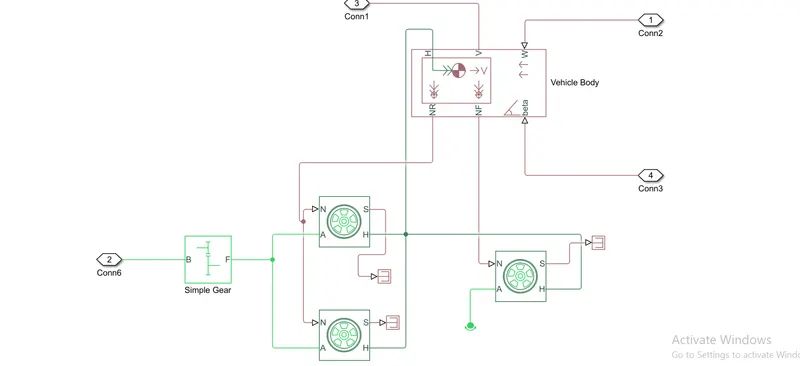
below screenshot shows the blocks used inside the vehicle subsystem
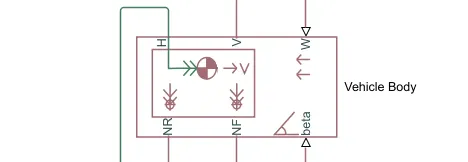
*this block contain 6 ports which can be used to model various aspects of the vehicle body
*H- This stands for hub and is used to connect the hubs of the wheels to the main body of the vehicle
*V-Physical signal output port which stands for 'velocity' and is used the output the velocity of the vehicle
*W- Physical signal input port and allows us to model a wind velocity that acts aginst the vehicle
*NR- Physical signal output port to connect to connect the rear wheels
*NF- Physical signal output port to connect the front wheels of the vehicle
*Beta- Physicall signall input port which allows the vehicle to undergo an inclination of hill climbing force
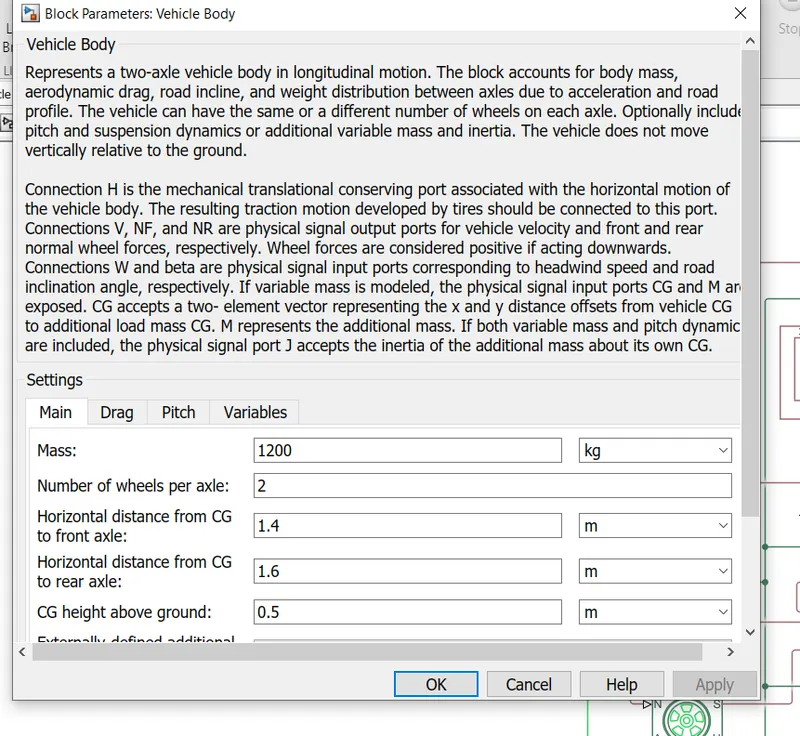
model parameters are used to set up mass, frontal area and others
Tires
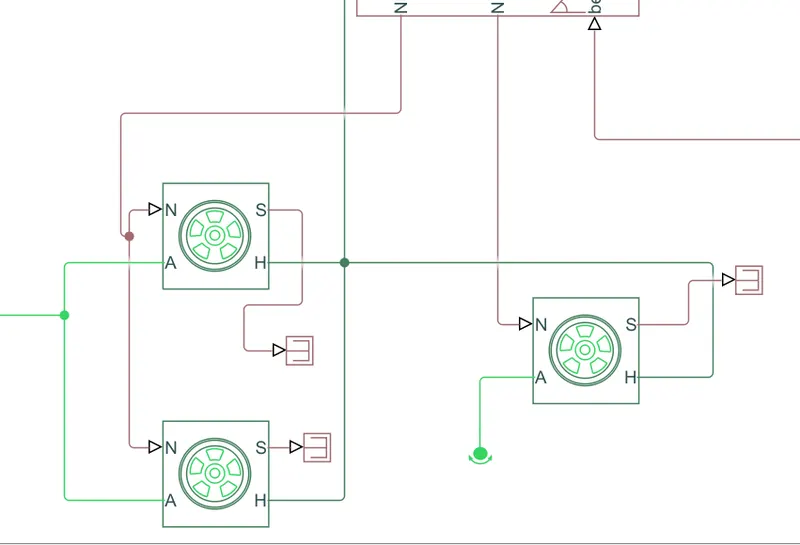
*this block represents the longitudinal behavior of a tire of a highway
*connection A is the mechanical rotational port for the wheel axle. Connection H is the mechanical translational port for the wheel hub through which the thrust developed by the tire is applied to the vehicle
*connection N is a physical signal input port that applies the normal force acting on the tire. The force is considered positive if it acts downwards. Connection S is a physical signal output port that reports the tire slip
*three tires are connected, where the left two tires are the rear wheels and the remaining one is the front wheel . they are interconnected to the hub of the vehicle body block. and their respective axles are connected accordingly. We here have connected the rear axle with the gear as we want the model to be a rear wheel drive vehicle
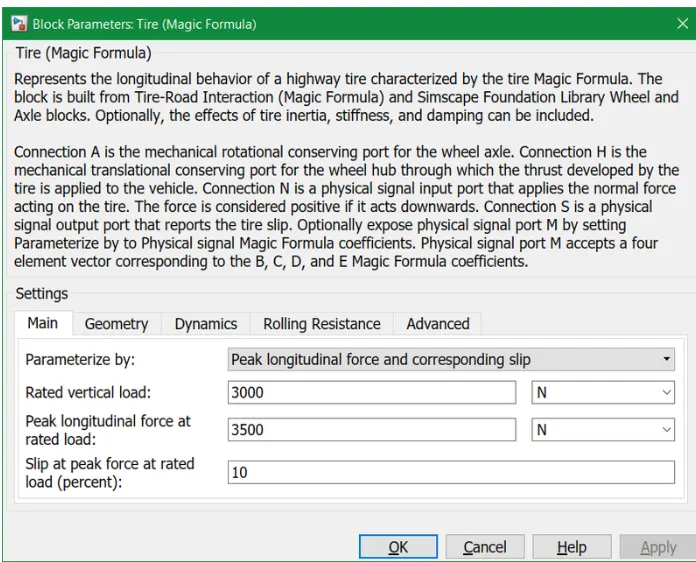
all the parameters are set to be default
simple gear
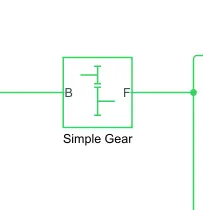
this block represents a fixed-ratio gear or gear box. Connections B (base) and F (follower) are mechanical rotational conserving ports. The base is the input port and the follower is the output port
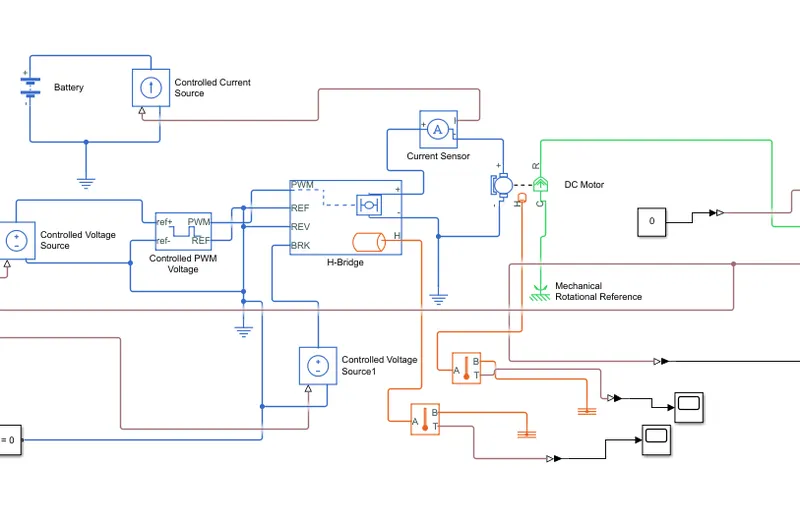
blocks used in this system are
*DC Motor
*H-bridge
*Controlled PWM voltage
*Controlled voltage source
*Temperature sensor
DC motor
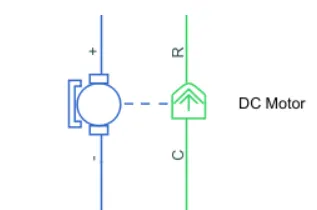
* there are two sides of the block , the mechanical side is on the right and the electrical side is on the left. mechanical side has tow ports C and R, C stands for casing and is the stable part and R is the rotor which produces a torque
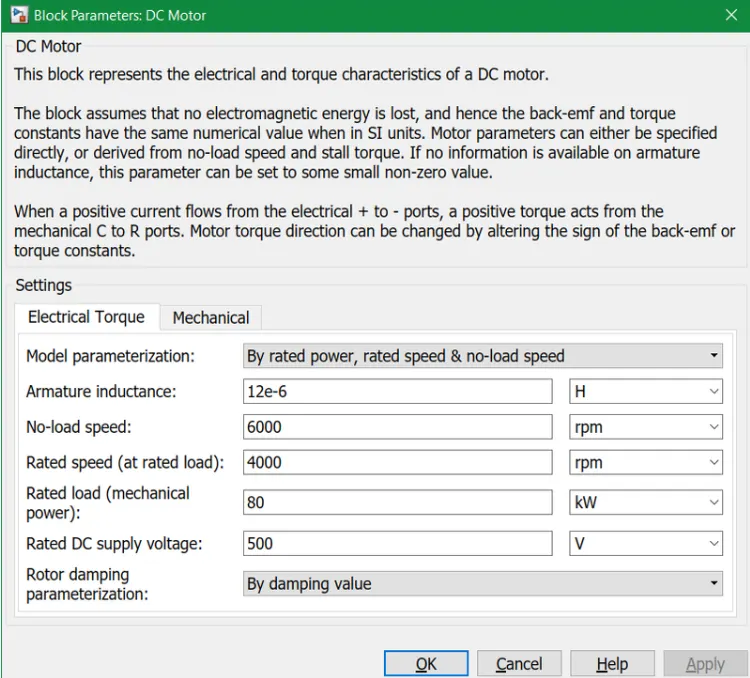
*the electrical side has a positive and negetive side for the voltages to be applied. if positive voltage is applied to the motor block from the positive to the negetive terminal then a positive torque will act from C to R port
*the direction of the torque can be cahnged by changing the sign of the back emf or the torque constant. Here i have connected the c port to the mechanical rotational reference because it will be stationary. the R port is connected to the gear in the vehicle body block
H bridge
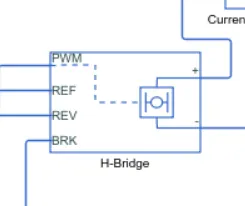
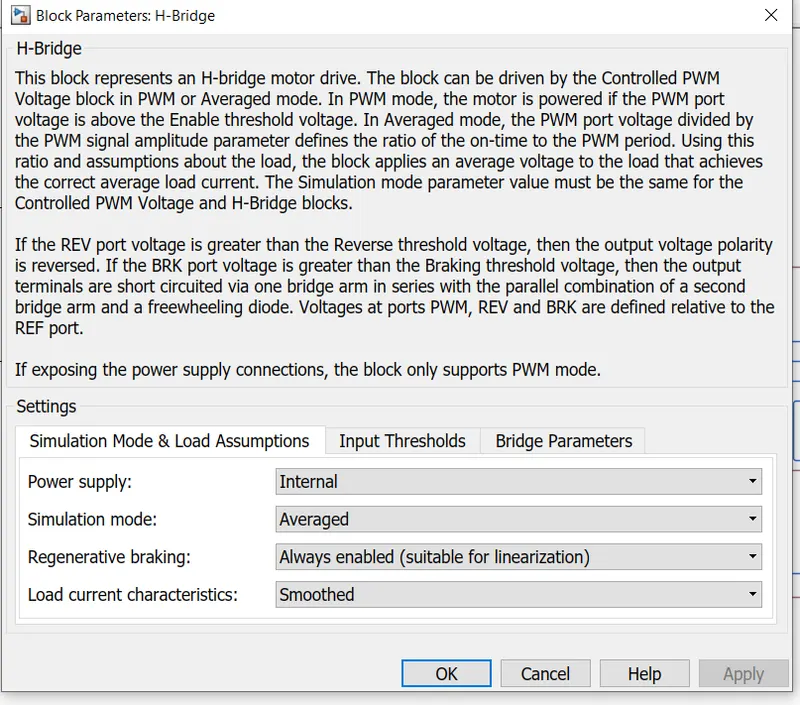
*PWM (Phase Width Modulation) where the H-Bridge block output is a controlled voltage that depends on the input signal at the PWM port and Averaged which consists of two load current characteristics being smoothed and unsmooth or discontinuous
*the first port (PWM) is the input port, the second port (REF) is to connect the electrical reference block. The third port (REV) controls the reverse polarity of the block and the fourth port (BRK) controls the short circuit of the block
Controlled PWM voltage
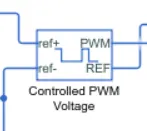
*this block creates a Pulse-Width Modulated (PWM) voltage across the PWM and REF ports
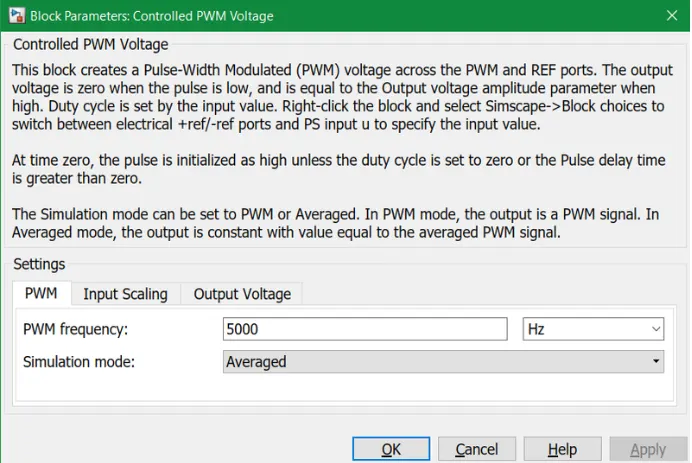
* the output voltage is zero when the pulse is low, and is equal to the Output voltage amplitude parameter when high. Duty cycle is set by the input value
The PWM and REF ports are connected to the ports of the same in the H-bridge block
Controlled voltage source
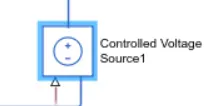
*two voltage source blocks are used for the simulation,one to control acceleration which is connected to the ref+ port of the PWM block and the second for regenerative braking which is connected to the BRK port of the H-bridge block
Controlled current source
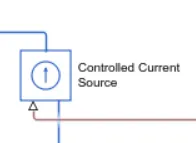
*this block represents an ideal current source that is powerful enough to maintain the specified current through it regardless of the voltage across it.the output current is I = Is, where Is is the numerical value presented at the physical signal port
*it is connected to the positive and negative terminals of the battery
Current sensor
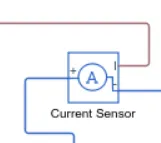
*this block represents an ideal current sensor, that is, a device that converts current measured in any electrical branch into a physical signal proportional to the current
*connections + and - are conserving electrical ports through which the sensor is inserted into the circuit. connection I is a physical signal port that outputs current value
* terminals of the current sensor are connected between the H bridge block and the DC motor
Temperature sensor
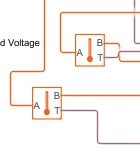
block used to calculate the temperature of the connected source,one is connected to controller and other one is connected to the dc motor
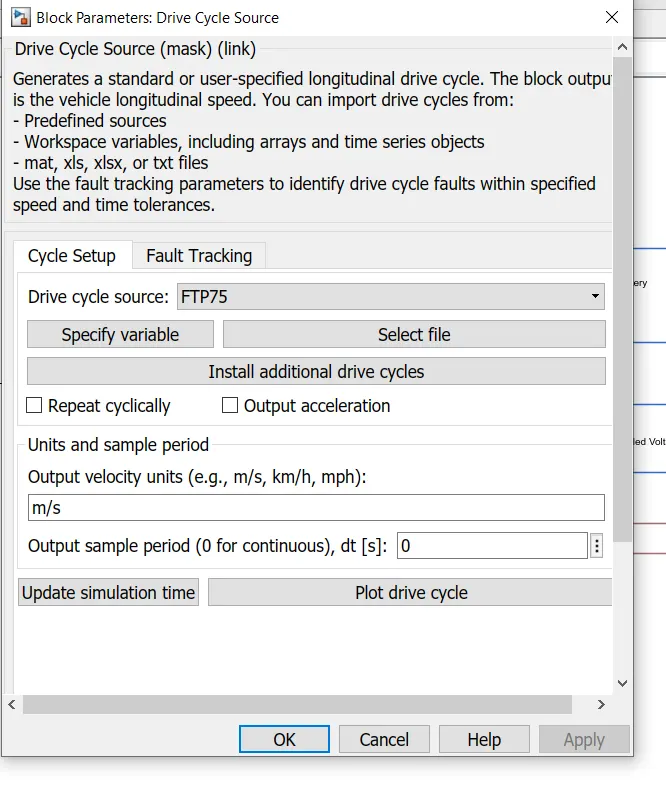
Driver cycle
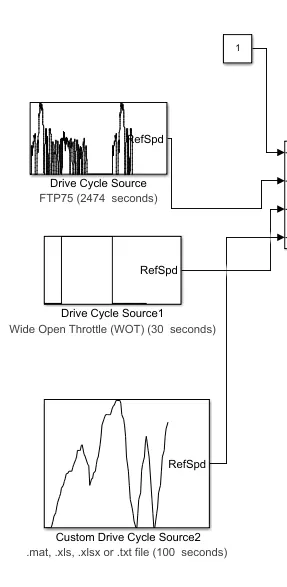
three types of drive cycle is used .One is FTP then WOT and last is custom made
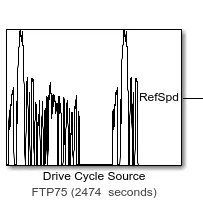
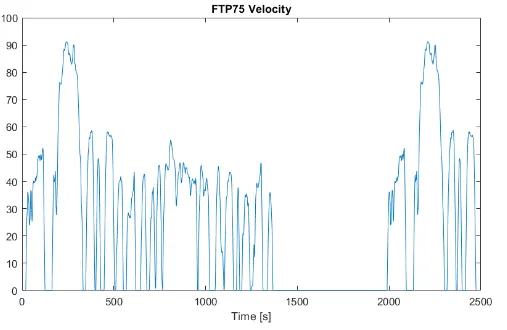
this block is used for the input which represents a drive cycle. the drive cycle used for this simulation is the FTP75 which stands for Federal Test Procedure. all the parameters are set to default
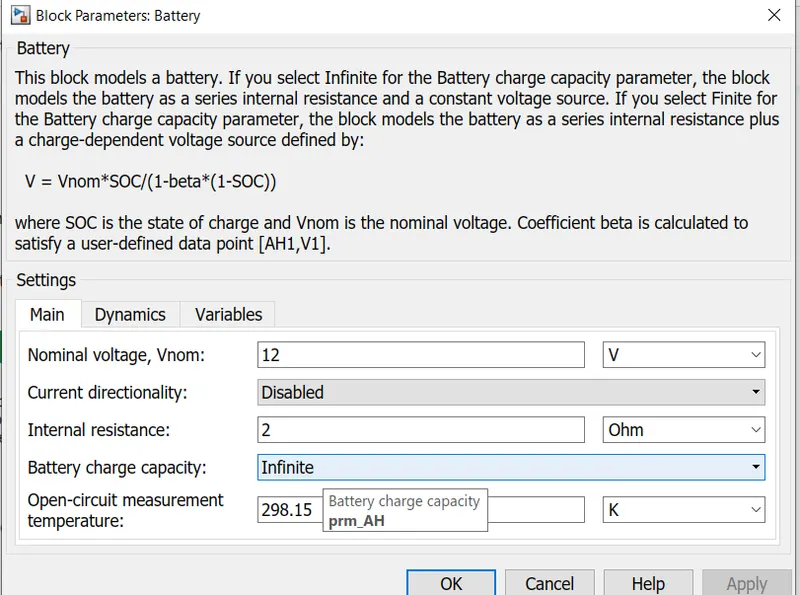
Battery
battery will be the energy store of the EV and will contain the electrical energy in DC form and provide this energy to operate
Longitudinal driver block
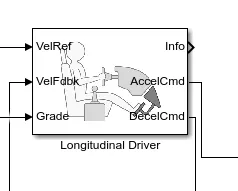
*block that is used as a controller for driver based inputs which are acceleration and braking
*the output port (RefSpd) of the drive cycle block is connected to the VelRef port which calculates the input parameters
*the VelFdbk port is connected to the velocity port (V) of the vehicle body block from the subsytem and also the scope in order to plot the input data
*the Grade port is set to 1 by using a constant block
*the AccelCmd and DecelCmd ports which are the outputs for acceleration and braking respectively are connected to the respective controlled voltage source blocks responsible for acceleration and regenerative braking
Results
output for FTP75
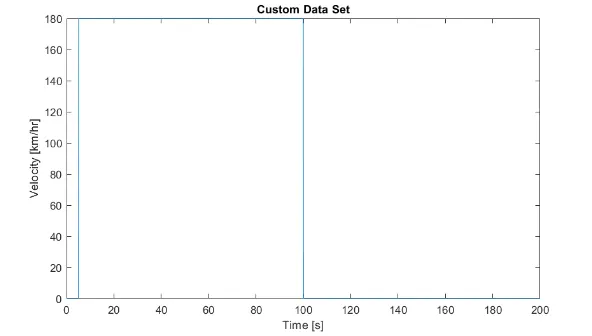
for WOT condition
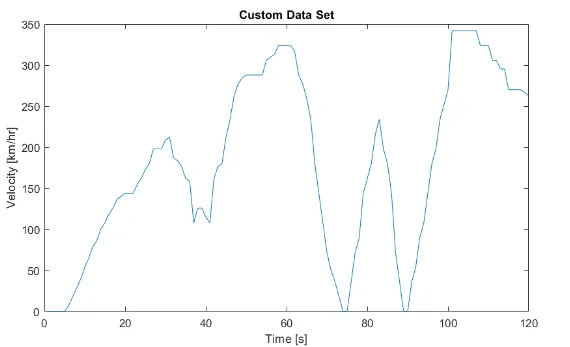
for custom made drive cycle
conclusion
Modelling an electric rickshaw done using simulink with the blocks used explained and the impact of the driving cycle on the vehicle's speed is analysed