Final Project: Design of an Electric Vehicle
1] Create a MATLAB model of electric car which uses a battery and a DC motor. Choose suitable blocks from Powertrain block set. Prepare a report about your model including following:
Objectives:
1. System level configurations
2. Model parameters
3. Results
4. Conclusion
ANSWER:-
AIM:- To create a MATLAB model of electric car which uses a battery and a DC motor
Overview of electric vehicle and how they work:- An electric vehicle unlike a conventional car which moves with the help of an engine, an electric vehicle usses an electric motor that is powered by a battery, the speed is controlled by varying the output voltage or frequency to the motor by the control unit. The control unit usses a reference like throttle input or drive cycle.
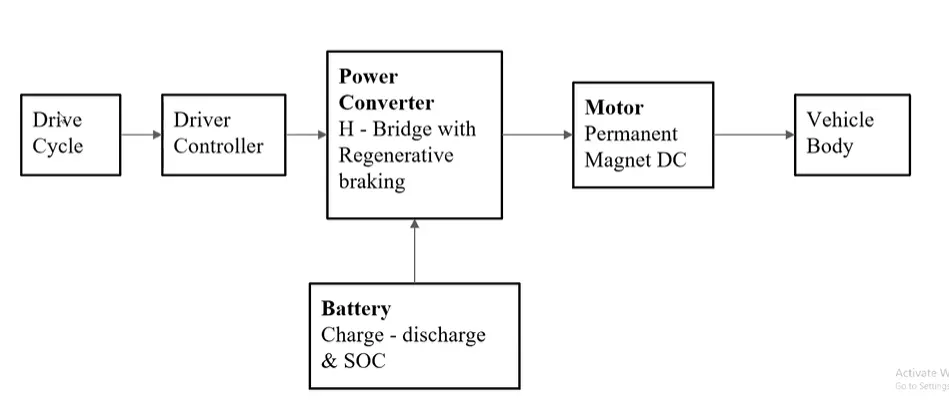
Based on the above diagram we can make a matlab simulink model of an electric vehicle. Firstly we take a drive cycle from and make 2 subsystems. We observe the input drive cycle and the output velocity and there should be negligible difference between them. After running this we observe the state of chanre of the battery. Matlab model of electric car which uses a battery and a DC motor.
SIMULINK MODEL DESIGN PARAMETERS
Mass of Vehicle (total kerb weight) = 1080 Kg
Frontal Area of Vehicle, = 1.33 m^2
Drag Coefficient = 1.2
Radius of Wheel = 18 inches
Rolling Resistance COefficient = 0.005
Cell Voltage = 5 V, (consists of 96 cells connected in series and parallel)
Blocks Used :-
Vehicle Body : A Vehicle can have the same or a different number of the wheel on each axle.The Vehicle body represents a two-axle vehicle body in longitudinal motion. For example, two wheels on the front axle and wheel on the rear axle. The vehicle wheel is assumed identical in size. The vehicle can also have a center of gravity(CG) that is below the plane of travel. The block accounts for body mass, aerodynamics force, road incline, and weight distribution between axle due to acceleration and road profile. The vehicle does not move vertically relative to the ground.
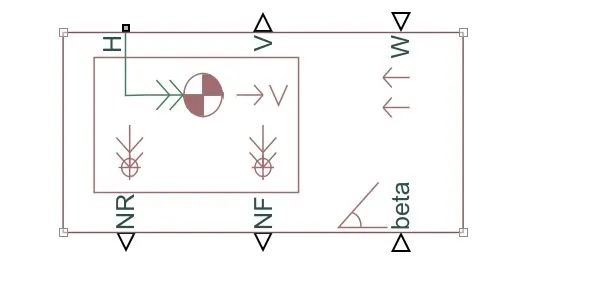
W: It signifies the signal port for headwind speed.
Beta: Input from this port is the road inclination angle.
V: The output from this port is vehicle longitudinal velocity in m/s.
NF: It gives the output for normal force on the front axle. Wheel force is considered positive if acting downwards.
NR: It uses to connect the rear wheel with the vehicle body. It gives the signal output port for normal force on the rear axle.
H: It uses to provide a mechanical translation. It is associated with the horizontal motion of the vehicle body.
The Vehicle body parametera are as shown below:
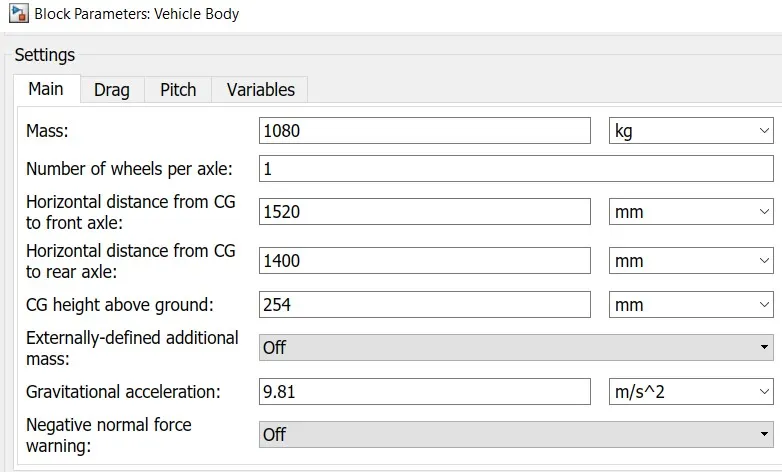
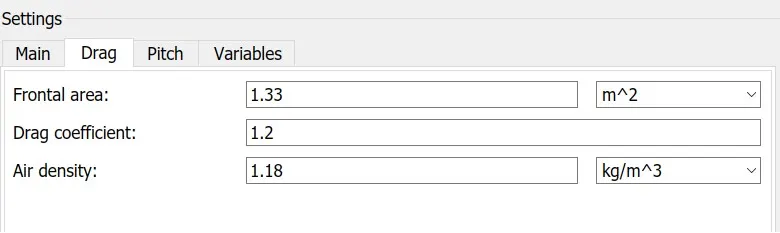
Some parameters are shown above, with mass to be 1080 kg, center of gravity to be 254 mm. Drag coefficient and frontal area to be 1.2 and 1.22m^2.
Tire: The tyre blocks model has a longitudinal behavior given by the magic formula, which is an empirical equation based on the four fitting coefficients. The block can model tire dynamics under constant or variable pavement conditions. The tire block model the tire as a rigid wheel-tire combination in contact with the road and subject to slip. When torque is applied to the wheel axle, the tire pushes on the ground and transfer the resulting reaction as a force back on the wheel. The action pushed the wheel forward or backward. The tire block is shown below.
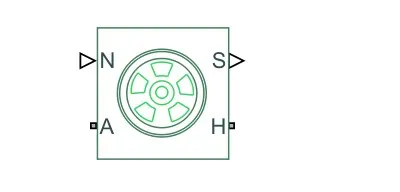
N: It is associated with a normal force acting on the tire. The normal force is positive if it acts downward on the tire, pressing it against the pavement. It is used to connect with the body parts.
A: It is a mechanical rotation port, it is associated with the axle of the tire.
H: It is a mechanical translational port associated with the wheel hub that transmits the thrust generated by the tire to the remainder of the vehicle.
S: This port is associated with the relative slip between the tire and the road.
The parameters for a tire are given below:
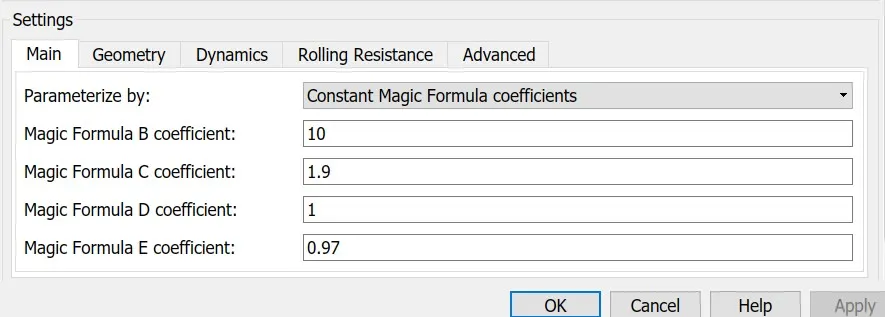
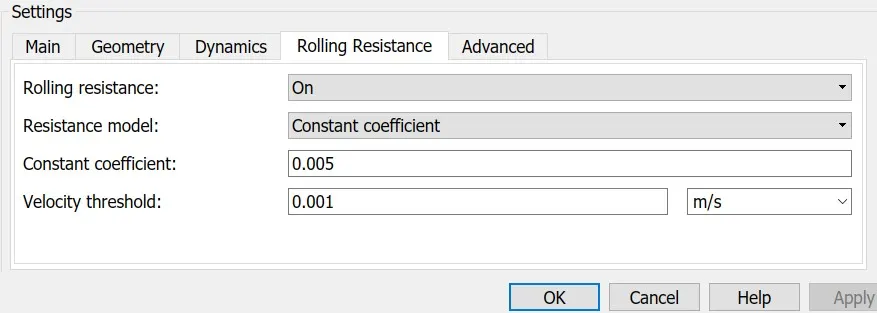
The tire is modeled with the above characteristics with the radius of the tire to be 18 inches and the inertia of the tire has also been modeled. Rolling resistance has also been considered for the tire.
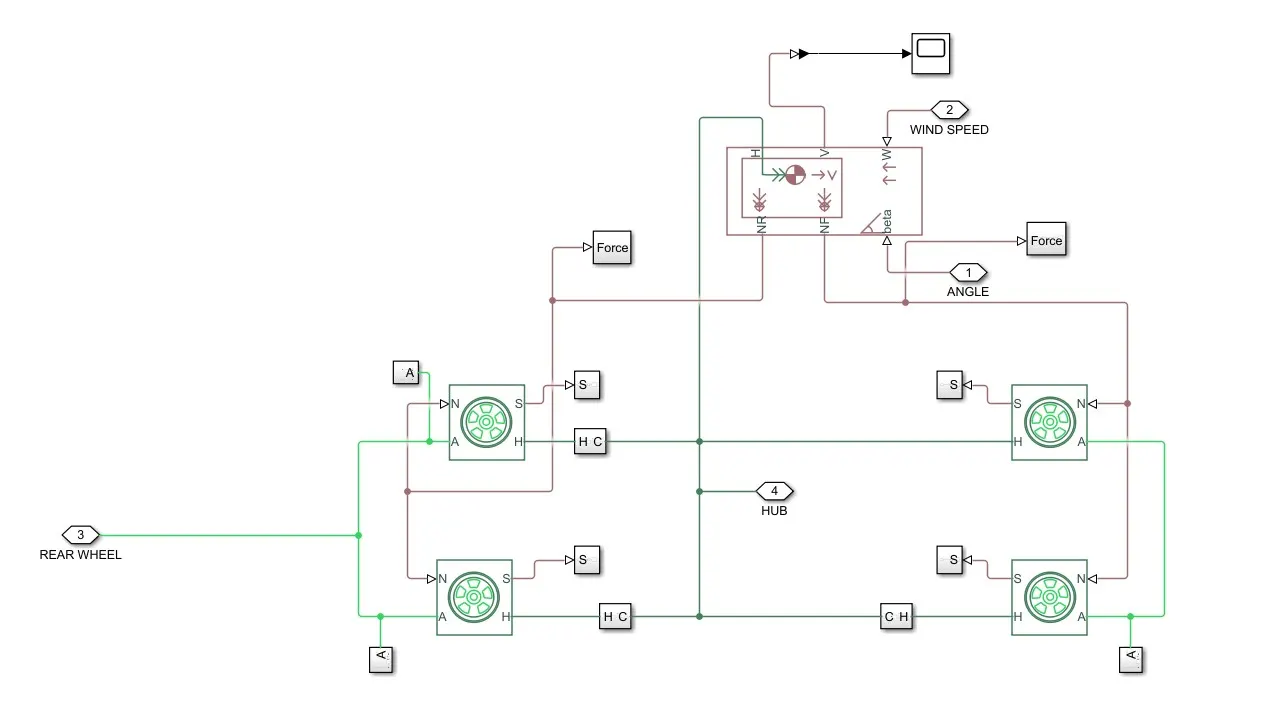
After that connection of the tire with the vehicle, the body has been made for the Vehicle subsystem, Which is shown below.
The vehicle subsystem model consists of various sensors, to plot the longitudinal force, the normal force of tire.
Ideal Force Sensor: The ideal force sensor is used to calculate the longitudinal tire force of the tire. It is connected with the hub port of the tire, which converts the PS Simulink converter to convert the signal to the plot.
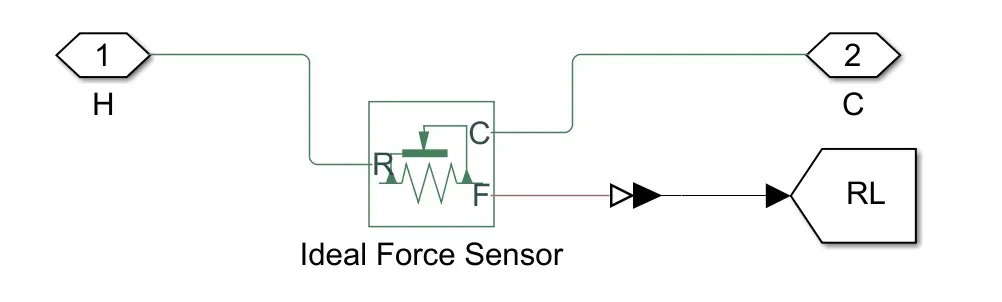
Normal Tire force is also plotted for the system for both the real and front wheel.
Main system model shown below:
This is put into a subsystem, which is connected with the sensor subsystem to model the velocity output and distance covered by the system. The sensor subsystem consisted of an ideal translational motion sensor which is connected with the hub of the vehicle to measure velocity and distance covered by the vehicle.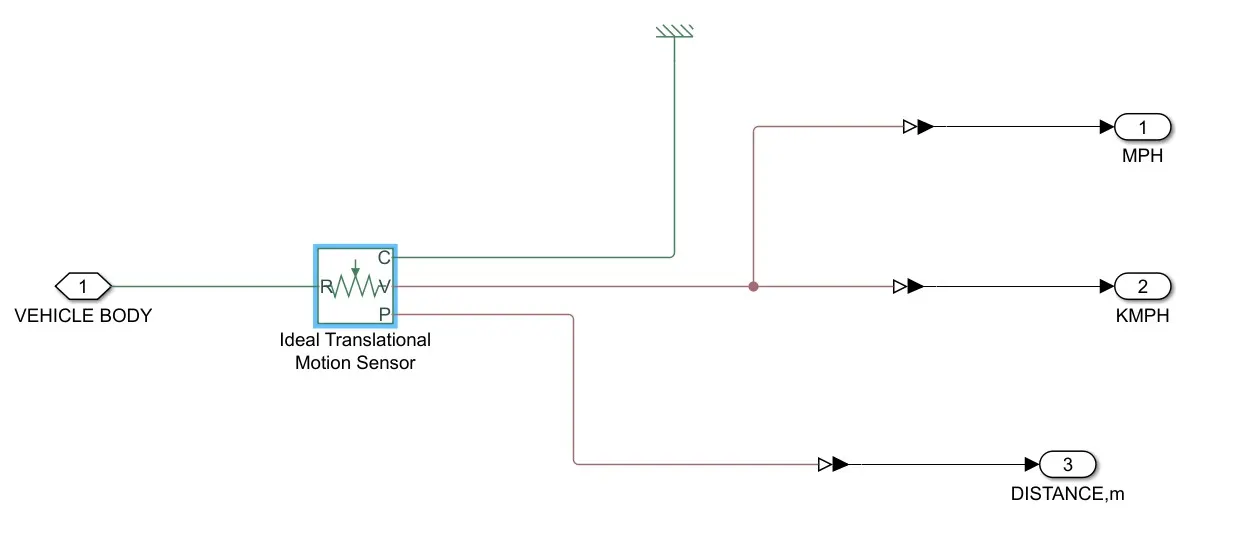
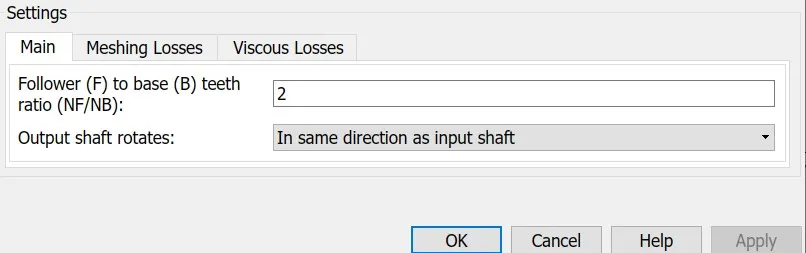
Simple Gear: Simple gear is used to represent a gearbox which is connected to the rear wheel axle. It is connected to the driveline axels of base gear, B, and the follower gear F, to corotate with a fixed ratio.
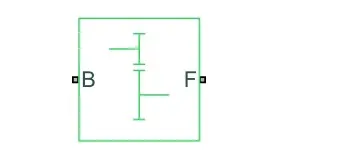
B: It represents the rotational mechanism associated with the base or input shaft.
F: It represents the rotational mechanism associated with the output shaft.
The parameter of the simple gear is shown below:-
MOTOR: DC motor model block is used to provide the required torque to the vehicle subsystem through the gear connection.
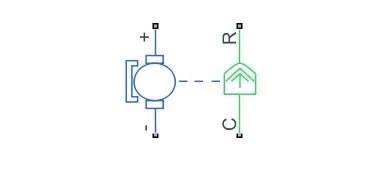
+, Positive terminal: This port is associated with the DC motor positive terminal.
-, Negative Terminal: This port is associated with the DC motor negative terminal.
C: Mechanical rotation conserving port associated with the DC motor case. It is connected with mechanical rotational referenced.
R: This mechanical rotation port is associated with the dc motor rotor. It is connected with the simple gear in our model, which issued to supply the required torque.
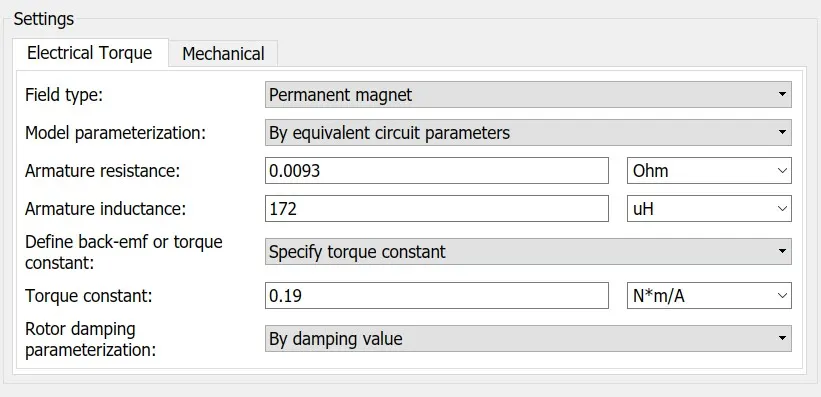
The various parameters of the motor are shown below:
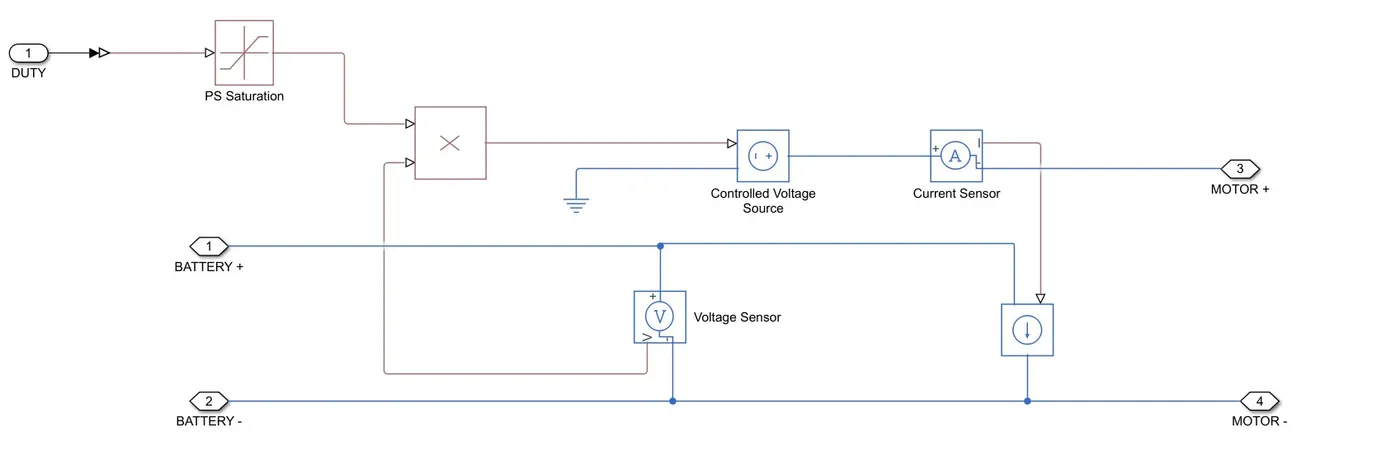
Pulse Width Modulation(PWM) : The pulse width modulation block is used to control the motor output by varying the duty cycle given to it. It works in accordance with the battery input which input is controlled with the controller. A duty cycle or power cycle is the fraction of one period in which a signal or system is active. The duty cycle is commonly expressed as a percentage or a ratio. Its value range from 0 to 12. The voltage sensor is used to measure the battery voltage and this voltage is multiplied with the duty cycle to get the supply voltage of the motor. A controlled voltage source block is used to maintain specific voltage towards motor control.
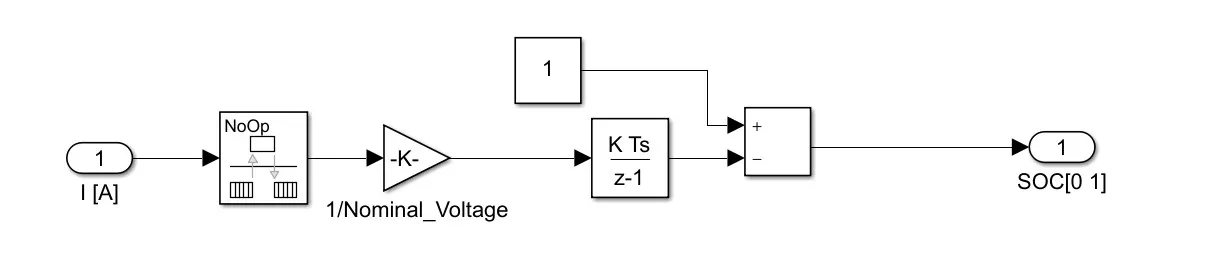
BATTERY: The battery is modeled with the help of an equivalent circuit of cell. Cells are connected in parallel and series connection to form a battery pack. SOC calculation has also been made to know the level of batteries charge remain in the system for functioning, and when to start the regenerative braking.
Results:-
For WOT (Wide Open Throttle) drive Cycle
Drive Cycle:-
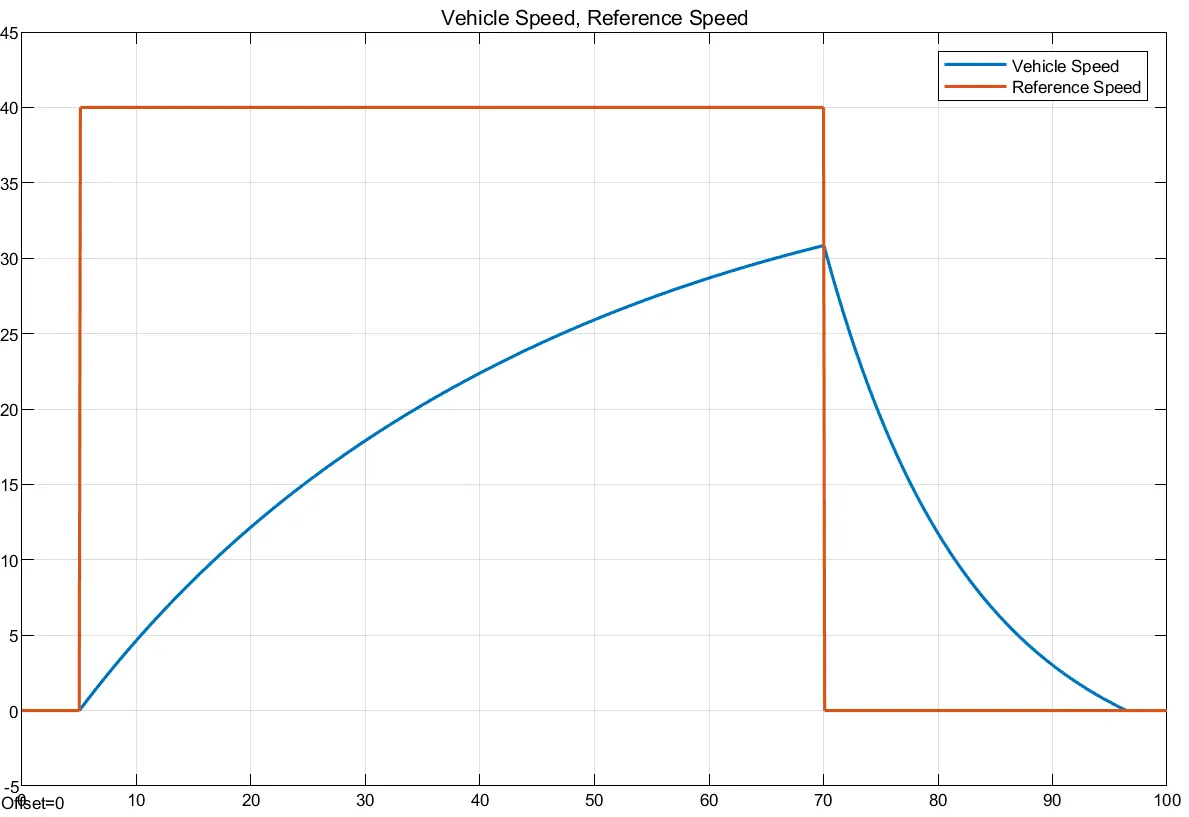
Vehicle speed doesn't follow much the given drive cycle as input but we can see that there is a declearation after the given time.
Further improvement can be done to match the input drive cycle by tuning the PID cycle further as per requirement.
Torque Output of Motor:-
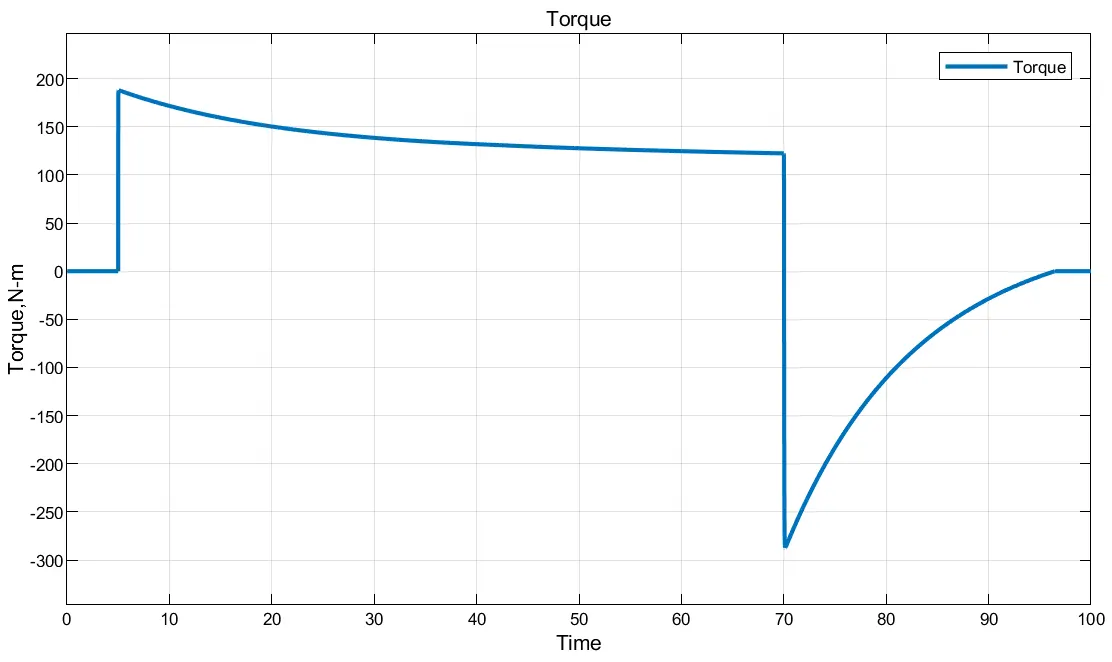
From the above figure we can see that the torque produced by the motor. At beginning we can see that the toque is zero as the vehicle is at off position . As the vehicle starts to accelerate the torque of motor also increases to maximum rated torque at maximum speed.
During decleration of vehicle , we can ses that the torque of motor decrease and become negative which can be used for regenerative braking of motor , which charge the vehicle at then then torque become zero as the vehicle stops.
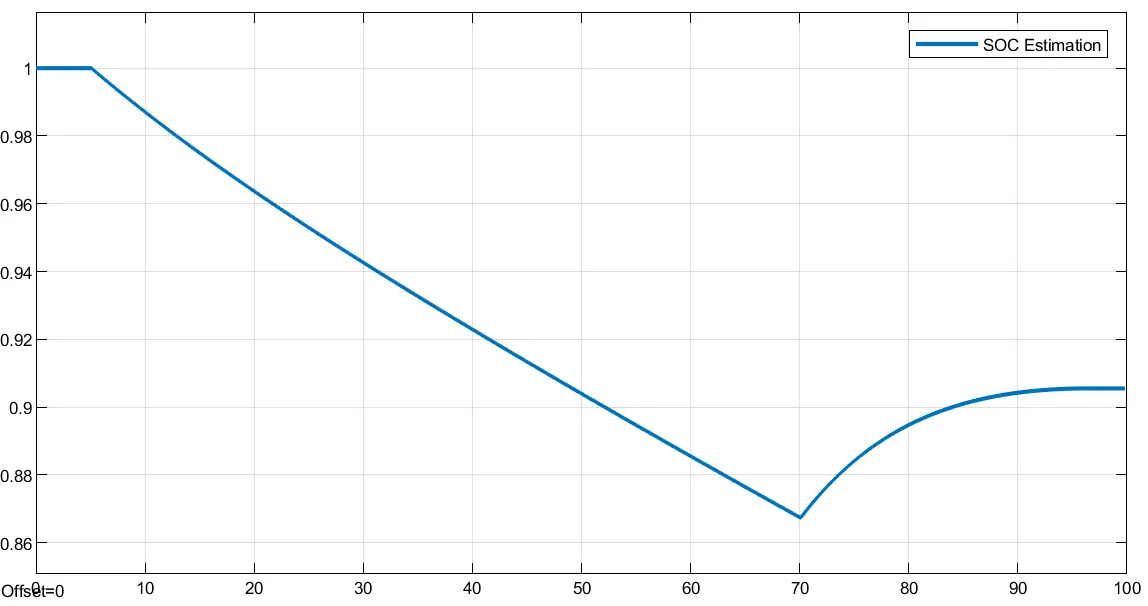
From the above plot we can see that the charge level of battery , as the vehicle starts to accelerate the battery charge level decreases and during deceleration after 70 sec during regenerative braking we can see that the SOC level of battery increase because of charging.
Vehicle Speed and distance Covered:-
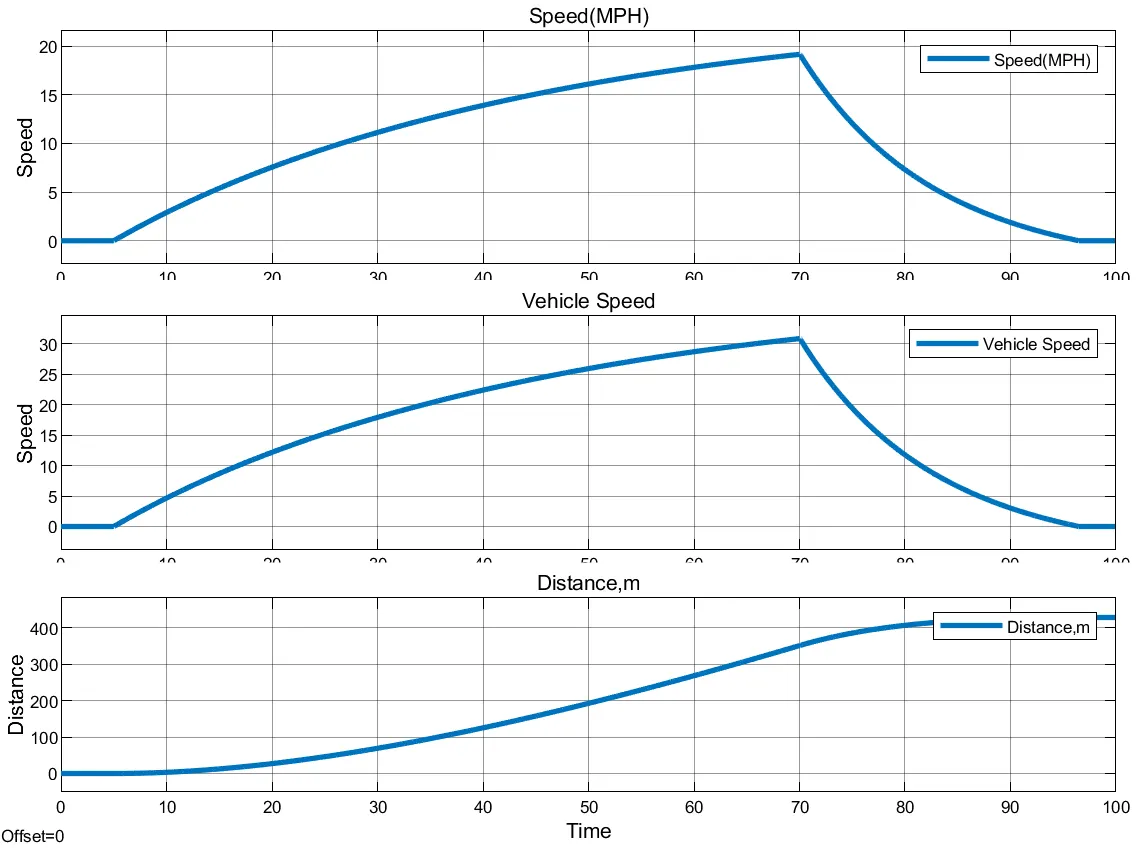
From the above plot we can see that the vehicle drive speed and drive cycle it follow. Ans we can also see distance covered by the vehicle. Totaol distance covered by the vehicle during runtime is 428.8m.
Conclusion:-
Pure Electric Vehicle model has been successfully designed in simulink .
WOT drive cycle is executed and its drive cycle had benn successfully implemented.