Final Project: Design of an Electric Vehicle
OBJECTIVE :
Create a MATLAB model of electric car which uses a battery and a DC motor. Choose suitable blocks from Powertrain block set. Prepare a report about your model including following:
Main Objectives:
1. System level configurations
2. Model parameters
3. Results
4. Conclusion
Introduction
A new study related to Vehicle/Automobile engineering says that by coming 2025 , there will be a major transformation in the automobile sector. Many automakers are working to change the vehicle technologies, the major area is to decrease the pollution and use electrification in the upcoming vehicles. The researchers and automakers are continuously working to reduce CO2 emissions.
New technology like high-capacity lithium type battery will be a major energy source for the propulsion of electric vehicles.
At present, with the new technologies, some manufacturer has launched its products which are Tesla, Chevy Bolt EV and Nissan leaf which are fully electric battery-based car.
The power and performance of electric vehicles is depending upon the two machines i.e., a brushless DC motor (BLDC) or an induction motor.
The DC (direct current) is replaced by DC brushless motors and Induction motors. Also, the lead acid battery is replaced by lithium-ion batteries for EVs.
Because the future of both the components induction or brushless DC motors depends upon their demands and uses.
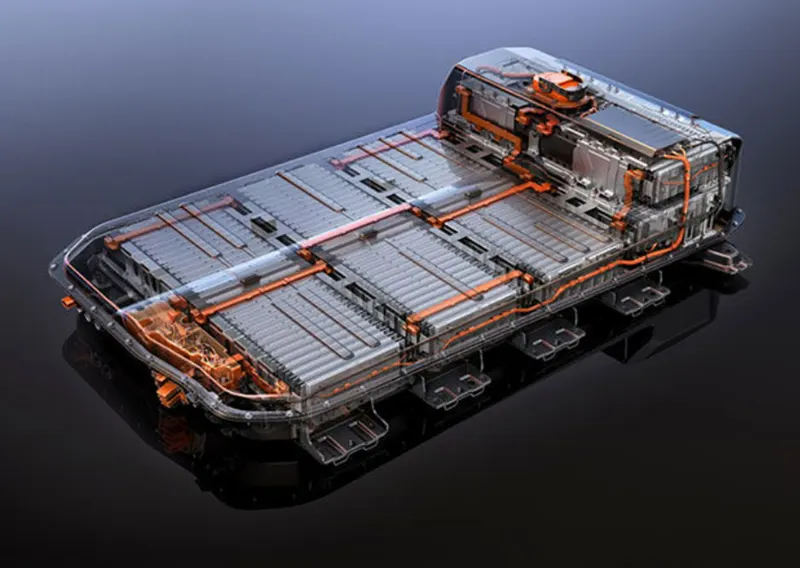
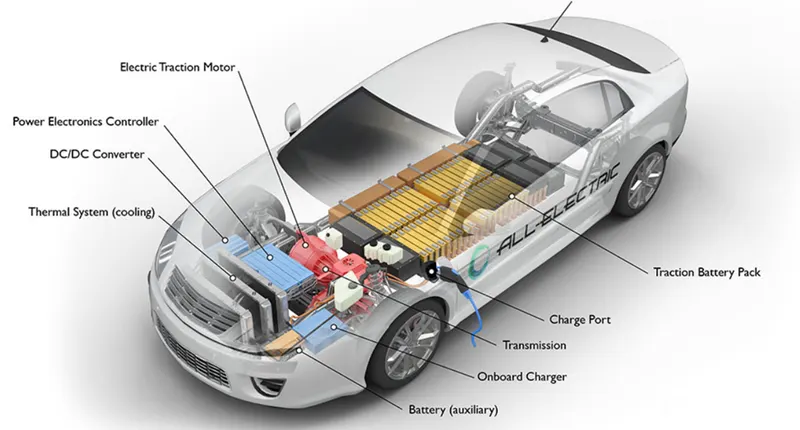
The most important components of electric vehicle areas:
- Auxiliary Battery: In an electric drive vehicle, the auxiliary battery provides electricity to power vehicle accessories.
- Traction Battery Pack: Traction battery pack is also known as Electric Vehicle Battery (EVB) which is used to store the electricity. Some examples of traction battery energy storage systems are as given:
- Lithium-Ion
- Nickel-Metal Hydride
- Lead-Acid
- Ultra-Capacitors
- DC/DC Converter: Basically, DC/DC converter is an electronic device which is used to converts higher-voltage DC power from the traction battery pack to the lower-voltage DC power. The converted power is used to run the vehicle accessories. It is also used to recharge the auxiliary battery.
- Electric Traction Motor: Another important component is electric traction motor and this device is used to provide motive power to the wheels.
- Onboard charger: Takes the incoming AC electricity supplied via the charge port and converts it to DC power for charging the traction battery. It monitors battery characteristics such as voltage, current, temperature, and state of charge while charging the pack.
- Power electronics controller: This unit manages the flow of electrical energy delivered by the traction battery, controlling the speed of the electric traction motor and the torque it produces.
- Charge port: The charge port allows the vehicle to connect to an external power supply in order to charge the traction battery pack.
- Thermal system (cooling): This system maintains a proper operating temperature range of the electric motor, power electronics, and other components.
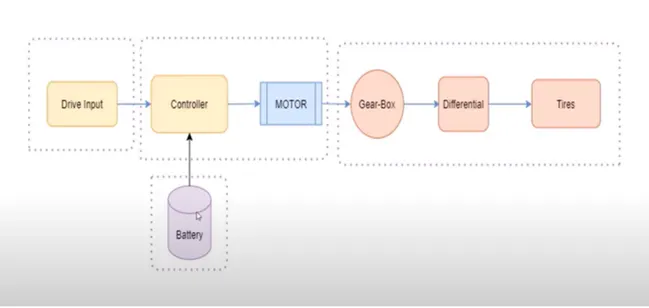
Simplified Block Diagram can be represented as follows:
OBJECTIVE FOR DESIGNING AN EV:
- To make a most simple \& low run time vehicle model using individual component models.
- To check out performance parameters: Speed, SOC, Current etc with various drive cycles.
- To play with: Motor power, Vehicle body (Rolling resistance, Air drag, Weight) inputs.
To know MATLAB models\& their configuration to match with actual vehicle
BLOCK DIAGRAM:
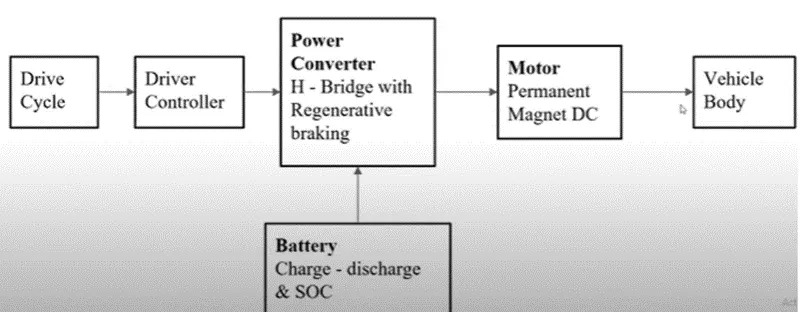
Modelling of EV using Simulink :
Overall simulink diagram with subsystems :
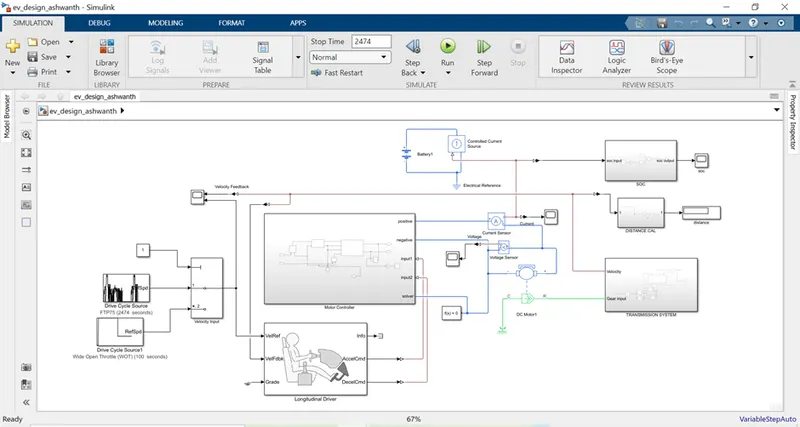
The above figure shows the complete model of an Electric Vehicle.
So, here we will be seeing complete construction of the above model step by step. The above model contains 4 subsystems. So, first we will be going through each
subsystem and see the components contain with full explanation of each and every component, their working etc.
CONSTRUCTION AND WORKING:
Let’s start from Transmission System as the model's construction starts from that:
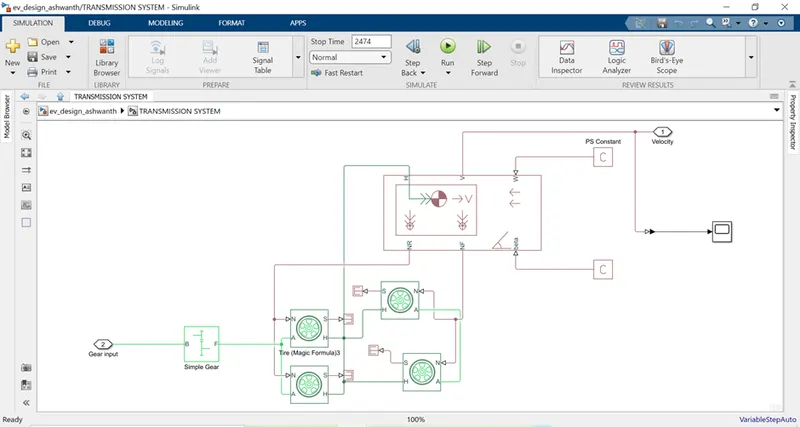
The above subsystem is the base of the model as, it contains:
Tires: - We are designing a 4-wheeler EV so we need 4 such tires, where H represents Hub, S as Tire slip, N as Normal Force and A as Axle connection.
Vehicle Body: - It represents a two-axle vehicle body in longitudinal motion. The block accounts for body mass, aerodynamic drag, road incline, and weight distribution between axles due to acceleration and road profile.
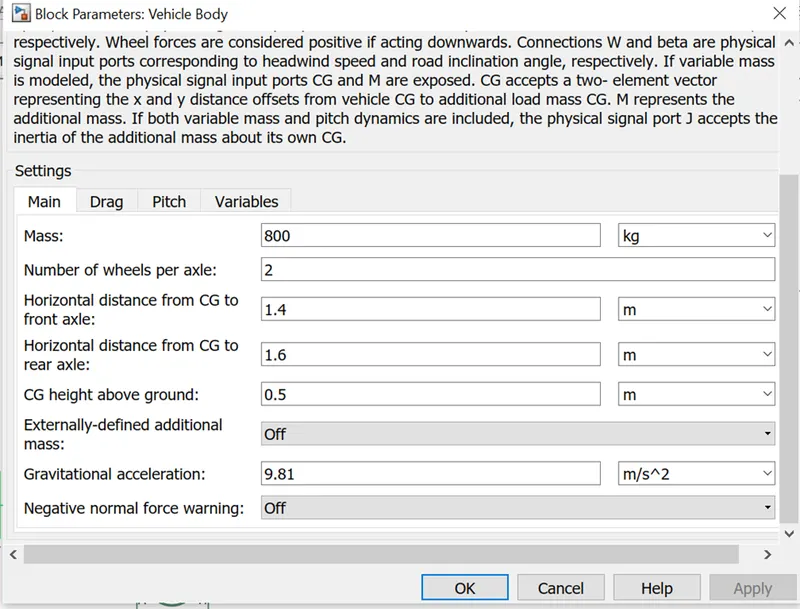
Connection H is the mechanical translational conserving port associated with the horizontal motion of the vehicle body.
The resulting traction motion developed by tires should be connected to this port.
Connections V, NF, and NR are physical signal output ports for vehicle velocity and front and rear normal wheel forces, respectively.
Wheel forces are considered positive if acting downwards. Connections W and beta are physical signal input ports corresponding to headwind speed and road inclination angle, respectively. If variable mass is modelled, the physical signal input ports CG and M are exposed.
CG accepts a two- element vector representing the x and y distance offsets from vehicle CG to additional load mass CG. M represents the additional mass. If both variable mass and pitch dynamics are included, the physical signal port J accepts the inertia of the additional mass about its own CG.
Simple Gear: - Represents a fixed-ratio gear or gear box. No inertia or compliance is modelled in this block.
we can optionally include gear meshing and viscous bearing losses. Connections B (base) and F (follower) are mechanical rotational conserving ports. Specify the relation between base and follower rotation directions with the Output shaft rotates parameter. Optionally include thermal effects and expose thermal conserving port H by setting Friction model to a temperature-dependent setting.
Summary of the subsystems in short:
Here, we first set the tires which will be operated through gear & the vehicle body from motor.
Then we setup the vehicle body which will represent all the weights and connects tires and a input is put open for velocity which will come from drive cycle later. Then we added simple gear which will help to move vehicle with the help of tires, it also has an input which will come from shaft of the motor.
Thus, we are ready with the base of our EV.
Now, we will move ahead with motor controller, which is the heart of our EV:
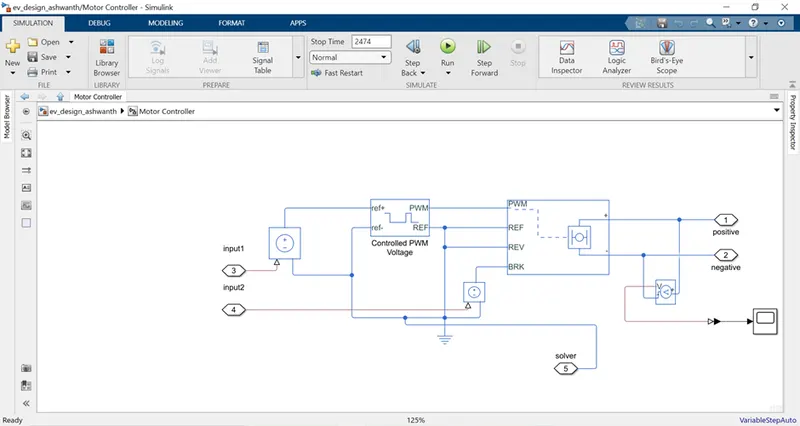
The above subsystem contains following components:
H-bridge:
This block represents an H-bridge motor drive. The block can be driven by the Controlled PWM Voltage block in PWM or Averaged mode. In PWM mode, the motor is powered if the PWM port voltage is above the Enable threshold voltage. In Averaged mode, the PWM port voltage divided by the PWM signal amplitude parameter defines the ratio of the on-time to the PWM period. Using this ratio and assumptions about the load, the block applies an average voltage to the load that achieves the correct average load current. The Simulation mode parameter value must be the same for the Controlled PWM Voltage and H-Bridge blocks. In simple words it’s a 4 no. of switches. And the data entered is as below.
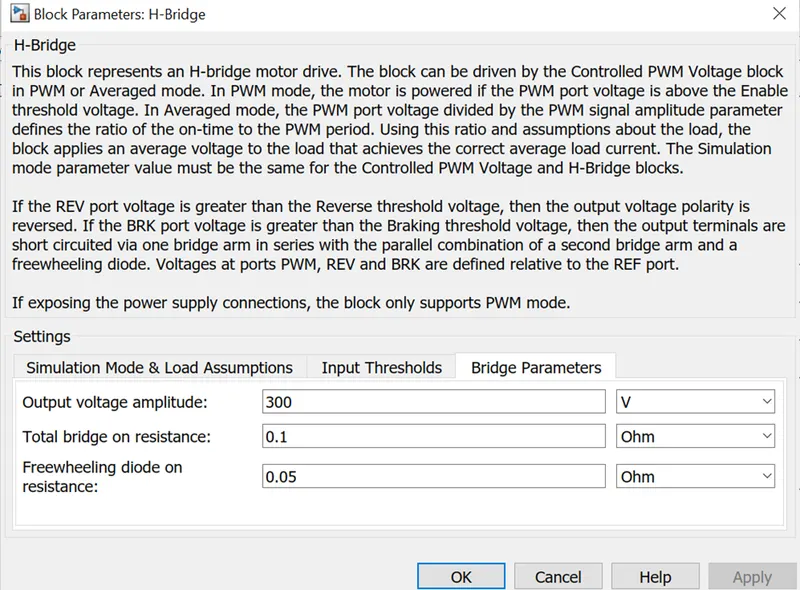
Controlled PWM voltage:
This block creates a Pulse-Width Modulated (PWM) voltage across the PWM and REF ports. The output voltage is zero when the pulse is low, and is equal to the Output voltage amplitude parameter when high. Duty cycle is set by the input value.
Summary of the subsystem:
The H-bridge is used due to the four inputs from PWM generators, REV, REF and braking. And another terminal is connected from motor, a voltage sensor is attached to it due to conversion of electrical signal to physical. On the other hand, PWM controlled voltage control is used for input to H-bridge.
Hence, in this subsystem we constructed the control system of our vehicle, where the two inputs are coming from longitudinal driver which commands control and both the components operate accordingly.
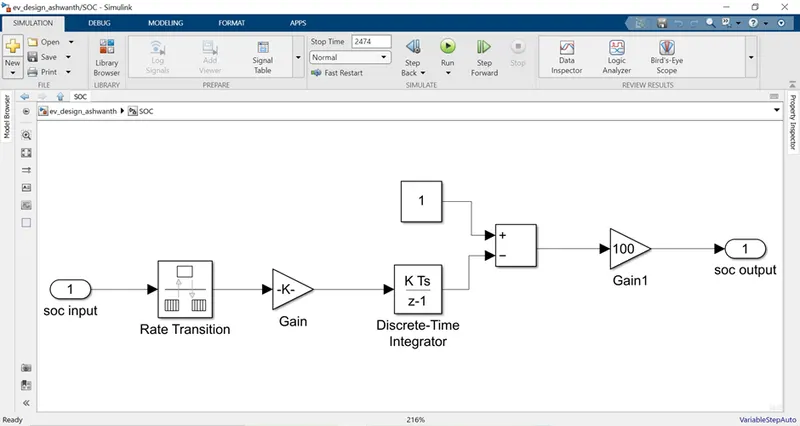
Now, let us give some light on, SOC and DISTANCE CALCULATOR:
SOC: In short it is State of charge and it's the subsystem which is been made to see the battery dissipation of the vehicle which it will be in running and shows the % of battery left. It contains of rate transition and discrete time integrator which converts and help in exchange of signals.
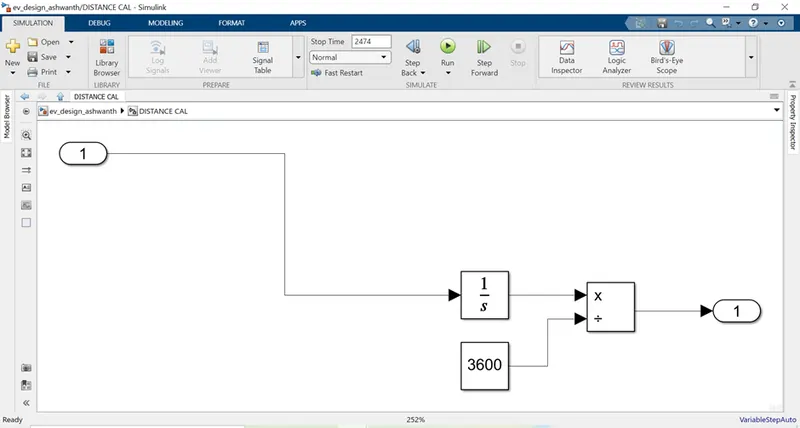
DISTANCE CALCULATOR: - This subsystem is made as a display to see the distance travelled by the vehicle. It contains an integrator, which helps to show the distance in kms when 3600 constant is multiplied to it.
So, till now we saw all the subsystems available in the model, now we will see the motor configuration ahead:
We have taken a simple DC motor with the following configurations: -
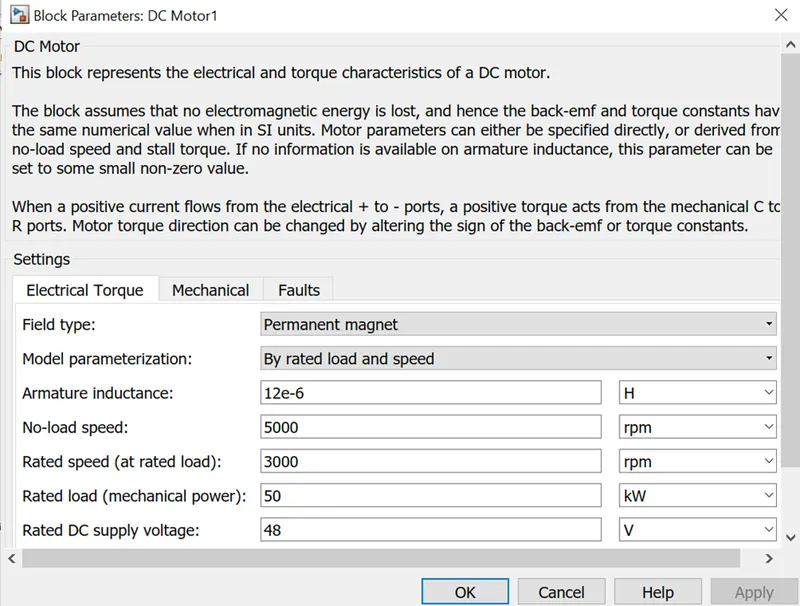
This block represents the electrical and torque characteristics of a DC motor.
The block assumes that no electromagnetic energy is lost, and hence the back-emf and torque constants have the same numerical value when in SI units. Motor parameters can either be specified directly, or derived from no-load speed and stall torque. If no information is available on armature inductance, this parameter can be set to some small non-zero value.
When a positive current flows from the electrical + to - ports, a positive torque acts from the mechanical C to R ports. Motor torque direction can be changed by altering the sign of the back-emf or torque constants.
It takes the input command from motor controller and delivers to transmission system. And for the time when vehicle gets brake it will work as generator and charge the battery for that moment due to regenerative braking.
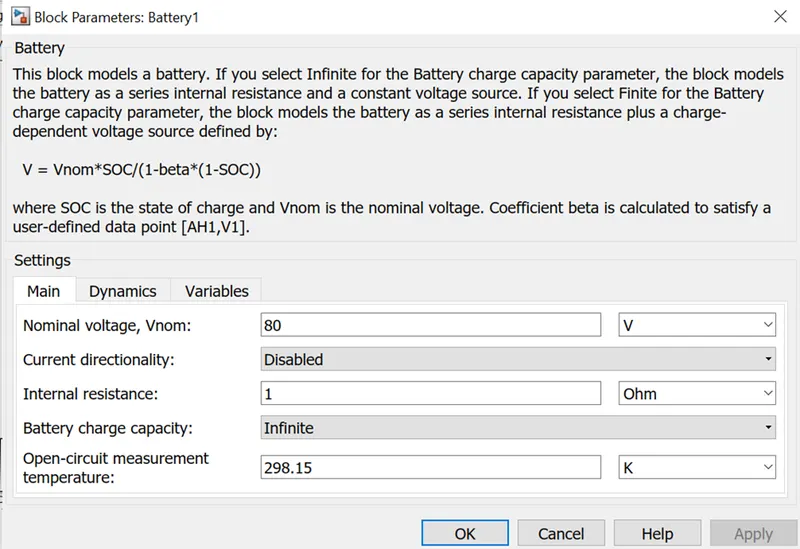
Let’s come to battery part, we will be using a simple battery which will be charged from outside means but in this case, we will be using a simple battery for quick simulation, with following parameters: -
LONGITUDINAL DRIVER: - It takes the input from velocity input for the drive cycles and give commands to motor controller so that it handles motor speed according to given drive cycles. But it is very difficult to maintain the same drive cycle as commanded.
We almost saw every important part of the model, but we forgot the most important one, i.e., input.
VELOCITY INPUT: - It is the multi-port input which Pass through the input signals corresponding to the truncated value of the first input. The inputs are numbered top to bottom (or left to right). The first input port is the control port. The other input ports are data ports. And we can give as many as input we want.
Here, we have given two drive cycles, if we want, we can even provide our own cycles with the help of self-made spreadsheet file attaching to multi-port switch.
WORKING:
Input Drive Cycle is given as soon as motor gets excited. The desired input from user is given to Velocity Input (i.e., to multiport switch) and it delivered cycles are been recorded for the comparison of initial input cycle and final output drive cycle. The same is been inputted to Longitudinal Driver which decodes the command and converts it to machine language and moves ahead to Motor Controller, (the commands are been executed with the help of Controlled PWM Voltage), which generates the pulses and H-Bridge which takes the multiple input and with the help of voltage and current sensors delivers the command signal to Motor.
According to the signals, the current and voltage fluctuation is noted,
Then Controlled Motor, signals to transmission system (which is the real practical part), where a simple gear is attached to the wheels(tires) offers acceleration, de-acceleration, braking and reverse motoring and thus, accordingly vehicle body works.
The final velocity is been noted and later to be compared with inputted one.
Simultaneously, battery performance is also recorded for the efficiency of our vehicle. The whole performance of vehicle through the journey of 2474 seconds is been recorded.
Now, let us see the results and find how efficient our vehicle is.
RESULTS:
Comparison between commanded drive cycle with resultant drive cycle
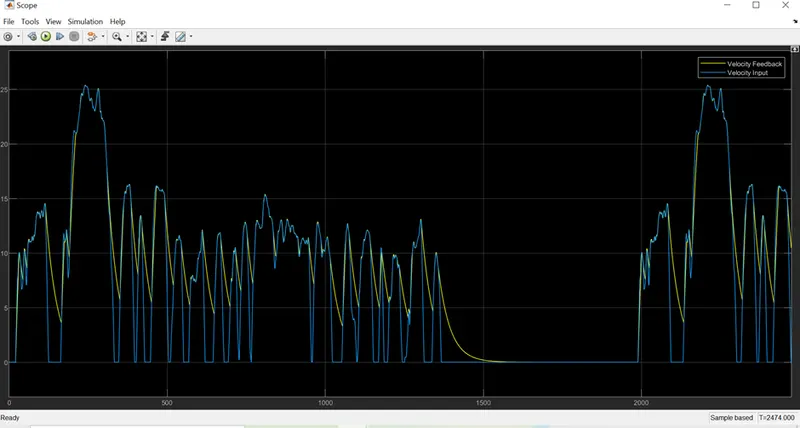
The above figure shows the graph both the drive cycles, blue colour is for input signal and Yellow for final output.
By going through the graph, we can note the following points: -
- Both signals are almost same while acceleration command is seen.
- While deacceleration also the output almost tried to copy instruction
But when a sudden braking input is applied to the model it is not replicating to the input.
The sudden braking input could not be replicated as it is dangerous and more ore less impossible to stop the running car running at certain velocity as it acquires certain kinetic energy and work done starts.
Now, let’s see the output current fluctuation
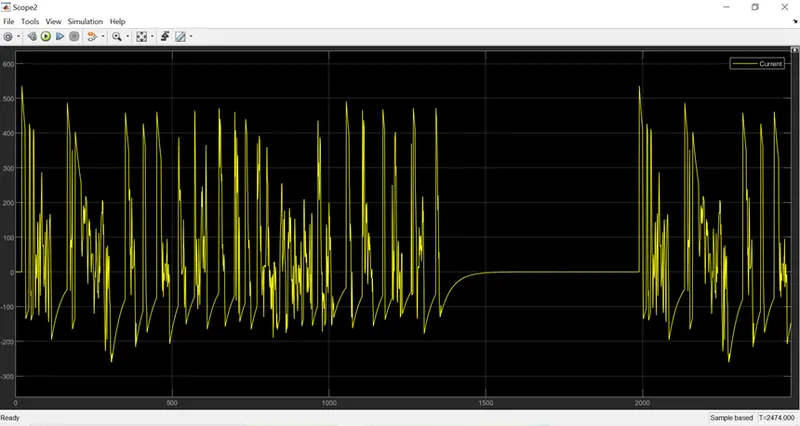
We can see a huge fluctuation is occurred during the performance, while the vehicle experiences acceleration, deacceleration and braking and for some time vehicle seen to be running in constant speed and at rest in middle of journey too.
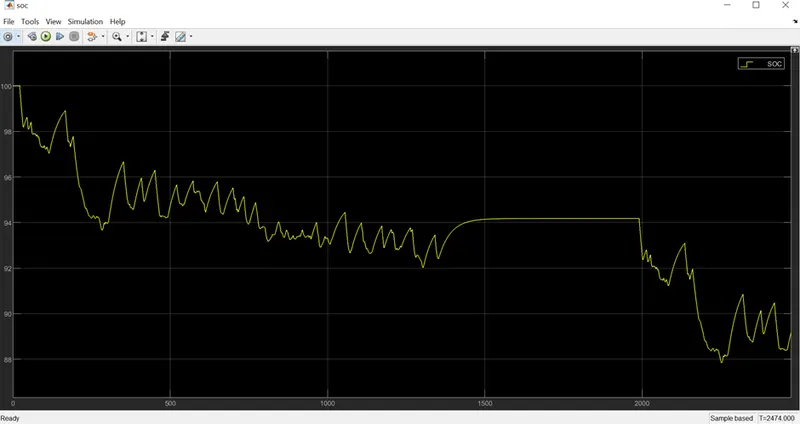
So, we have seen the velocity performance and current output, now let us see the battery performance during the journey and how much battery is still left after completion of journey,
Here, we can see more than 80% of battery is still left for more operation. And according to graph we can see the graph is continuously decreasing due to running of vehicle. But if we see how regenerative braking occurs. And if we see carefully, we could notice when the deacceleration or braking is occurred battery percentage is always increased. Thus, if helps the vehicle to improve the efficiency and increase working period.
State of charge SOC:
CONCLUSION:
Thus, while making this project we come to learn many different things which is required to make and run an Electric Vehicle.
EV has obtained an output according to the FTP75 drive cycle and it can be tested for any drive cycle by selecting in the drive cycle block. It has travelled nearly 6 km by the present 89AH battery capacity if we increase the battery capacity to higher levels, we can travel more distance but in the real time this should be done by considering the space and cost.
Links and References :
Gdrive Link :
https://drive.google.com/drive/folders/1S3yhUSvju_dZkNYPWZ8alB6SBh61IVwI
References :
1. Electric Vehicle info website
2. Mathworks documentation
3. Google Image search