FINAL INDEPENDENT PROJECT - FORWARD MOTION KINEMATICS OF 3R ROBOTIC ARM
FORWARD MOTION KINEMATICS OF 3R ROBOTIC ARM
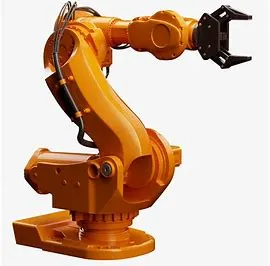
A robotic arm is a kind of open kinematic chain, which is really just a collection of link and joints. Usually at the end of this chain is a tool of some kind, like a gripper or a welder or a drill. This is called the end-effector.
GEOMETRY INFORMATION:
PROGRAM EXPLANATION:
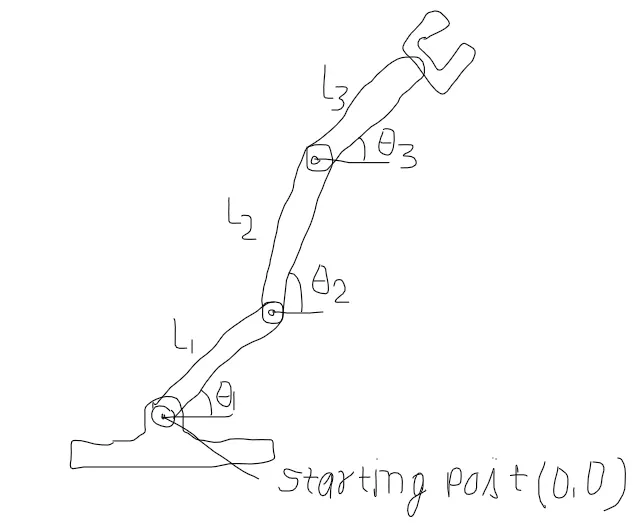
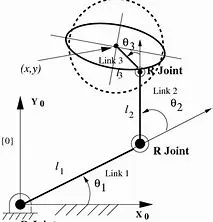
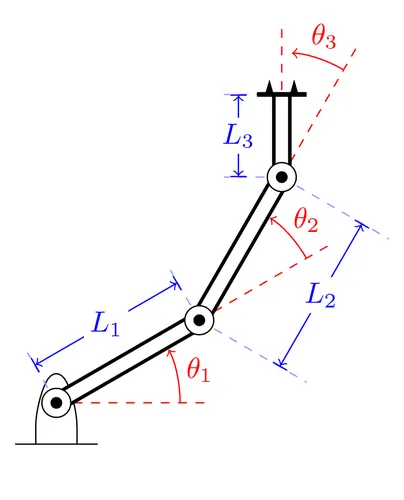
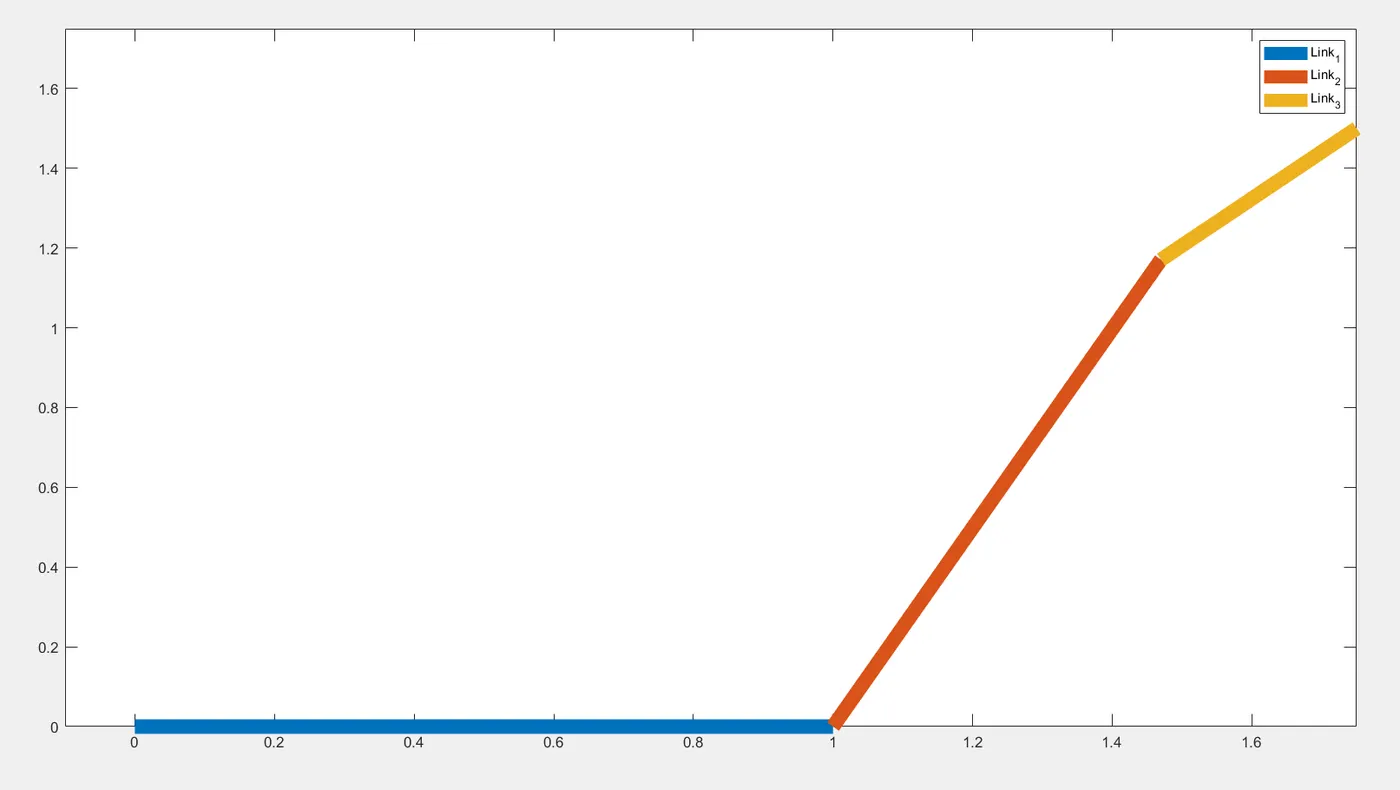
I'm making a program for forward kinematic 3r robotic arm, here I'm using 3 link's L1, L2 and L3 where l1=1, l2=0.5 and l3=0.25 . Angle for each link θ1, θ2, and θ3 where θ1 is between (0,90), θ2 between(0,90) and θ3 between (0,360). Starting point for link l1 is (x0, y0) and ending point is (x1,y1), ending point for link l2 is (x2,y2), and ending point for link l3 is (x3,y3).
(cosd) where 'd' is define angle in degree.
1. Program to simulate the forward kinematic 3R Robotic Arm.
2. Giving all inputs for link l1, l2 and l3.
3. Giving angle for link l1, l2 and l3.
4. Ct to ct+1 is incrementing the value.
5. Coordinates and end points for all link's (x0,y0), (x1,y1), (x2,y2) and (x3,y3).
6. Plotting simulation of arm.
7. Pause(0.03) pause the value for theta in each place.
x and y limit [-0.1 1.75 0 1.75].
8. Capture the current plot to combine later.
9. Increase the ct so each frame capture in M.
10 Making a movie for robotic arm and save vedio in video file.
FORMULA'S:
x1=l1*cosd(THETA1) x2=l1+l2*cosd(THETA2) x3=l1+l2+l3*cosd(THETA3)
y1=l1*sind(THETA1) y2=l1+l2*sind(THETA2) y3=l1+l2+l3*sind(THETA3)
ct=ct+1.
PROGRAM:
%Program to simulate the forward kinematic 3R Robotic Arm
clear all
close all
clc

%Giving inputs
%L1, L2 and L3 are the length of link-1,2 and 3.

l1=1;
l2=0.5;
l3=0.25;

%Angle for link L1
theta1=linspace(0,90,10);

%Angle for link L2
theta2=linspace(0,90,10);

%Angle for link L3
theta3=linspace(0,360,10);

ct=1;
for i=1:length(theta3)
    THETA1=theta1(i);

    for j=1:length(theta3)
        THETA2=theta2(j);

        for k=1:length(theta3)
            THETA3=theta3(k);


        %coordinates of link L1
        x0=0;
        y0=0;

        %End point of link L1
        x1=l1*cosd(THETA1);
        y1=l1*sind(THETA1);

        %End point of link L2
        x2=l1+l2*cosd(THETA2);
        y2=l1+l2*sind(THETA2);

        %End point of link L3
        x3=l1+l2+l3*cosd(THETA3);
        y3=l1+l2+l3*sind(THETA3);

        %plotting simulation of Arm

        plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],[x2 x3],[y2 y3],'linewidth',10)
        axis([-0.1 1.75 0 1.75])
        legend('Link_1','Link_2','Link_3');

        %Plot
        pause(0.03)

        %capture the current plot to combine later
        M(ct)=getframe(gcf);

        %Increment the ct so each frame capture in M
        ct=ct+1;
        end

    end
end
%Making amovie for Robotic Arm
movie(M);

%Creating a video file
videofile=VideoWriter('forward_kinematics_of_3R_robotiv_arm.avi','Uncompressed avi');
open(videofile);

%Video  in videofile
writeVideo(videofile,M)
close(videofile)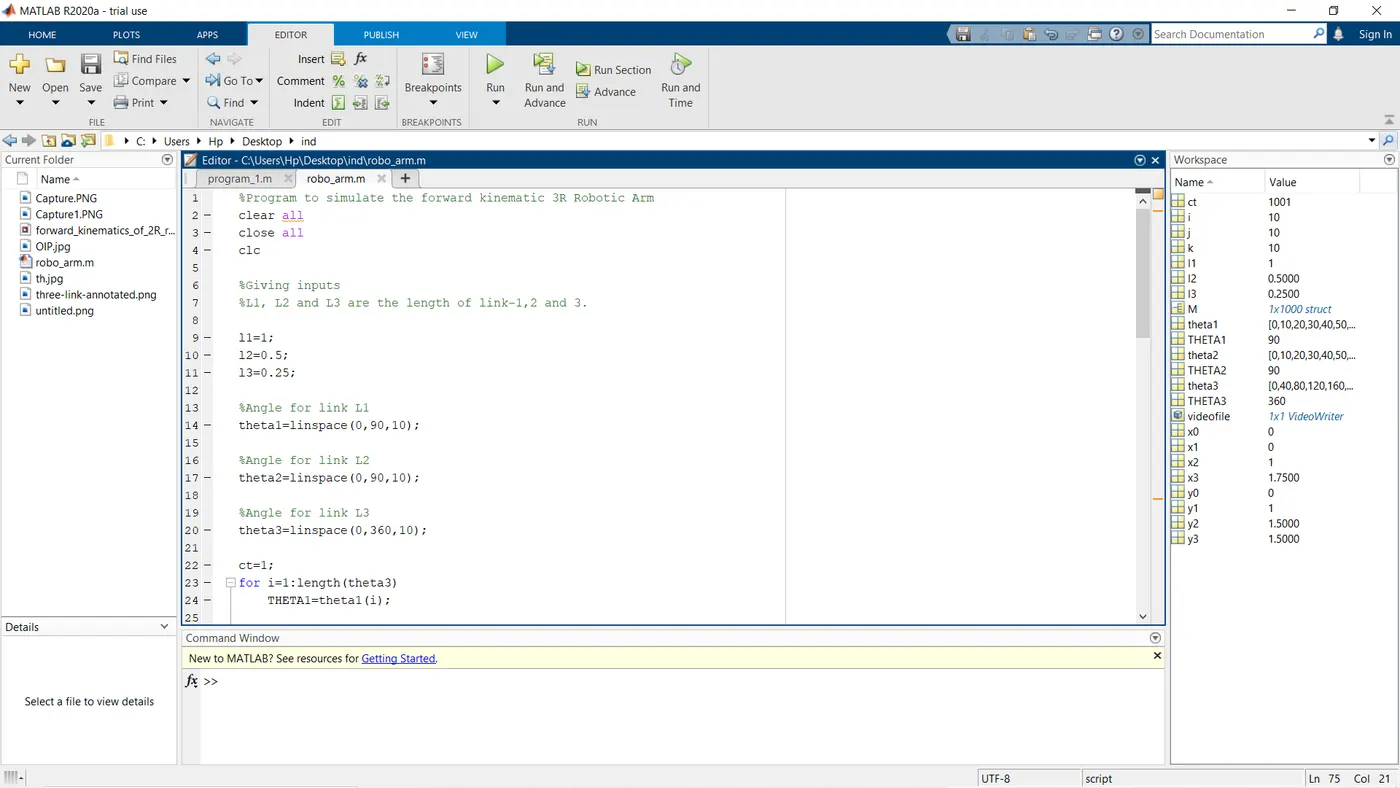
OUTPUT: I am attaching an animation video
APPLICATIONS:
1. Gripper or a welder or a drill
2. The tools and objects it can carry- painting (cars).
3. Soldering (cars).
4. Access unevenly placed parts (for scanning, selecting...).
5. Pick and place (most industries, a lot for food industry).
6. Third hand: the arm carries the object and the operator can work on it easily.
7. Act in a human-designed environment: send the arm on a mobile base to a.