damper matlab
please see the following matlab file:
https://drive.google.com/file/d/1MkUdwyVB7UF0fyGJ9vW0XogQRE-GdxwI/view?usp=sharing
code:
clear all
close all
clc
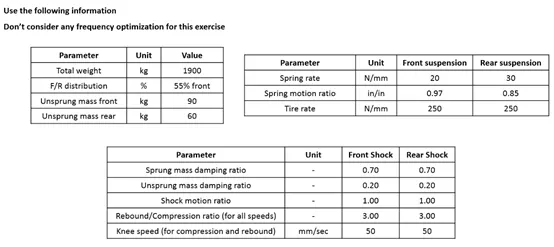
spring_rate=20000
spring_rate_rear=30000
tire_rate=250000
sprung_mass_damping_ratio=0.7
unsprung_mass_damping_ratio=0.2
rebound_to_compression_ratio=3
knee_speed=50
total_design=1900
corner_weight_unsprung_front=90/2
corner_weight_unsprung_rear=60/2
front_ratio=0.55
rear_ratio=1-front_ratio
axle_front=total_design*front_ratio
axle_rear=total_design*rear_ratio
corner_front_sprung=(axle_front/2)-corner_weight_unsprung_front
corner_rear_sprung=(axle_rear/2)-corner_weight_unsprung_rear
motion_ratio_front_design=0.97
motion_ratio_rear_design=0.85
wheel_rate_front=(spring_rate)*((motion_ratio_front_design)^2)
ride_rate_front=(wheel_rate_front*tire_rate)/(wheel_rate_front+tire_rate)
nat_freq_front=(1/(2*pi))*(sqrt((ride_rate_front)/(corner_front_sprung)))
wheel_rate_rear=(spring_rate_rear)*((motion_ratio_rear_design)^2)
ride_rate_rear=(wheel_rate_rear*tire_rate)/(wheel_rate_rear+tire_rate)
nat_freq_rear=(1/(2*pi))*(sqrt((ride_rate_rear)/(corner_rear_sprung)))
critical_damping_sprung_front=2*(sqrt(ride_rate_front*corner_front_sprung))
critical_damping_sprung_rear=2*(sqrt(ride_rate_rear*corner_rear_sprung))
ride_rate_front_unsprung=(wheel_rate_front+tire_rate)
ride_rate_rear_unsprung=(wheel_rate_rear+tire_rate)
critical_damping_unsprung_front=2*(sqrt(ride_rate_front_unsprung*corner_weight_unsprung_front))
critical_damping_unsprung_rear=2*(sqrt(ride_rate_rear_unsprung*corner_weight_unsprung_rear))
damping_coefficient_front=sprung_mass_damping_ratio*critical_damping_sprung_front
damping_coefficient_rear=sprung_mass_damping_ratio*critical_damping_sprung_rear
damping_coefficient_front_unsprung=unsprung_mass_damping_ratio*critical_damping_unsprung_front
damping_coefficient_rear_unsprung=unsprung_mass_damping_ratio*critical_damping_unsprung_rear
ls_compression=(damping_coefficient_front)/(2*1000)
hs_compression=(damping_coefficient_front_unsprung)/(2*1000)
ls_rebound=(damping_coefficient_front*3)/(2*1000)
hs_rebound=(damping_coefficient_front_unsprung*3)/(2*1000)
ls_compression_rear=(damping_coefficient_rear)/(2*1000)
hs_compression_rear=(damping_coefficient_rear_unsprung)/(2*1000)
ls_rebound_rear=(damping_coefficient_rear*3)/(2*1000)
hs_rebound_rear=(damping_coefficient_rear_unsprung*3)/(2*1000)
velocity=linspace(0,500,300)
for i=1:length(velocity)
v=velocity(i)
if v<= knee_speed
force_comp(i)=ls_compression*v
force_rebound(i)=-(ls_rebound*v)
force_comp_rear(i)=ls_compression_rear*v
force_rebound_rear(i)=-(ls_rebound_rear*v)
else
force_comp(i)=force_comp(i-1)+((v-velocity(i-1))*(hs_compression))
force_rebound(i)=force_rebound(i-1)-((v-velocity(i-1))*(hs_rebound))
force_comp_rear(i)=force_comp_rear(i-1)+((v-velocity(i-1))*(hs_compression_rear))
force_rebound_rear(i)=force_rebound_rear(i-1)-((v-velocity(i-1))*(hs_rebound_rear))
end
i=i+1
end
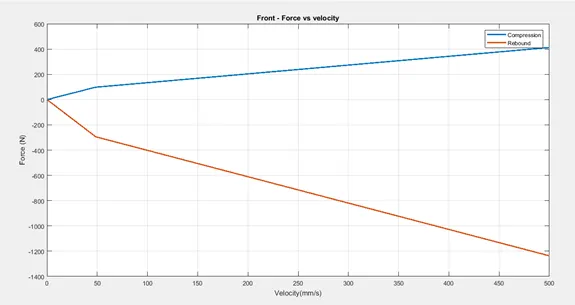
figure(1)
plot(velocity,force_comp,'Linewidth',2);
hold on
plot(velocity,force_rebound,'Linewidth',2);
title('Front - Force vs velocity');
xlabel('Velocity(mm/s)');
ylabel('Force (N)');
legend('Compression','Rebound');
grid on
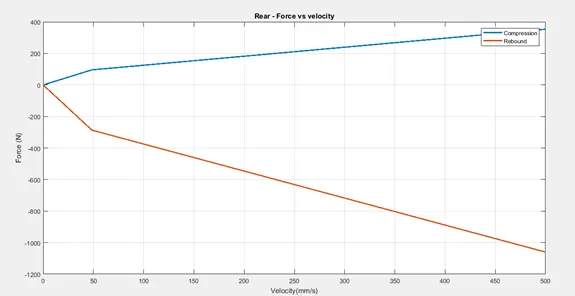
figure(2)
plot(velocity,force_comp_rear,'Linewidth',2);
hold on
plot(velocity,force_rebound_rear,'Linewidth',2);
title('Rear - Force vs velocity');
xlabel('Velocity(mm/s)');
ylabel('Force (N)');
legend('Compression','Rebound');
grid on
steps:
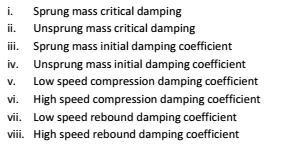
-The front corner sprung weight is calculated for the front and rear
-then the front and rear sprung wheel rate and ride rate is calculated
-the front and rear sprung critical damping is calculated
-then unsprung corner weights are calculated for front and rear
-then unsprung ride rates are calculated for front and rear
-then unsprung critical damping is calculated
-then front and rear sprung damping coefficient calculated
-then front and rear unsprung damping coefficient calculated
Then low speed and high speed damping in compression and rebound is calculated for the front
-then low speed and high speed damping coefficient is calculated for the rear
-Then force velocity curve is plotted
-for that the limits of velocity and number of outputs between these limits are determined by linspace command
-Then using if conditional inside a for loop the high sped and low speed damping force can be calculated using the knee speed provider as the the input to the if condition,so if the velocity is lower than knee speed ,low speed force equations ae used,and if it is higher high speed force equations are used
-then the front and rear outputs are plotted in different plots using figure command
output plots: