Assignment 7-Side Pole Crash Simulation Challenge
SIDE POLE CRASH SIMULATION OF DODGE NEON CAR
Project 2 – Crashworthiness Analysis Using Hypermesh, Radioss and HyperCrash(SIDE POLE CRASH ANALYSIS)
Aim:
- To perform the crash analysis on the side section of the car and to check where the stresses are acting on it.
- To check the unit systems and change if necessary
- Create an interface of Type 7 with the friction value of 0.2 and other parameters.
- Making sure there aren’t any penetrations
- Correct rigid bodies for any issues
- Create a rigid wall with friction 0.1.
- Compare the model weight with the full-scale 300k nodes model and use added masses to reach the target weight of 700kg while getting CG about the required range.
- Give an initial velocity of 35 mph.
- Use a model checker to ensure good quality.
- Give the Time-step: 0.5 microsecond.
- Give Run time as 80 ms.
Output Requests:
- Sectional force in the cross member.
- Intrusion at B Pillar,hinge pillar & Fuel tank region.
- Peak velocity of inner node of the door.
ABSTRACT:
The crash test is a virtual reconstruction that replicates the same forces and speeds that would occur if the vehicle was to be involved in an actual crash. In this type of testing, since nothing is physically impacting the Body-in-White (BIW), no physical deformation or damage occurs to the body’s structure, allowing multiple crashworthiness tests to be conducted in succession. This type of simulation is an integral part of the design process and can help save both time and money since it can be implemented instead of costly, destructive testing programs.
For this project, the case setup and simulation are to be done in Hypermesh and Hypercrash, whereas Hyperview and Hypergraph 2D will be used for post-processing. Hypergraph will be used to plot energies, Von-Mises stresses, plastic strains, acceleration curves, and force and Hyperview will be used to view the simulation.
As part of the process, we are to create a rigid wall, check penetrations, assign an initial velocity of 35mph, carry out mass balancing to ensure the total weight comes to 700 kgs, and finally, create sections, intrusions, as part of the output request requirements.
A. What is a Crash Test?
A crash test is a form of destructive testing usually performed in order to ensure safe design standards in crashworthiness and crash compatibility for various modes of transportation or related systems and components.
B. Various Crash Test
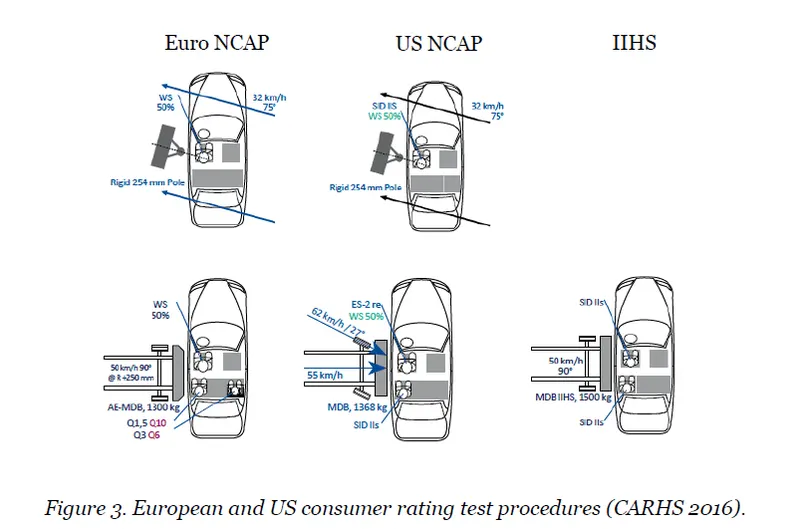
A crash test is a form of destructive testing usually performed in order to ensure safe design standards in crashworthiness and crash compatibility for various types of vehicle like small, medium and heavy-duty and its related systems and components for the sake of getting the performance of the vehicle under the different conditions of the crash at different angles with taking certain object like a rigid wall, cables specially three-strand cable, concrete barriers, guardrail systems etc. It will be performed either by numerical simulations or experimentally. The figure below illustrates different types of crash test generally used.
- Frontal Impact test- In this test a fully front structure of the vehicle collides with another object like another vehicle, rigid wall etc. at a given speed.
- Offset Test- In this test, only a part of the front portion of the vehicle strikes on some barrier usually a vehicle at a given speed.
- Small Overlap Test- In this only a small portion of the vehicle strikes an object like a tree, pole or if a car were to clip another. This situation loads a maximum value of force into the vehicle structure at a particular given speed. This test usually comprises 15% to 20% of the front structure.
- Side Impact Test- In this test sometimes the vehicle is in static condition or in dynamic and another vehicle or an object collide at the side surface having some speed.
- Roll-Over Test- In this test a vehicle is in rollover condition having a certain angle by which they test (specifically the pillars holding the roof) to support itself in a dynamic impact. It is also done for the static crash testing condition.
- Roadside Hardware- These are performed to ensure that the crash barriers and crash cushions will protect vehicle occupants from roadside hazards.
- Old Versus New- In this, an impact is done between an old car against a new car and the big car against a small car it is performed to show the advancements in crashworthiness.
Crash tests are conducted under rigorous scientific and safety standards. Each crash test is very expensive so the maximum amount of data must be extracted from each test. Usually, this requires the use of high-speed data acquisition, at least one triaxial accelerometer and a crash test dummy, but often includes more. A crash test is much important which helps in minimizing the losses such as deaths, injuries, and property damages from vehicle crashes on the roads.
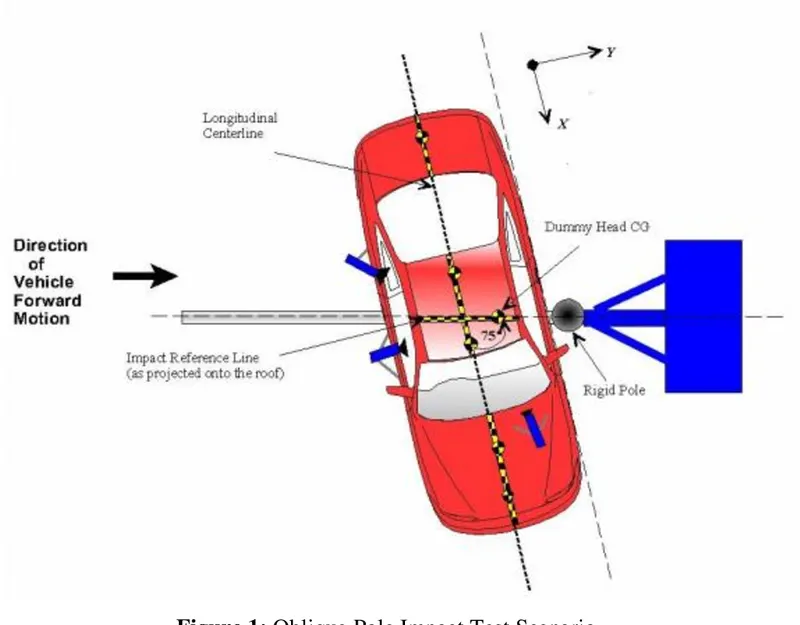
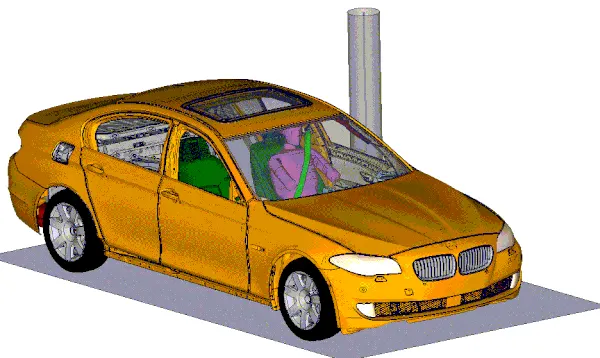
In this Project, we must perform the side pole crash of the vehicle. side impacts are the impacts undertaken against the solid cylindrical pole with precise speed. The test requires the side portion of the vehicle to impact the pole.
In the New Car Assessment Program (NCAP), passenger vehicles are crashed at 35 mph into a rigid barrier that covers the full width of the vehicle. The Institute runs offset side tests instead of full-width side tests. In an offset crash only one side of a vehicle side end, not the full width, hits the barrier.
C. HOW CRASH TESTING WORKS
A crash test is a form of destructive testing usually performed in order to ensure safe design standards in crashworthiness and crash compatibility for various modes of transportation-related systems and components.
Crash test dummies have been the subject of public service announcements, cartoons, parodies, even the name of a band. Real crash test dummies, however, are true life-savers as an integral part of automotive crash tests. Even though cars get a little safer each year, and fatality rates are declining, car crashes are still one of the leading causes of death and injury in the United States.
One of the reasons cars have been getting safer is because of a well-established testing program.
The dummies contain three types of instrumentation:
D. Accelerometers: These devices measure the acceleration in a particular direction. This data can be used to determine the probability of injury. Acceleration is the rate at which speed changes. For example, if you bang your head into a brick wall, the speed of your head changes very quickly (which can hurt). But, if you bang your head into a pillow, the speed of your head changes more slowly as the pillow crushes (and it doesn't hurt).The crash-test dummy has accelerometers all over it. Inside the dummy's head, there is an accelerometer that measures the acceleration in all three directions (fore-aft, up-down, left-right). There are also accelerometers in the chest, pelvis, legs, feet and other parts of the body.
- Load Sensors: Inside the dummy are load sensors that measure the amount of force on different body parts during a crash.
- Movement Sensors: These sensors are used in the dummy's chest. They measure how much the chest deflects during a crash.
E. Crashworthiness Requirements:
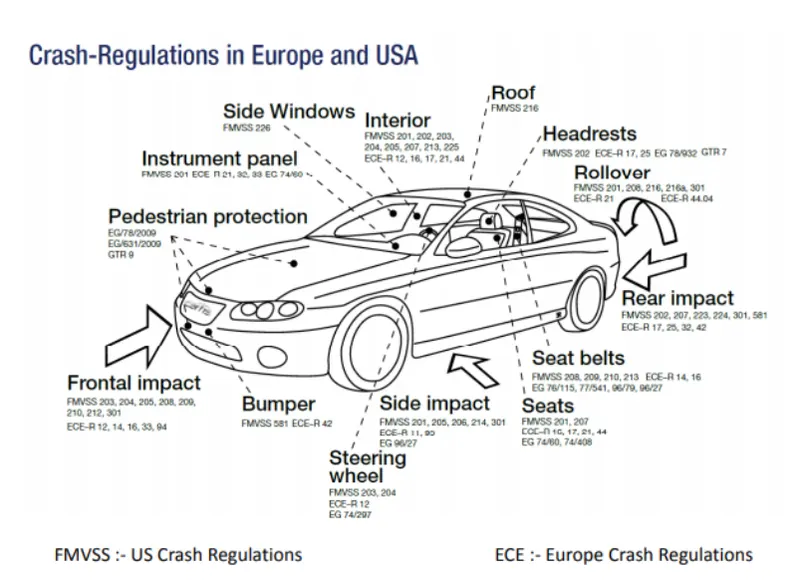
The vehicle structure should be sufficiently stiff in bending and torsion for proper ride and handling. It should minimize high-frequency fore-aft vibrations that give rise to harshness. In addition, the structure should yield a deceleration pulse that satisfies the following requirements for a range of occupant sizes, ages, and crash speeds for both genders: Deformable, yet stiff, front structure with crumple zones to absorb the crash kinetic energy resulting from frontal collisions by plastic deformation and
prevent intrusion into the occupant compartment, especially in case of offset crashes and collisions with narrow objects such as trees.
- Short vehicle front ends, driven by styling considerations, present a challenging task to the crash-worthiness engineer.
- Deformable rear structure to maintain the integrity of the rear passenger compartment and protect the fuel tank.
- Properly designed side structures and doors to minimize intrusions in side impact and prevent doors from opening due to crash loads.
- Strong roof structure for rollover protection.
- Properly designed restraint systems that work in harmony with the vehicle structure to provide the occupant with an optimal ride down and protection in different interior spaces and trims.
- Accommodate various chassis designs for different power train locations and drive configurations.
PROCEDURE:
- Check for UNIT SYSTEM
- Import model in HYPERCRASH
- Check for penetration and intersection
- Add masses to reach a target weight of 700kg
- Export changes file and import in HYPERMESH
- Create Interface contact's
- Create a rigid wall
- Add velocity to the nodes
- Create cross-section's
- Create TH for section forces, intrusion springs, interface contacts
- Create cards
- Model checker
unit system used for analysis is "kg mm ms".
1. Imported Model:
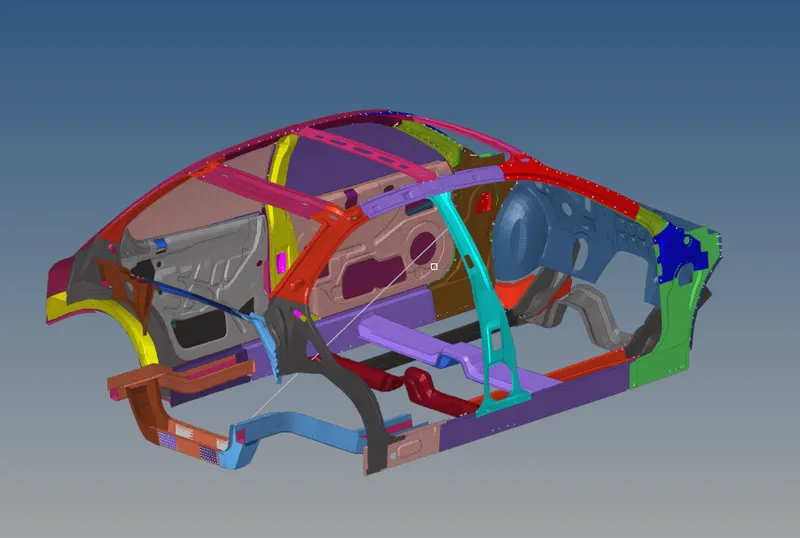
Imported Geometry
2. CHECK FOR UNIT SYSTEM:
In the data, we have two files
- Neon_side_reduced_0000.rad (starter file) stores information about:
- Nodes
- Load Conditions
- Velocity
- Boundary Conditions, etc.
- Basically, it is an ASCII (American Standard Code for Information Interchange) file that contains the model information.
- The starter file should always end with 0000.rad.
- Neon_side_reduced_0001.rad (engine input file)
The engine File stores information about:
- Simulation Runtime
- Simulation Speed control parameters, such as No. of Animation Files, No. of Time History File, Size of the history file and Animation frequency, etc.
- Basically, it is an ASCII (American Standard Code for Information Interchange) file that describes the run controls.
- We can also edit the Engine File directly through the Control Cards.
- The starter file should always end with 0001.rad.
unit system used for analysis is "kg mm ms".
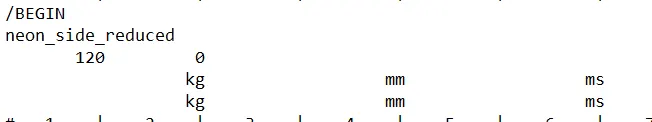
Checking Unit System In Starter File
- I will do some of the setup in Hypercrash first, then move to Hypermesh for the rest of the setup
RADIOSS User Profile - Opening HyperCrash
3. IMPORT STARTER FILE IN HYPERCRASH:
- Select Neon starter file and drag it to hypercrash application to open the model
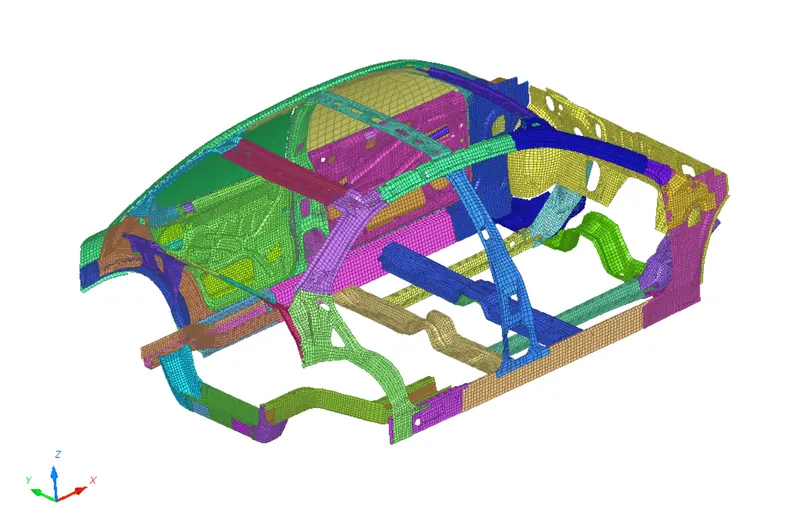
Model Imported In HyperCrash
4. CHECK FOR PENETRATION AND INTERSECTION:
- Penetration is defined as the overlap of the material thickness of shell elements, whereas Intersection is defined as elements that pass completely through one another. All models and especially impact models should be checked for penetrations and intersections and they should be De-penetrated to ensure the integrity of the model. Penetrations adversely affect results and should be removed.
- To check penetration and intersection: Go to Quality>> Check all solver contact interfaces >> Select parts > Click on check penetration.
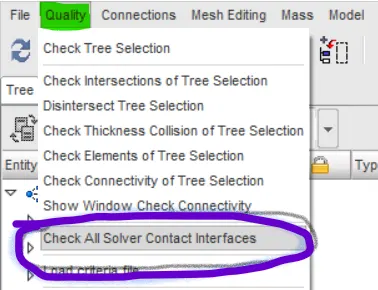
Checking for Penetrations
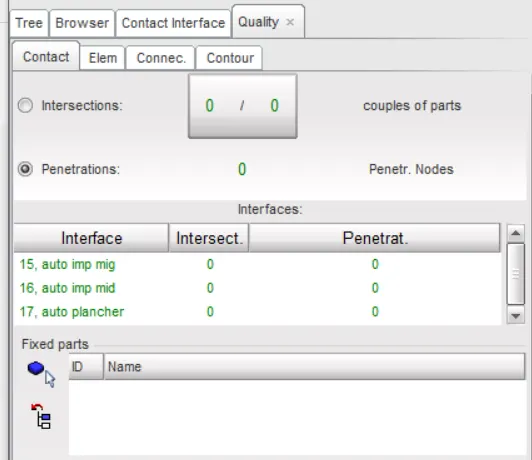
Zero Penetrations
- We can clearly see from the above figure there are no penetrations and intersections are present in the model.
5. Compare the model weight with the full-scale 300k nodes model and use added masses to reach a target weight of 700kg while getting CG about the required range.
- A vehicle’s centre of gravity, or CG, is the theoretical point where the sum of all the masses of each of its individual components effectively acts. In other words, from a physics perspective, a vehicle behaves as its entire weight resides at this one point. Carrying weight up high, such as a panoramic sunroof will raise a vehicle’s CG while placing heavy subsystems low in a vehicle, such as a battery pack, will work to lower it. Lower is better from a handling standpoint, as it reduces weight transfer during cornering and braking, and it also reduces the propensity to roll over.
MASS ADITION & POSITIONING OF COG:-
- Mass balancing:In order to maintain the COG of a car, we must add mass for the given components, In the given model here are so many parts are missing because of the node limit in the student version
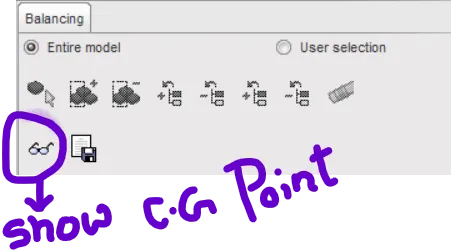
- To check the COG, Go to menu >> Mass >> Balancing >> Show CG point
- It is showing that the total mass of the body is 188.2 kg which is 700-166.30 = 533.7 kg less than our target mass.
- Before adding mass check the CG, to check the COG of the body we have to click on the specs icon as shown below.
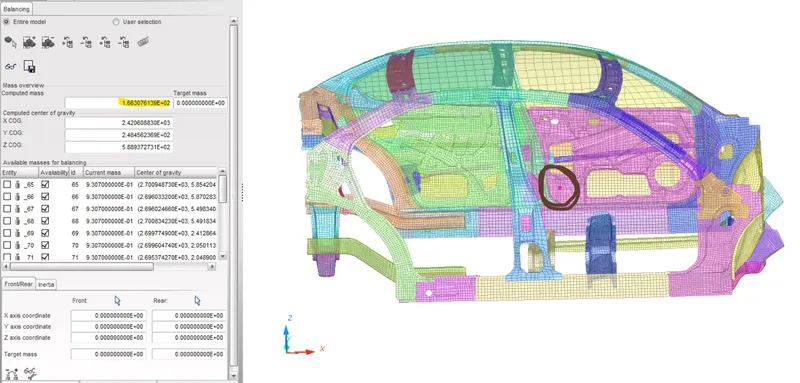
COG when it is imported
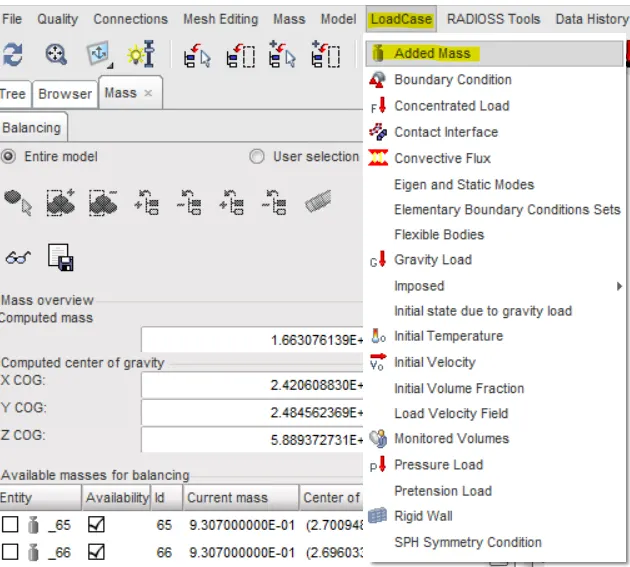
Creating MASS
- Current weight: 166 kg
- Target weight: 700 Kg
- We must add the mass in such a way that the Centre of gravity is exactly in the middle of the Cross Beam to simulate the real-time model.
- We are only worried about the position of the COG (X and Y axis) and not the height (Z-axis).
- We use Type 1 Mass, where mass is distributed on each node of the selected group.
- also we can use TYPE 0 mass where mass is added to each node of the group like suppose you have set the 0.1 kg for each node then if you select say 1000 node at a time then total mass will be added as (0.1*1000=100 kg).
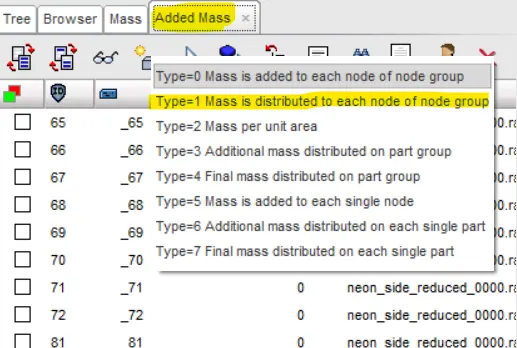
Creating TYPE 1 MASS
- I have added 7 masses as shown below, which will achieve target mass of 700kg
- First, Assign Added Mass value and then, In grnod_ID Support, right click >> select in graphics >> select the nodes. Do this for every added mass
- We should add mass in such a way that the COG comes to middle.
- The initial structure of the BIW Model is 166 kg.the mass is added to the structure to achieve 700 kg mass like a full car model.The mass is added in such a way that COG of the body should lie near the driver seat .so mass is distributed as front end crossbar having mass of 230 kg to feel the engine components.The rear end left and right side rail having 65 kg each for the 3rd and 4th passanger. The front first end cross bar is given 100 kg for the driver and gearbox purpose.38 kg is distributed in the front rails for the engine component.In order to adjust COG 54 kg is adjusted at front end left and right side rails .
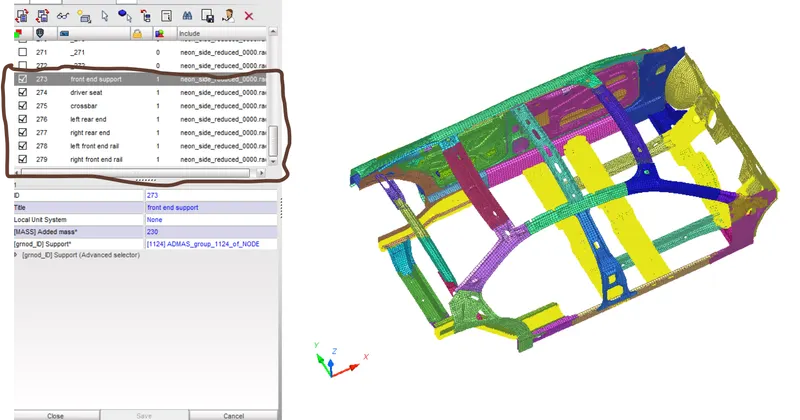
Total 7 MASSES are created
- After adding mass we have successfully balanced the weights to a target length of 700kg and COG also moved to recommended position.
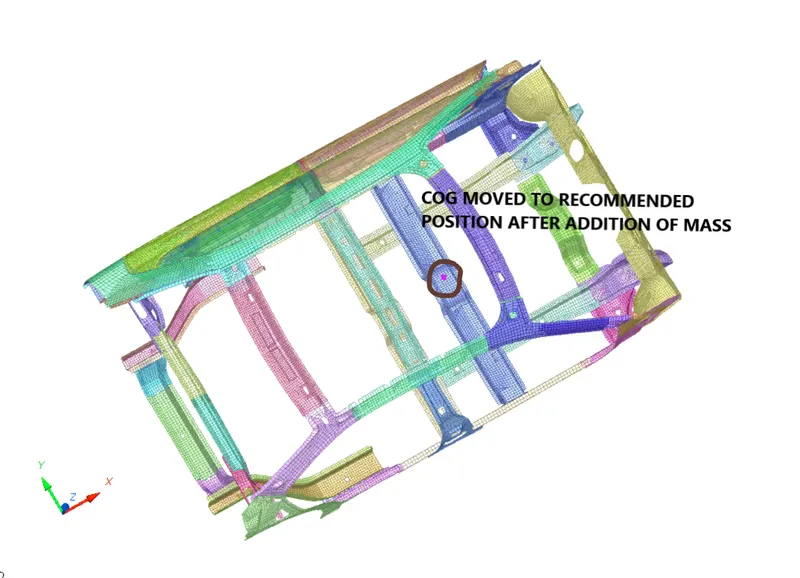
COG moved to recommended position after adding MASS
6. EXPORT HYPERCRASH FILE:
- Export the rad file changes made in hypercrash and import the same file in hypermesh to make other changes
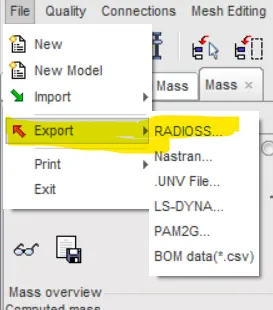
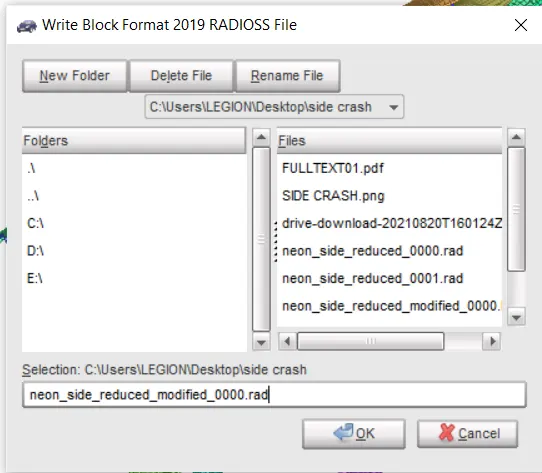
- For that Go to File >> Export >> RADIOSS and save the file. I have saved the file with name “neon_side_reduced_modified_0000.rad”.
- Now open this same file in hypermesh
7. CREATE SELF CONTACT:
In this case, the Type 7 Contact Interface is defined. Interface TYPE7 is a multi-usage impact interface, modelling contact between a master surface and a group of slave nodes. It is also possible to consider heat transfer and heat friction.
All limitations that were encountered with interfaces TYPE3, TYPE4 and TYPE5 are solved with this interface:
- A node can at the same time be a slave and a master node.
- Each slave node can impact each master segment; except if it is connected to this segment.
- A node can impact more than one segment.
- A node can impact on the two sides, on the edges and on the corners of each segment.
- It is a fast search algorithm without limitations.
The main limitations of this interface are:
- Time step is reduced in case of high impact speed or contacts with a small gap.
- It does not work properly if used with a rigid body at high impact speed or a rigid body with a small gap.
It does not solve edge to edge contact (to solve this, /INTER/TYPE11 should be used along with TYPE7).
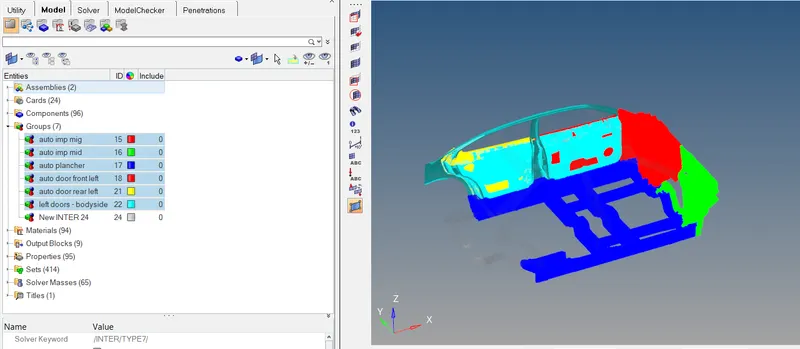
- At the begining there was 7 interfaces of type 7 used to the BIW structure .but there was no proper connection present in the whole model so for the betterment of the model we have to deleted those interfaces present and have to create a new interface for the whole model for proper connection.
TYPE 7: NODE TO SURFACE
This interface simulates the most general type of contacts and impacts. TYPE7 interface has the following properties:
- Impacts occur between a master surface and a set of slave nodes, like the TYPE5 interface.
- A node can impact one or more master segments.
- A node can impact on either side of a master surface.
- Each slave node can impact each master segment except if it is connected to this segment.
- A node can belong to a master surface and a set of slave nodes.
- A node can impact the edge and corners of a master segment. None of the previous interfaces allows this.
Type 7 contact
- The recommended properties are as follows
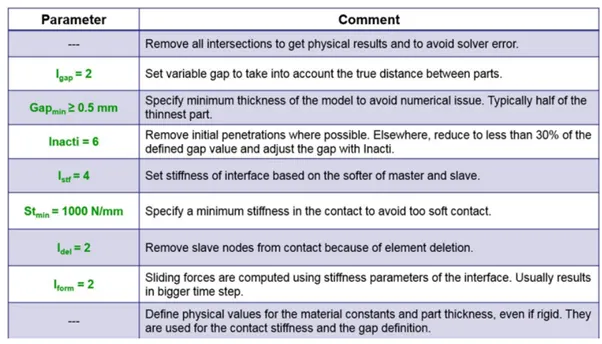
Recommended Properties
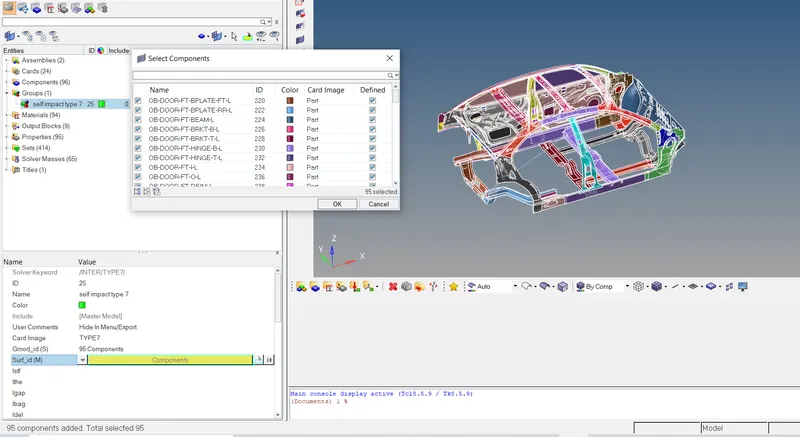
Selecting all the components for new interface
- We need to give in the Slave nodes and the master segment. Since we are defining a Self-Impact in the model, the Slave and Master segments for this contact will be the entire given model. So, we then select all the nodes for both segments respectively as shown below.
- Also, delete all the other components under Groups as they are not assigned to any part in the model
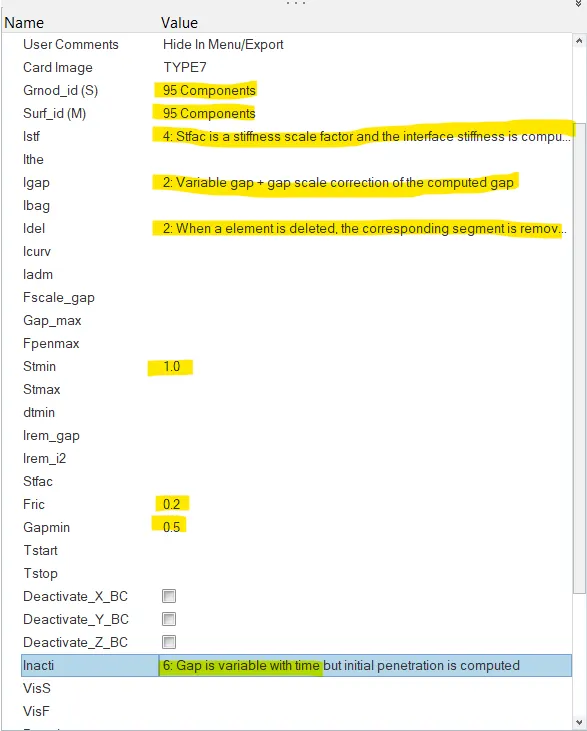
Properties are assigned to TYPE 7 contact
- To check whether master and slave nodes selected properly you can review them as shown below
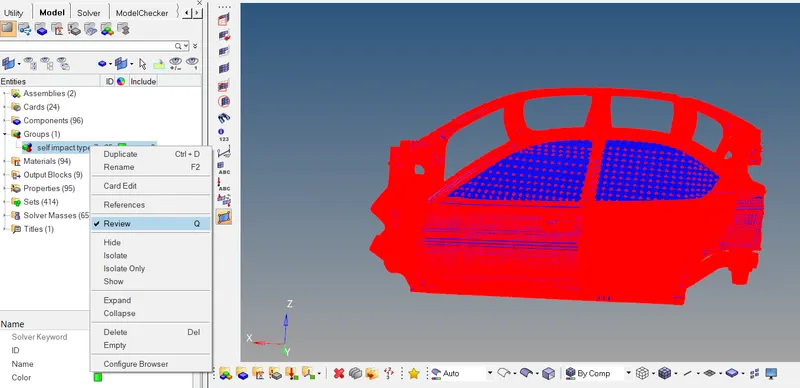
Slave and Master nodes selected Perfectly
8. CREATE RIGID WALL:
- A rigid wall is a nodal constraint applied to a set of slave nodes in order to avoid the node penetration to the wall. If contact is detected, then the slave node acceleration and velocity are modified. Mainly to constrain the movement of a moving body after impact, we will be using a plane wall. An infinite plane wall is a plane that extends to infinity. It is defined with two points.
- Rigid wall entities provide a method for treating a contact between a rigid surface and nodal points of a deformable body. In the Radioss user profiles, rigid walls can be created in the Model and Solver browsers.
- To create an RWALL: Go to Slover browser >> Create >> Rwall >> Plane
- We need a reference node to create an RWALL so for that we are creating a temp node in the middle of the door side.
- After that translate that node to create some gap between car and wall which will be created at the translated node or you can manually create a gap by putting the increased value of the temp node in the Y axis & Z axis as shown in below.
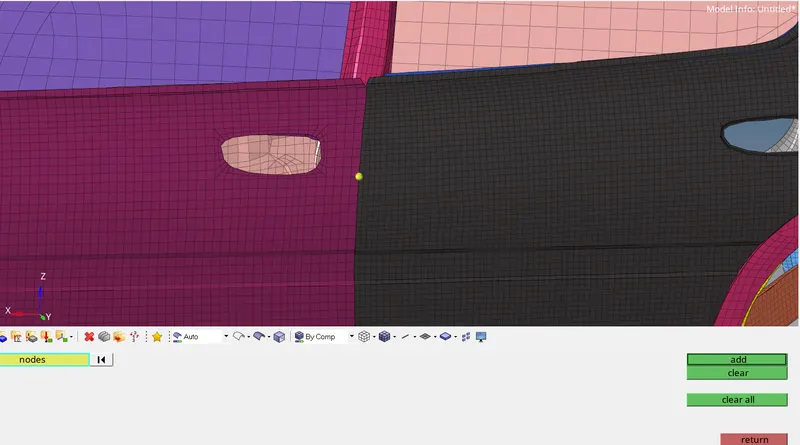
Temp node is created
Co-ordinates X, Y and Z values
- It is a Shell element with no thickness (gap) and infinite thickness.
- A search tolerance is given (optional) so that the nodes within the range will be taken as slaves.
- We are going to create an Infinite plane type Rigid wall.
- Enter the coordinates of the Temp node [XM, YM, ZM] >> Enter the Direction of the Normal [0, 0, 1] >> Select GRNOD_ID 1: set of displayed nodes >> Dsearch: 1000/1500
- We must provide frictional parameters for the rigid wall when the slave nodes come in contact
- Friction type [Slide] = 2: Sliding with friction
- Frictional Coefficient [FRIC] = 0.1
- The D-search distance we can use around the range of 1000 mm. All the Nodes within this distance will be considered as salve nodes for the contact between the car and the Rigid Wall.
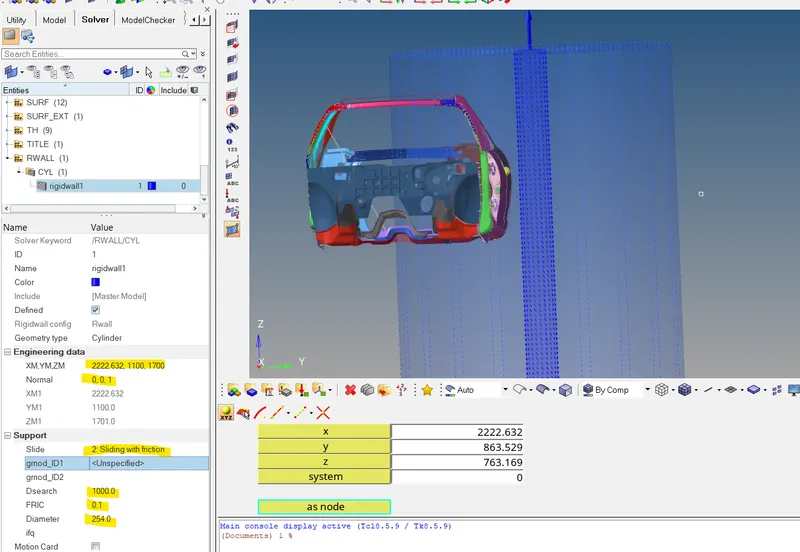
RWALL is created
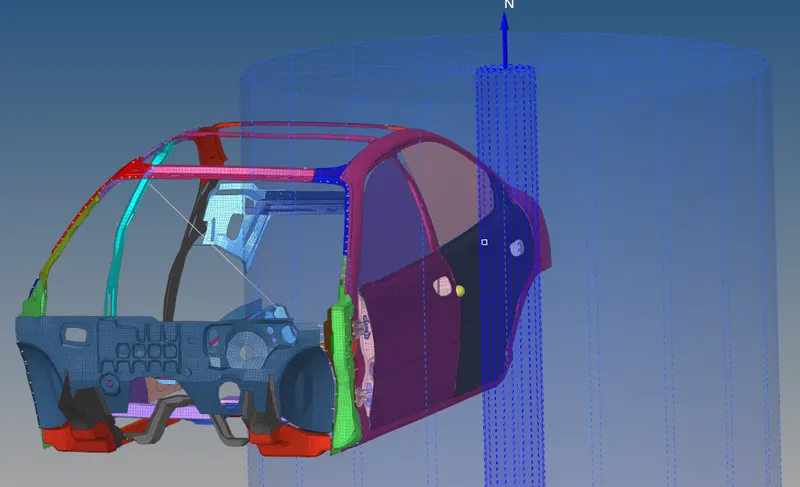
- but as spoken earlier there is no gap present in the doorstep and the rigid wall as the co ordinates of the temp node is given which is located in the mid doorstep ...so here we can create a gap between the side doorstep and rigid wall manually by increaing the value of y co ordinates as per your criteria and by increasing the value of Z cordintaes temp node we increse the height of the wall as shown in fig.
- so here instead of putting the exact value co ordinates of temp node we increased a liitle bit in the value and for that reason the rwall is differ from the location and create a gap between those two.
9. CREATE VELOCITY:
- Initial velocity is 35 mph.
- Converting 35mph into ms
- We get 1mph = 0.447 ms therefore 35mph = 15.6454 ms
- The initial velocity (Vi) is the velocity of the object before acceleration causes a change. After accelerating for some amount of time, the new velocity is the final velocity (Vf).
- Go to solver browser >> Create >> Boundry conditions (BC) >> Inivel
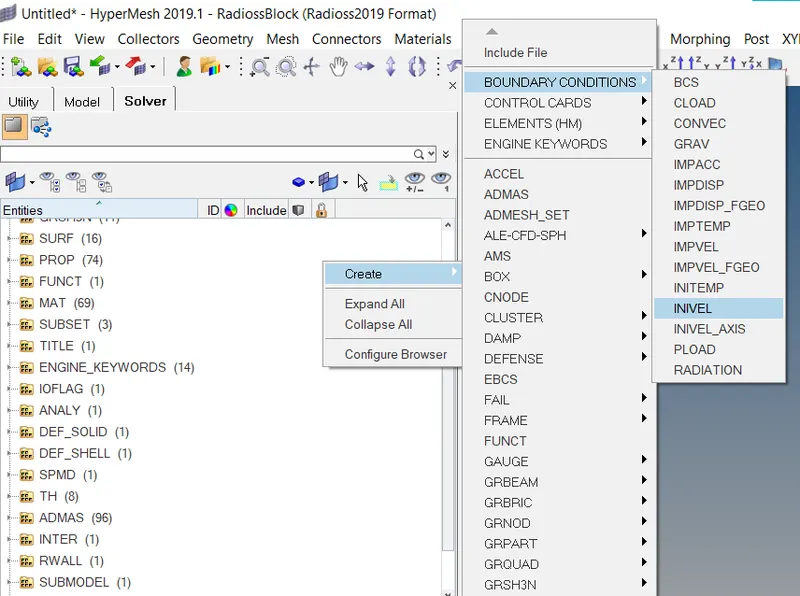
Creating Initial Velocity
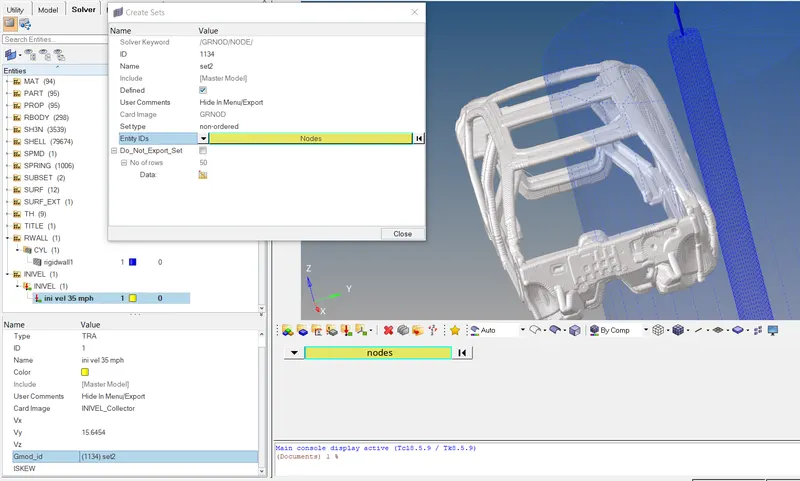
Selecting all the nodes
10. CREATE SECTIONAL FORCES:
- We need to Create Sections at cross bars in order to anlize the deformation forces.
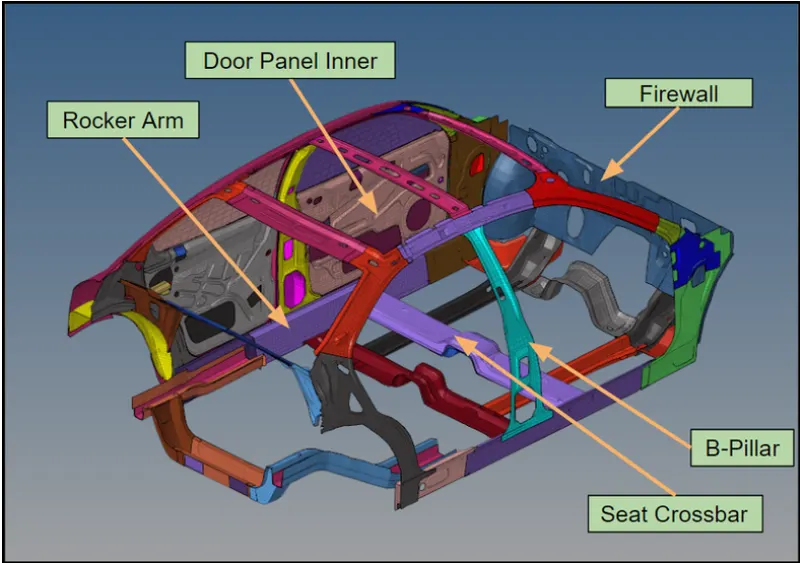
- We should know how the forces are transmitted from the doorstep to the B Pillar and the rate of deformation. It is done in order to ensure the safety of the passenger.
- Certain components will crash (deform) more than the other so that the forces are distributed correctly leaving very little force left to transmit inside the cabin.
- To create a section and Frame Go to Slover browser >> Create >> Section >> SECT
11. FRAME CREATION:
- Before creating sections, we should create frames. The Frame is created to make local coordinates of the section.
- To create the Frame, Right Click on the Tab Area in the Solver Browser >> Click Create >> FRAME >> MOV >> Select the Nodes So Create an Axis >> Create.
- Remember, while creating local coordinates, select the nodes in such a way that the Z- Axis should be in the direction of the initial velocity applied.
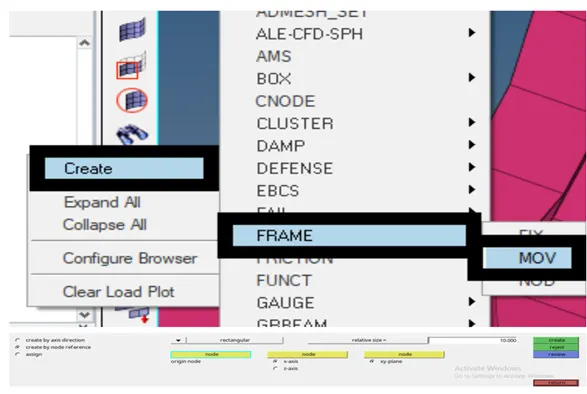
- Now create sections and assign each FRAME to each Section accordingly.
- in here i will show the workdone for fiest cross bar.
- first create a SECT CARD for first cross bar like shown in previous fig.
- Create a movable frame for first cross bar.
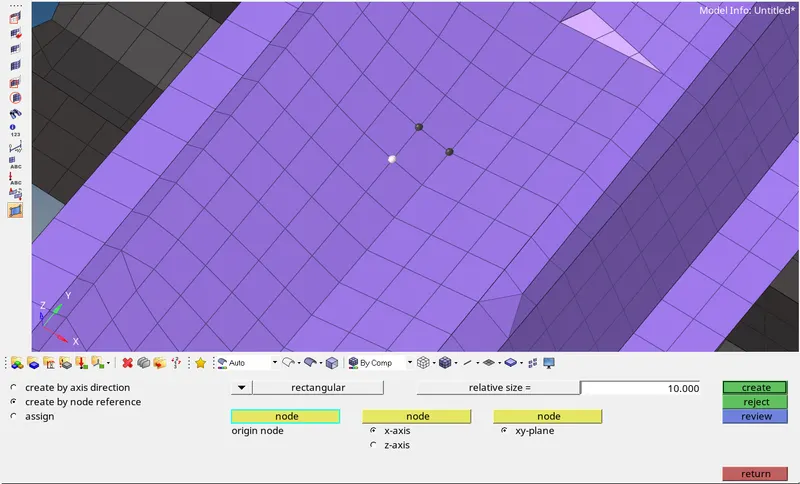
selection of 3 node for making frame
- for creation of frame you have to select 3 node ...for the sect card you have to select again those particular 3 node(N1,N2&N3).this 3 node taken as reference frame node for calculating the forces across the section.
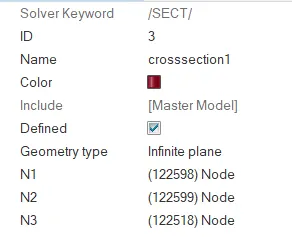
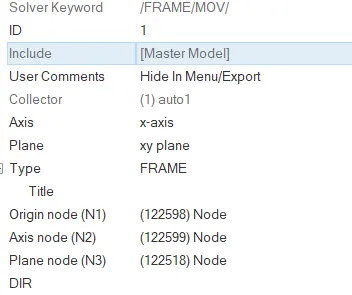
same value of N1,N2 & N3
- Then under the FRAME_Id you have to select the frame you had made earlier.
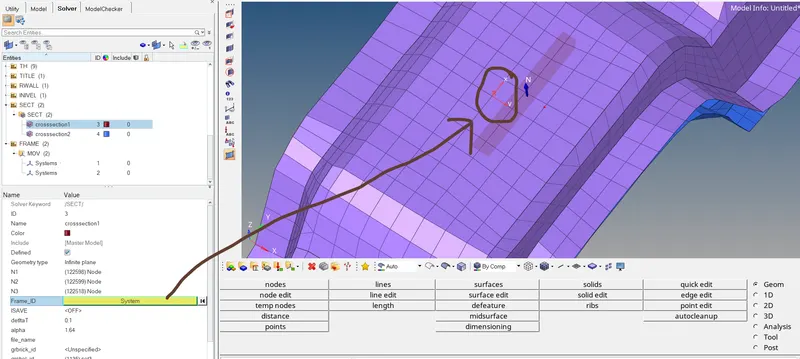
selection of frame id
- Put the value of delta T as 0.1 and alpha as 1.64 and iframe value set to 12.
- then for the cross section under grshel id set two rows of elements .
Selecting elements for grshel_id
- For grshel_id select a section of elements on a component where we should calculate forces going through them.
- Remember, the plane created at the section must be perpendicular to that component.
- Now do the same for the rest.
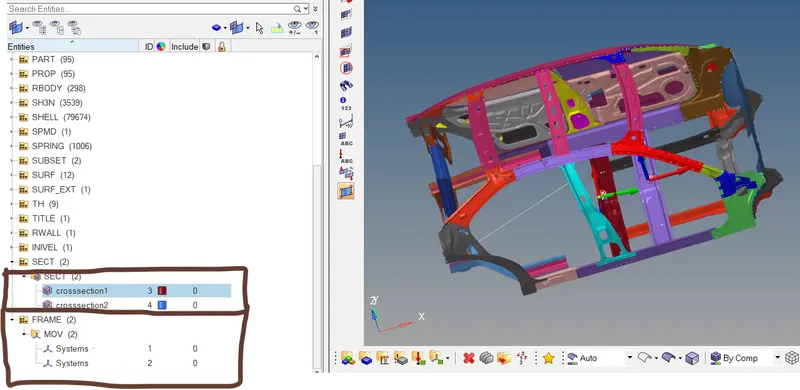
All the required sections are created successfully
13. CREATE SPRINGS(i.e INTRUSIONS):
- Intrusions here means how much displacements the B-pillar, hinge pillar and fuel tank facing.
- We are planting Spring elements to study the intrusions (forces inside the cabin causing deformation/rupture).
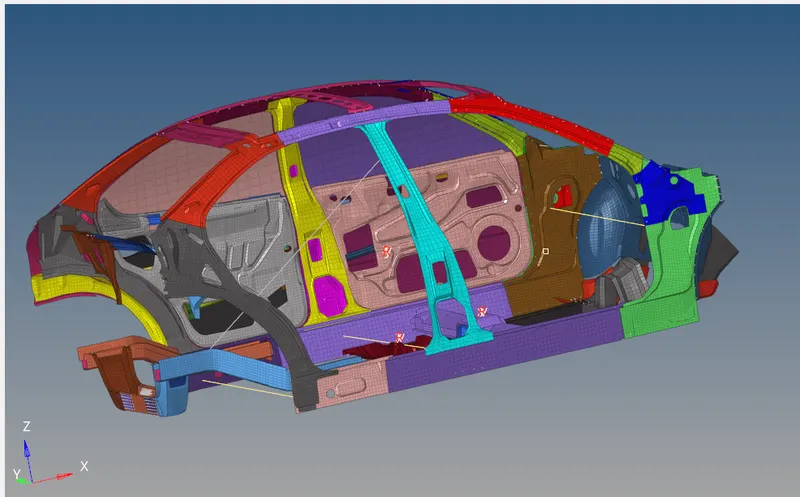
- So to find the results at the specified parts, we need to create spring between left and right parts of B-piller, Hinge-piller and fuel tank, for creating spring go to 1D -> SPRINGS -> SPRING2 and select 2 nodes as shown in figure below.
- Select the node at required node id as shown below and then, select another node on other end to create spring, this is done to see how much the cabin is crushing during crash
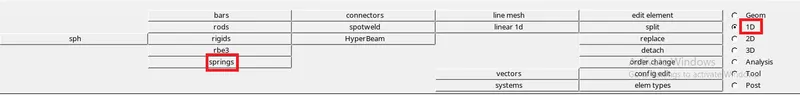
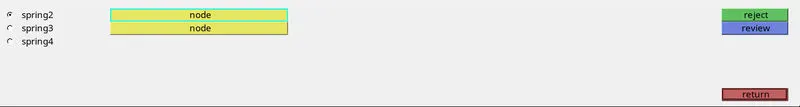
Spring created as shown in the figure below
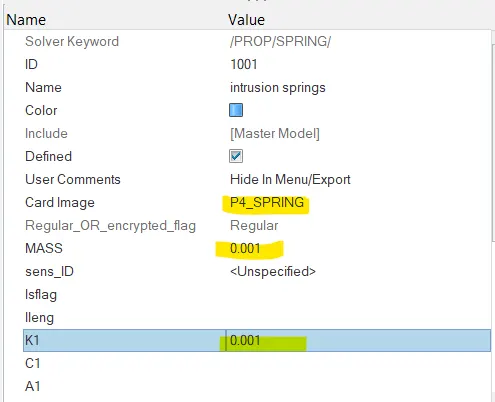
- Now we have to create property card for spring and assign it to the spring element created
- Go to model Browser >> Create >> Property >> Rename as Intrusion springs
- After creating a property, a new tab will open there we have to select CARD image as P4 SPRING and Mass as 0.001, and Stiffness as 0.001.
- then assign the prpoperty to the spring component.
14 . Study of Peak velocity of inner node of the door –
- To find peak velocity at the inner node of the door, we will create a moving frame at the node location by using right-click on solver browser -> create -> skew -> MOV
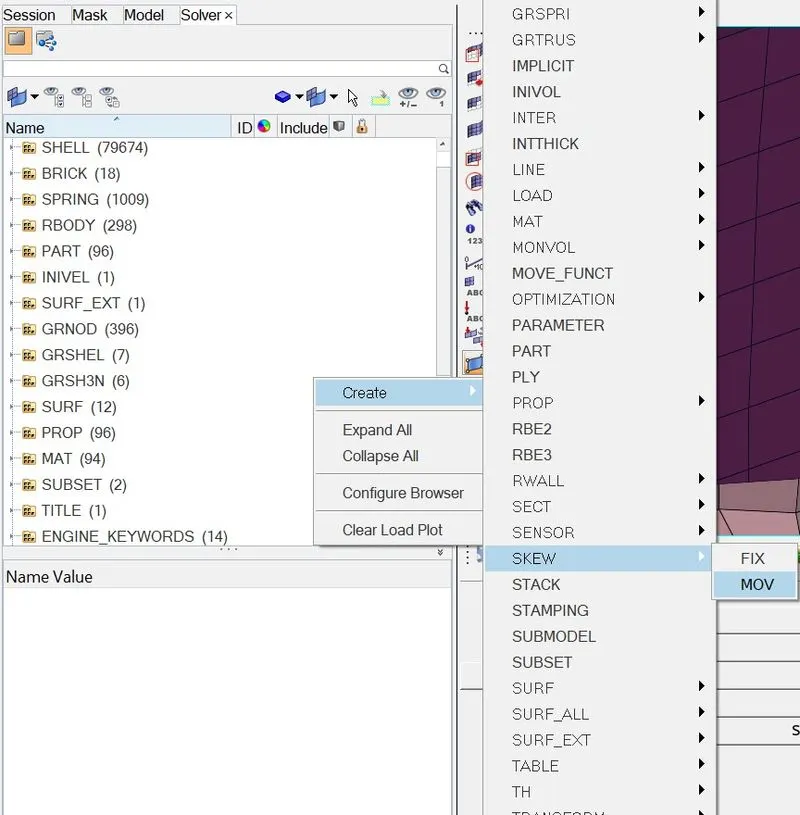
- select the required node as origin node then select node to define x-axis and XY-plane.as shown in figure below
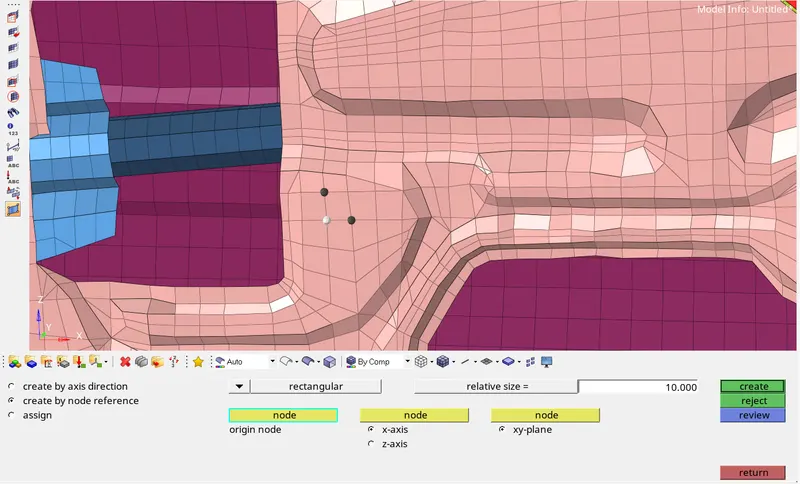
Output request for peak velocity on Inner door
- The next step is to create a Time History (TH) output specifically for this. For that, we can switch to the model browser and create a new output block, this time for peak velocity (right-click > create > output blocks).
- The entity ID is going to be just the one node - node 337772 and for lskew, we shall be selecting the skew created previously.
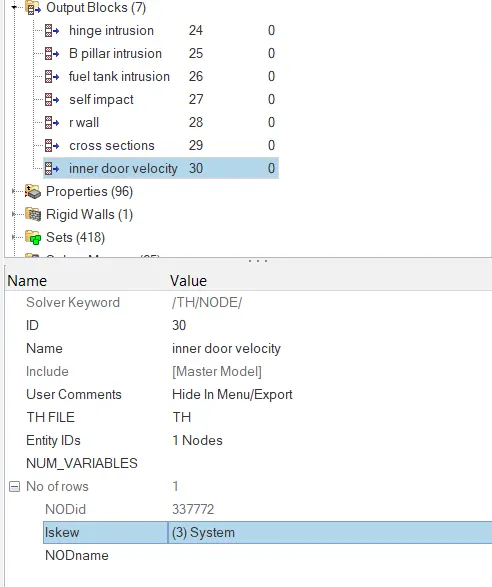
15. Delete existing TH and Create New Cards
- Delete all the unnecessary TH files and create the Time History files for the boundary conditions that we have created for side impact crash model.
- This will help us reduce some time for simulation as the solver only calculates TH for required outputs.
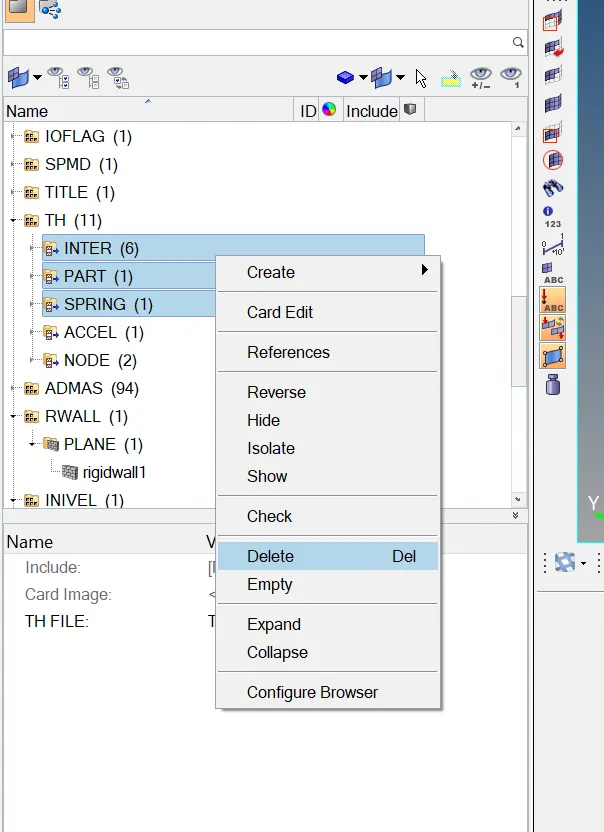
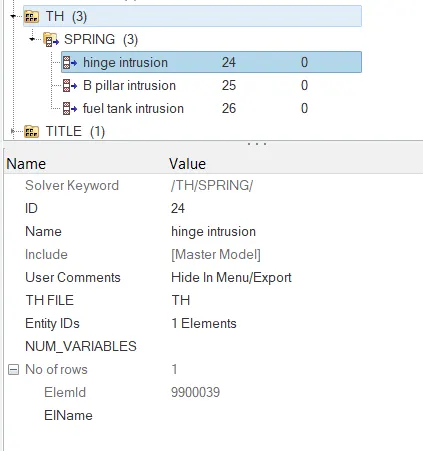
Deleting Unnecessary TH's intrusion TH
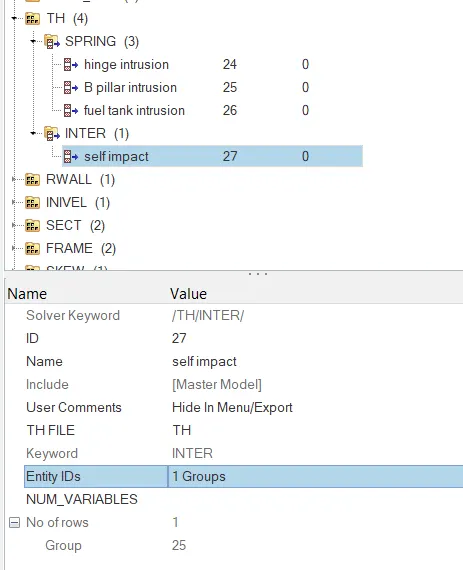
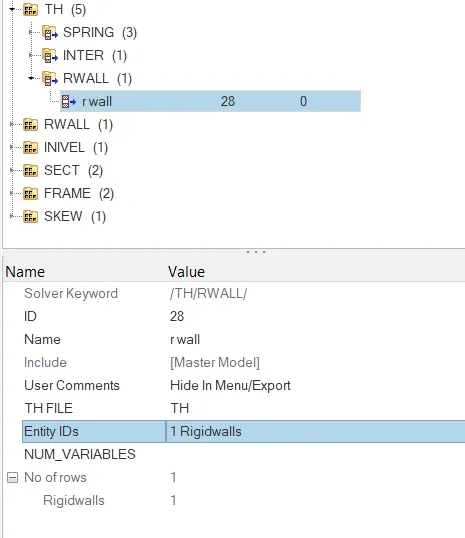
Interfaces TH Rigid Wall TH
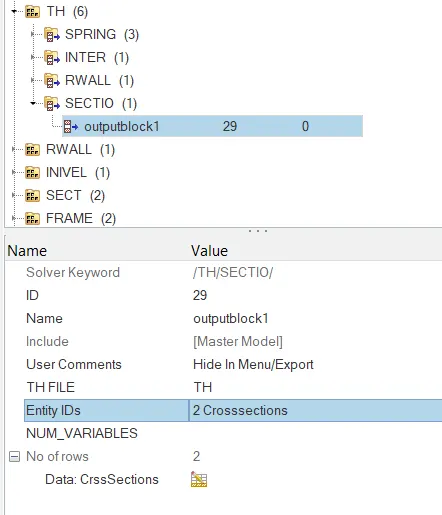
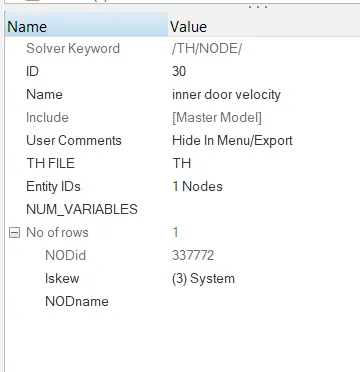
Section's TH inner node peak velocity TH
16. Edit Cards
- Before running the simulation check all these cards and assign the values accordingly.
-
To check these parameters in Hypermesh, we will navigate to Cards under Model browser. To check the run time, For the time step, we will input timestep value as shown in table below
TIMESTEP CONTROL
Engine Card
TSCALE
[Scale factor]
Tmin
[Critical Timestep]
Description
ENG_DT_NODA
0.67
0.001
Mass is added to the node when the computed timestep becomes smaller than the critical timestep.
ENG_DT_BRICK
0.9
0.0001
Controls the timestep by small strain formulation on the elements if they cause the timestep to drop.
ENG_DT_INTER
0.67
0.0005
Uses the default constant timestep method.
we will open ENG_RUN card and input run time in Tstop as 80 ms.
Go to ENG_ANIM_DT card enter T freq as 5
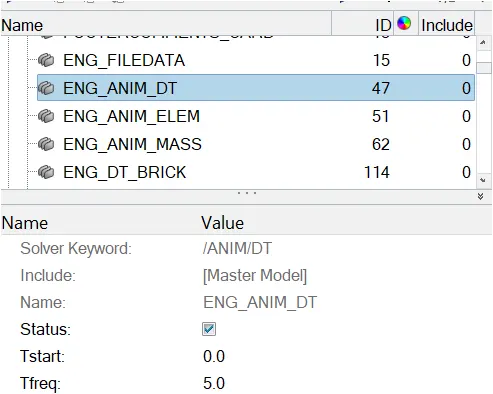
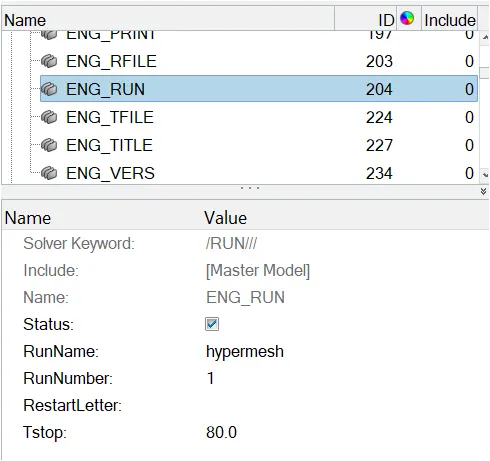
ENG_ANIM_DT Card ENG_RUN Card
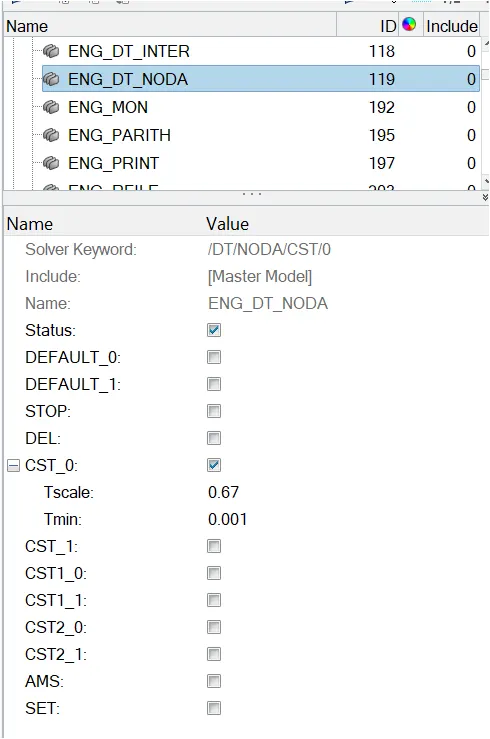
ENG_DT_NODA Card
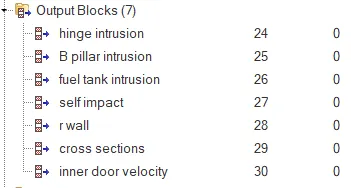
17. Creating Output Blocks
- Output blocks contain the data which we need to create graphs after the simulation
- Therefore, we need to create 5 different output blocks for different sets of data
- Print only the required output blocks as this makes the simulation fast.
18. Errors
- After running the simulation in tools >> Model Checker.
- We can easily identify and delete Unused sets and Empty sets using tools >> empty or unused option
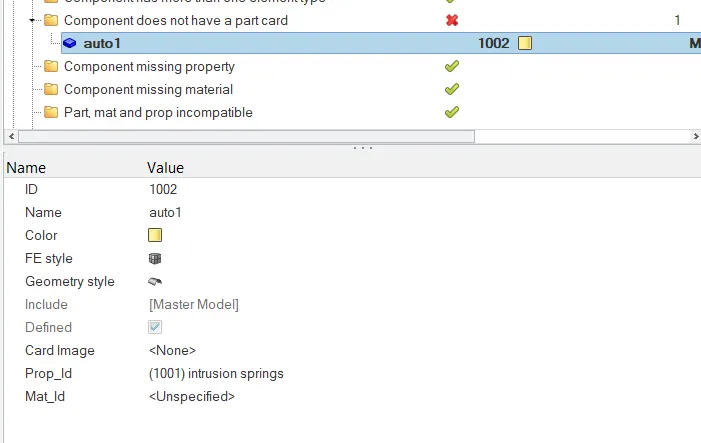
the error i got
- Also, assign property for the spring.
you also have auto correct option to get rid of the error in model .
19. DRY RUN (Simulation)
- Sometimes, the errors are not shown in Model Checker
- In this case we should run a dummy simulation to know the errors
- To do that go to ENG_RUN and change Tstop value to 0.
- Now run the analysis as shown below
- It will run in quick time and points out all the errors
- Note down all the errors and rectify them
- After rectifying all the errors change the Tstop value as required and run the analysis
- This Dry Run is useful for Simulating Bigger Models
- Since there were no errors during the dry run, we can now run the actual simulation
- Change Tstop to 80 and run the analysis
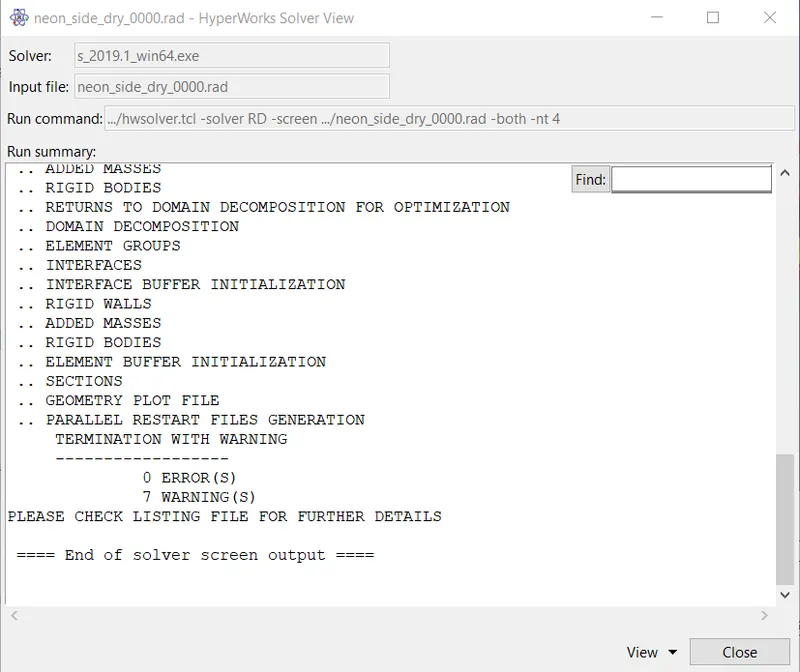
dry run completed with 0 error
20.ANALYSING THE OUTPUT FILE
- The next step is to carry out energy error and mass error checks and this is done by checking the RADIOSS engine output file. This can be accessed from the same directory as the starter and engine files and is denoted by the '.out' extension. The file in question contains '_0001.out' and can be accessed using any text editor - such as Notepad.
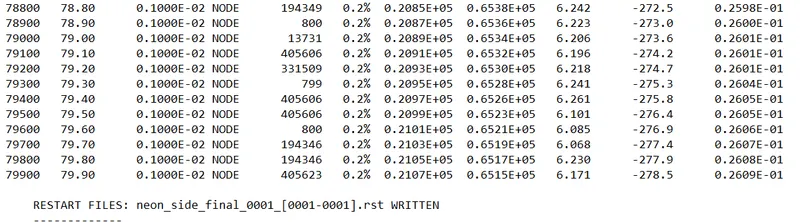
Engine Output file
- As we can see, the energy error is 0.2%. It is definitely acceptable within range of -10% to +5% error. In addition to that, the mass error is 0.026090, which means that a negligible quantity of mass of was added during the simulation, possibly for the sake of time step control/stabilization. It is a rather low amount so it's still acceptable.
- Total Simulation Time: 2100.53 sec
- of cycles: 80001
21. SIMULATION ANIMATION
- To view the simulation, we can switch to Hyperview through the client selector.
- In Hyperview, we will need to import the h3d variant of the file.
- Then the contour panel is opened, which appears as shown in fig below. In which the parameters to view the simulation are selected. Such as: result type:In terms of Displacement, von misses stress etc. then selecting the components & apply.
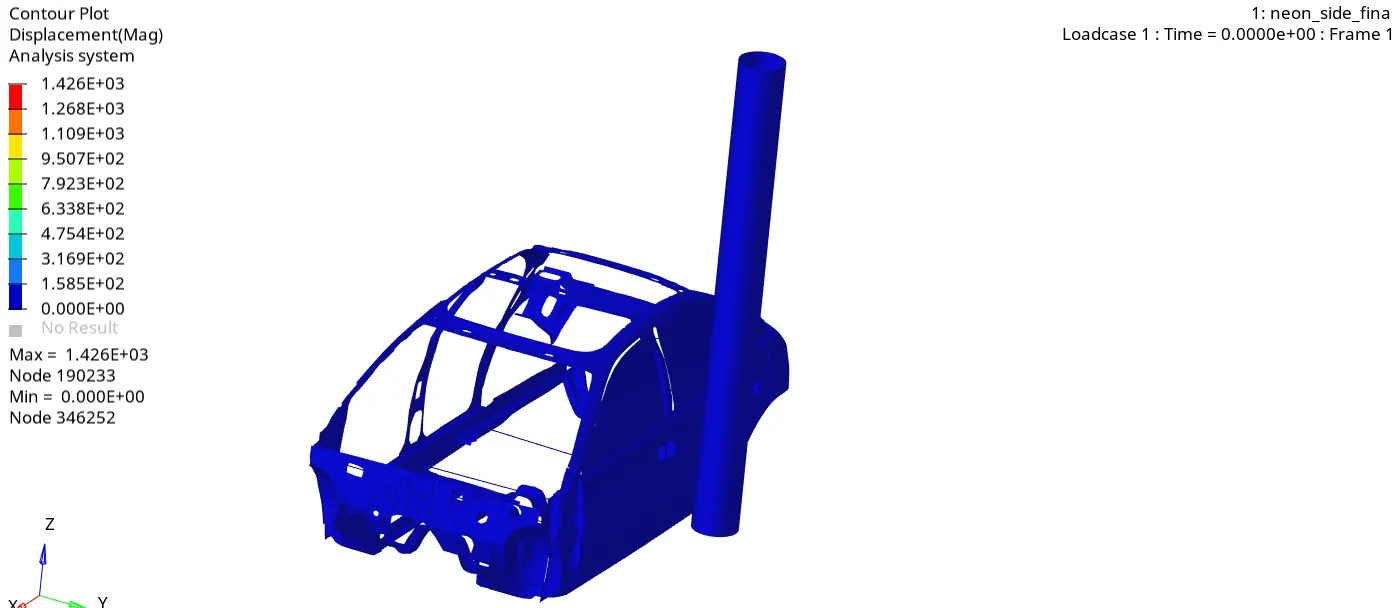
side Crash Analysis - Displacement
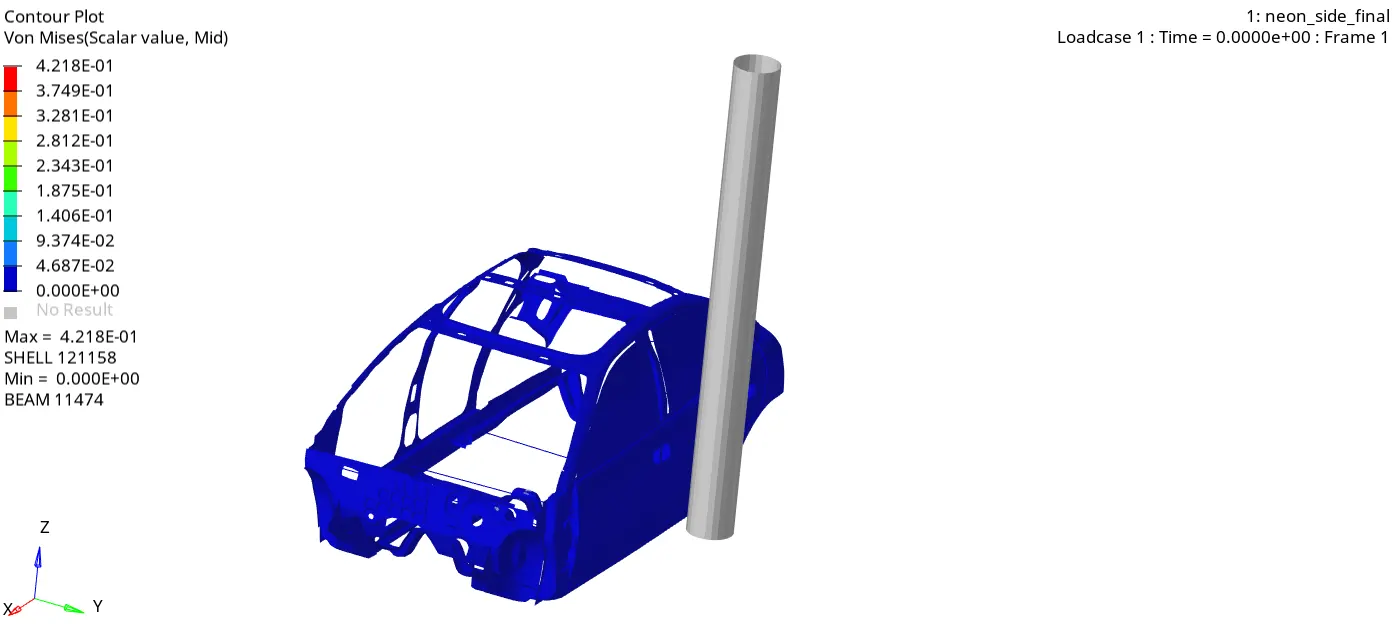
side Crash Analysis - Von Mises Stress Side View
- From the simulation, we can see that. Initially, the doorstep starts crushing then the forces are transferred to the b Pillar then from there the forces are transferred to outer rail,side impact beam,cross beam. In each stage, the forces are going to reduce because energy is absorbed in each stage. Because of no engine blocks, suspension system and tyre etc the car BIW is going to go down at the end of the simulation
- From the Von Mises stress plot, we can say that the stress distribution is quite good in the vehicle after the crash. There are very few areas where we can see stress concentration. Generally, the stress is more in doorstep B pillar region as it is the first point of impact.
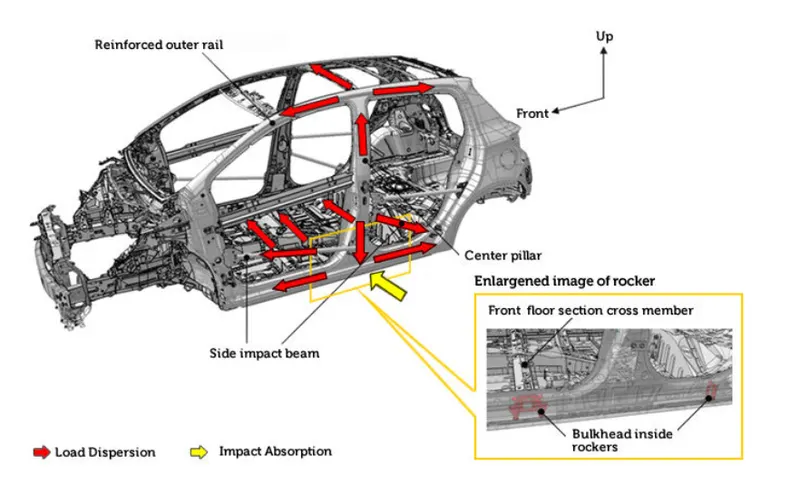
22. GENERATING THE PLOTS
- After generating the simulation, we can then go ahead and generate the plots. Using the same client selector, we can switch to Hypergraph2D. In the Hypergraph client, we are asked to import the required file, which is the T01 (Time history file) variant of the file.
A. Global Variable Graphs: Energies
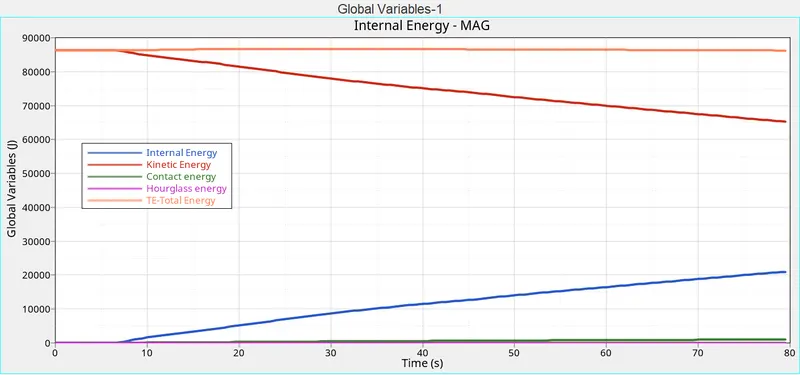
INTERNAL ENERGY AND KINETIC ENERGY:
- The changes in kinetic and internal energies occur at the exactly when BIW body comes in contact the rigid wall. Obviously, the BIW loses kinetic energy throughout the simulation due to decrease in velocity. At the same time, it absorbs the forces, and this results in an increase in internal energies, and as a result, the deformations also occur. Thus, the total energy in the system is almost constant at 86000 J and due to some energy loss which we can see in energy error, there is some decrease in total energy.
- From the above graph, we can see that the Hourglass energy is almost negligible since we have used Improved integrated element formulation (QEPH)
B. Contact Energy Graph
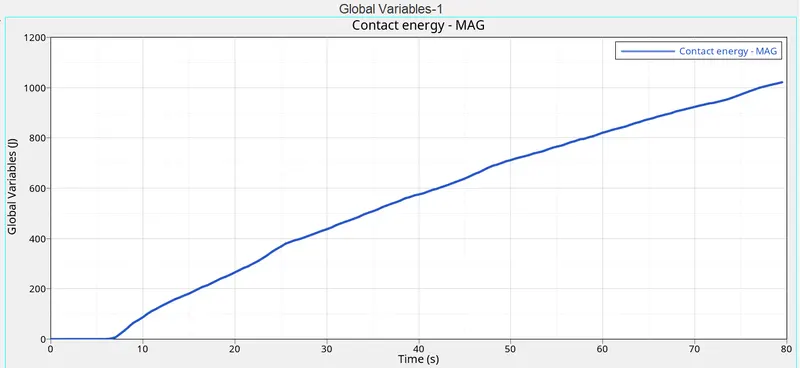
- Contact energy is a type of energy that is formed when one element meets the other or neighbouring elements. The opposing force created by this element forms the contact energy. In this case, it increases after 8 ms, at this point the model starts deforming in such a way that penetration of nodes occurs. When certain regions of the model press on themselves, buckled elements are forced into contact.
- The increase in contact energy affects the overall energy of this system, which is why there is a decrease in the total energy over the course of the simulation. it is a negligible decrease though. The magnitude of contact energy generated is much lower.
C. Rigid Wall Forces:
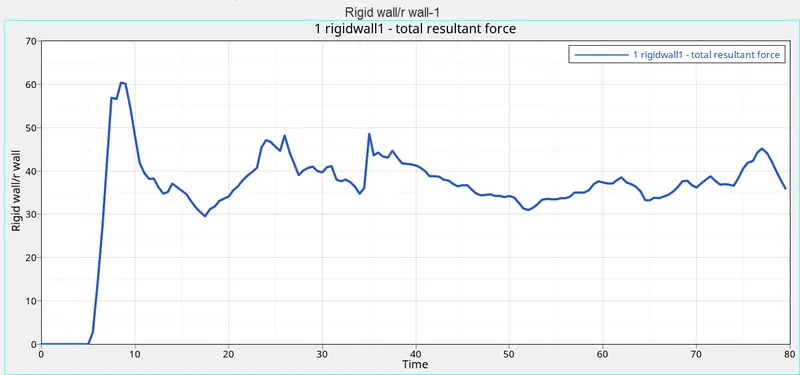
- As it can be seen in the starting, rigid wall force generated is zero till 3 ms of simulation because of no contact, but at the 6 ms there is peak rise in the wall forces to a value of 60KN which is the point of first impact, Then rigid wall force decreases and stabilize to a constant value between 30 to 45 kN.
D. OUTPUT REQUESTS
SECTIONAL FORCES - On CROSSBARS:
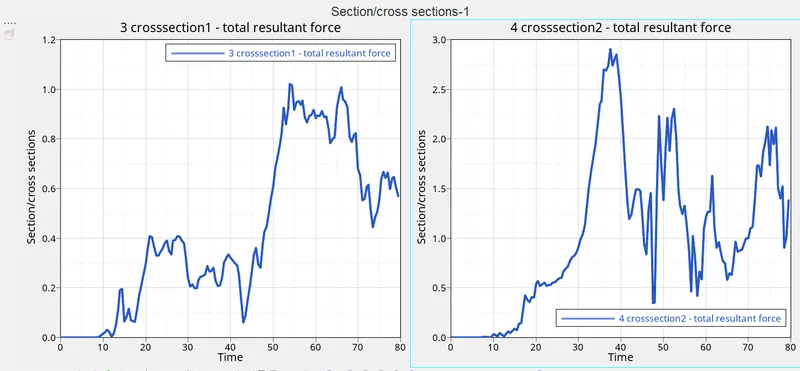
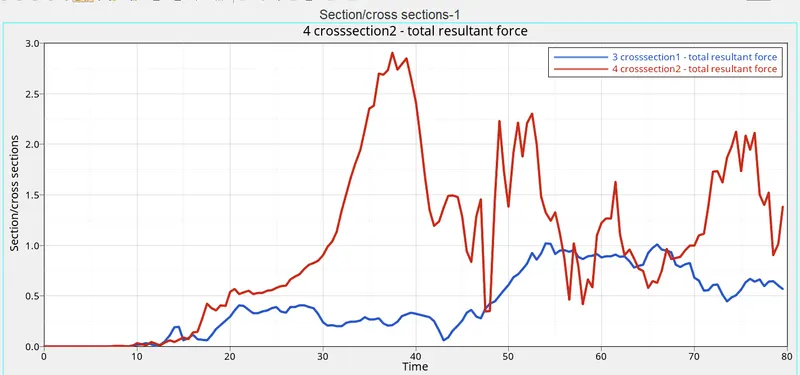
- During the side-impact, the vehicle is going to impact the cylindrical rigid wall. At the time of impact, this vehicle will have some kinetic energy possessed and the rigid wall will try to oppose this kinetic energy and itself will apply the force from the opposite direction as shown above. So while impacting the rigid wall the kinetic energy of the vehicle will be reduced continuously and at the same instance, the wall will apply force to the vehicle components due to the transfer of energy. From this, we can conclude the force will be recorded in the vehicle components due to high collision and it can be either positive or negative based on how much particular component is going to deform and how much force it is absorbing from the rigid wall.
- From the above graph, we can say that the vehicle is going to impact the cylindrical rigid wall with some initial velocity, and from our observation, we can say that the same force applied by the rigid wall it is been recorded in the crossbar component at the section frame. Here the crossbar 2 is absorbing more forces than crossbar 1. This difference in the cross-section is due to the component located at a different location and depending upon the displacement of the particular cross-section component. The maximum force recorded in crossbar 1 is around 1.01 kN and that in crossbar 2 is around 2.9 kN which is displayed in the above graph. The force is so high because as explained above a large amount of force on a small proportion of the side of the vehicle is imposed.
G. Intrusion Springs:
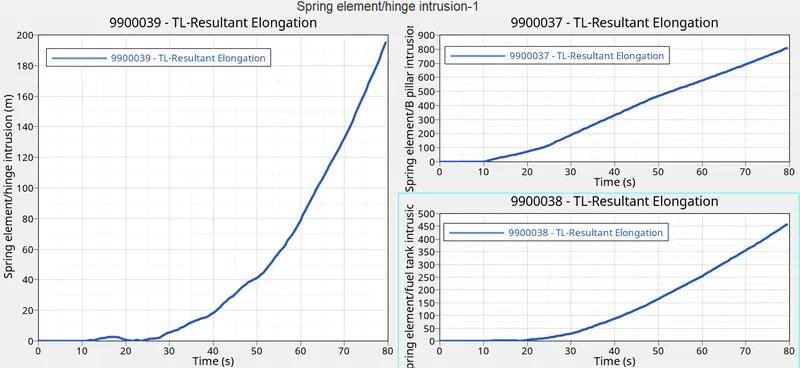
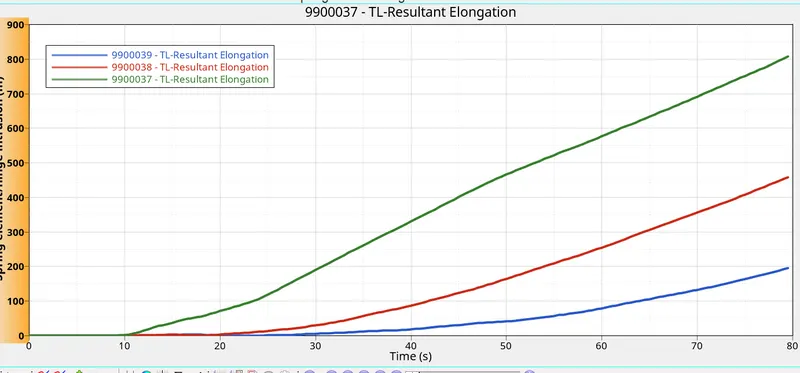
- Here we can see that after the side-impact the intrusion is recorded in the form of displacement. This intrusion node 9900039, 9900038 & 9900037 are near the driver side B-Pillar in the rocker arm component. As there are no other components in the middle section of the vehicle like the absence of Engine, Radiator, Seat, Other Assemblies, etc there is very huge deformation recorded at these intrusion nodes. This can be fixed after fixing the other parts inside the BIW Structure. The maximum displacement recorded in 3 nodes is displayed in the above graph. The displacement is so high because as explained above a large amount of force on a small proportion of the side of the vehicle is imposed.
- What can help to reduce the fuel tank intrusion?
--> To counterbalance this intrusion we can add the reinforcement structure near the fuel tank and inside the door panels. Additionally, we can add the cylindrical beam with a higher thickness of up to 4-5 mm can be provided the additional strength to avoid the fuel tank intrusion.
Peak Velocity In Inner Door:-
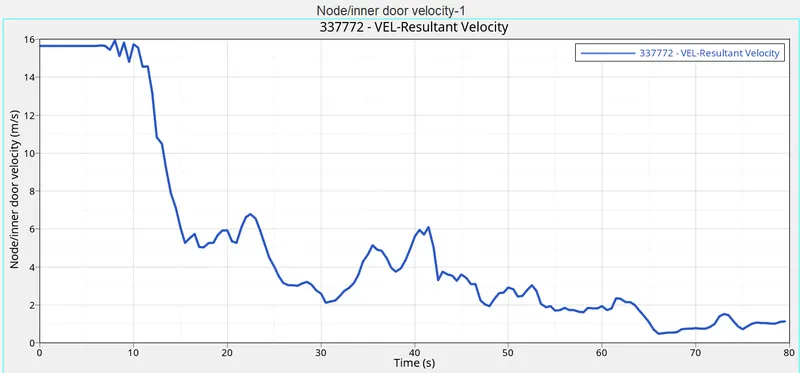
- As we all know that when the car hits the pole first impact will be the door and due to the deformation, the inner portion of the door might hit the passengers inside the car and lead to injuries. Hence it is important that the Peak velocity at the door region is to be calculated.
- From the Graph, the peak velocity of the node on the door is 15.94 mm/ms at 8.5 ms. The velocity of the node is almost constant before hitting the rigid cylindrical wall (up to 7 ms). After impact, there is a steep drop and then a small rise, probably due to the folding deformation created as the crash progressed (due to inertia). As time passes, we can see the velocity gradually decreasing.
Learning Outcomes:
- Importance of COG and its recommended position
- Learned the topics of the interfaces and values that are recommended for the project.
- Created Initial Velocity, and Intrusions, Frames, Sections, and local co-ordinates.
- Created time history cards and output blocks
- Rectified errors in model checker
- Simulation is run, animations are captured, and graphs are also plotted
Conclusion and observation
- All the required objectives are fullfilled according to the question
- side pole crash analysis was carried out on the given half of a BIW model of the Dodge Neon as per the given requirements. The output requests were also generated after the creation of cross-sections in each of those regions. Acceleration and intrusion values were also measured at certain points of the model.
- But it does not show the actual simulation since many components is missing in the section which absorbs the most amount of energy.
- The forces are transferred through cross members to the other side.
- The cross section at B pillar is expressing maximum forces due to the pole is placed near the B pillar.
- The maximum intrusion is at B pillar followed by area near fuel tank.
- The stiffness should be increased of the component near fuel tank so there will be less intrusions.
MODEL DRIVE LINK:-https://drive.google.com/file/d/1hWbpbyJgXhgQKUo4pArvOGrFP6uJsol7/view?usp=sharing