Assignment 5-RADIOSS Interfaces & Study of Effect of Notches Challenge
OBJECTIVES
1. To mesh the given bumper assembly with a mesh size of 6mm
2. To carry out simulations on the given crush tube model, so as to compare results as per the following requirements for each case:
- Run the crash tube model as it is.
- Change the Inacti=6 and run.
- Create the type 11 contact and run.
- Remove both notches and remove boundary condition on rigid body node then run.
- Create a new notch in the middle, select the whole section and run.
- Create a new notch with nodes only from opposing 2 faces and run.
IMAGES OF MODELS
Bumper Assembly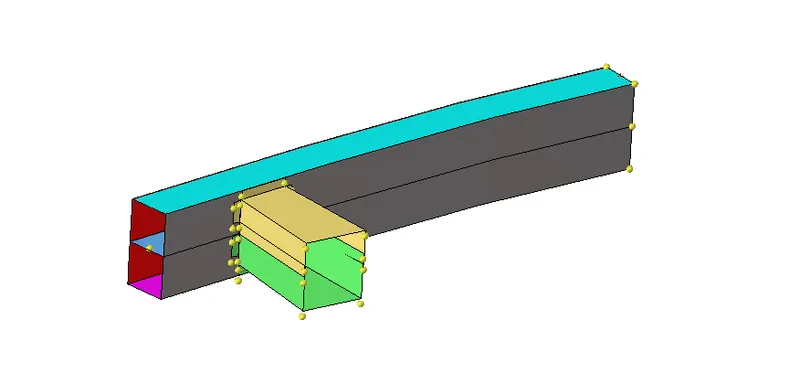
Crush Tube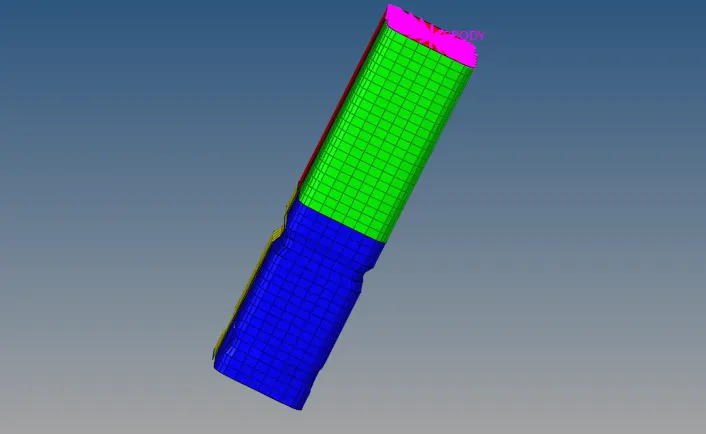
PROCEDURES
Meshing the bumper assembly
1. After importing the bumper assembly on Hypermesh, the first step is to carry out geometry cleanup using the various quick edit tools (Geometry > Quick Edit). Also, Geometry > Surface Edit > Extend is used to ensure the panel in the centre intersects the outer panels to create the non-manifold edge that is yellow in colour.
2. After cleaning up, we can set it up for meshing. We can assign the mesh quality criteria via Preferences > Criteria File Settings and assign the values.
3. We can then move onto meshing via 2D > Automesh in the bottom panel. Since all the components have rectangular faces, we can directly mesh each face without having to split it up to avoid trias. With the mesh size set as 6mm in the automesh menu.
4. Since this is just one side of the bumper, we can use the reflect tool to replicate the other half of it. Reflect tool can be accessed via Tools > Reflect. Selecting the axis along which it is to be reflected, and the base point, along with all the elements duplicated, we can go ahead and click 'reflect' to generate the other half.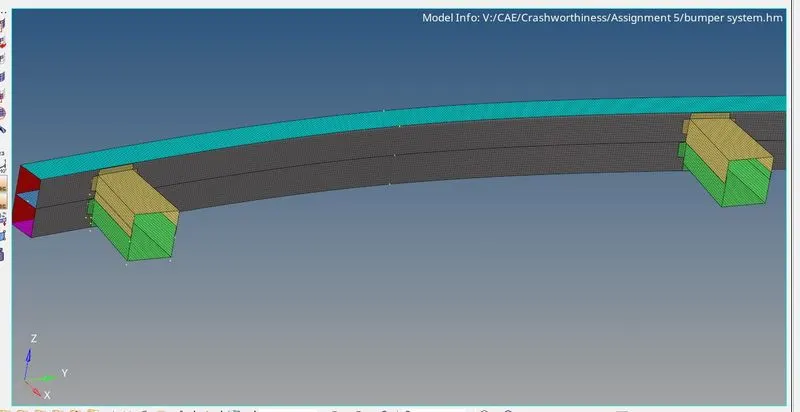
After this, we need to equivalence the mesh in the centre since they won't be connected. This is done using Tools > Edges. We can select all the elements and adjust the tolerance to find regions that lack equivalency. After highlighting them using 'preview equivalency', we click 'equivalence' to finish up.
Running Simulations on the crush tube
There are 6 cases to be carried out and all of them have mostly common procedures, except the interface/model changes, which are outlined as follows:
1. The crush tube model will be imported into Hyperworks via the 'import solver deck' option in the upper toolbar, or through File > Import > Solver Deck.
2. As per the given requirements, the changes shall be made in this step, either through the model browser in Hyperworks, or by switching to Hypercrash via Applications > Hypercrash in the upper toolbar. Specific instructions will be explained within each case.
Accessing Hypercrash:
3. After the changes are made, we can move to the analysis section in Hyperworks and select 'Radioss' (if Hypercrash was used to make changes, the model needs to be exported first through File > Export in Hypercrash. Then it needs to be imported again in Hyperworks, after which the radioss tool can be accessed).
4. In the radioss section, we can click 'save as' to save the file if it hasn't been saved yet. Care must be taken to include '_0000.rad' in the file name since it's the starter file. After that, we can check the connectors option and input '-nt 4' in the options bar before clicking 'Radioss'. This starts the Radioss simulation, which will run for a few minutes.
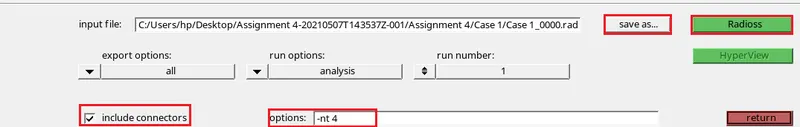
Radioss solver running
5. After the simulation is complete, we can switch to Hyperview through the client selector.
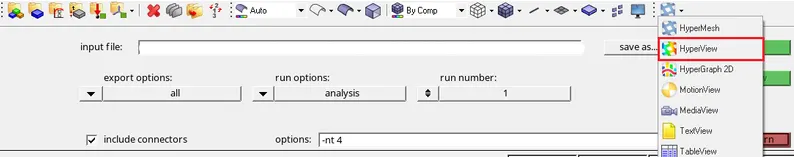
In Hyperview, we will need to import the h3d variant of the file. After importing, we can then select the 'contour' tool to switch to the Von Mises contour so we can analyze the stresses that form within the crush tube in the simulation.
6. Next step is to carry out energy error and mass error checks and this is done by analyzing the RADIOSS engine output file. This can be accessed from the same directory as the starter and engine files and is denoted by the '.out' extension. We need to check the file that contains '_0001.out' by using any text editor.
7. We can then go ahead and generate the plots, using the same client selector, we can switch to Hypergraph. In the Hypergraph client, we are asked to import the required file, which is the T01 variant of the file.
On importing, we can build the plots using the variables for the plots (Graph 1: Global Variables - Internal energy, Kinetic energy, Hourglass energy, Contact energy, Total energy AND Graph 2: Rigidwallforce - total resultant force)
CASE 1: Run the crash tube model as it is
For the first case, we are required to run the simulation on the crush tube as is. The instructions outlined previously are followed. In this case, we will be discussing the Type 7 interface when inacti is set to 0 (Default).
From the above animation, it is evident that the presence of the notches results in stress concentrations in those regions and as a result, buckling occurs there first. This will happen in all the following cases involving notches. The region below the highest notch is completely deformed first. After the deformation of the lower part, buckling moves onto the upper part, where buckling takes part next until the crush tube is completely sandwiched between the rigid wall and the source of the force application.
Moving on, we can take a look at the output files to discern possible errors:
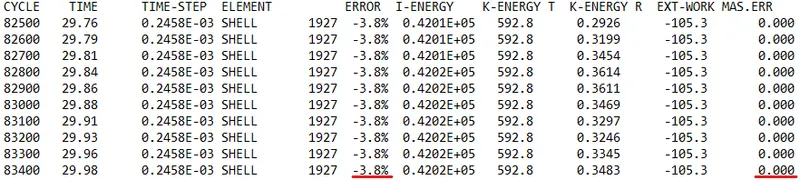
As we can see, the energy error is -3.8%. It is acceptable since it is below -15%. In addition to that, there is no mass error (0%)
Taking a look at the energy and rigid wall plots:
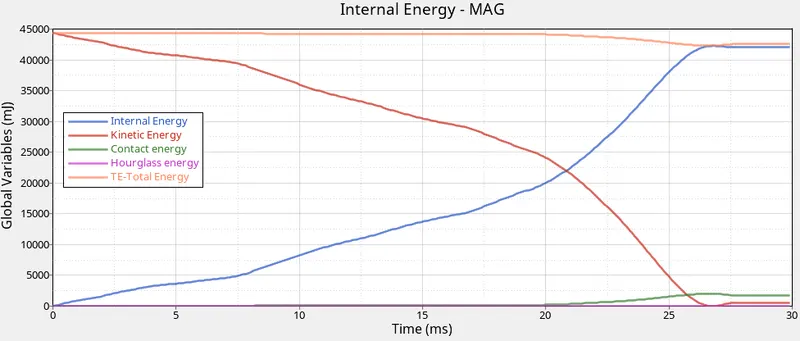
The kinetic energy goes on decreasing as per the buckling endured by the crush tube. It falls to 0 at the 27ms mark, meaning there is no deflection in the model at all at that point. There is a slight increase afterward due to a slight rebound (reaction force) of the tube.
Internal energy keeps increasing over the course of the simulation as expected, with the tube continuously absorbing energy, which in turn results in deformations. Once the deformation was complete, it plateaued around the 27ms mark.
Contact energy is a type of energy that is formed when one element comes in contact with the other or neighbouring elements. The opposing force created by this element forms the contact energy. In this case, it increases after 20 ms, at this point the full model is buckled in such a way that penetration of nodes occurs. With the entire tube pressing on itself, buckled elements are forced into contact. It slightly decreases and stabilizes after the 27ms mark, probably due to the rebound discussed earlier.
The increase in contact energy affects the overall energy of this system, which is why there is a decrease in the total energy at around the same time.
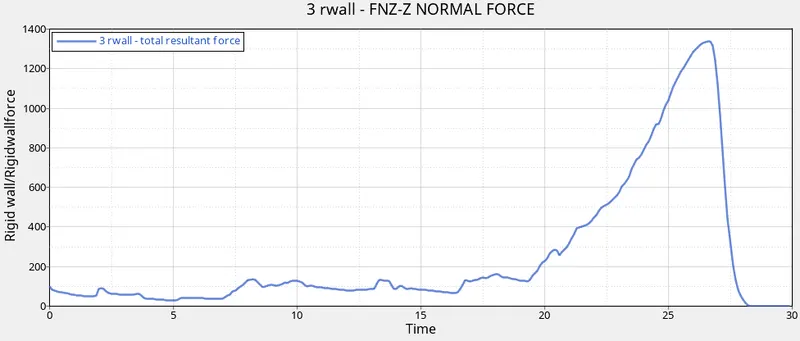
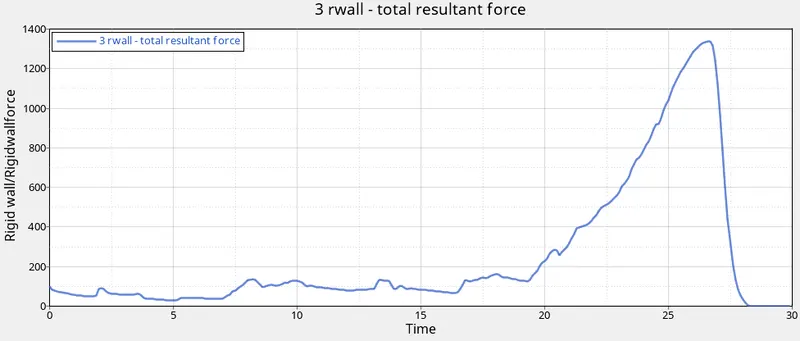
Looking at the RWall forces plot below, it is evident that the rigid wall immediately experiences some of the force. It slightly increases until the 20ms mark where there is a steep increase in the force due to the crush tube having mostly deformed. It was not able to absorb any more energy and this was being transferred to the rigid wall. After the 27ms mark, the tub was deformed completely and that explains the steep decrease in RWall forces.
CASE 2: Change the Inacti=6 and run
In this case, we shall be using Hypercrash as well. So, continuing past the second step outlined in the procedure, we can import the given crush tube model using File > Import.
After importing, we can go ahead and switch to the model browser tab. After that, we can move on to contact interface > self contact.
Doing so lets us edit its attributes. We can go ahead and change the inacti value to 6, as per the requirement.
After that, we can export the model with an appropriate file name and continue the steps outlined (from step 3), after this saved model is imported again in Hyperworks.
There isn't any discernible difference between case 1's and case 2's animations, they're both very similar. Even though the Inacti parameter was changed, it didn’t have any effect on the simulation as there was no initial penetration to manage in the first place.
Next, we can take a look at the output file:
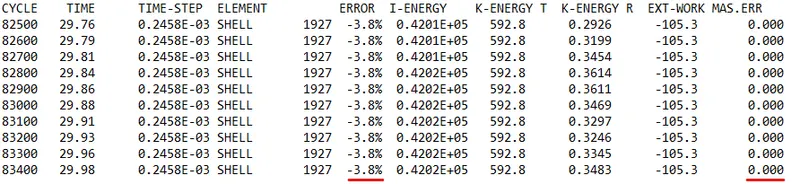
As we can see, the values are the same as in case 1. The energy error is the same -3.8% (also the same mass error of 0%). Moving on to the plots: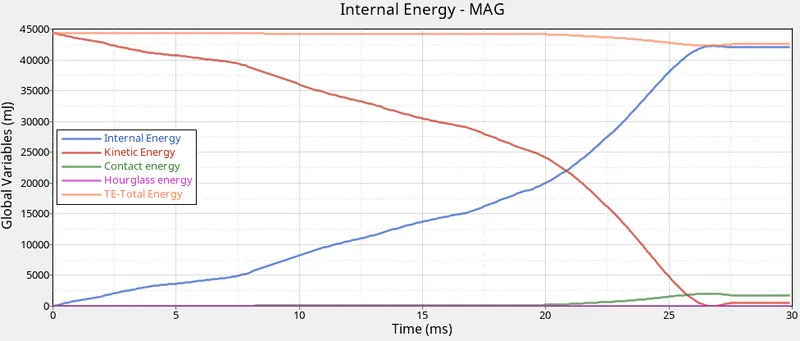
There isn't much to be said as the graphs are exact copies as that of case 1. The only thing we have learned from the energy plot is that there is no initial penetration since there is no difference between case 1 and case 2 energy plots (since the simulation was tweaked to detect such penetrations through the inacti function). If any initial penetrations existed, internal energy would start from a non-zero value.
RWall forces also exhibit the same characteristics as of case 1:
CASE 3: Create the type 11 contact and run
In this case, we are to introduce the type 11 interface to the case 2 solver deck file. After importing it in Hyperworks, following step 2 of the general procedure, we are to make changes in the model browser tab.
Right-clicking the section, we can select Create > Contact. After that, we can define this newly created contact and assign it the following values: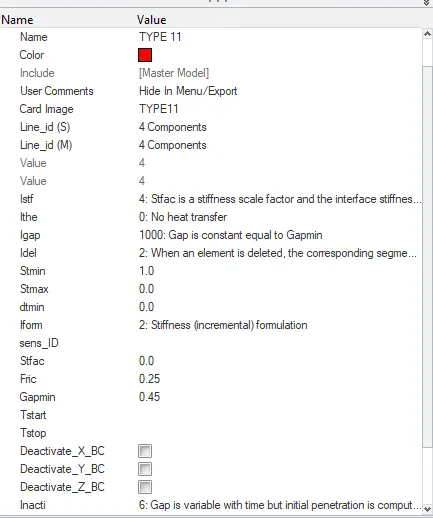
For both Line_id (S & M) attributes, all the components of the model will be selected. The other values are recommended settings for Type 11.
Then, as usual, the file can be processed using the radioss solver. The remaining steps are followed as given.
And here are the output file values: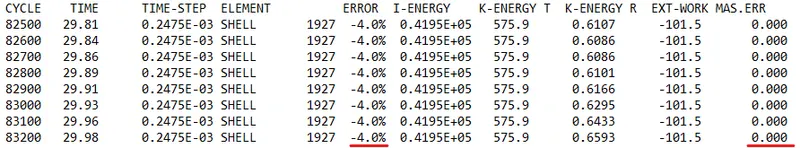
Energy error is still within the -15% limit at -4%. Mass error is non-existent. Moving on to the plots: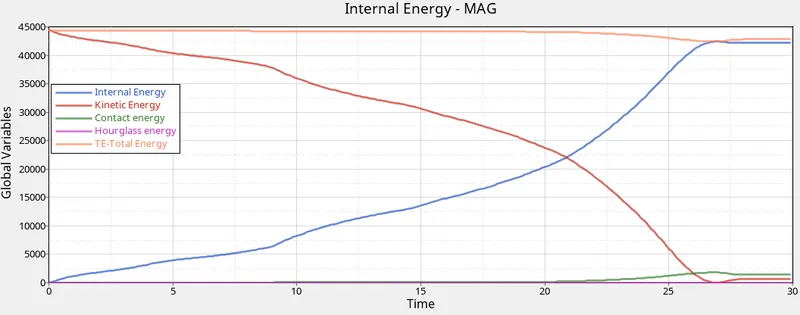
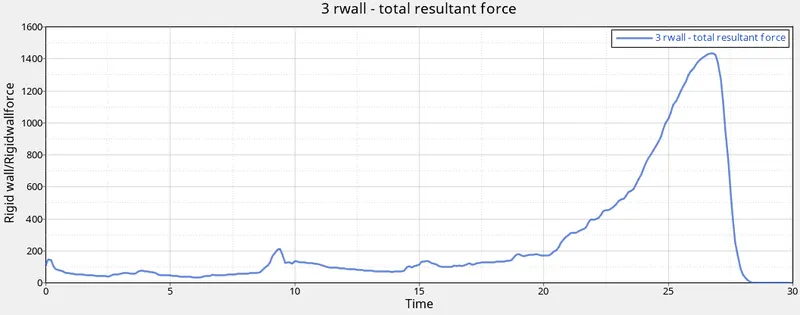
Here, the deformation characteristics are similar to what was observed in previous cases. There is no discernible difference between the energy and rigid wall plots of this case and previous cases. Therefore, we can conclude that there was no edge-to-edge penetration in this model.
CASE 4: Remove both notches and remove boundary condition on rigid body node then run
For this case, we are required to remove the notches and boundary conditions. To do that, after importing the solver deck file (starter file for case 3), we can make use of one of the mesh edit functions available on Hyperworks - the align node tool (F7).
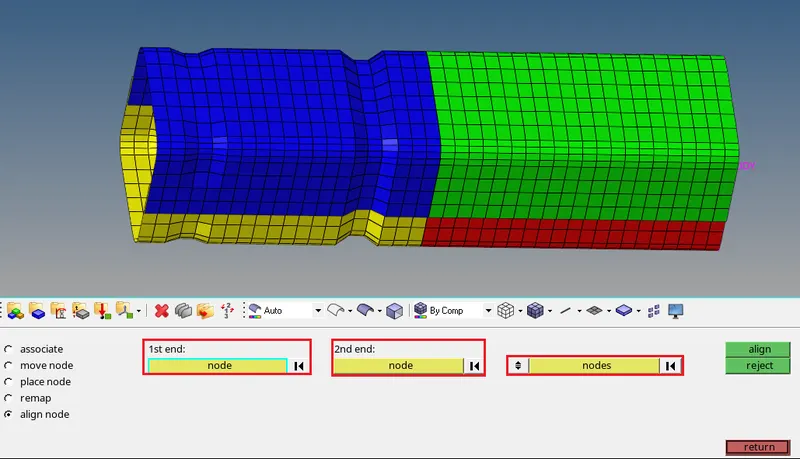
With this tool, we need to select the '1st end' and '2nd end' - which are basically reference points for node alignment. The algorithm picks the singular straight line running through these nodes as reference and aligns the nodes that require alignment, which in this case will be notch removal. After that, we can save the file as 'case4_0000.rad'.
Without notches: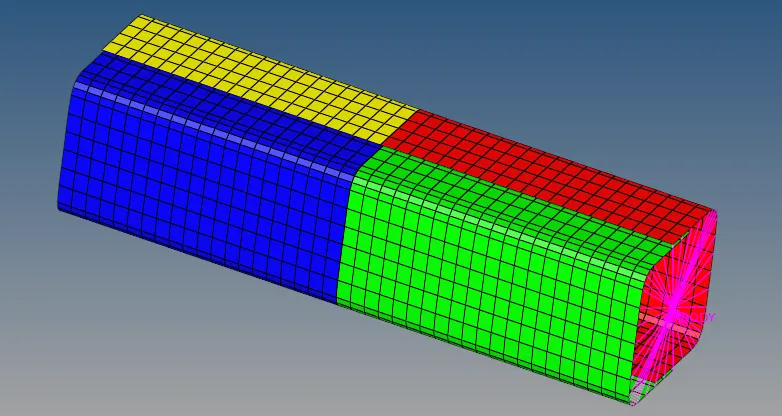
We can now switch to Hypercrash and import 'case4_0000.rad'. Moving on to the model browser tab, right-click 'boundary conditions' and select 'delete'. Doing so removes the boundary condition as per the requirement for this case.
Now we can export this file in the same name and continue to the radioss simulation procedure on Hyperworks. The remaining steps are the same continuing from step 3 in the main procedure as outlined before.
Since there are no notches present, the buckling started at the contact area of the rigid wall and the tube. Whereas, in previous cases, the initial buckling or deformation would happen at the notches.
Here are the output values, which are acceptable numbers: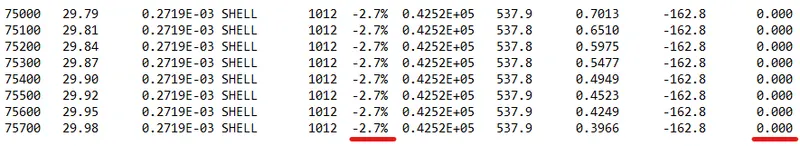
Taking a look at the energy plot: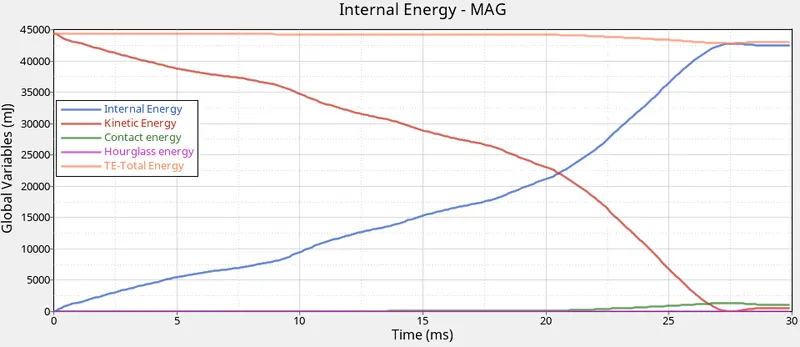
The kinetic energy decreases from maximum with an increase in internal energy. The characteristics are similar as in previous cases, with the internal energy's slope increasing after the 20ms mark, probably due to most of the elements coming in contact with other elements due to the buckling, and due to the fact that the crush tube is almost completely crushed. Although, compared to previous cases, the contact energy is slightly lesser. This is probably due to the lack of notches in the model.
Looking at the rigid wall plot:
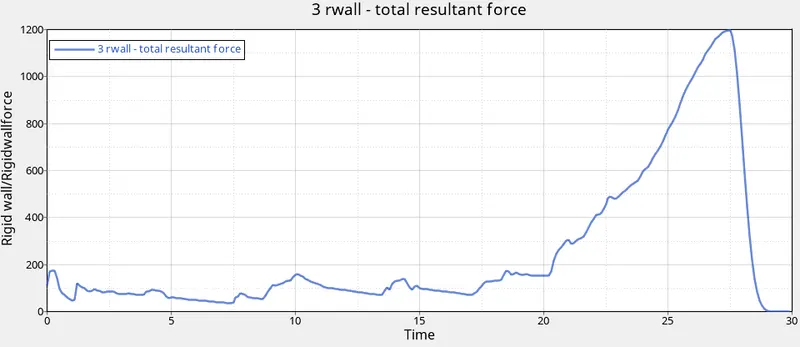
The total resultant force peaks at almost 1200 kN. Just as in the case with internal energy in the previous plot, there is a steep increase at 20ms mark here as well. At this point, a large amount of force is being transferred to the rigid wall considering the crush tube is almost completely deformed to absorb any more energy.
OBSERVATIONS AND RESULT
The given bumper assembly was meshed as per the required mesh size of 6mm and it was also reflected to form the other half.
In the case of the crush tube analyses:
Notches are the regions where deformations happen first under duress, due to them being regions of stress concentration. But it does help to control and predict the location of deformations. This in turn plays a role in how the absorbed energy spreads throughout the tube. A notched tube results in higher contact forces but a smoother transmission of load.
In this assignment, different types of contacts were used to analyze the simulations of the crash tube. Under a constant load, the behaviour was observed by varying the geometry through the removal and creation of notches.