Week 9 - FVM Literature Review
What is Finite Volume Method(FVM)?
Ans:The Finite volume method (FVM) is a widely used numerical technique. The fundamental conservation property of the FVM makes it the preferable method in comparison to the other methods, i.e., FEM, and finite difference method (FDM). Also, the FVM’s approach is comparable to the known numerical methods like FEM and FDM, which means that its evaluation of volumes is at discrete places over a meshed geometry.
Furthermore, the FVM transforms the set of partial differential equations into a system of linear algebraic equations. Although the discrete approximation procedure in use in the FVM is distinctive, it also utilizes two basic steps. Firstly, it transforms and integrates the PDEs into balance equations over an element. The process incorporates the changing of the surface and volume integrals into discrete algebraic relations over elements as well as their surfaces using an integration quadrature of a specified order of accuracy. This will result in a set of semi-discrete equations.
Secondly, in this next step, the interpolation profiles are chosen to estimate the variation of the variables within the element and relate the surface values of the variables to their cell values and thus transform the algebraic relations into algebraic equations. In regards to the two steps in the FVM process, your approximation selection affects the overall accuracy of the subsequent numeric.
What is Finite difference Method(FDM)?
Ans:The finite-difference method is the most direct approach to discretizing partial differential equations. You consider a point in space where you take the continuum representation of the equations and replace it with a set of discrete equations, called finite-difference equations. The finite-difference method is typically defined on a regular grid and this fact can be used for very efficient solution methods. The method is therefore not usually used for irregular CAD geometries, but more often for rectangular or block-shaped models.
There is a connection with the finite-element method: Certain formulations of the finite-element method defined on a regular grid are identical to a finite-difference method on the same grid. Regular grids can often be used in meteorological, seismological, and astrophysical simulations.
The major differences between FDM & FVM:
A finite difference method (FDM) discretization is based upon the differential form of the PDE to be solved. Each derivative is replaced with an approximate difference formula (that can generally be derived from a Taylor series expansion). The computational domain is usually divided into hexahedral cells (the grid), and the solution will be obtained at each nodal point. The FDM is easiest to understand when the physical grid is Cartesian, but through the use of curvilinear transforms the method can be extended to domains that are not easily represented by brick-shaped elements. The discretization results in a system of equation of the variable at nodal points, and once a solution is found, then we have a discrete representation of the solution.
A finite volume method (FVM) discretization is based upon an integral form of the PDE to be solved (e.g. conservation of mass, momentum, or energy). The PDE is written in a form which can be solved for a given finite volume (or cell). The computational domain is discretized into finite volumes and then for every volume the governing equations are solved. The resulting system of equations usually involves fluxes of the conserved variable, and thus the calculation of fluxes is very important in FVM. The basic advantage of this method over FDM is it does not require the use of structured grids, and the effort to convert the given mesh in to structured numerical grid internally is completely avoided. As with FDM, the resulting approximate solution is a discrete, but the variables are typically placed at cell centers rather than at nodal points. This is not always true, as there are also face-centered finite volume methods. In any case, the values of field variables at non-storage locations (e.g. vertices) are obtained using interpolation.
A finite element method (FEM) discretization is based upon a piecewise representation of the solution in terms of specified basis functions. The computational domain is divided up into smaller domains (finite elements) and the solution in each element is constructed from the basis functions. The actual equations that are solved are typically obtained by restating the conservation equation in weak form: the field variables are written in terms of the basis functions, the equation is multiplied by appropriate test functions, and then integrated over an element. Since the FEM solution is in terms of specific basis functions, a great deal more is known about the solution than for either FDM or FVM. This can be a double-edged sword, as the choice of basis functions is very important and boundary conditions may be more difficult to formulate. Again, a system of equations is obtained (usually for nodal values) that must be solved to obtain a solution.
Comparison of the three methods is difficult, primarily due to the many variations of all three methods. FVM and FDM provide discrete solutions, while FEM provides a continuous (up to a point) solution. FVM and FDM are generally considered easier to program than FEM, but opinions vary on this point. FVM are generally expected to provide better conservation properties.
Finite-Difference Method: Advantages and Disadvantages
The finite-difference method is defined dimension per dimension; this makes it easy to increase the “element order” to get higher-order accuracy. If you can fit the simulation in a rectangular or box-shaped geometry using a regular grid, efficient implementations are much easier than for finite-element and finite-volume methods. Regular grids are useful for very-large-scale simulations on supercomputers often used in, as mentioned before, meteorological, seismological, and astrophysical simulations.
With the finite-difference method, you may easily run into problems handling curved boundaries for the purpose of defining the boundary conditions. Boundary conditions are needed to truncate the computational domain. They represent communication with the surrounding world, which is the part that you do not want included in your simulation. If one can overcome the boundary-condition problem on curved boundaries, the method gives very efficient and high quality results.
For computations that need high accuracy, the extra effort in making boundary-fitted meshes and the associated complications of such meshes for the implementation may be worth it. Examples include Formula 1 car computational-fluid-dynamic (CFD) simulations and space-shuttle CFD simulations. The finite-difference method is more difficult to use for handling material discontinuities. In addition, it does not lend itself for local grid refinement or anything similar to “adaptive mesh refinement.” This may be needed to resolve local rapid variations in solutions such as around a corner of a complex shape, as described earlier.
Finite-Volume Method: Advantages and Disadvantages
The finite-volume method is a natural choice for CFD problems, since the partial differential equations you have to solve for CFD are conservation laws. However, both finite differences and finite elements can also be used for CFD. Efficient technology for CFD with the finite-element method has become increasingly popular over the last 10 to 15 years. Techniques for CFD with the finite-difference and finite-volume method have been known and used much longer.
The finite-volume method’s strength is that it only needs to do flux evaluation for the cell boundaries. This also holds for nonlinear problems, which makes it extra powerful for robust handling of (nonlinear) conservation laws appearing in transport problems.
The local accuracy of the finite-volume method, such as close to a corner of interest, can be increased by refining the mesh around that corner, similar to the finite-element method. However, the functions that approximate the solution when using the finite-volume method cannot be easily made of higher order. This is a disadvantage of the finite-volume method compared to the finite-element and finite-difference methods.
The need for interpolation schemes and flux limiters in FVM.
Interpolation schemes:Interpolations schemes contains terms that are interpolations of values typically from cell centres to face centres.
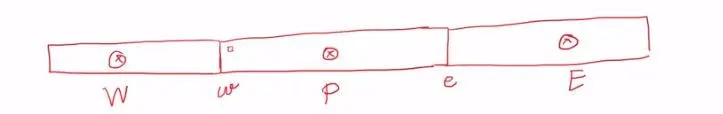
Here w and e are flux .
To find out the flux will use interpolation schemes i.e:
`T_w=(T_p+T_W)/(Deltax)`
`T_e=(T_P+T_E)/(Deltax)`
The interpolationSchemes sub-dictionary contains terms that are interpolations of values typically from cell centres to face centres. being divided into 4 categories: 1 category of general schemes; and, 3 categories of schemes used primarily in conjunction with Gaussian discretisation of convection (divergence) terms in fluid .It is highly unlikely that the user would adopt any of the convection-specific schemes for general field interpolations in the interpolationSchemes sub-dictionary, but, as valid interpolation schemes.
A general scheme is simply specified by quoting the keyword and entry, e.g. a linear scheme is specified as default by:
default linear;
The convection-specific schemes calculate the interpolation based on the flux of the flow velocity. The specification of these schemes requires the name of the flux field on which the interpolation is based; in most OpenFOAM applications this is phi, the name commonly adopted for the surfaceScalarField velocity flux . The 3 categories of convection-specific schemes are referred to in this text as: general convection; normalised variable (NV); and, total variation diminishing (TVD). With the exception of the blended scheme, the general convection and TVD schemes are specified by the scheme and flux, e.g. an upwind scheme based on a flux phi is specified as default by:
Some TVD/NVD schemes require a coefficient where corresponds to TVD conformance, usually giving best convergence and corresponds to best accuracy. Running with is generally recommended. A limitedLinear scheme based on a flux phi with is specified as default by:
default limitedLinear phi 1.0;
Flux limiters:
When we are calculating Gradients,the values should be bounded they cannot be jumped.If we have a shock flow problem there will be a huge discontinuity, so the gradient will have a huge value ,so will use flux limiter.
The behaviour of numerical schemes in order to capture shocks and discontinuity that arises in hyperbolic equations. Physically, these equations model the convective fluid flow. It has been observed that low-order schemes are usually stable but quite dissipative in nature around the points of discontinuity/shocks. On the other hand higher-order numerical schemes are unstable in nature and show oscillations in the vicinity of discontinuity. One can have a better understanding of such behaviour by analysing the modified equation of these schemes.
Now as said above one can not have high order accuracy without oscillations. The objective is to have highly accurate and stable oscillation free schemes. This kind of schemes are known as high resolution schemes. In 1984 Harten proposed the constuction and gave TVD criteria for such scheme. Here we talk only about using flux limiters function to construct high resolution schemes. The idea is to tune the numerical flux of high order and low order scheme using the flux limiter function in such a way that the resulting scheme gives a high order accuracy in the smooth region of flow and sticks with first order of accuracy in the vicinity of socks/discontinuities.