Week-7 Challenge: DC Motor Control
Question:-1
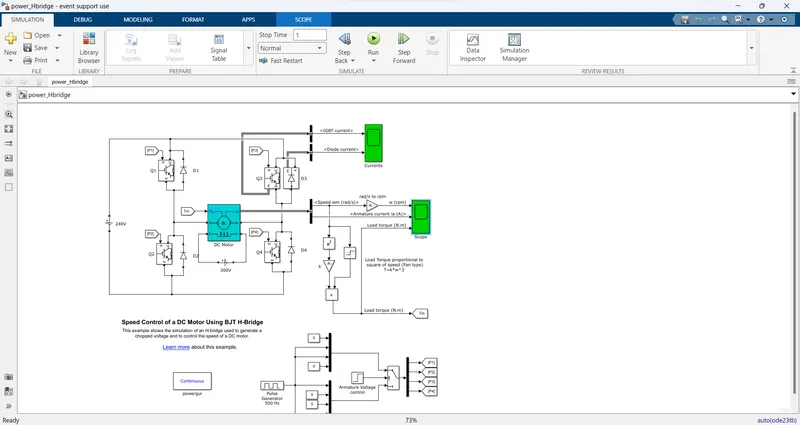
Working of H-bridge model:-
- Here H-bridge DC chopper circuit is designed to control the speed of the motor.
- IGBT acts as BJT in power switching devices.
- Four IGBT switches are used for inverting the DC voltage 0 to 240 v supply.The current flows from collector(C) to emitter(E).
- The gate are controlled by the pulses(0 and 1) according to the armature voltge of motor given by pulse generator.
-
FORWORD DIRECTION IN MOTOR:-IN simulink model connecting the four switches and it means says four quadrent in model.when the first switch(s1) and fourth switch (4) is closed than the working in forword mode in motor and more one we can saying the speed of motor is gradualy increases and some times after go dwon.and conecting the current is postive to postive .
REVERSE DIRECTION IN MOTOR:-WHEN the switch third and second is closed than the motor speed is the reverse direction and the motor speed is go down the sudden negative means reverse .
over all speed is covering first of all increasing and the some time after the suddenly decreasing the speed its means revese direction.
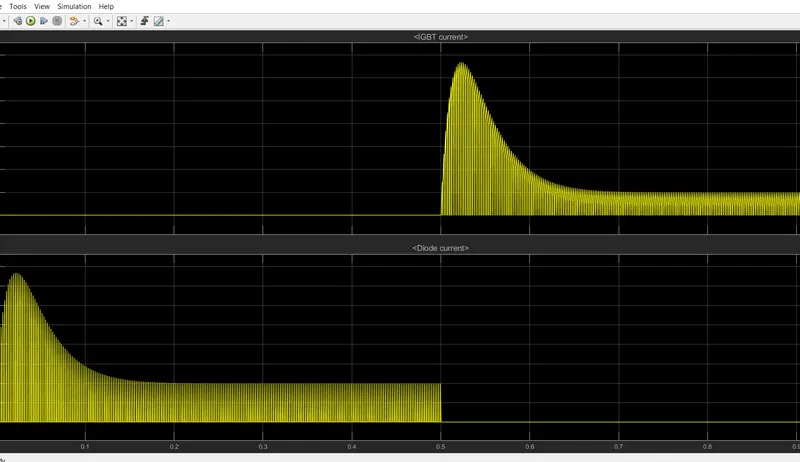
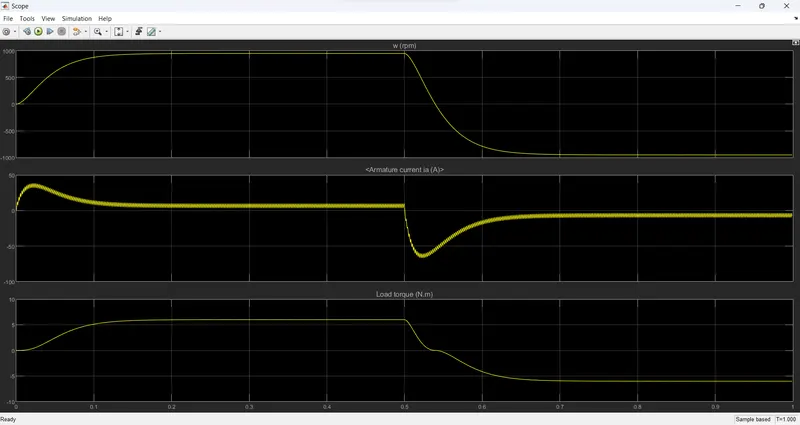
B:-SHOOTUP CURRENT:-when the motor is forword mode than the current is incresing but sometimes after geting a saturation point and the when the motor is reverse going direction than the sudden change the in neagtive and the when the changing in negative this time duration in the geting shootup current.and once again in a satureation state.
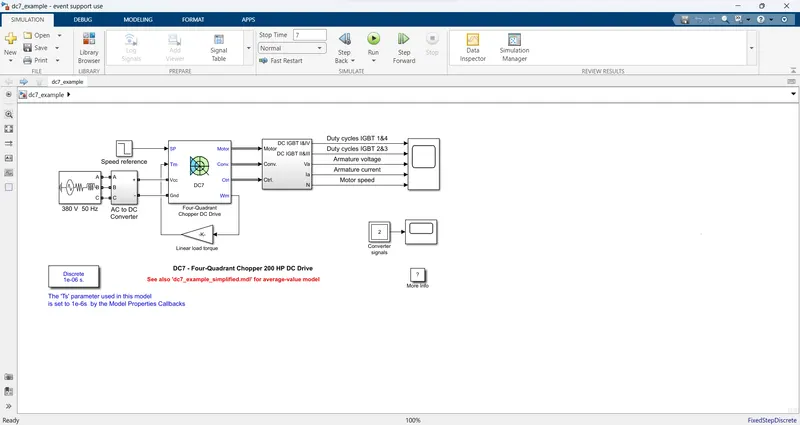
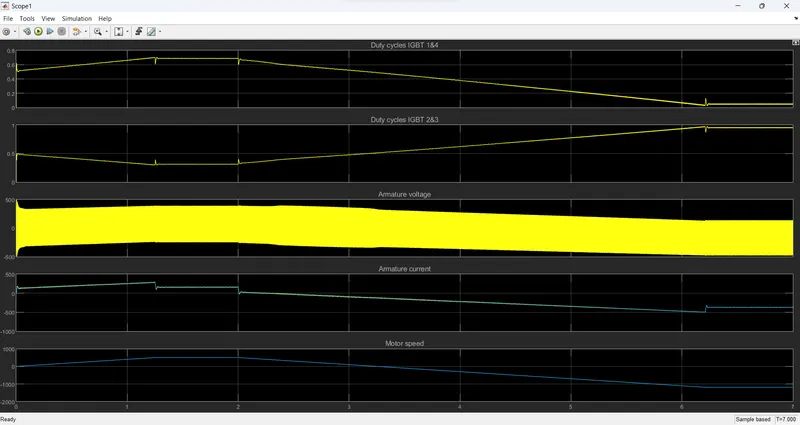
C:-The Four-Quadrant Chopper DC Drive (DC7) block IS NORMALY SAYING IN FOUR QUADRENT IN MODEL.IN SIMULINK MODEL AS GIVEN DATA OF MODEL SAYING THE DUTY CYCLE IS DEFINED THE MODEL OG INPUT AN OUTPUTS DATA DEFINED AND IN THE QUADRENT FIRST AND THIRED IS THE BLOCK IS USED THE DC MOTOR SPEED RECOVERING.
COMPARE:- H- BRIDGE Chopper DC Drive (DC7) block
ARMATURE CURRENT- INCREASING FAST AND SOME AFTER INSTANIOUS TIME INCREASES AND SOME
DECREASING AT SATURATION STATE TIMES AFTER STATURATION STATE
SUDDEN CHANGE GRADUALLY CHANGE
IN GRTING SHOOTUP CURRENT NO GETING OTHER CURRENT
SPEED:- GRADUALLY SPEED IS INREASING THAN THE SLOWELY INCRESING THAN GRADUALLY DECREASING
A STATURETION STATE
SUDDEN CHANGE IN SPEED IN REVERSE NOT GRT SUDDEN CHANGE
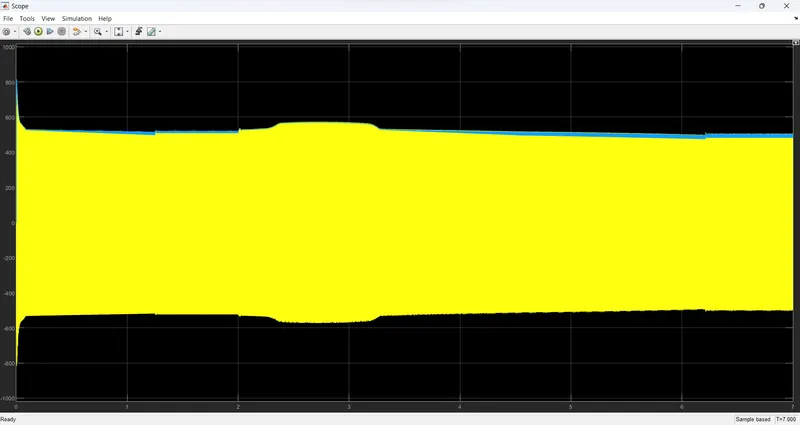
QUESTION:-2 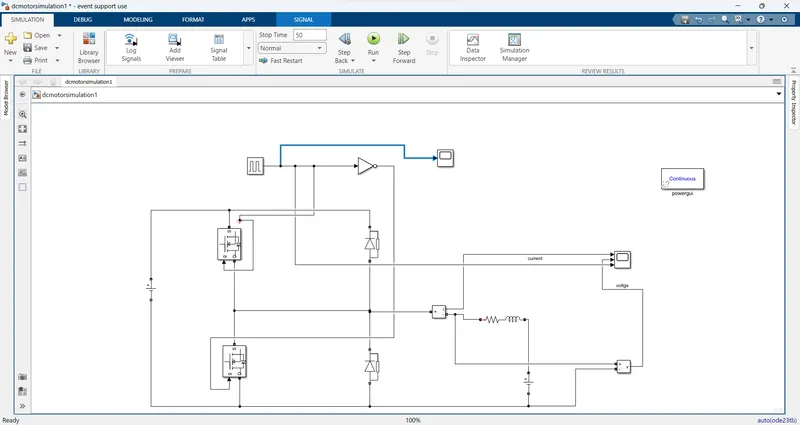
created a 2-quadrant chopper using simulink & explain the working of the same with the relevant results.
and creating a 2-quadrant chopper using simulink model .this chopper also called the two quadrent chopper of type c.
working:- two mosfet switching blocks ,two diode block,one pulse genrator,one not block,two scope ,
one current measurement block,one voltage measurment block two dc voltage source,one RL load series, continous blocks, than completing the model .
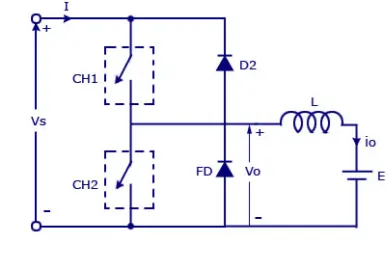
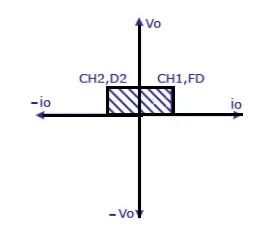
in four quadrent chopper but the explanation in two chopper
first quadrent chopper in output voltage and output current will be postive and second things the output voltage is postive and outut current will be negative see in below figre .
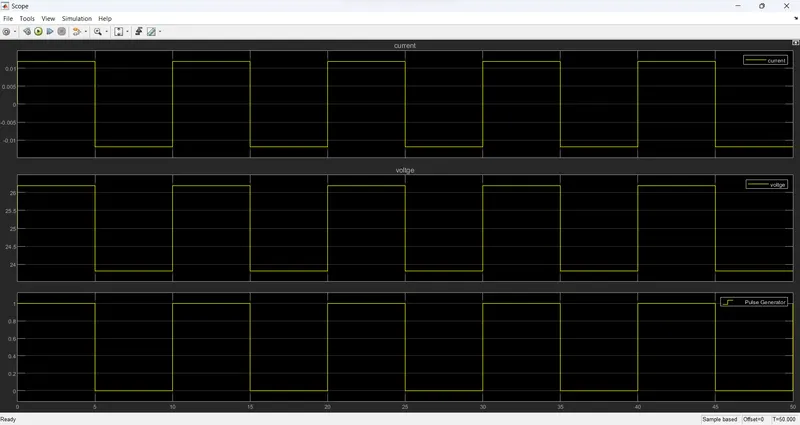
Question:-3
BLDC MOTOR:- INTRODUCTION:- BLDC Motor is special dc machine which is used to converts the eletrical energy to machenical energy .this motor is designed as the produce the high torqueand speed .and this motor has long operating life due to lack of brush and commutator.there will be a friction btween brushless and the commutatorand both will be wear gradually and heat generated from midle losses of power.
BLDC IS TWO TYPE MOTOR:-
- INNER ROTOR BLDC MOTOR:
:-IN THIS MOTOR RATATING PART IS PERSENT IN CENTER.
2.OUTER ROTATOR TYPE BLDC MOTOR:-
IN THIS MOTOR STATIONARY PART IS PRESENT IN CENTER AND BY HELP OF MAGNET PIECE ROTATING PART DESIGNED.
WORKING:-The brushless dc motor is really an ac motor.the current through it alternates as we will see ti is called brushless dc motor because the alternating current must variable frequency and so derived from a dc supply and because its speed and torque speed characterstic are very similar to the ordinary with brushless dc motor as result of bldc .
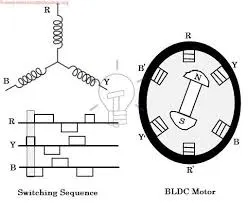
and also known as the self synchronious motor and and bldc of the permament magnet is electronically connected and rotor consist of a permament magnet and the stator pole in flow the current direction with magnetise the stator and rotor than the ratating in correct direction and the stator coil is switched off than momentum carries the rotator on stator coil is re energized but the current and hence the magnetic field is reused. so the rotator pulled on round in clockwise direction. and this process is continues with the cureent flow direction in stator coil alternatating .
obvisoulybthe switching of the current must be synchronused with the postion of the rotator . this is done the using the sensor .these are often the HALL EFFECT SENSOR that use the magnetism of the rotator to sense it postion but the optical sensors are also used.
if the abve the smmery thats used in the ELECTRONIC SPEED CONTROLLER devise.
BLDC MOTOR IS DESIGNED FOR THE THE SMOOTH OPERATION.
APPLICATION:-
- It is used in dental drills.
- it is used in scanners and miniature pumps.
- it is used in laser beam reflector rotation.
- BLDC motor is used in factory automation.
- it is used in manufacturing equipments.