Week-7 Challenge: DC Motor Control
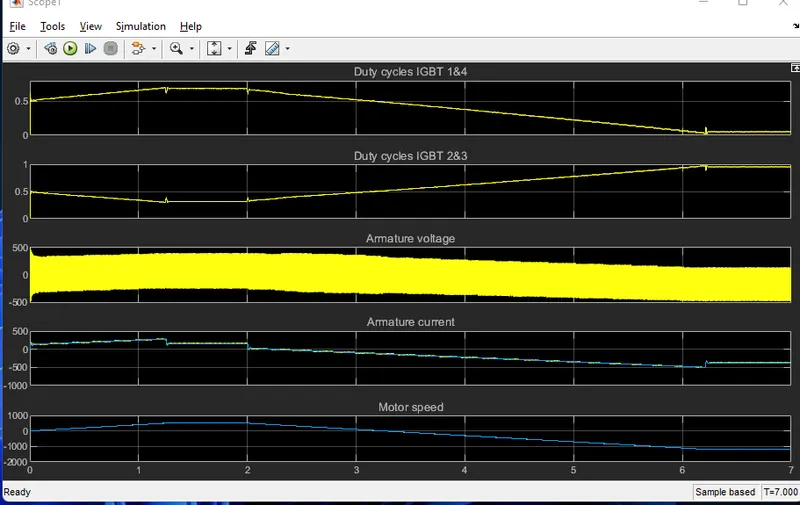
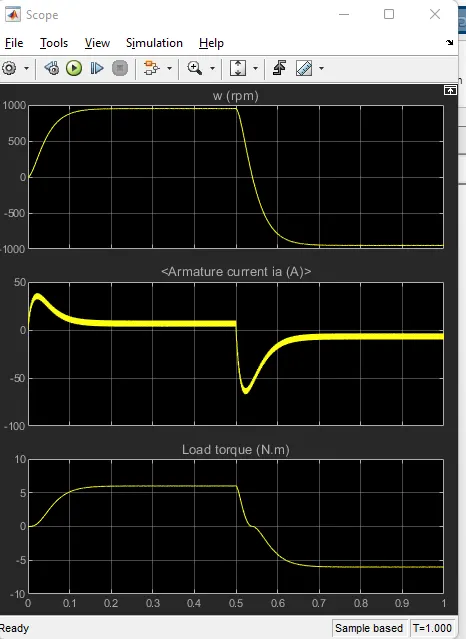
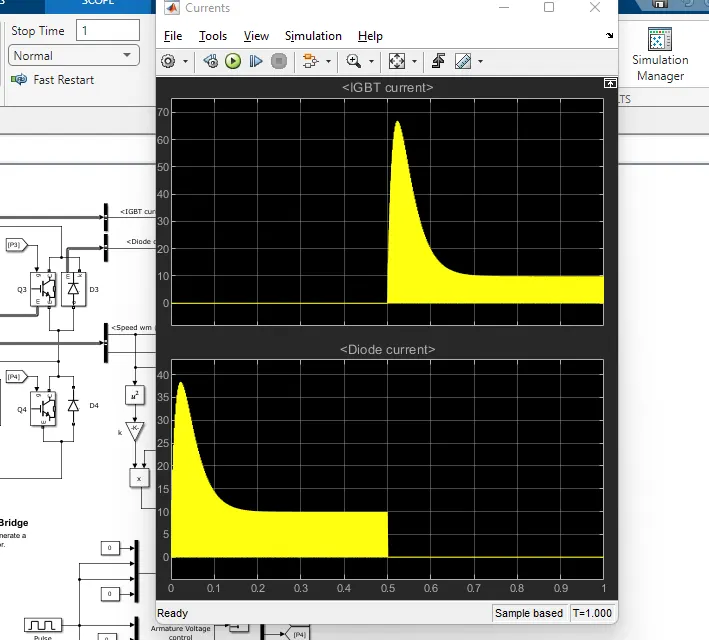
the waveform for speed, armature current and load torque is shown in above graphs.
from armature current graph , we can see that ,at starting there is sudden spike increase in current at 0 sec also and at 0.5 sec also.
We can see that , as the voltage gets changed in the circuit , the speed of motor also changes.
In this transition of positive to negative direction of rotation we observe a high surge in current, this is due to the transient switching occurring in the circuit.
As there is already current flowing in the circuit & on changing of switches after 0.5 sec, the current in the circuit adds to the changed direction of current and we observe a surge.
from armature current graph , we can see that ,at starting there is sudden spike increase in current at 0 sec also and at 0.5 sec also means at transition from positive to negative direction of rotation we observe a high surge in current, this is due to the transient switching occurring in the circuit.
As there is already current flowing in the circuit & on changing of switches after 0.5 sec, the current in the circuit adds to the changed direction of current and we observe a surge in current.
the surge in the current can be reduced by reducing the duty cycle.
in above results , the duty cycle selected as 75%.
by changing the duty cycle from 75% to 50% , the current surge can be reduced tremendously.
COMPARISON OF 4 QUADRANT CHOPPER AND BJT H BRIDGE:
1) the 4 quadrant chopper works in all four modes like
- forward motoring
- forward breaking
- reverse motoring
- reverse breaking
but the BJT h bridge model works on only two modes
- forward motoring
- reverse motoring
2)to change the direction of rotation of motor from forward to reverse and vice versa , the current signals get transited from one to other switch while in h bridge model, the direction of rotation of motor is changed by changing the polarity of current.
3)the 4 quadrant chopper have high switching frequency
while h bridge model have low switching frequency
4)the armature current in 4 quadrant chopper have a little spike at transition from one to other switch because of high swithing frequency while h bridge model have high spike of current.
5) the 4 quadrant chopper is generally used in industrial application while h bridge model is used in robotics.
BLDC MOTOR
Brushless DC electric motors also known as electronically commutated motors .A brushless DC motor (known as BLDC) is a permanent magnet synchronous electric motor which is driven by direct current (DC) electricity and it accomplishes electronically controlled commutation system (commutation is the process of producing rotational torque in the motor by changing phase currents through it at appropriate times) instead of a mechanically commutation system. BLDC motors are also referred as trapezoidal permanent magnet motors.
Unlike conventional brushed type DC motor, wherein the brushes make the mechanical contact with commutator on the rotor so as to form an electric path between a DC electric source and rotor armature windings, BLDC motor employs electrical commutation with permanent magnet rotor and a stator with a sequence of coils. In this motor, permanent magnet (or field poles) rotates and current carrying conductors are fixed.