Week-7 Challenge: DC Motor Control
1. A) Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge.
sol: 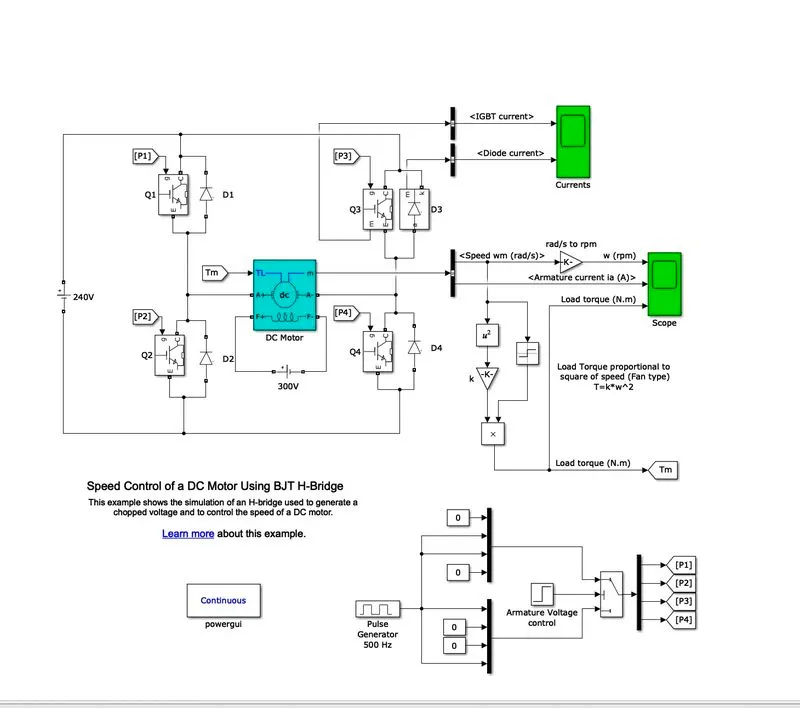
In the above Circuit, the Input voltage is generated from the Pulse generator where the amount of supply and duty cycle is assigned in the Pulse generator.
Pulse width=ON+OFF
Duty Cycle=ON/ON+OFF
D-PW/T
Then the switch block is connected to the Pulse generator through armature voltage control black. The H-bridge consists of 4 BIT/Diode pairs (BIT Simulated by IGBT Models). Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3.
When Q1 and 04 are fired, a positive voltage is applied to Motor and Diodes D2-D3 operate as freewheeling diodes, where Q1 andQ4 are switched off.
When Q2 and Q3 are fired, a negative voltage is applied to Motor and Diodes D1-D4 operates as free wheeling diode when Q2 and Q3 are switched OFF.
-
A Switch block at bottom of the circuit Splits the Power Supply into 4 parts namely are [{p1} {p2} {p3} {p4}]. These inputs are in the Goto form block.
-
That block is used to send signals to "From Block" that have the specified tag. If the tag visibility is "scoped" then a Goto tag visibility block must be used to define the visibility of that particular tag. The block icon displays the selected tag name (local tag are enclosed in bracket " and Scoped tag names are enclosed in braces" {}").
-
Therefore these 4 types of Input are connected to transistors Q1, Q2, Q3, and Q4 through "FromBlock"; An "From block" Receives the Signal from the "Gato Block with the specified tag. The block icon displays the selected tag name (local tags are enclosed in brackets and Scoped tag names are enclosed in brace {}, brackets).
-
SWITCHES
Q1 and Q2-Forward Motoring.
Q2 and Q3-Reverse Motoring.
-
This formation is called an H Bridge, An H-Bridge is an arrangement of transistors that allows a circuit full control over a standard electric DC motor.
-
The DC Motor is connected to the battery and the Mechanical Input of the DC Motor is Initiated as torque. Load Torque Proportional to Square of Speed.
Where T=Load torque
w=Speed
- Torque for Mechanical input of DC motor also switched by Goto and From
- The output of the DC motor is connected with the "BUS sector whereas the Speed is plotted in the Scope. A conversion of Speed from rad/sec to rpm is held between the BUS sectors to scope using converter block.
B) Comment on the armature current shoot-up from the scope results.
sol:
-
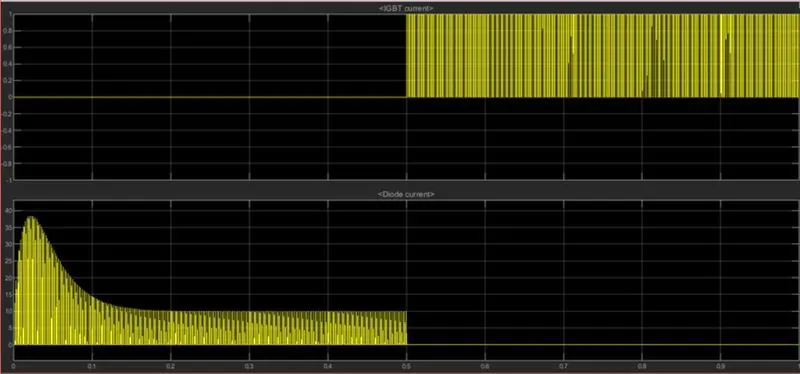
In the Current output, the amount of circuit acted is shown as the graphical representation during the period of duty cycle. The scope shows IGBT current and Diode current passed in the Quadrant Q3 and D3 (as initial current is in diode to start the circuit is in D3 diode).
-
Where Q3 represents IGBT current and D3 is represented as Diode current in scope.
- The Graph shows that when the Switch Q3 is OFF on the Starting Stage of Current flow and Diode current is on that stage.
- During the 0.5 sec of time D3 switch is ON that are given according to Pulse generator (step time in armature voltage control of 0.5) and after the time period of 0.5 sec D3 switch is OFF and IGBT current is acted after 0.5 sec and Q3 switch remains ON
-
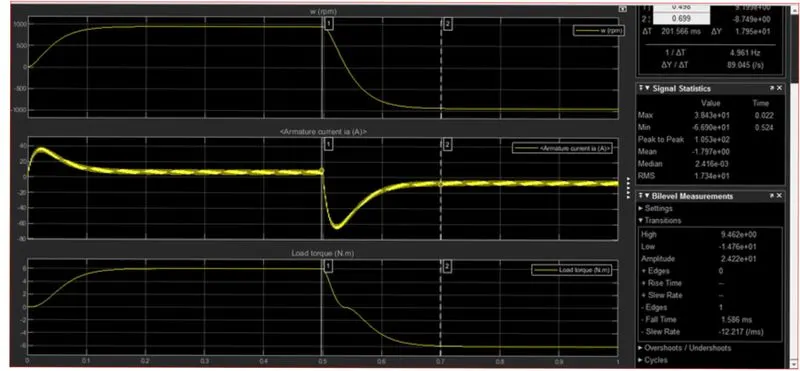
The Speed and Armature current is obtained by the DC Motor and Load Torque is Calculated by load torque proportional to the square of speed.
-
At Starting point, there is a sudden Shoot up is acted.
-
This Scope shows that speed is increased in a certain period of time and at that time armature current is positive whereas Load Torque also moves forward.
-
After the time period of 0.5 sec which is given in Pulse generator (step time), sudden shoot-up is acted and speed gets decreased in that time armature current is in negative terminal whereas Torque act as reverse action.
-
Here the sudden shoot-up is acted while the Armature current is processed at a positive and negative terminal.
BY CHANGING THE PULSE GENERATOR INPUT VALUE (TO REDUCE THE SHOOT UP OF ARMATURE CURRENT)
-
One simple and easy way to control the Speed of a Motor is to Regulate the Amount of Voltage across its Terminal and this can be achieved using "Pulse Width Modulation".
-
For Experimental Section we will reduce the Pulse width (i.e. refer to as DUTY CYCLE) of the Pulse generator block by 50% at the same time period.
-
The Inputs of P1, P2, P3, and P4 are also changed according to the drive cycle. When the Q1 and Q4 switch is ON the Motor is generated as Forwarding direction that states Q3 switch and the Q2 switch is in OFF.
-
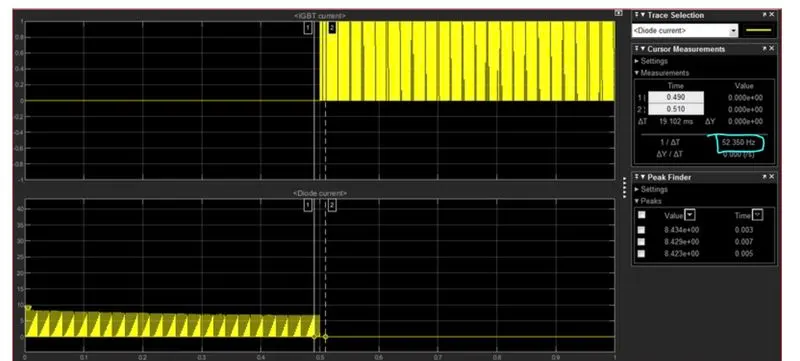
When the Q2 and Q3 switch is ON the Motor is generated in the reverse direction that states the Q1 and Q4 switch is in OFF condition. The change made as 50% of Pulse width is Shown as below.
-
Here we see that the sudden shoot-up is not acted by comparing with 75 of the pulse width. The same cycle time is followed in this experiment also.
-
In this observation starting current is generated as Diode current for a time period of 0.5 sec, then IGBT current is acted while the diode current is being stopped.
-
This graph shows when the switch Q3 is OFF on the starting stage of current flow and Diode current is ON at that stage. During the 0.5 sec of time D3 switch is ON that is given according to the Pulse generator and after the time period of 0.5 sec D3 switch is OFF. An IGBT current is acted after 0.5sec and Q3 switch remains ON.
-
There will be little variation as shown in the graph at the starting point of current but the complete reduction of Shoot-Up is not held here.
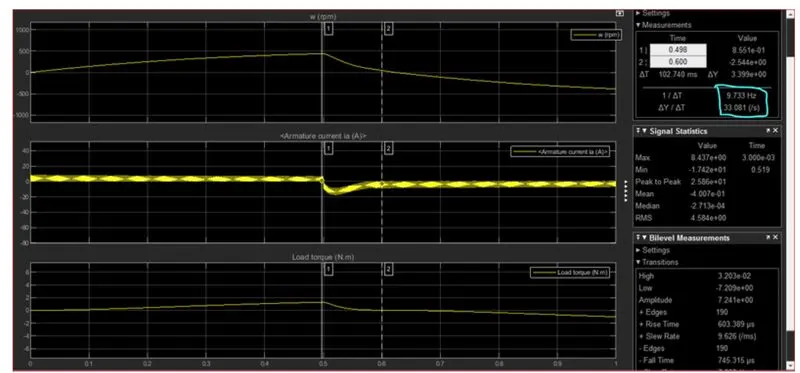
-
In this above Scope, A Flow of Armature current is displayed and Speed, Load Torque is also displayed.
-
The change is made in pulse width as 50% (52% marked difference in the graph) from the pulse generator and results are shown that voltage fluctuation is held in starting point of Forwarding reverse state.
-
That sudden Fluctuation is reduced in this Experiment by reducing the Pulse width (duty cycle of the motor) of the input Supply
-
A Change is also held in Speed and Load Torque where the constant level of Speed and Torque is acted in above scope compared with the previous with 75% of the Pulse width.
-
The time period of forwarding and reverse action is maintained as same as the previous Duty cycle.
-
In this observation, the Shoot-Up is reduced when the motor changes direction from forwarding to Reverse compared to 75% of the Pulse width.
C) Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
sol: COMPARISON OF FOUR-QUADRANT CHOPPER DC DRIVE( DC7) WITH H-BRIDGE
-
In four Quadrant Chopper DC drive distributes the required current supply for each sector and it consists of 4 quadrants like forwarding Motoring, Regenerative Braking, Reverse Motoring, and Reverse Regenerative Braking, Whereas in H-bridge supplies an irregular current for each sector that causes voltage Fluctuation in armature current; it consists of 2 Operation namely they are Forward Motoring, Reverse Motoring.
-
In Modern Battery Technology Charger used for EV charging uses an H-bridge circuit. Whereas a Four Quadrant Operation is required in industrial as well as commercial applications.
-
The efficiency is high in Chopper compared with H-bridge and Maintenance is less than H-bridge.
-
In Robotic Technology. H-bridge circuit is used; some other application of Four Quadrant Operation is Engine Test Loading Systems.
- In H-bridge we need to change Polarity which turns into the opposite direction to control the motor whereas in the chopper model we need to interrupt one signal under the control of another.
3. Explain in a brief about the operation of the BLDC motor.
sol: Operation:
- BLDC motor works on the principle similar to that of a conventional DC motor, i.e., the Lorentz force law which states that whenever a current-carrying conductor is placed in a magnetic field it experiences a force. As a consequence of the reaction force, the magnet will experience an equal and opposite force. In the case, BLDC motor, the current-carrying conductor is stationary while the permanent magnet moves.
- When the stator coils are electrically switched by a supply source, it becomes an electromagnet and starts producing the uniform field in the air gap. Though the source of supply is DC, switching makes to generates an AC voltage waveform with a trapezoidal shape. Due to the force of interaction between the electromagnet stator and the permanent magnet rotor, the rotor continues to rotate.
- Consider the figure below in which the motor stator is excited based on different switching states. With the switching of windings as High and Low signals, corresponding winding energized as North and South poles. The permanent magnet rotor with North and South poles aligns with stator poles causing the motor to rotate.
- Observe that the motor produces torque because of the development of attraction forces (when North-South or South-North alignment) and repulsion forces (when North-North or South-South alignment). In this way motor moves in a clockwise direction.
- Here, one might get a question that how we know which stator coil should be energized and when to do. This is because; the motor's continuous rotation depends on the switching sequence around the coils. As discussed above Hall sensors give shaft position feedback to the electronic controller unit.
- Based on this signal from the sensor, the controller decides particular coils to energize. Hall-effect sensors generate Low and High-level signals whenever rotor poles pass near to it. These signals determine the position of the shaft