Week-4 Challenge WOT Condition Part-2
EV LIVE SESSION 2021
1)
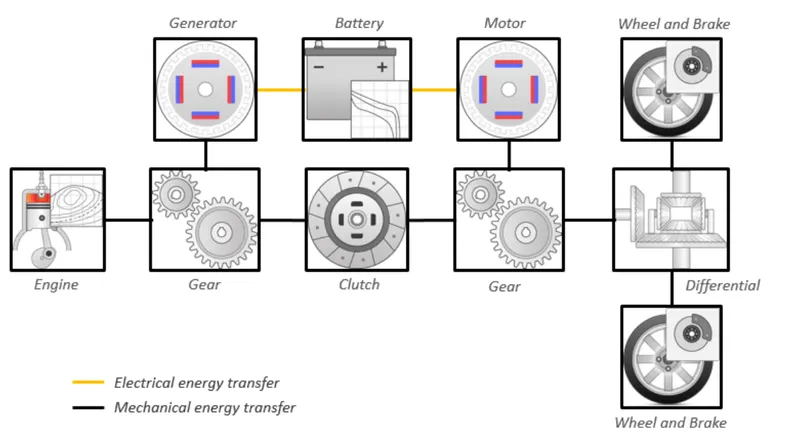
Mapped model is one type where the data points are preassigned in lookup tables.
The engine or motor torque required is sensed and the motor or engine block generates the required torque output just as required simply without considering the real time motor or engine, parameters.
The output values are stored for the corresponding given input values of the engine motor and generator
The accuracy of this type is not that high but the simulation will be done in much less time as it does not run by real time.
Dynamic model used the combination of the outputs from various subsystems to generate the output.
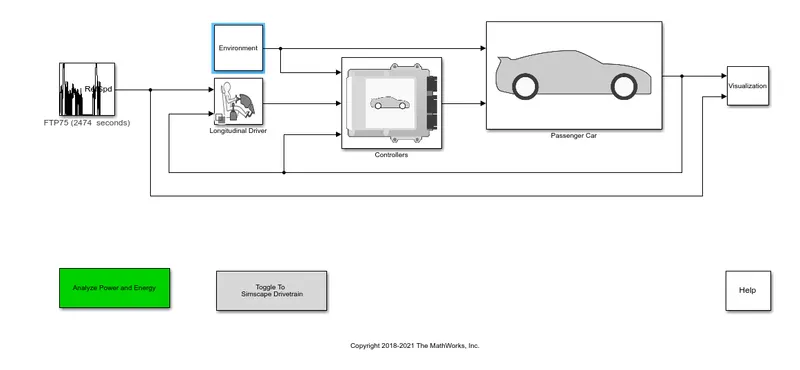
It runs by real time simulation whete the required input from the drive cycle is taken and for that individiual real time simulation perforned and summing all the results of the subsystem gives the output for the simulation
As per the drive cycle requirements the intial bus voltage, current is given along with the vehicle feedback so that it runs the actual simulation at that particular moment throught the drive cycle.
2)
3)