Week 4.1 - Solving second order ODEs
Function code for ode
function [dtheta_dt] = ode_fun(t,theta,b,g,l,m)
theta1 = theta(1);
theta2 = theta(2);
dtheta1_dt = theta2;
dtheta2_dt = -(b/m)*theta2-(g/l)*sin(theta1);
dtheta_dt = [dtheta1_dt;dtheta2_dt];
end
%motion of a simple pendulum with damping
clear all
close all
clc
%input variables
b = 0.05;
g = 9.81;
l = 1;
m = 0.1;
%initial condition
theta_0 = [0;3];
%time inputs
t_span = linspace(0,10,500);
%to solve ode
[t,y] = ode45(@(t,theta) ode_fun(t,theta,b,g,l,m),t_span,theta_0);
%extracting the element from y array
theta = y(:,1);
%base point of pendulum
x0 = 0;
y0 = 0;
plot(x0,y0,'marker','o')
axis([-1 1 -2 0])
ct=1; %initializing ct value
for i = 1:length(y) %starrting of for loop
x1 = l*sin(theta(i)); %point is that where bob of pendulum is attached
y1 = -l*cos(theta(i)); %point is that where bob of pendulum is attached
figure(1)
plot([x0,x1],[y0,y1],'linewidth',2) %plotting the figure
hold on
plot(x1,y1,'marker','o',MarkerSize=20,MarkerFaceColor='r') %plotting the figure
hold off
axis([-1 1 -2 0]) %range between x axis and y axis
title('simple harmonic motion of pendulum')
xlabel('xaxis')
ylabel('yaxis')
M(ct)=getframe(gcf);
ct = ct+1
end
%animation creation
movie(M)
videofile = VideoWriter('ordinay_differential_equation.avi','uncompressed AVI');
open(videofile)
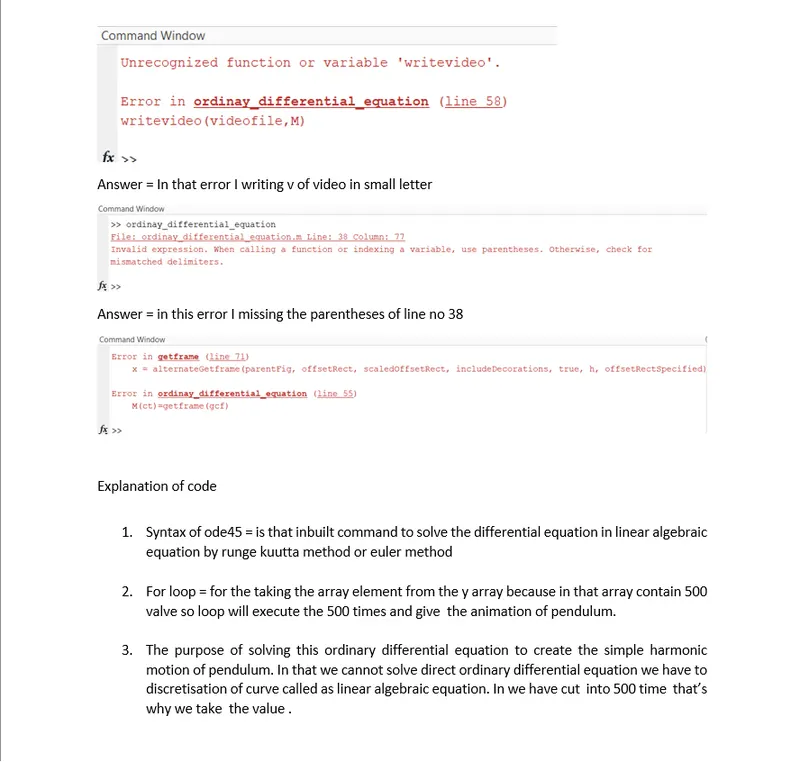
writeVideo(videofile,M)
close(videofile)