Week 3 - Solving second order ODEs
INTRODUTION:
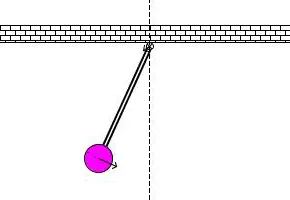
The pendulum is a body or mass suspended from a fixed point so that it can swing back and forth under the influence of gravity. Pendulums are used to regulate the movement of clocks because the interval of time for each complte oscillation,called the period, is constant. The period depends on the length of the pendulum and also to a slight degree on the amplitude, the width of the pendulum's swing.
AIM:
To solve the second-order ode function using Matlab which depicts the motion of the pendulum and to create an animation of the same.
OBJECTIVE:
To write a programe that solves the following ODE. This ODE represents the equation of motion of a simple pendulum with damping
In the above equation,
g = gravity in m/s2,
L = length of the pendulum in m,
m = mass of the ball in kg,
b = damping coefficient.
Fixed parameters
Length (L) = 1 metre,
Mass(m) = 1kg,
Damping coiefficient(b) = 0.05.
Acceleration due to gravity(g) = 9.81m/s2.
For time period = 0 - 20 sec
Anglar displacement = 0,Angular velocity = 3 rad/sec at time t = 0.
FUNCTION CODE
function [dtheta_dt] = ode_func(t,theta,b,g,l,m)

theta1 = theta(1)
theta2 = theta(2)
dtheta1_dt = theta2;
dtheta2_dt = -(b/m)*theta2 - (g/l)*sin(theta1);
dtheta_dt = [dtheta1_dt; dtheta2_dt];
end
EXPLANATION
- In this function program, the second-order ODE is simplifed to the first -order ODE by introducing the term theta1& theta2.
- Then theta1&theta2 is differentiated and the dtheta_dt gives a column matrix.
5.MAIN PROGRAM:
clear all
close all
clc

b = 0.05;
g = 9.81;
l = 1;
m = 0.1;

% Initial condition
theta_0 = [0,3];

% Time points
t_span = linspace(0,20,200);

% Solve ODE
[t, results] = ode45(@(t,theta) ode_func(t, theta, b,g,l,m),t_span, theta_0);

plot(t,results(:,1))
hold on
plot(t,results(:,2))
ylabel('Velocity(Red) & Displacement (Blue)')
xlabel('Time')

% Animation
ct = 1;
for i = 1:length(results(:,1))
    x0 = 0;
    y0 = 0;
    x1 = 1*sin(results(i,1)+pi);
    y1 = 1*cos(results(i,1)+pi);
    figure(2)

    plot([x0 x1],[y0,y1],'-o','MarkerSize',10,'MarkerFaceColor','r','MarkerEdgeColor','r','linewidth',4)
    axis([-2 2 -2 2])
    hold on
    plot([-1 1],[0 0],'linewidth',5,'color','[0 0.3 0]')
    M(ct) = getframe(gcf)
    hold off
    ct = ct+1;
end

% Movie & Videofile
movie(M)
v_f = VideoWriter('Pendulum_Challenge.avi','Uncompressed AVI')
open(v_f)
writeVideo(v_f,M)
close(v_f)
EXPLANATION
- In the above program,the fixed parameters are length,mass damping coefficient, and acceleration due to gravity.
- Time and angle are given as the initial condition.
- In the tspan command, 200 values are taken in between 0 to 20 times period.
- Using the ode 45 command ODE function is introduced.
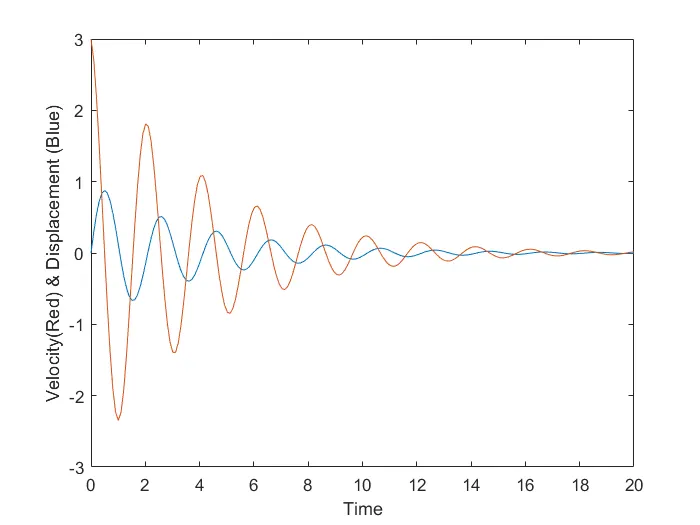
- Using the plot command velocity and displacement is plotted in the y-axis against time in the x- axis.
- Using the for loop command the mass at various points and various times are marked in the graph and are plotted.
- Using the movie command the plot is saved as an uncompressed avi file.
6.PLOT
ANIMATION LINK: https://youtu.be/dzya5RJiDMM