Week 3 - Solving second order ODEs
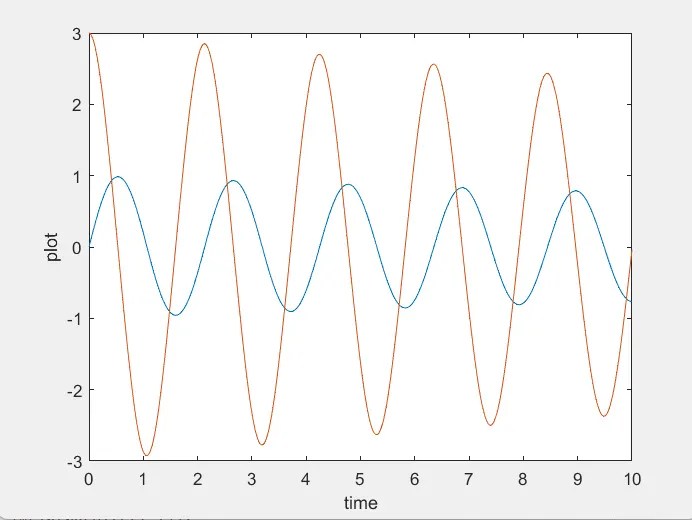
Aim : To creat a animation of simple pendulum by using second order differential equation. A nd also to plot the graph between angular velocity and displacement.
Theory : A simple pendulum is a weight suspended from a pivot,so that it can swing freely.
It consists of a mass rod , frictionless pivot or point of suspension, angular displacement, bob.
Equation :
d^2 (theta) / dt^2 + b/m * d(theta)/dt + g/l *sin(theta).
here we are taking as
- l = length = 1 meter.
- b = damping = 0.05
- m = mass = 1 kg.
- g = gravity = 9.81 m/s^2.
Code explanation :
We start the code with clear all close all clc.
We give the initial conditions.
Next we give the initial points.
we solve the odes .
we plot the results and we give the xlabel and ylabel.
Next we aniamte the transit motion of the simple pendulum motion
Finally we start making video of simple pendulum.
Code :
clear all
close all
clc

b=0.05;
g=9.81;
l=1;
m=1;

% initial conditions
theta_0 = [0;3];

% initial points
t_span = linspace(0,10,500);

%solve ode
[t,results] = ode45(@(t,theta) ode_func(t,theta,b,g,l,m),t_span,theta_0);

plot(t,results(:,1))
hold on
plot(t,results(:,2))
ylabel('plot')
xlabel('time')

% animation the transient motion of the simple pendulum.


ct=1;
for i= 1:length(results(:,1));
    x0 = 0;
    y0 = 0;
    x1 = l*sin(results(i,1));
    y1 = -l*cos(results(i,1));

    figure(2)

    plot([-1 1],[0 0])
    hold on

    plot([x0 x1],[y0 y1],'linewidth',3,'color','b')
    axis([-2 2 -2 2])

    plot(x1,y1,'o','markersize',20,'color','r')
    pause(0.001)
    grid on
    M(ct) = getframe(gcf)
    hold off

    ct = ct+1
end

%making the file video

movie(M)
videofile = VideoWriter('simple pendulum.avi')
open(videofile)
writeVideo(videofile,M)
close(videofile)
Function code :
function [ dtheta_dt] = ode_func(t,theta,b,g,l,m)

theta1 = theta(1)
theta2 = theta(2)
dtheta1_dt = theta2;
dtheta2_dt = -(b/m)*theta2 - (g/l)*sin(theta1);
dtheta_dt = [dtheta1_dt; dtheta2_dt];
end
Plot :
Animation video :
Errors occured :
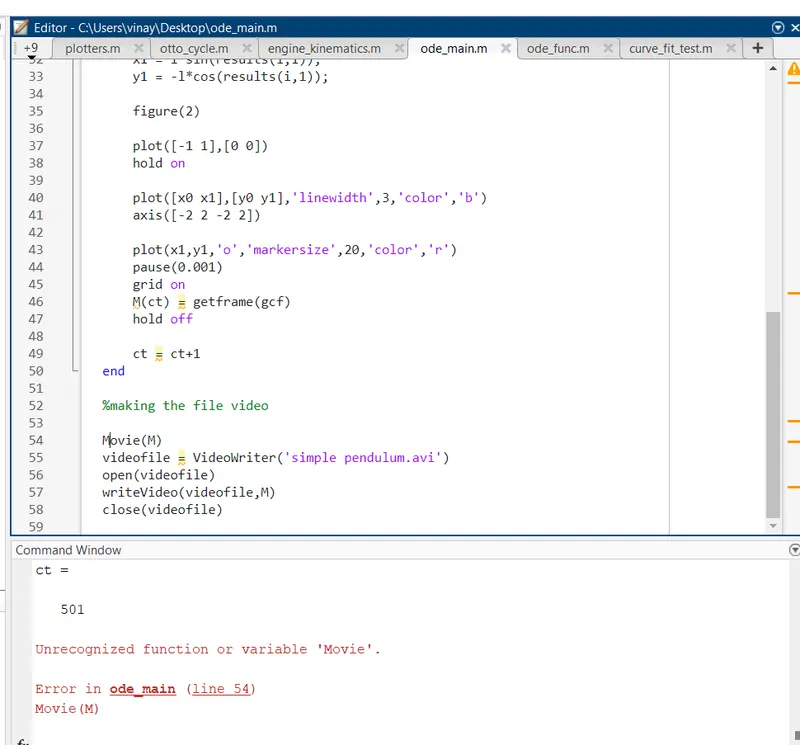
Solution : small error that instered of 'M' we use small 'm'.