Week 3 - Solving second order ODEs
AIM :- write the program to solve second order ODE using Matlab and aminate the oscillation of the simple pendulum.
ODE= Order Differential Equation.
ODE is the extremely I important in engineering the describe a lot of important finominal and solving these ODES can actually help us understand the systems.
This equation is derived to solve the second-order ODE
Where :-
theta-angular displacement
b=damping coiefficient
I-length of connecting string
t=osilating time
m= mass
g= gravity
Writing function command program:
Function command is nothing but a piece of code that we can reuse by just calling its name and passing in the right parameters.
writing of function code :-
function [dtheta_dt]= ode_func(t,theta,b,m,g,l)

theta1 = theta(1)
theta2 = theta(2)
dtheta1_dt = theta2
dtheta2_dt = -(b/m)*theta2-(g/l)*sin(theta1)
dtheta_dt = [dtheta1_dt;dtheta2_dt]
end
Function[dtheta_dt] =ode_func(t,theta,b,m,g,1)
thetal theta (1)
theta2 = theta (2)
dthetal_dt = theta2
dtheta2_dt = -(b/m) *theta2-(g/l)* sin(thetal) dtheta_dt [dthetal_dt; dtheta2_dt] = end coding
• At first, we have to use the word Function to start the function command.
• And then we want to create a templet and this is a code templet and name for the templet.
• We are going to name the code templet as ode_function.
• We are going to use this equation to solve the ode equation.
• So whenever we want to substitute different values we just call this function and then pass in the right values.
• Then we have to save the function while saving the name of the function and the name of the file should exactly be the same.
• The calling the function means using the function and using the templates with the appropriate values.
• We have to ensure the no of inputs we provide match the orders of inputs also match.
• And this equation is very large so we are going to break it up into several terms.
• End word id is used to end the function command.
MAIN CODE :-
%solving the second order ODE
close all
clear all
clc

%inputs
l=1
m=1
b=0.05
g=9.81

%initial conditions
theta_0=[0;3];

%time points
t_span=linspace(0,20,500);

%solving of the ODE
[t,results]=ode45(@(t,theta)ode_func(t,theta,b,m,g,l),t_span,theta_0)

figure(1)
plot(t,results(:,1))
hold on
plot(t,results(:,2))
ylabel('plot')
xlabel('time')

ct=1
for i=1:length(results(:,1));
    x0=0
    y0=0
    y1=-1*cos(results(i));
    x1=1*sin(results(i));

%plotting
figure(2)
plot([-1 1],[0 0],'linewidth',3,'Color','b')
hold on
plot([x0 x1],[y0 y1],'LineWidth',2,'Color','y')
plot(x1,y1,'marker','o','Markersize',25,'Markerfacecolor','r')
axis([-1.5 1.5 -1.5 0.5])
M(ct) = getframe(gcf);
ct=ct+1
hold off
end


movie(M)
videofile=VideoWriter('ode_challenge.avi','uncompressed avi')
open(videofile)
writeVideo(videofile,M)
close(videofile)
• To get started we have to open a new file.
• Whenever we start a new program it is good practice to include some commands input variables are taken.
• We have to ensure the no of inputs we provide match the orders of inputs also match.
• We have to ensure that both the function program and the working program must be in the same folder.
• And then we have to calculate the required values after calculating the required values.
• We have to use the plot command to create a graph.
OUTPUTS :-
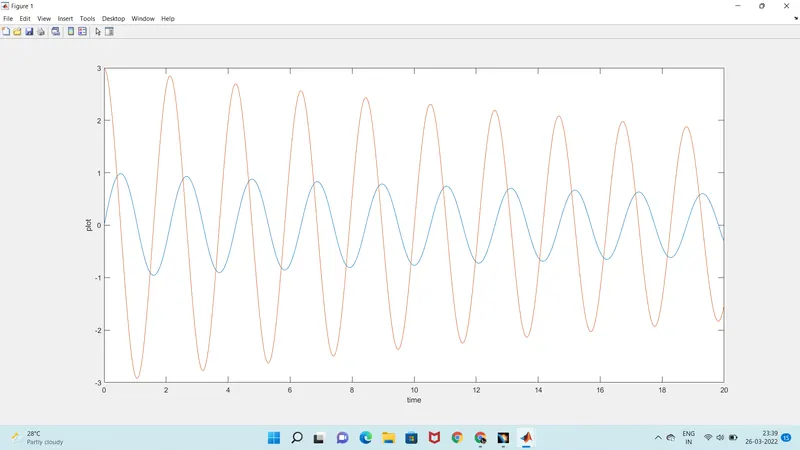
ANIMATION VIDEO :-
YOUTUBE LINK :-