Week 3.2 - 2R Robotic Arm Challenge
https://youtu.be/yKcOOmCAd4c .... here is the link for my youtube video to the output of this challenge!!!
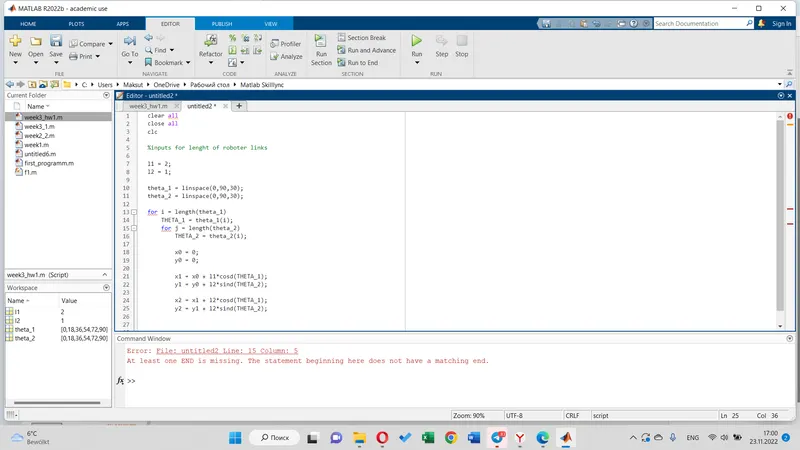 here I forgot to write one 'end' of for loop, but it was easy to overcome this problem, because command window shows me where is the problem
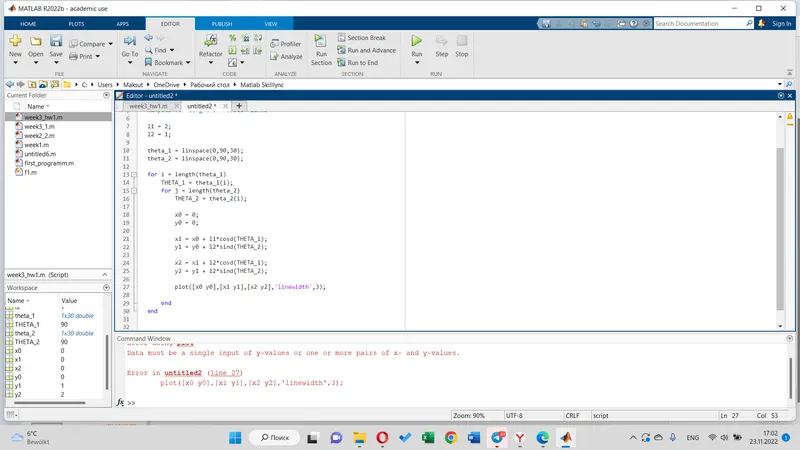 and here I did mistake in plotting in assigning coordinates.
% as a first step I defined inputs of roboter arms
l1 = 1;
l2 = 0.5;

%after that I defined my angles of these arms using linspace command in order to have angles in gradually changing order

theta_1 = linspace(0,90,10);
theta_2 = linspace(0,90,10);

%as a next step, I used for loop to assign every element of theta_1 array to THETA1 and respetively second for loop of 2nd angle to THETA2 so that we can later use these angles in our calculation

ct = 1;
for i = 1 : length(theta_1)
  THETA1 = theta_1(i);
  for j = 1 : length(theta_2)
    THETA2 = theta_2(j);

    %after that I defined my initial points of first arm
    x0 = 0;
    y0 = 0;

    %and the final coordinates of first arm using calculation with cos and sin
    x1 = l1 * cosd(THETA1);
    y1 = l1 * sind(THETA1);

    %and also final coordinates of second arm, initial coordinates of 2nd we already have, because it is connected to 1st arm
    x2 = x1 + l2 * cosd(THETA2);
    y2 = y1 + l2 * sind(THETA2);

    %here I did plottting of these two arms gradually changing with respect to angles with the help of pause command
    plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
    axis(-0.1 1.5 0 1.5)
    pause(0.3)

    %and finally in order to animate how the position of two arms changes, I wrote M command
    M(ct) = getframe(gcf);
    ct = ct + 1;
   %I used 'ct' so that I could have chaning order of my for loops

    end
end

%now I have to exectue required commands to make video of my animation.

movie(M)
videofile = VideoWriter('forward_kinematics',Uncompressed AVI')
open(videofile)
writeVideo(videofile,M)
close(videofile)