Week 2- 2R Robotic Arm Challenge
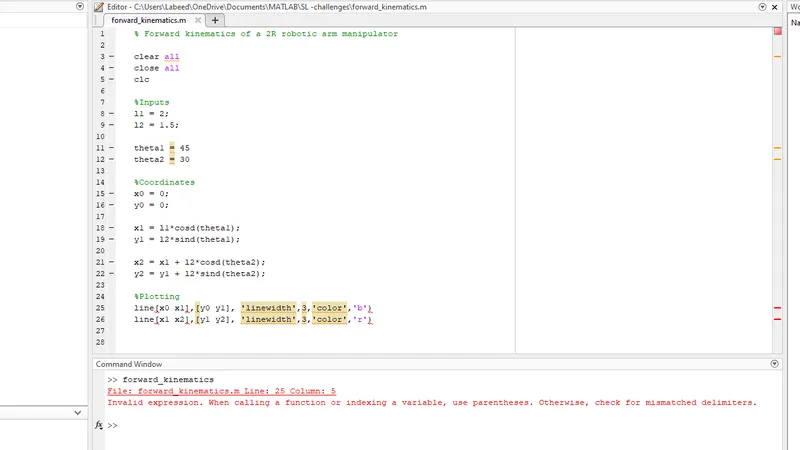
% Forward kinematics of a 2R robotic arm manipulator

clear all
close all
clc

%Inputs
l1 = 2;
l2 = 1.5;

theta1 = 45
theta2 = 30

%Coordinates
x0 = 0;
y0 = 0;

x1 = l1*cosd(theta1);
y1 = l2*sind(theta1);

x2 = x1 + l2*cosd(theta2);
y2 = y1 + l2*sind(theta2);

%Plotting
line([x0 x1],[y0 y1], 'linewidth',3,'color','b')
line([x1 x2],[y1 y2], 'linewidth',3,'color','r')
(*Error1)
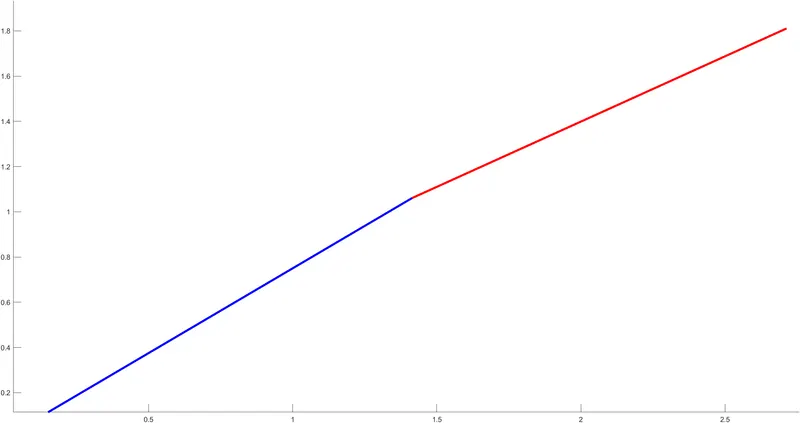
First plot of a 2R robotic arm
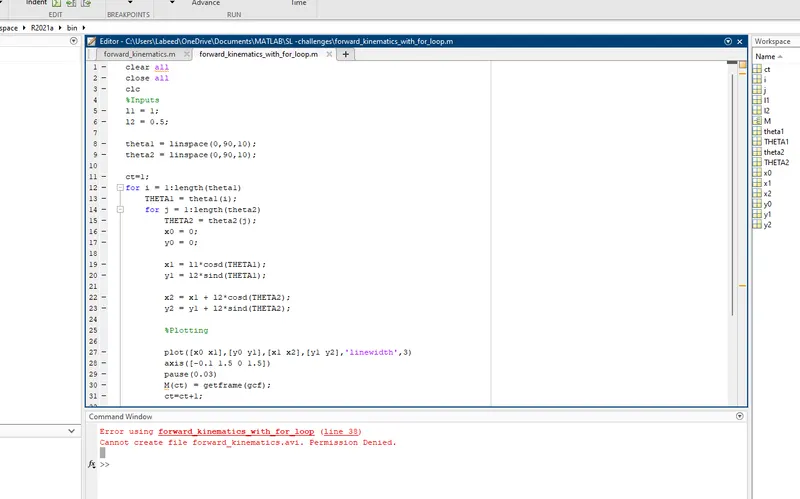
Program for animation:
*Objective:- The objective is to have multiple values of theta1 and theta2 and for each value of theta1 and theta2 we are going to be creating plots and simultaneously stiching all plots to make a animation.
clear all
close all
clc
%Inputs
l1 = 1;
l2 = 0.5;

theta1 = linspace(0,90,10);
theta2 = linspace(0,90,10);

ct=1;
for i = 1:length(theta1)
    THETA1 = theta1(i);
    for j = 1:length(theta2)
        THETA2 = theta2(j);
        x0 = 0;
        y0 = 0;

        x1 = l1*cosd(THETA1);
        y1 = l2*sind(THETA1);

        x2 = x1 + l2*cosd(THETA2);
        y2 = y1 + l2*sind(THETA2);

        %Plotting

        plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
        axis([-0.1 1.5 0 1.5])
        pause(0.03)
        M(ct) = getframe(gcf);
        ct=ct+1;


    end
end

movie(M)
videofile = VideoWriter('forward_kinematics.avi','Uncompressed AVI');
open(videofile)
writeVideo(videofile,M)
close(videofile)
Error in creating Video file: