Week 2- 2R Robotic Arm Challenge
AIM:- Program in Matlab to simulate the forward kinematics of a 2R Robotic Arm
Theory:-
Forward kinematics refers to use of kinematics equation of a robot to compute the position of end effector from specified values for the joint parameters. If we know the geometry of the robot and all its joint points, we can do the math and figure out the position and orientation of any point on the robot.
2R Robotic Arm Diagram :-
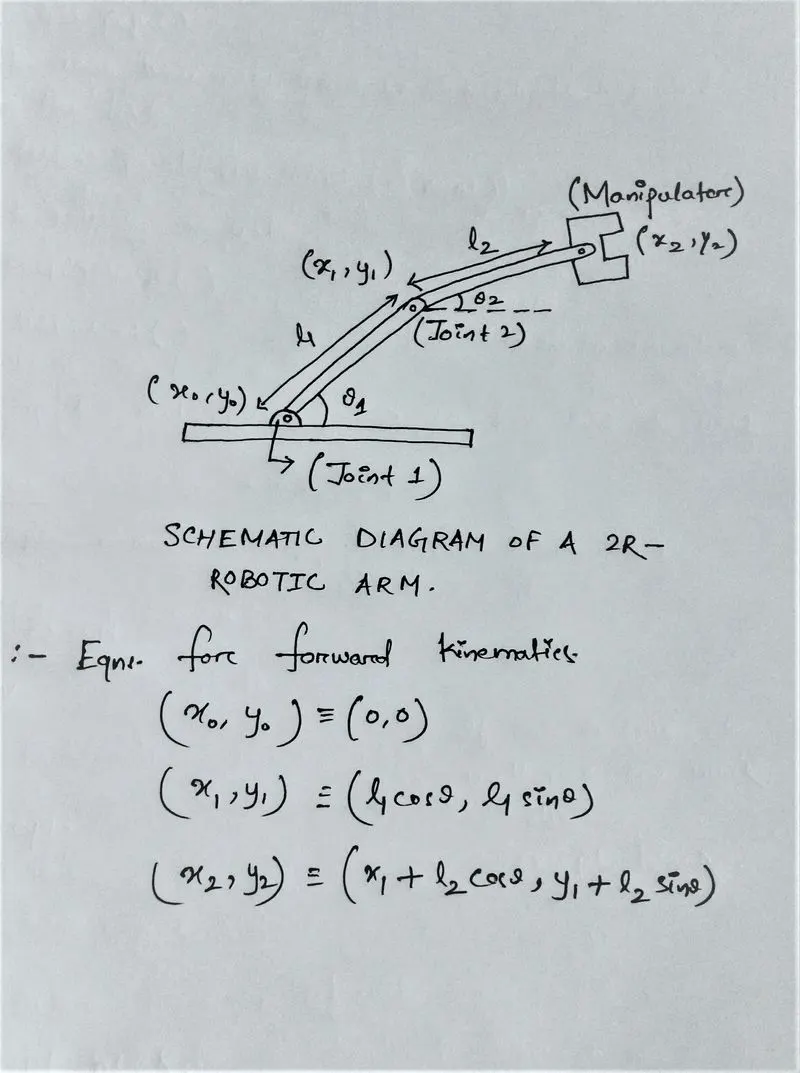
Program:-
clear all
close all
clc
% inputs
l1 = 1.5
l2 = 0.7
theta1=linspace(0,120,10)
theta2=linspace(0,120,10)
ct=1;
for i=1:length(theta1)
THETA1=theta1(i);
for j=1:length(theta2)
THETA2=theta2(j);
x0=0;
y0=0;
x1=l1*cosd(THETA1);
y1=l1*sind(theta1);
x2=x1+l2*cosd(THETA2);
y2=y1+l2*sind(THETA2);
% Plotting
plot([x0 x1] , [y0 y1] , [x1 x2],[y1 y2],'linewidth',3)
axis([-0.1 1.5 0 1.5])
pause(0.1)
M(ct)=getframe(gcf);
ct=ct+1;
end
end