Week 2- 2R Robotic Arm Challenge
% forward kinematics using for loop
clear all
close all
clc
% inputs dimension of link
l1=1;
l2=2;
theta1=linspace(0,90,10);
theta2=linspace(0,90,10);
ct=1;
for i = 1:length(theta1)
THETA1 = theta1(i);
for j = 1:length(theta2)
THETA2 = theta2(j);
% cordinates
x0 = 0;
y0 = 0;
x1 = l1*cosd(THETA1);
y1 = l1*sind(THETA1);
x2 = x1+l2*cosd(THETA2);
y2 = y1+l2*sind(THETA2);
% ploting robotic arms
plot( [x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
axis( [0.1 1.5 0 2])
pause(0.3)
m(ct)=getframe(gcf);
ct=ct+1
end
end
% Creating movie of forward kinematics
movie(m)
videofile= videowriter('forward_kinematics.avi','uncompressed AVI');
open(videofile)
writevideo(videofile,m)
close(videofile)
% Google drive link of plot
https://1drv.ms/u/s!Ao30PvmoKS8ZgRx-bKxtexwiRrX2?e=jBnbyi
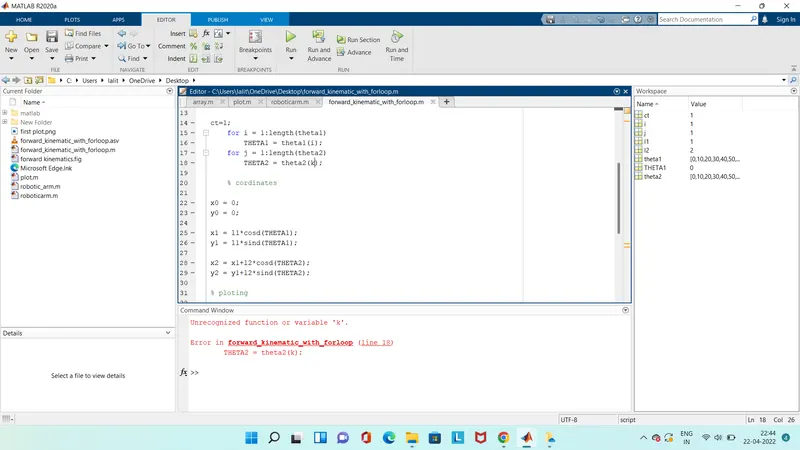
% Error face while programming
1.Using forloop for forrward kinematics
% Step taken to over come the error
1.watching video of 2R robotic arm & practicing code shown in video.
% Screen short of problem face while duing programing.
.