Week 2- 2R Robotic Arm Challenge
Aim:
To program and simulate Forward Kinematics of a 2R Robotic Arm using Matlab Software.
Procedure:
To calculate the Forward Kinematics of a 2R Robotic Arm we use the below formula
Formula for 1st Arm:
x1=l1*cosθ
y1=l1*sinθ
Formula for 2nd arm:
x2=x1+l2*cosθ
y2=y1+l2*sinθ
where,
l = Length of the Arm.
θ = degree of the arm
x = value of arm in x-axis
y = value of arm in y-axis
Coding:
% use input commands
theta is valued from 0° to 90° with interval of 5 for 0° to 90°.
'for' loop is used to calculate the values of intervals of a with respect to theta.
Animation is played with 0.03 seconds of time interval
Movie file has been created as below,
% Forward Kinematic of a 2R Robotic Arm
clear all
close all
clc

% inputs
l1=2;
l2=0.8;
theta1=[1:5:90];
theta2=[1:5:90]

ct=1
for a = 1:length(theta1);
    THETA1= theta1(a);
    for b = 1:length(theta2);
        THETA2= theta2(b);

        x0=0;
        y0=0

        x1=l1*cosd(THETA1);
        y1=l1*sind(THETA1);

        x2=x1+l2*cosd(THETA2);
        y2=y1+l2*sind(THETA2);

        % plotting
        plot([x0 x1], [y0 y1], [x1 x2], [y1 y2], 'linewidth',3);
        xlabel('X-Axis');
        ylabel('Y-Axis');
        axis([0 3 0 3]);
        pause(0.03);
        M(ct) = getframe(gcf);
        ct=ct+1
    end
end

movie(M)
videofile = VideoWriter('Forward Kinematic of a 2R Robotic Arm.avi', 'Uncompressed AVI')
open(videofile)
writeVideo(videofile,M)
close(videofile)
Once the above codings are given, click on 'Run' button to get the results.
Output Result File:
The Output result file animation is attached in below link in google drive & as Youtube Link.
https://drive.google.com/file/d/1WfKBGmpmp8vZSVnxHS1tXVLO7mGunnUM/view?usp=drivesdk
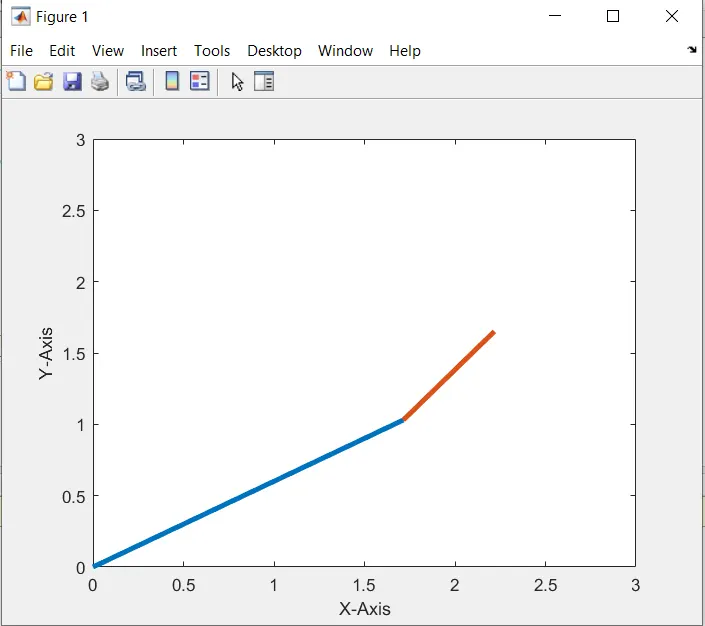
Sample image has been screenshot and showed below.
Errors Faced:
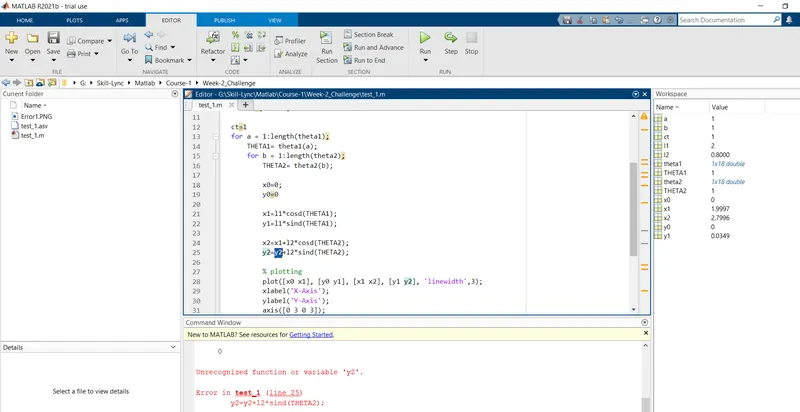
Error1: In y2 equation instead of y1 i have used y2, so the results is not created.
So, i have changed the variable from y2 to y1 to solve the error
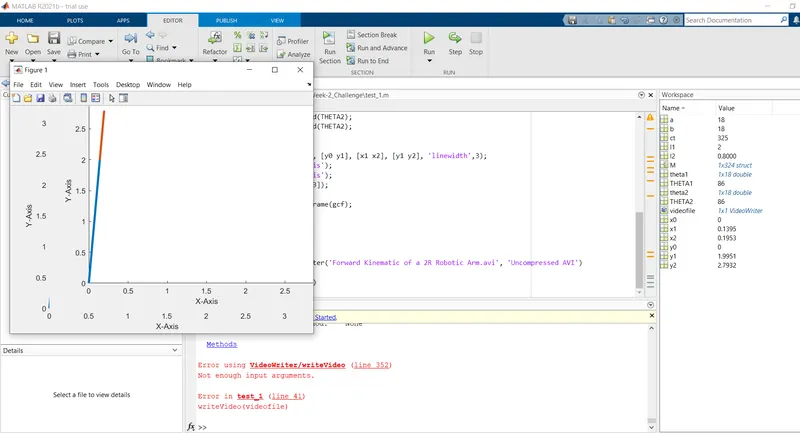
Error2: while creating the writeVideo(videofile) i have missed variable 'M' , so the animation video is not created.
I have included the variable 'M' in the command as writeVideo(videofile,M) to solve the error.
Conclusion:
The above coding and simulation attached shows the 2R Robotic Arm using Forward Kinematics and the errors occured is also attached.