Week 2- 2R Robotic Arm Challenge
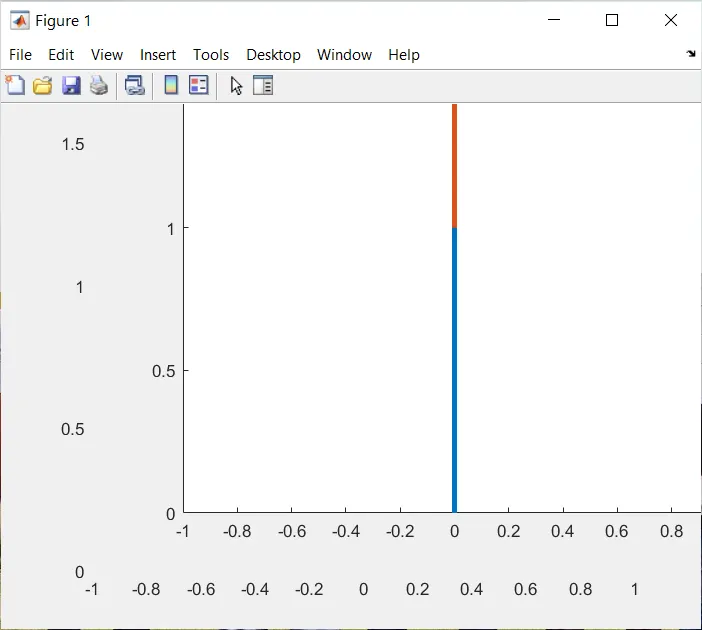
close all
clear all
clc
% inputs l1 = 1;
l2 = 0.5;
ct=1;
theta1 = linspace(0,90,10);
theta2 = linspace(0,90,10);
for i = 1:length(theta2)
THETA1 = theta1(i);
for j = 1 : length (theta2)
THETA2 = theta2(j);
x0 = 0; y0 = 0;
x1 = l1*cosd(THETA1);
y1 = l1*sind(THETA1);
x2 = x1 + l1*cosd(THETA2);
y2 = y1 + l2*sind(THETA2);
% plotting
plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
pause(0.03)
axis([-1 1 0, 1.5])
M(ct)= getframe(gcf); ct=ct+1;
end
end
movie(M)
videofile = VideoWriter('forwardroboticarmmanipulator','Uncompressed AVI');
open(videofile)
writeVideo(videofile,M)
close(videofile)
THAT WAS THE CODE I EXECUTED & I FACED SOME MINOR PROBLEMS WHILE EXECUTING, IF THERE IS ANY FURTHER MISTAKES PLEASE MENTION OR GET INTO MY NOTICE