Week 2- 2R Robotic Arm Challenge
close all
clear all
clc
% To simulate the forward kinematics of a 2R Robotic Arm
% Initially we should assume some values is as following :

% Length of Link 1 (m)
L1 = 1;
% Length of Link 2 (m)
L2 = 0.5;
% Angle for link 1  (Degree)
theta1 = linspace(0,90,10);
% Angle for link 2  (Degree)
theta2 = linspace(0,90,10);
ct = 1
for i = 1:10
    THETA1 = theta1(i);
    for j =1:10
        THETA2 = theta2(j);
         % Co-ordinates at the base of 1 st link
         X0 = 0
         Y0 = 0
         % Co-ordinates at the base of 2 nd link or at the end of 1 st link
         X1 = L1*cosd(THETA1);
         Y1 = L1*sind(THETA1);
         % Co-ordinates at the end of 2 nd link
         X2 = X1 + L2*cosd(THETA2);
         Y2 = Y1 + L2*sind(THETA2);
         % Plotting

         plot([X0 X1],[Y0 Y1],[X1 X2],[Y1 Y2],'LineWidth',3);
         axis([-1 1.5 0 1.5])
         pause(0.05)
         M(ct) = getframe(gcf)
         ct = ct + 1

    end
end
movie(M)
videofile = VideoWriter('Forward_kinematics_of_a_2R_Robotic_Arm.avi','Uncompressed AVI')
open(videofile)
writeVideo(videofile,M)
close(videofile)EXPLANATION:
Assumption done initially is explained as following :
1) % Length of Link 1 (meter) assumed as
L1 = 1;
% Length of Link 2 (meter) assumed as
L2 = 0.5;
2) % Angle for link 1 (Degree)
theta1 = linspace(0,90,10);
% Angle for link 2 (Degree)
theta2 = linspace(0,90,10);
'Linspace' command is used for showing (X1,X2,n) angles bet 0 to 90 degree with equally spaced for 10 nos.Theta is the angle between link and imaginary horizontal plane parallel to x axis .
3) for i = 1:10
THETA1 = theta1(i);
for j =1:10
THETA2 = theta2(j);
For loop is used for showing angles in a sequence from 1 to 10. Eg :(0,10,20,30,40,50,60,70,80,90)
4) % Co-ordinates at the base of 1 st link
X0 = 0
Y0 = 0
% Co-ordinates at the base of 2 nd link or at the end of 1 st link
X1 = L1*cosd(THETA1);
Y1 = L1*sind(THETA1);
% Co-ordinates at the end of 2 nd link
X2 = X1 + L2*cosd(THETA2);
Y2 = Y1 + L2*sind(THETA2);
As assumption according to theta length of link in x & y axis is calculated and formulated
5) plot([X0 X1],[Y0 Y1],[X1 X2],[Y1 Y2],'LineWidth',3);
axis([-1 1.5 0 1.5])
pause(0.05)
ct = ct + 1
M(ct) = getframe(gcf)
Plotting of graph is generated using x & y co-ordinates ,with pause command for playback time ,axis for representation coordinates
6) movie(M)
videofile = VideoWriter("Forward_kinematics_of_a_2R_Robotic_Arm.m")
open(videofile)
writeVideo(videofile)
close(videofile)
Above commands will remain same for creation of animation .
ERRORS:
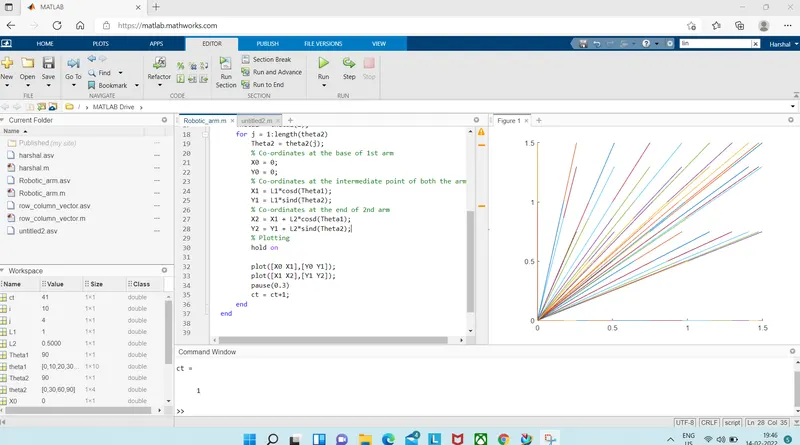
Solution :
% Co-ordinates at the base of 2 nd link or at the end of 1 st link
X1 = L1*cosd(THETA1);
Y1 = L1*sind(THETA2);
% Co-ordinates at the end of 2 nd link
X2 = X1 + L2*cosd(THETA1);
Y2 = Y1 + L2*sind(THETA2);
Steps taken to overcome errors
% Co-ordinates at the base of 2 nd link or at the end of 1 st link
X1 = L1*cosd(THETA1);
Y1 = L1*sind(THETA1);
% Co-ordinates at the end of 2 nd link
X2 = X1 + L2*cosd(THETA2);
Y2 = Y1 + L2*sind(THETA2);